Skip to content · ⁨Перейти к содержанию⁩
Subjects · ⁨Предметы⁩

AP Physics C: Mechanics · ⁨AP Физика C: Механика⁩

Tips · ⁨Советы⁩

AP Physics C: Механика — это версия с использованием математического анализа: кинематика, силы, работа, энергия и мощность, импульс, момент силы и вращение, а также колебания. Она охватывает меньший объем материала, чем Физика 1, но углубляется значительно глубже, и математический анализ не является украшением — он используется для вывода результатов и так, как их ожидает экзамен.

На практике: интегрировать, чтобы получить суммарную величину из меняющейся, и дифференцировать от положения к скорости к ускорению, уверенно и без напоминаний.

Вращательная динамика занимает много времени, потому что моменты инерции должны составляться как интегралы, а не вспоминаться.

Конспекты рассматривают каждый раздел в порядке CED с полным выводом матана. В библиотеке лежат прошедшие экзамены и критерии оценки. Поскольку многие баллы зависят от подготовки, а не от арифметики, в разборах специально показано, как строится интеграл, прежде чем он будет вычислен.

  • 1

    Kinematics · ⁨Кинематика⁩

    Watch lesson · ⁨Смотреть урок⁩
    1.1

    Scalars and Vectors

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 1.1.A: Describe a scalar or vector quantity using magnitude and direction, as appropriate.

    • 1.1.A.1 Scalars are quantities described by magnitude only; vectors are quantities described by both magnitude and direction.
    • 1.1.A.2 Vectors can be visually modeled as arrows with appropriate direction and lengths proportional to their magnitude.
    • 1.1.A.3 Distance and speed are examples of scalar quantities, while position, displacement, velocity, and acceleration are examples of vector quantities.
    • 1.1.A.4 Vectors can be expressed in unit vector notation or as a magnitude and a direction.
      • 1.1.A.4.i Unit vector notation can be used to represent vectors as the sum of their constituent components in the $x$-, $y$-, and $z$-directions, denoted by $\hat{i}$, $\hat{j}$, and $\hat{k}$, respectively.
        • Equation: $\vec{r} = \left( A\hat{i} + B\hat{j} + C\hat{k} \right)$
      • 1.1.A.4.ii The position vector of a point is given by $\vec{r}$, and the unit vector in the direction of the position vector is denoted $\hat{r}$.
      • 1.1.A.4.iii A resultant vector is the vector sum of the addend vectors' components.
        • Equation: $\vec{C} = \vec{A} + \vec{B}$
        • Equation: $\vec{C} = \left( A_x + B_x \right)\hat{i} + \left( A_y + B_y \right)\hat{j}$
    • 1.1.A.5 In a given one-dimensional coordinate system, opposite directions are denoted by opposite signs.
    Русский

    Цель обучения 1.1.A: Описывать скалярную или векторную величину с помощью модуля и направления, в зависимости от ситуации.

    • 1.1.A.1 Скаляры — это величины, описываемые только модулем; векторы — это величины, описываемые как модулем, так и направлением.
    • 1.1.A.2 Векторы можно визуализировать в виде стрелок с соответствующим направлением и длиной, пропорциональной их модулю.
    • 1.1.A.3 Расстояние и скорость являются примерами скалярных величин, тогда как положение, перемещение, скорость и ускорение — примерами векторных величин.
    • 1.1.A.4 Векторы могут быть представлены в виде разложения по единичным векторам или как величина (модуль) и направление.
      • 1.1.A.4.i Разложение по единичным векторам используется для представления векторов как суммы их составляющих компонент в направлениях $x$-, $y$- и $z$-, обозначаемых как $\hat{i}$, $\hat{j}$ и $\hat{k}$ соответственно.
        • Уравнение: $\vec{r} = \left( A\hat{i} + B\hat{j} + C\hat{k} \right)$
      • 1.1.A.4.ii Вектор положения точки задается формулой $\vec{r}$, а единичный вектор в направлении вектора положения обозначается как $\hat{r}$.
      • 1.1.A.4.iii Результирующий вектор представляет собой векторную сумму компонент векторов-слагаемых.
        • Уравнение: $\vec{C} = \vec{A} + \vec{B}$
        • Уравнение: $\vec{C} = \left( A_x + B_x \right)\hat{i} + \left( A_y + B_y \right)\hat{j}$
    • 1.1.A.5 В заданной одномерной координатной системе противоположные направления обозначаются противоположными знаками.
    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Kinematics 运动学 describes motion. Two kinds of quantity:

    • A scalar 标量 has only size (magnitude 大小): distance, speed, mass, time.
    • A vector 矢量 has magnitude and direction: displacement, velocity, acceleration, force.

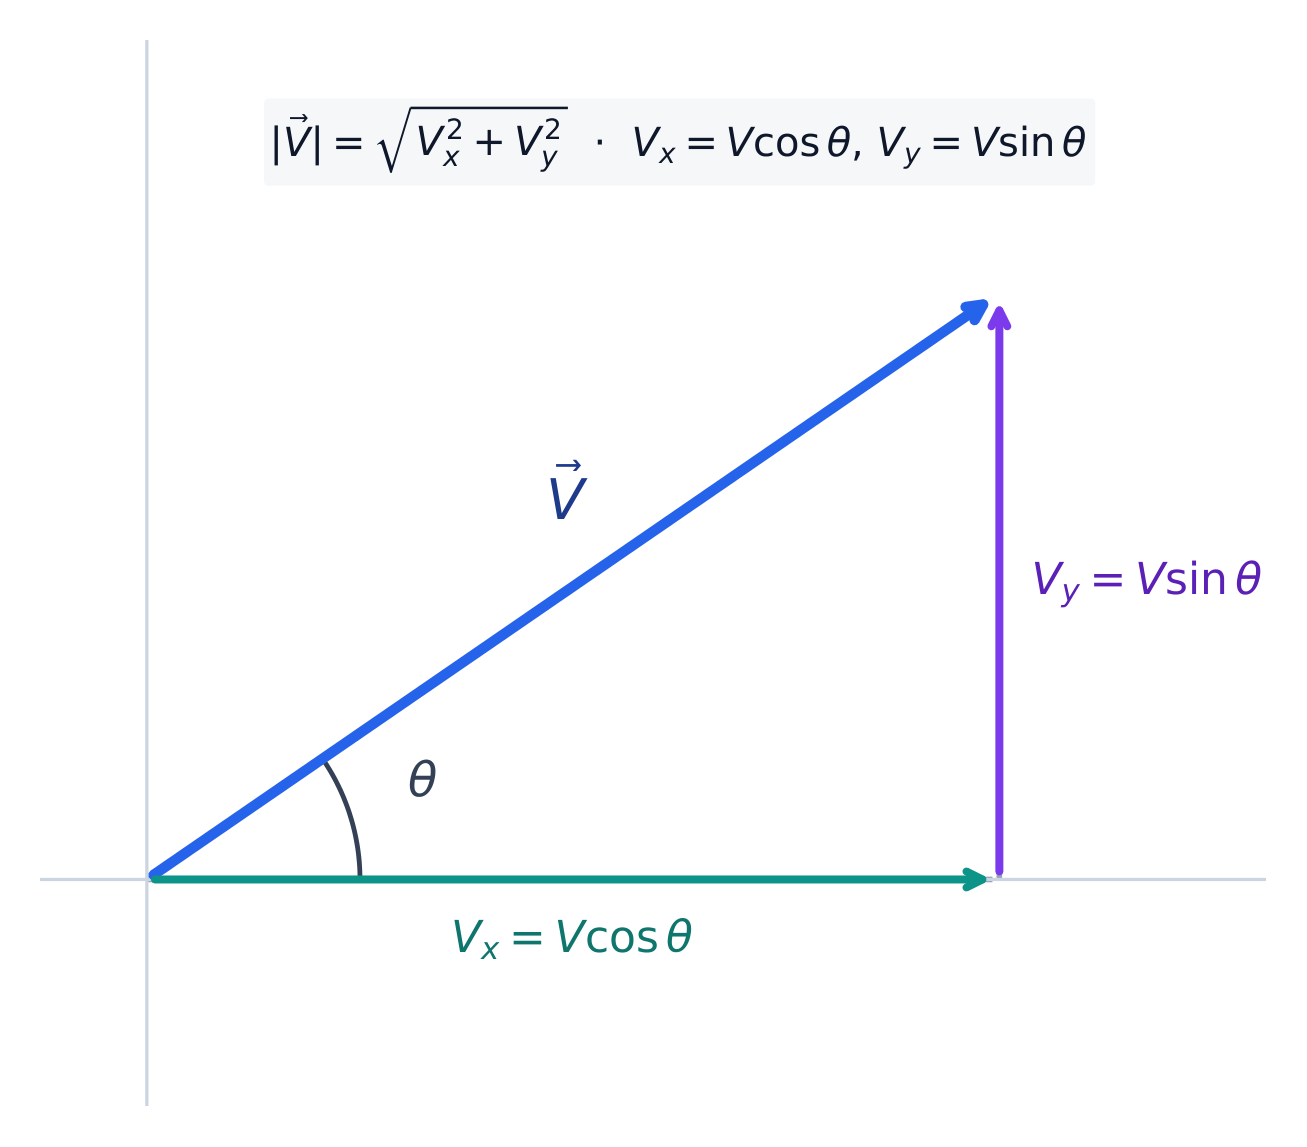
    In this calculus-based course you resolve vectors into components 分量 and add them component by component; a vector's magnitude is $\sqrt{v_x^2+v_y^2+\cdots}$. Physics C also writes vectors with unit vectors 单位矢量: $\vec{v}=v_x\hat{i}+v_y\hat{j}$, where $\hat{i}$ and $\hat{j}$ are directions of length one along $x$ and $y$ – handy because calculus can then act on each component separately.

    Resolving a vector into its x and y components
    Resolving a vector into its x and y components
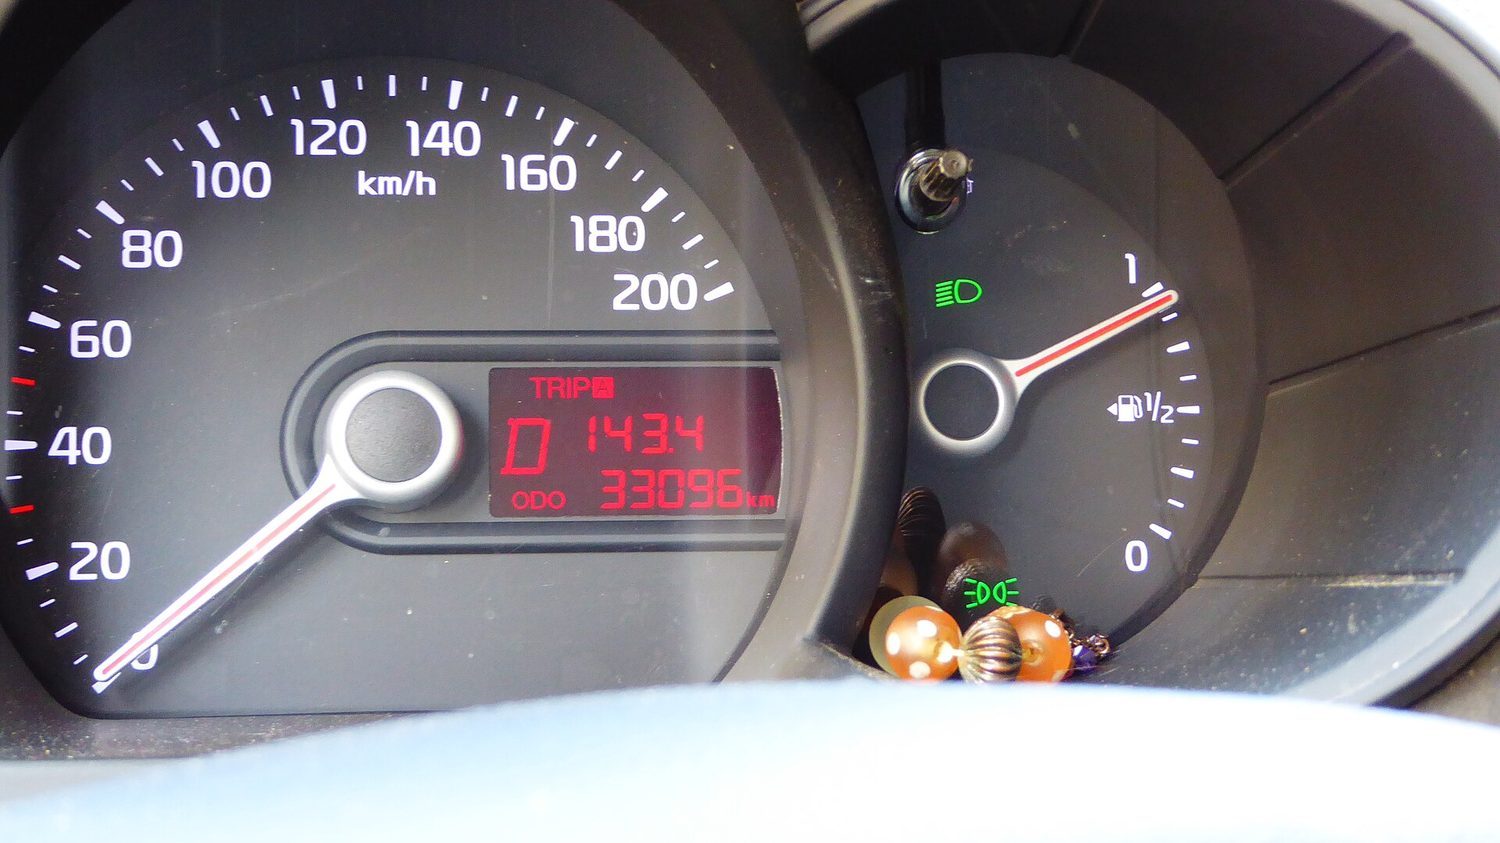
    A car speedometer: speed is the magnitude of velocity — a scalar rate of motion
    A car speedometer: speed is the magnitude of velocity — a scalar rate of motion
    Explore · ⁨Исследовать⁩

    Explore the dot product · ⁨Исследуйте скалярное произведение⁩

    Drag the components of $\vec{A}$ and $\vec{B}$. The dot product $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ reaches zero exactly when the two vectors are perpendicular — the geometry behind $\cos\theta$. · ⁨Перетаскивайте компоненты $\vec{A}$ и $\vec{B}$. Скалярное произведение $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ достигает нуля ровно тогда, когда два вектора перпендикулярны — это геометрия за $\cos\theta$.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Kinematics/ˌkɪnɪˈmætɪks/ Кинематика
    scalar/ˈskeɪlə/ скаляр
    magnitude/ˈmæɡnɪtjuːd/ величина
    vector/ˈvektə/ векторное
    components/kəmˈpəʊnənts/ компоненты
    unit vectors/ˈjuːnɪt ˈvektəz/ единичные векторы
    1.2

    Displacement, Velocity, and Acceleration

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 1.2.A: Describe a change in an object's position.

    • 1.2.A.1 When using the object model, the size, shape, and internal configuration are ignored. The object may be treated as a single point with extensive properties such as mass and charge.
    • 1.2.A.2 Displacement is the change in an object's position.
      • Equation: $\Delta x = x - x_0$

    Learning Objective 1.2.B: Describe the average velocity and acceleration of an object.

    • 1.2.B.1 Averages of velocity and acceleration are calculated considering the initial and final states of an object over an interval of time.
    • 1.2.B.2 Average velocity is the displacement of an object divided by the interval of time in which that displacement occurs.
      • Equation: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
    • 1.2.B.3 Average acceleration is the change in velocity divided by the interval of time in which that change in velocity occurs.
      • Equation: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
    • 1.2.B.4 An object is accelerating if either the magnitude and/or direction of the object's velocity are changing.
    • 1.2.B.5 Calculating average velocity or average acceleration over a very small time interval yields a value that is very close to the instantaneous velocity or instantaneous acceleration.

    Learning Objective 1.2.C: Describe the instantaneous position, velocity, and acceleration of an object as a function of time.

    • 1.2.C.1 As the time interval used to calculate the average value of a quantity approaches zero, the average value of that quantity approaches the value of the quantity at that instant, called the instantaneous value.
      • 1.2.C.1.i Instantaneous velocity is the rate of change of the object's position, which is equal to the derivative of position with respect to time.
        • Equation: $\vec{v} = \dfrac{d\vec{r}}{dt}$
        • Equation: $v_x = \dfrac{dx}{dt}$
      • 1.2.C.1.ii Instantaneous acceleration is the rate of change of the object's velocity, which is equal to the derivative of velocity with respect to time.
        • Equation: $\vec{a} = \dfrac{d\vec{v}}{dt}$
        • Equation: $a_x = \dfrac{dv_x}{dt}$
    • 1.2.C.2 Time-dependent functions and instantaneous values of position, velocity, and acceleration can be determined using differentiation and integration.
    Русский

    Цель обучения 1.2.A: Описывать изменение положения объекта.

    • 1.2.A.1 При использовании модели материальной точки размер, форма и внутренняя конфигурация игнорируются. Объект может рассматриваться как единая точка с экстенсивными свойствами, такими как масса и заряд.
    • 1.2.A.2 Перемещение — это изменение положения объекта.
      • Уравнение: $\Delta x = x - x_0$

    Цель обучения 1.2.B: Описывать среднюю скорость и среднее ускорение объекта.

    • 1.2.B.1 Средние значения скорости и ускорения вычисляются с учетом начального и конечного состояний объекта за интервал времени.
    • 1.2.B.2 Средняя скорость — это перемещение объекта, деленное на интервал времени, в течение которого это перемещение происходит.
      • Уравнение: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
    • 1.2.B.3 Среднее ускорение — это изменение скорости, деленное на интервал времени, в течение которого это изменение скорости происходит.
      • Уравнение: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
    • 1.2.B.4 Объект движется с ускорением, если изменяется модуль и/или направление скорости этого объекта.
    • 1.2.B.5 Вычисление средней скорости или среднего ускорения за очень малый интервал времени дает значение, очень близкое к мгновенной скорости или мгновенному ускорению.

    Цель обучения 1.2.C: Описать мгновенное положение, скорость и ускорение объекта как функции времени.

    • 1.2.C.1 По мере того как временной интервал, используемый для вычисления среднего значения величины, стремится к нулю, среднее значение этой величины приближается к значению величины в данный момент времени, называемому мгновенным значением.
      • 1.2.C.1.i Мгновенная скорость — это скорость изменения положения объекта, которая равна производной положения по времени.
        • Уравнение: $\vec{v} = \dfrac{d\vec{r}}{dt}$
        • Уравнение: $v_x = \dfrac{dx}{dt}$
      • 1.2.C.1.ii Мгновенное ускорение — это скорость изменения скорости объекта, которая равна производной скорости по времени.
        • Уравнение: $\vec{a} = \dfrac{d\vec{v}}{dt}$
        • Уравнение: $a_x = \dfrac{dv_x}{dt}$
    • 1.2.C.2 Зависимые от времени функции и мгновенные значения положения, скорости и ускорения могут быть определены с помощью дифференцирования и интегрирования.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Projectile motion is two independent motions

    Because motion can change continuously, define the rates as derivatives 导数:

    $$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$
    Reversing this, integrate to recover velocity and position:
    $$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$
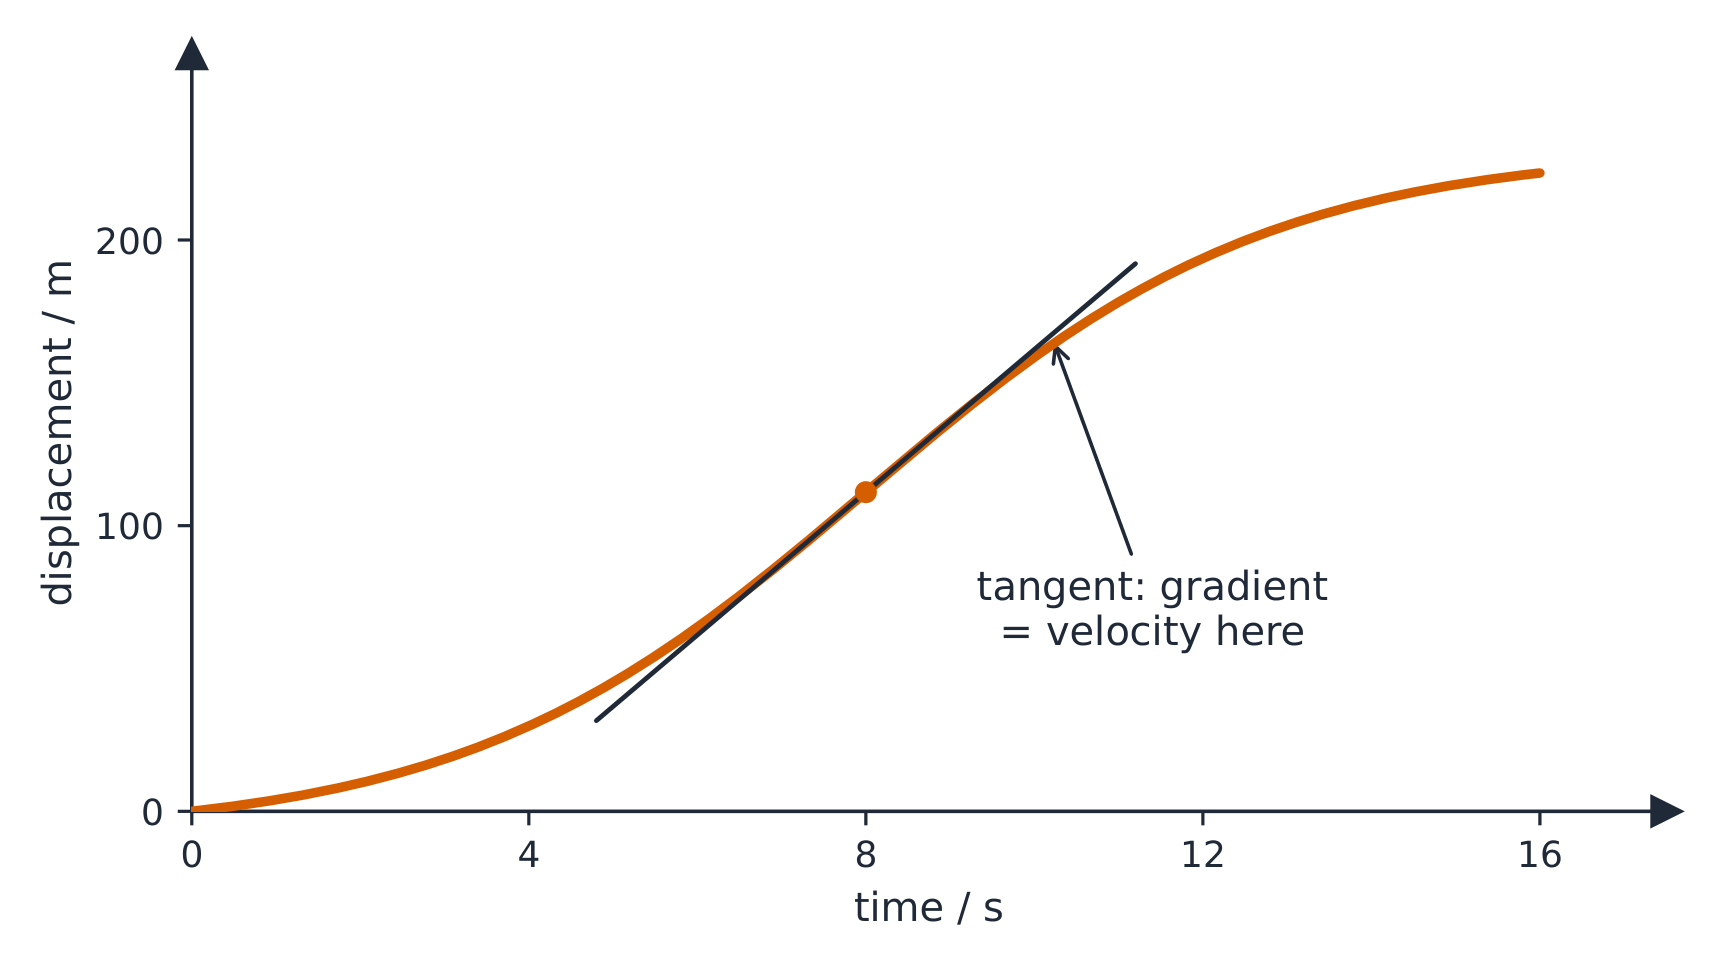
    Distinguish the average from the instantaneous: average velocity 平均速度 is $\Delta x/\Delta t$ over an interval, while instantaneous velocity 瞬时速度 is the derivative at one moment – the slope of the tangent line, and what a speedometer shows.

    For constant acceleration these give the familiar kinematic equations ($v=v_0+at$, $x=x_0+v_0t+\tfrac12at^2$, $v^2=v_0^2+2a\,\Delta x$). The most important constant-$a$ case is free fall 自由落体: near Earth's surface every object, heavy or light, accelerates downward at $g=9.8\ \text{m/s}^2$ once air resistance is negligible. When $a$ or $v$ varies with time, use the integrals directly.

    Worked example. A particle moves with $x(t)=2t^3-3t^2$ (metres). Differentiate for velocity and acceleration:

    $$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$
    At $t=2\ \text{s}$, $v=24-12=12\ \text{m/s}$ and $a=24-6=18\ \text{m/s}^2$. This calculus link – not just the constant-$a$ formulas – is what distinguishes Physics C.

    Worked example. A particle starts from rest at the origin with $a(t)=6t$. Integrate: $v=\int 6t\,dt=3t^2$ and $x=\int 3t^2\,dt=t^3$. At $t=2\ \text{s}$, $v=12\ \text{m/s}$ and $x=8\ \text{m}$.

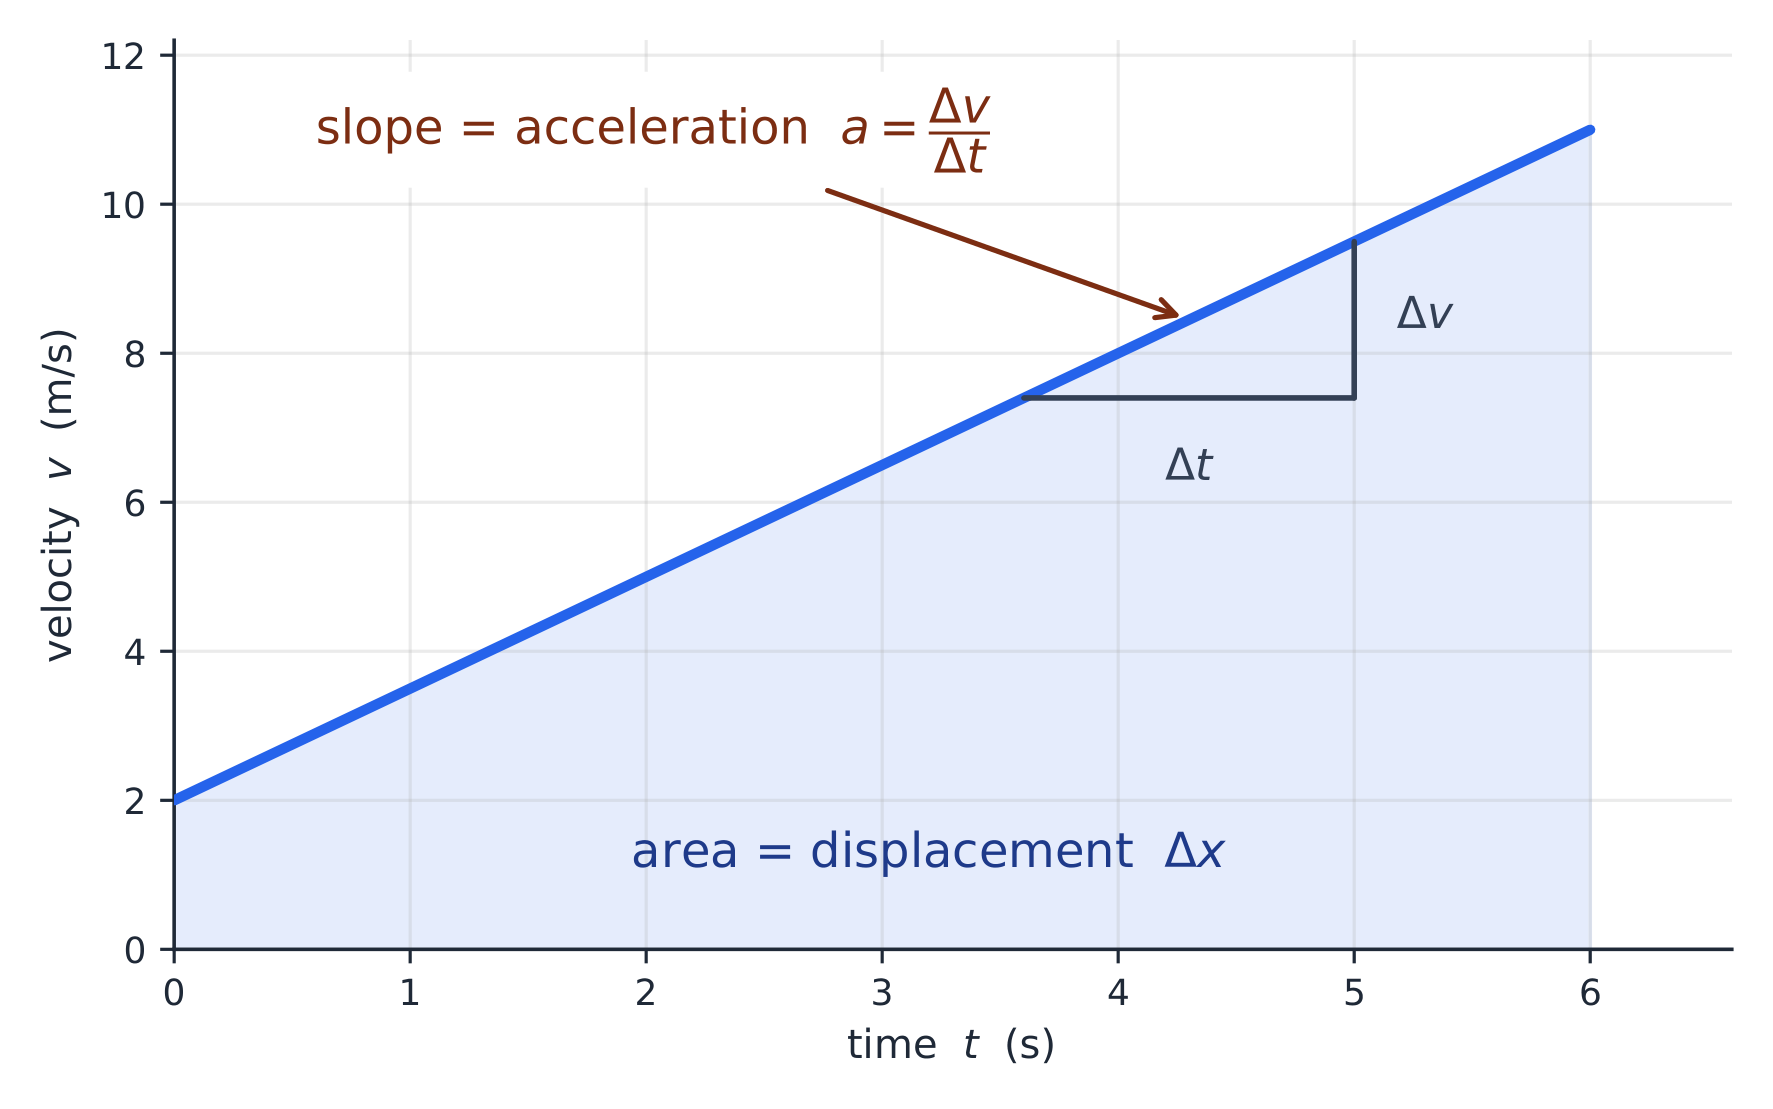
    On a velocity-time graph the gradient is the acceleration and the area is the displacement
    On a velocity-time graph the gradient is the acceleration and the area is the displacement
    A high-speed train: kinematics describes displacement, velocity and acceleration over time
    A high-speed train: kinematics describes displacement, velocity and acceleration over time
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    derivatives/dɪˈrɪvətɪvz/ производными
    average velocity/ˈævrɪdʒ vəˈlɒsɪti/ средняя скорость
    instantaneous velocity/ˌɪnstənˈteɪnɪəs vəˈlɒsɪti/ мгновенная скорость
    free fall/friː fɔːl/ свободное падение
    1.3

    Representing Motion

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 1.3.A: Describe the position, velocity, and acceleration of an object using representations of that object's motion.

    • 1.3.A.1 Motion can be represented by motion diagrams, figures, graphs, equations, and narrative descriptions.
    • 1.3.A.2 For constant acceleration, three kinematic equations can be used to describe instantaneous linear motion in one dimension:
      • Equation: $v_x = v_{x0} + a_x t$
      • Equation: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
      • Equation: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
      • Note: The equations above are written to indicate motion in the $x$-direction, but these equations can be used in any single dimension as appropriate.
    • 1.3.A.3 Near the surface of Earth, the vertical acceleration caused by the force of gravity is downward, constant, and has a measured value approximately equal to
      • Equation: $a_g = g \approx 10 \ \text{m/s}^2$.
    • 1.3.A.4 Graphs of position, velocity, and acceleration as functions of time can be used to find the relationships between those quantities.
      • 1.3.A.4.i An object's instantaneous velocity is the rate of change of the object's position, which is equal to the slope of a line tangent to a point on a graph of the object's position as a function of time.
        • Equation: $v_x = \dfrac{dx}{dt}$
      • 1.3.A.4.ii An object's instantaneous acceleration is the rate of change of the object's velocity, which is equal to the slope of a line tangent to a point on a graph of the object's velocity as a function of time.
        • Equation: $a_x = \dfrac{dv_x}{dt}$
      • 1.3.A.4.iii The displacement of an object during a time interval is equal to the area under the curve of a graph of the object's velocity as a function of time (i.e., the area bounded by the function and the horizontal axis for the appropriate interval).
        • Equation: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
      • 1.3.A.4.iv The change in velocity of an object during a time interval is equal to the area under the curve of a graph of the acceleration of the object as a function of time.
        • Equation: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$

    Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism expects that for all situations in which a numerical quantity is required for g, the value $g \approx 10 \ \text{m/s}^2$ will be used. However, students will not be penalized for correctly using the more precise commonly accepted values of $g = 9.81 \ \text{m/s}^2$ or $g = 9.8 \ \text{m/s}^2$.

    Русский

    Цель обучения 1.3.A: Описывать положение, скорость и ускорение объекта с помощью представлений движения этого объекта.

    • 1.3.A.1 Движение может быть представлено диаграммами движения, рисунками, графиками, уравнениями и повествовательными описаниями.
    • 1.3.A.2 Для постоянного ускорения три кинематических уравнения могут использоваться для описания мгновенного линейного движения в одном измерении:
      • Уравнение: $v_x = v_{x0} + a_x t$
      • Уравнение: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
      • Уравнение: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
      • Примечание: Приведенные выше уравнения записаны для описания движения в направлении $x$, однако эти уравнения могут применяться в любой одномерной системе координат при необходимости.
    • 1.3.A.3 Вблизи поверхности Земли вертикальное ускорение, вызванное силой тяжести, направлено вниз, является постоянным и имеет измеренное значение, приблизительно равное
      • Уравнение: $a_g = g \approx 10 \ \text{m/s}^2$.
    • 1.3.A.4 Графики положения, скорости и ускорения как функций времени могут использоваться для определения соотношений между этими величинами.
      • 1.3.A.4.i Мгновенная скорость объекта — это скорость изменения положения объекта, которая равна наклону касательной к точке на графике положения объекта как функции времени.
        • Уравнение: $v_x = \dfrac{dx}{dt}$
      • 1.3.A.4.ii Мгновенное ускорение объекта — это скорость изменения скорости объекта, которая равна наклону касательной к точке на графике скорости объекта как функции времени.
        • Уравнение: $a_x = \dfrac{dv_x}{dt}$
      • 1.3.A.4.iii Перемещение объекта за интервал времени равно площади под кривой графика скорости объекта как функции времени (т. е. площади, ограниченной функцией и горизонтальной осью для соответствующего интервала).
        • Уравнение: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
      • 1.3.A.4.iv Изменение скорости объекта за интервал времени равно площади под кривой графика ускорения объекта как функции времени.
        • Уравнение: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$

    Граничное условие: AP Physics C: Mechanics и AP Physics C: Electricity and Magnetism предполагают, что для всех ситуаций, в которых требуется численное значение g, будет использоваться значение $g \approx 10 \ \text{m/s}^2$. Однако учащимся не будет снижена оценка за правильное использование более точных общепринятых значений $g = 9.81 \ \text{m/s}^2$ или $g = 9.8 \ \text{m/s}^2$.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Move fluently between description, graph, table, and equation:

    A displacement-time graph: the slope at any instant is the velocity
    A displacement-time graph: the slope at any instant is the velocity
    • On a position–time graph, the slope ($dx/dt$) is velocity.
    • On a velocity–time graph, the slope is acceleration and the area ($\int v\,dt$) is displacement.
    • On an acceleration–time graph, the area ($\int a\,dt$) is the change in velocity.

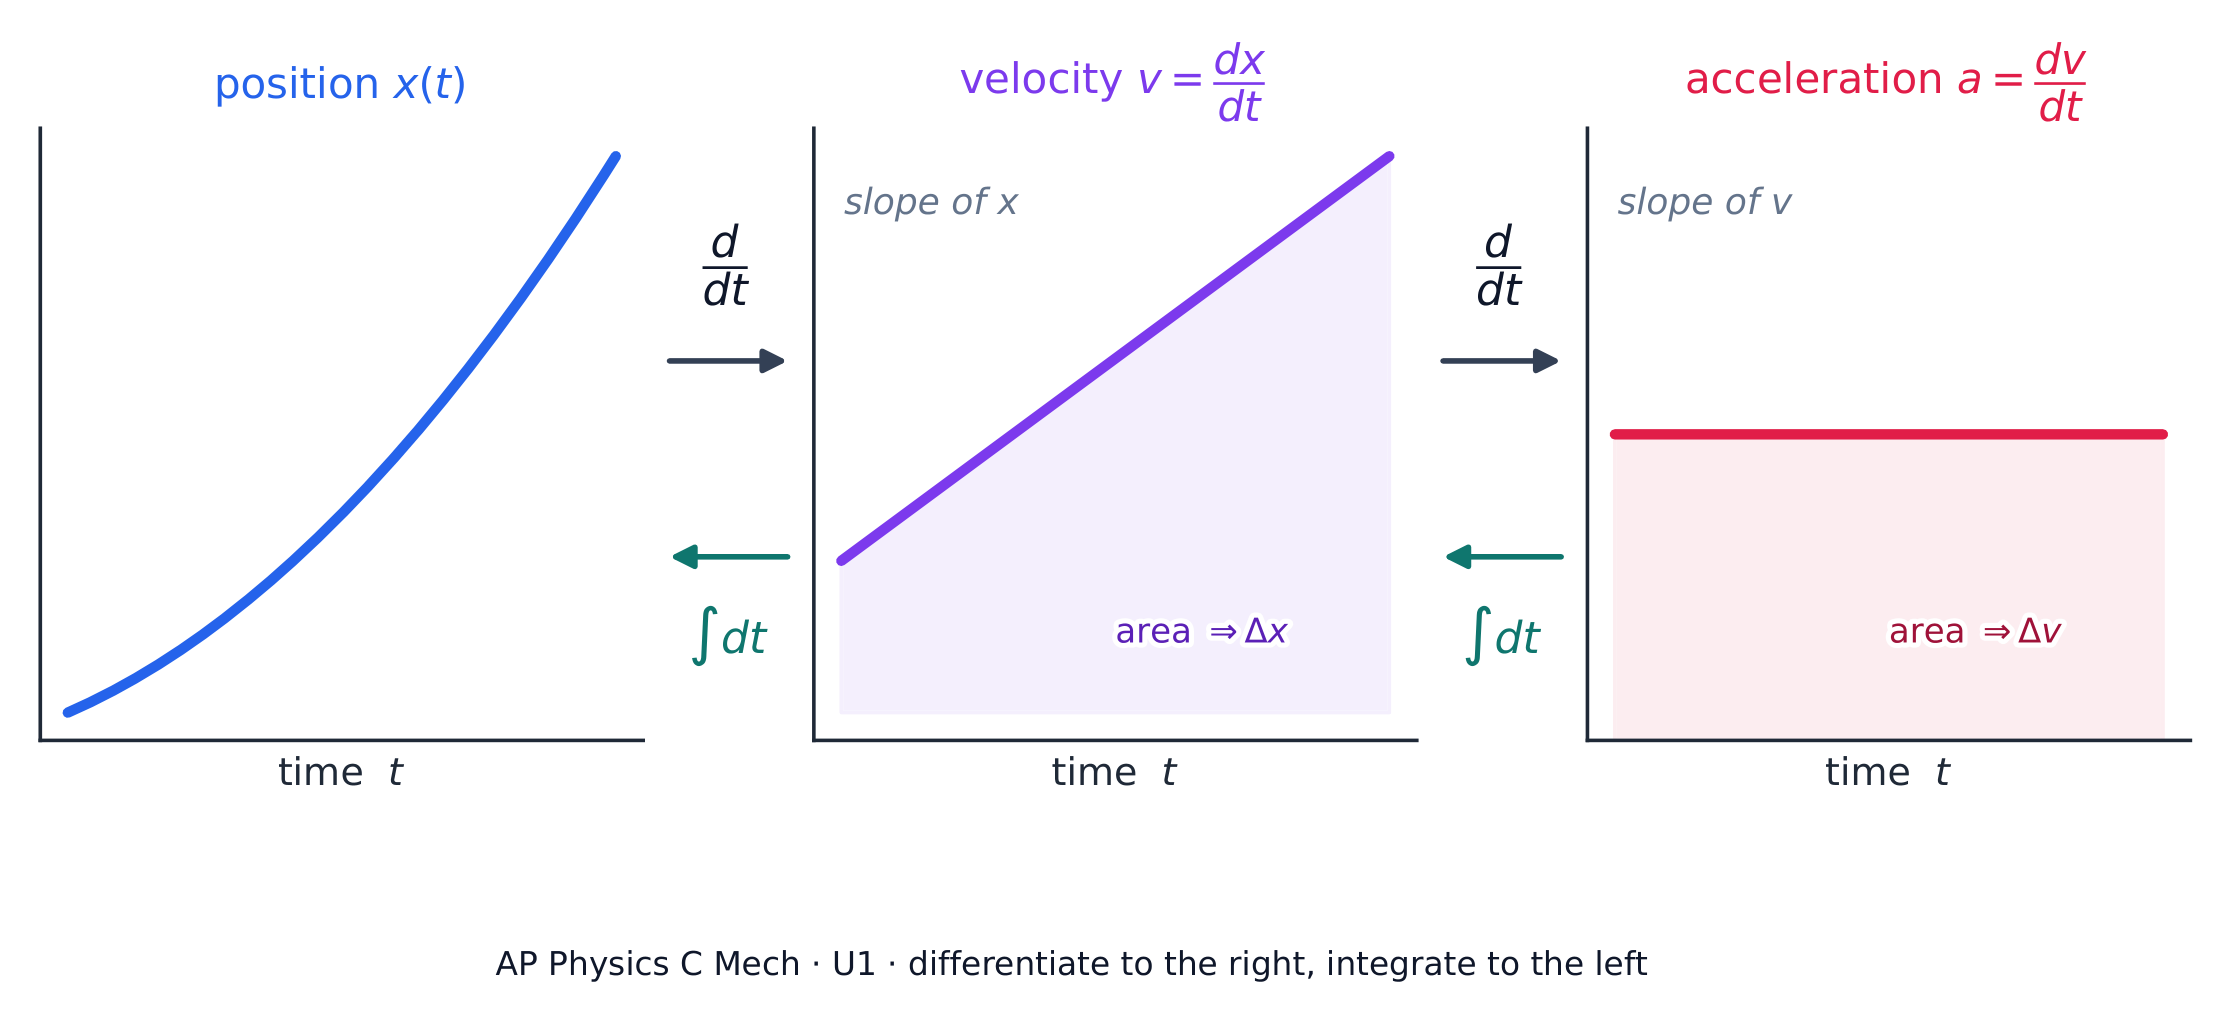
    Slopes are derivatives; areas are integrals – the two are inverse operations here.

    Position, velocity, and acceleration are linked by differentiation
    Position, velocity, and acceleration are linked by differentiation
    Explore · ⁨Исследовать⁩

    Explore the velocity–time graph · ⁨Исследовать график скорости от времени⁩

    Change the start velocity and acceleration. The slope of a $v$–$t$ line is the acceleration $a=\tfrac{dv}{dt}$, and the area underneath is the displacement $\Delta x=\int v\,dt$ — slope and area are the graphical faces of the derivative and the integral. · ⁨Изменяйте начальную скорость и ускорение. Наклон графика зависимости $v$–$t$ равен ускорению $a=\tfrac{dv}{dt}$, а площадь под графиком — перемещению $\Delta x=\int v\,dt$; наклон и площадь являются графическим отражением производной и интеграла.⁩

    1.4

    Reference Frames and Relative Motion

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 1.4.A: Describe the reference frame of a given observer.

    • 1.4.A.1 The choice of reference frame will determine the direction and magnitude of quantities measured by an observer in that reference frame.

    Learning Objective 1.4.B: Describe the motion of objects as measured by observers in different inertial reference frames.

    • 1.4.B.1 Measurements from a given reference frame may be converted to measurements from another reference frame.
    • 1.4.B.2 The observed velocity of an object results from the combination of the object's velocity and the velocity of the observer's reference frame.
      • 1.4.B.2.i Combining the motion of an object and the motion of an observer in a given reference frame involves the addition or subtraction of vectors.
      • 1.4.B.2.ii The acceleration of any object is the same as measured from all inertial reference frames.

    Boundary statement: Unless otherwise stated, the frame of reference of any problem may be assumed to be inertial.

    Русский

    Цель обучения 1.4.A: Описывать систему отсчета данного наблюдателя.

    • 1.4.A.1 Выбор системы отсчета определит направление и величину величин, измеряемых наблюдателем в этой системе отсчета.

    Цель обучения 1.4.B: Описывать движение объектов как оно измеряется наблюдателями в различных инерциальных системах отсчета.

    • 1.4.B.1 Измерения из заданной системы отсчета могут быть преобразованы в измерения из другой системы отсчета.
    • 1.4.B.2 Наблюдаемая скорость объекта является результатом сложения скорости самого объекта и скорости системы отсчета наблюдателя.
      • 1.4.B.2.i Комбинирование движения объекта и движения наблюдателя в данной системе отсчета включает сложение или вычитание векторов.
      • 1.4.B.2.ii Ускорение любого объекта одинаково при измерении из всех инерциальных систем отсчета.

    Граничное утверждение: Если не указано иное, систему отсчета любой задачи можно считать инерциальной.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    All motion is relative to a reference frame 参考系. Combine velocities by vector addition: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. This handles boats crossing rivers and passengers on moving vehicles – relative motion 相对运动 problems. Read the subscripts as a chain: "A relative to B" plus "B relative to C" gives "A relative to C".

    Worked example. A boat that moves at $4.0\ \text{m/s}$ in still water heads straight across a river flowing at $3.0\ \text{m/s}$. Relative to the ground the boat moves at $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$, angled downstream. If the river is $80\ \text{m}$ wide, the crossing still takes $t=\dfrac{80}{4.0}=20\ \text{s}$ – only the across-stream component crosses the river; the current just carries the boat $60\ \text{m}$ downstream.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    reference frame/ˈrefrəns freɪm/ система отсчета
    relative motion/ˈrelətɪv ˈməʊʃn/ относительное движение
    1.5

    Motion in Two or Three Dimensions

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 1.5.A: Describe the motion of an object moving in two or three dimensions.

    • 1.5.A.1 Motion in two or three dimensions can be analyzed using one-dimensional kinematic relationships if the motion is separated into components.
    • 1.5.A.2 Velocity and acceleration may be different in each dimension and may be nonuniform.
    • 1.5.A.3 Motion in one dimension may be changed without causing a change in a perpendicular dimension.
    • 1.5.A.4 Projectile motion is a special case of two-dimensional motion that has zero acceleration in one dimension and constant, nonzero acceleration in the second dimension.

    Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze the motion of an object in two dimensions. AP Physics C: Electricity and Magnetism expects students to also qualitatively describe the motion of a particle in three dimensions.

    Русский

    Цель обучения 1.5.A: Описать движение объекта, движущегося в двух или трех измерениях.

    • 1.5.A.1 Движение в двух или трех измерениях может быть проанализировано с использованием одномерных кинематических соотношений, если движение разбить на компоненты.
    • 1.5.A.2 Скорость и ускорение могут быть разными в каждом измерении и могут быть неоднородными (непостоянными).
    • 1.5.A.3 Изменение движения в одном измерении может происходить без изменения движения в перпендикулярном измерении.
    • 1.5.A.4 Движение тела, брошенного под углом к горизонту, является частным случаем двумерного движения, при котором ускорение равно нулю в одном измерении и постоянно, отличаясь от нуля, во втором измерении.

    Граничное условие: AP Physics C: Mechanics требует только количественного анализа движения объекта в двух измерениях. AP Physics C: Electricity and Magnetism предполагает, что студенты также должны качественно описывать движение частицы в трех измерениях.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    In two or three dimensions, position is a vector $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$, and velocity and acceleration are its successive derivatives – each component handled independently.

    Worked example. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (metres). Differentiating each component: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ and $\vec{a}=4\,\hat{i}-6t\,\hat{j}$. At $t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$, so the speed is $\sqrt{17}\approx4.1\ \text{m/s}$ – no new physics, just one derivative per component.

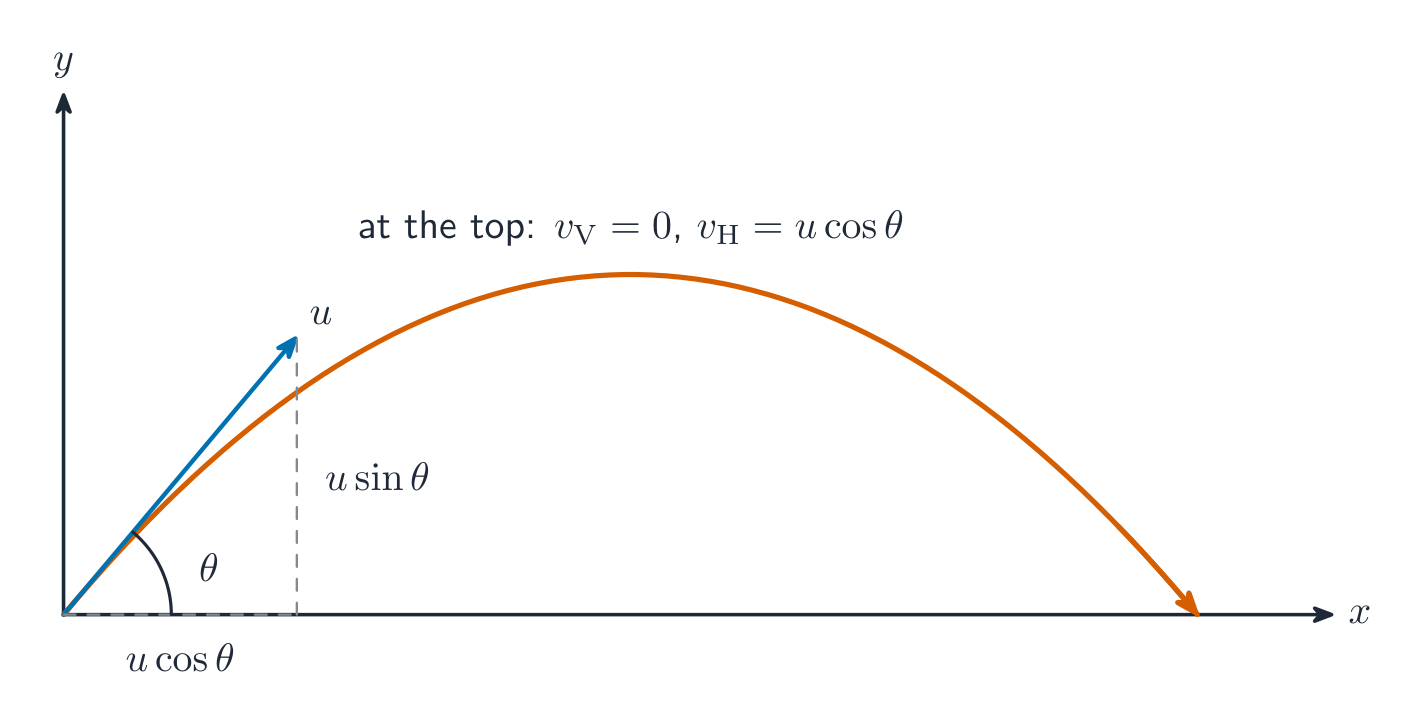
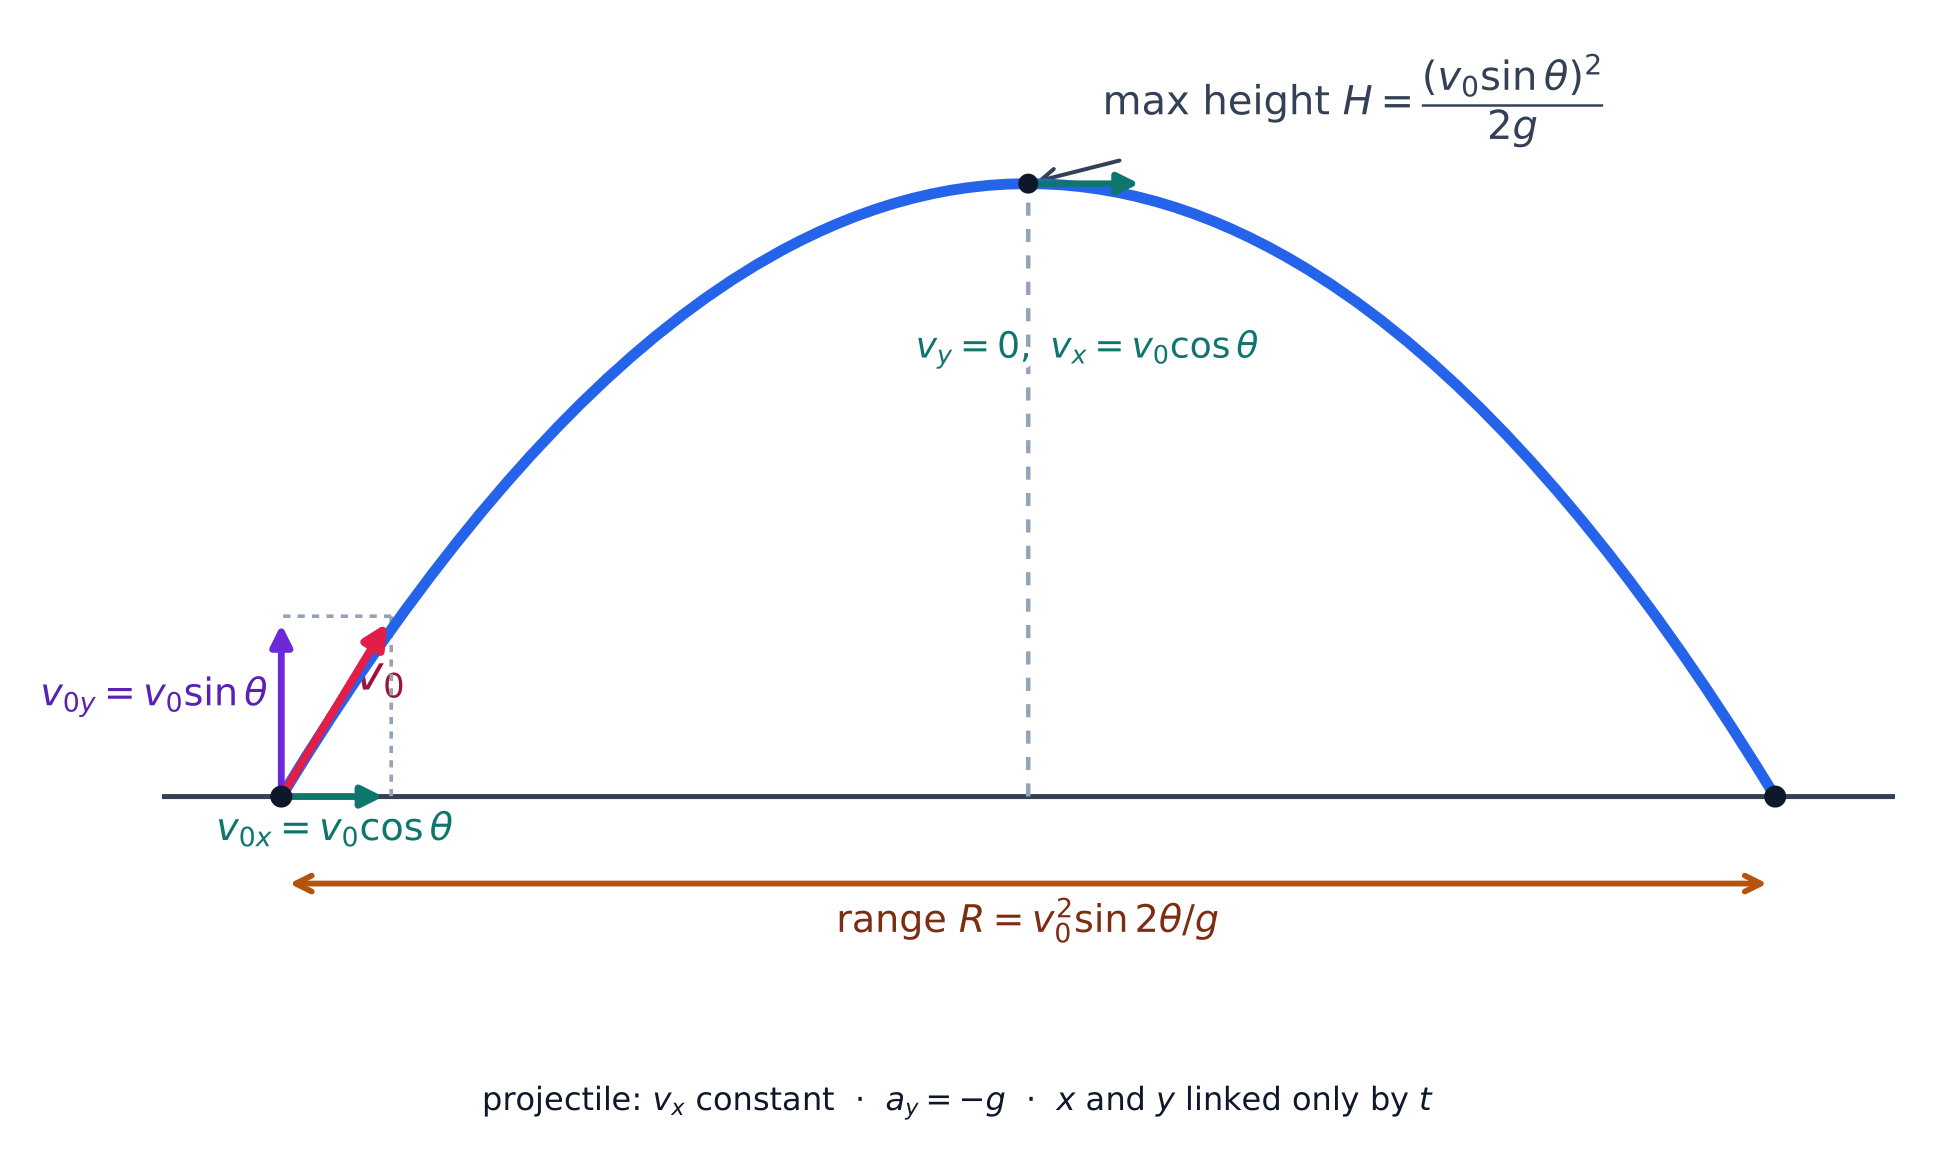
    A projectile launched at an angle: the horizontal and vertical motions are independent
    A projectile launched at an angle: the horizontal and vertical motions are independent

    For projectile motion 抛体运动, horizontal and vertical motions are independent, linked only by time $t$: horizontally $a_x=0$ (constant velocity), vertically $a_y=-g$. The path is a parabola. This component method extends to any two-dimensional motion where the accelerations along each axis are known.

    Worked example. A ball is launched at $20\ \text{m/s}$, $30^{\circ}$ above the horizontal ($g=9.8\ \text{m/s}^2$). The components are $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ and $v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. The vertical motion sets the time: total flight $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$, maximum height $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$, and range $=v_{0x}\times2.0=35\ \text{m}$.

    A projectile launched at an angle: velocity components, maximum height, and range
    A projectile launched at an angle: velocity components, maximum height, and range
    Explore · ⁨Исследовать⁩

    Explore projectile motion · ⁨Исследовать движение тела, брошенного под углом⁩

    Fire the projectile, then vary the angle and speed. The horizontal motion is steady while gravity acts only downward — together they trace a parabola. Find the angle that gives the greatest range (it peaks near $45^\circ$), and try the Moon. · ⁨Запустите снаряд, затем меняйте угол и скорость. Горизонтальное движение равномерное, гравитация действует только вниз — вместе они образуют параболу. Найдите угол, дающий максимальную дальность (она максимальна около $45^\circ$), и попробуйте на Луне.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    projectile motion/prəˈdʒektaɪl ˈməʊʃn/ бросок под углом к горизонту
    1.5

    Exam tips

    • Resolve every vector into components before adding — never add magnitudes at an angle directly.
    • On Physics C you are expected to use calculus: velocity is $\vec v=\tfrac{d\vec r}{dt}$ and acceleration $\vec a=\tfrac{d\vec v}{dt}$; reverse with integration.
    • Carry and check units and treat direction with signs (choose a positive axis and stick to it).
    • Use the dot product for work-type quantities and the cross product for torque and angular momentum.
    • Sketch the vectors — a diagram catches sign and direction errors the algebra hides.
  • 2

    Force and Translational Dynamics · ⁨Сила и трансlaçãoционная динамика⁩

    Watch lesson · ⁨Смотреть урок⁩
    2.1

    Systems and Center of Mass

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.1.A: Describe the properties and interactions of a system.

    • 2.1.A.1 System properties are determined by the interactions between objects within the system.
    • 2.1.A.2 If the properties or interactions of the constituent objects within a system are not important in modeling the behavior of the macroscopic system, the system can itself be treated as a single object.
    • 2.1.A.3 Systems may allow interactions between constituent parts of the system and the environment, which may result in the transfer of energy or mass.
    • 2.1.A.4 Individual objects within a chosen system may behave differently from each other as well as from the system as a whole.
    • 2.1.A.5 The internal structure of a system affects the analysis of that system.
    • 2.1.A.6 As variables external to a system are changed, the system's substructure may change.

    Learning Objective 2.1.B: Describe the location of a system's center of mass with respect to the system's constituent parts.

    • 2.1.B.1 For objects or systems with symmetrical mass distributions, the center of mass is located on lines of symmetry.
    • 2.1.B.2 The location of a system's center of mass along a given axis can be calculated using the equation
      • Equation: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
    • 2.1.B.3 For a nonuniform solid that can be considered as a collection of differential masses, $dm$, the solid's center of mass can be calculated using the equation
      • Equation: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
      • 2.1.B.3.i The linear mass density of a rod or other linear rigid body is the derivative of the rod's mass with respect to the position of the differential mass element on the rigid body.
        • Equation: $\lambda = \dfrac{d}{d\ell} m(\ell)$
      • 2.1.B.3.ii If a function of mass density is given for a solid, the total mass can be determined by integrating the mass density over the length (one dimension), area (two dimensions), or volume (three dimensions) of the solid. For example:
        • Equation: $M_{\text{total}} = \int \rho(r)\, dV$
    • 2.1.B.4 A system can be modeled as a singular object that is located at the system's center of mass.
    Русский

    Цель обучения 2.1.A: Описывать свойства и взаимодействия системы.

    • 2.1.A.1 Свойства системы определяются взаимодействиями между объектами внутри системы.
    • 2.1.A.2 Если свойства или взаимодействия составляющих объектов внутри системы не важны при моделировании поведения макроскопической системы, саму систему можно рассматривать как единый объект.
    • 2.1.A.3 Системы могут допускать взаимодействия между составляющими частью системы и окружающей средой, что может привести к передаче энергии или массы.
    • 2.1.A.4 Отдельные объекты внутри выбранной системы могут вести себя по-разному как друг относительно друга, так и по отношению к системе в целом.
    • 2.1.A.5 Внутренняя структура системы влияет на анализ этой системы.
    • 2.1.A.6 При изменении переменных, внешних по отношению к системе, ее субструктура может измениться.

    Цель обучения 2.1.B: Описывать положение центра масс системы относительно её составляющих частей.

    • 2.1.B.1 Для объектов или систем с симметричным распределением масс центр масс расположен на линиях симметрии.
    • 2.1.B.2 Положение центра масс системы вдоль данной оси может быть рассчитано с использованием уравнения ⟦number⟧
      • Уравнение: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
    • 2.1.B.3 Для неоднородного твердого тела, которое можно рассматривать как совокупность дифференциальных элементов массы, $dm$, центр масс твердого тела может быть рассчитан с использованием уравнения
      • Уравнение: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
      • 2.1.B.3.i Линейная плотность массы стержня или другого линейного жесткого тела — это производная массы стержня по положению элемента дифференциальной массы на жестком теле.
        • Уравнение: $\lambda = \dfrac{d}{d\ell} m(\ell)$
      • 2.1.B.3.ii Если задана функция плотности массы твердого тела, полную массу можно определить, проинтегрировав плотность массы по длине (одно измерение), площади (два измерения) или объему (три измерения) твердого тела. Например:
        • Уравнение: $M_{\text{total}} = \int \rho(r)\, dV$
    • 2.1.B.4 Систему можно моделировать как единичный объект, расположенный в центре масс системы.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    A system 系统 is the object or objects you analyze, treated as a point at its center of mass 质心. For a set of masses, $x_{\text{cm}}=\dfrac{\sum m_i x_i}{\sum m_i}$; for a continuous body, $x_{\text{cm}}=\dfrac{1}{M}\int x\,dm$. Only external forces move the center of mass.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    system/ˈsɪstəm/ система
    center of mass/ˈsentə ɒv mæs/ центр масс
    2.2

    Forces and Free-Body Diagrams

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.2.A: Describe a force as an interaction between two objects or systems

    • 2.2.A.1 Forces are vector quantities that describe the interactions between objects or systems.
      • 2.2.A.1.i A force exerted on an object or system is always due to the interaction of that object or system with another object or system.
      • 2.2.A.1.ii An object or system cannot exert a net force on itself.
    • 2.2.A.2 Contact forces describe the interaction of an object or system touching another object or system and are macroscopic effects of interatomic electric forces.

    Learning Objective 2.2.B: Describe the forces exerted on an object or system using a free-body diagram.

    • 2.2.B.1 Free-body diagrams are useful tools for visualizing forces being exerted on a single object or system and for determining the equations that represent a physical situation.
    • 2.2.B.2 The free-body diagram of an object or system shows each of the forces exerted on the object or system by the environment.
    • 2.2.B.3 Forces exerted on an object or system are represented as vectors originating from the representation of the center of mass, such as a dot. A system is treated as though all of its mass is located at the center of mass.
    • 2.2.B.4 A coordinate system with one axis parallel to the direction of acceleration of the object or system simplifies the translation from free-body diagram to algebraic representation. For example, in a free-body diagram of an object on an inclined plane, it is useful to set one axis parallel to the surface of the incline.

    Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism only expect students to depict the forces exerted on objects, not the force components on free-body diagrams. On the AP Physics exams, individual forces represented on a free-body diagram must be drawn as individual straight arrows, originating on the dot and pointing in the direction of the force. Individual forces that are in the same direction must be drawn side by side, not overlapping.

    Русский

    Цель обучения 2.2.A: Описать силу как взаимодействие между двумя объектами или системами

    • 2.2.A.1 Силы — это векторные величины, описывающие взаимодействия между объектами или системами.
      • 2.2.A.1.i Сила, действующая на объект или систему, всегда возникает в результате взаимодействия этого объекта или системы с другим объектом или системой.
      • 2.2.A.1.ii Объект или система не может exert (прикладывать) равнодействующую силу самому себе.
    • 2.2.A.2 Контактные силы описывают взаимодействие объекта или системы, соприкасающегося с другим объектом или системой, и являются макроскопическим проявлением межатомных электрических сил.

    Цель обучения 2.2.B: Описывать силы, действующие на объект или систему, используя диаграмму свободного тела.

    • 2.2.B.1 Диаграммы свободного тела являются полезными инструментами для визуализации сил, действующих на отдельный объект или систему, а также для определения уравнений, представляющих физическую ситуацию.
    • 2.2.B.2 Диаграмма свободного тела (FBD) объекта или системы показывает каждую силу, действующую на объект или систему со стороны окружающей среды.
    • 2.2.B.3 Силы, действующие на объект или систему, изображаются в виде векторов, исходящих из представления центра масс, например, точки. Система рассматривается так, будто вся её масса сосредоточена в центре масс.
    • 2.2.B.4 Координатная система, ось которой параллельна направлению ускорения объекта или системы, упрощает перевод диаграммы свободного тела в алгебраическое представление. Например, на диаграмме свободного тела объекта на наклонной плоскости полезно расположить одну ось параллельно поверхности наклона.

    Уточнение: AP Physics C: Механика и AP Physics C: Электричество и магнетизм требуют от студентов лишь изображать силы, действующие на объекты, а не проекции сил на диаграммах свободного тела. На экзаменах AP по физике отдельные силы, представленные на диаграмме свободного тела, должны быть нарисованы как отдельные прямые стрелки, исходящие из точки и указывающие в направлении действия силы. Отдельные силы, направленные в одну сторону, должны быть нарисованы рядом друг с другом, без наложения.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

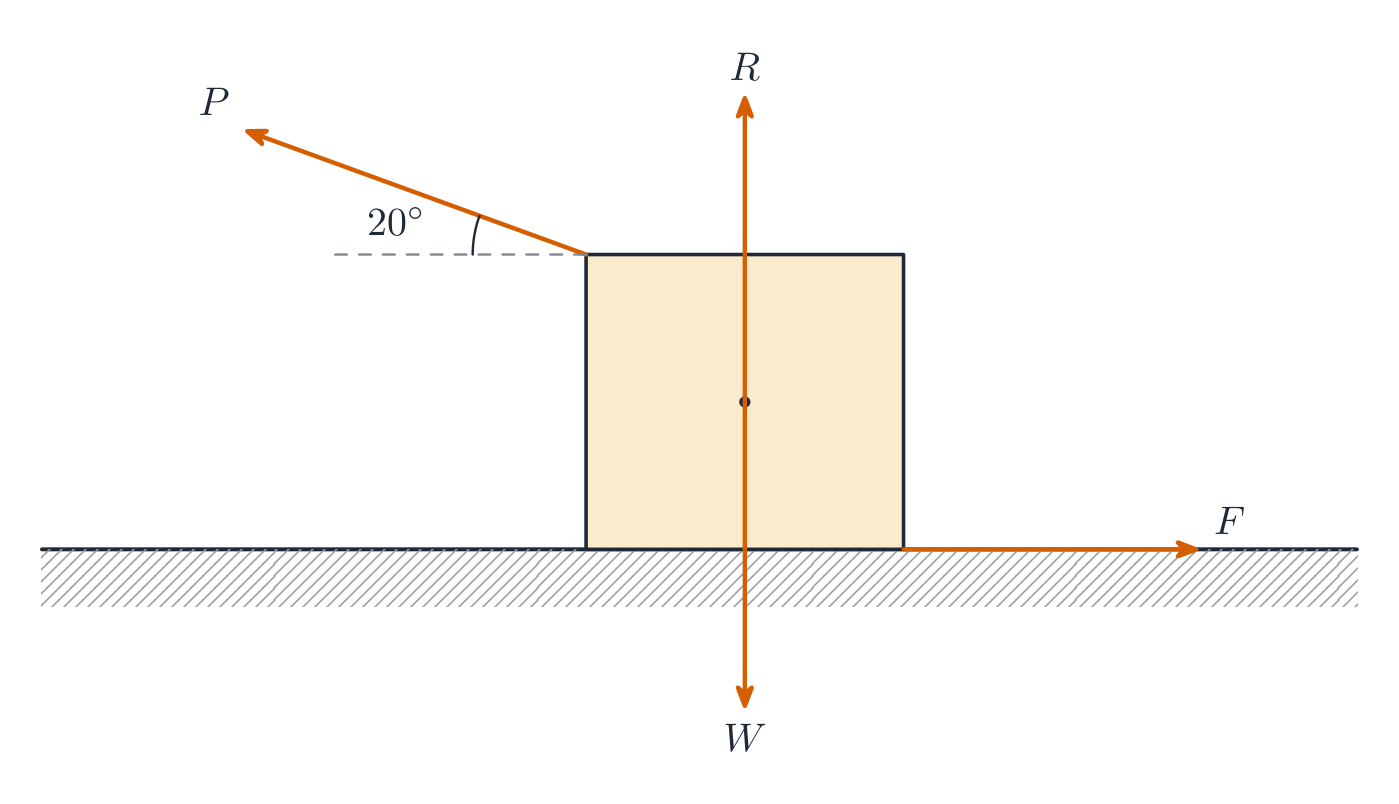
    A force 力 is a push or pull (a vector, in newtons). A free-body diagram 受力图 draws one object with an arrow for every force on it – weight, normal, tension, friction, applied, drag. Draw it first; it sets up every dynamics equation.

    A free-body diagram shows every force acting on one object
    A free-body diagram shows every force acting on one object
    Explore · ⁨Исследовать⁩

    Balance the forces on a free-body diagram · ⁨Сбалансировать силы на диаграмме свободного тела⁩

    A free-body diagram shows every force on one object as an arrow. The object accelerates only if the forces don't cancel — the net force sets $a=F/m$. · ⁨Диаграмма свободного тела показывает все силы, действующие на один объект, стрелками. Объект ускоряется только если силы не компенсируют друг друга — равнодействующая сила определяет $a=F/m$.⁩
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    force/fɔːs/ сила
    free-body diagram/friː ˈbɒdi ˈdaɪəɡræm/ диаграмма свободного тела
    2.3

    Newton's Third Law

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.3.A: Describe the interaction of two objects or systems using Newton's third law and a representation of paired forces exerted on each object or system.

    • 2.3.A.1 Newton's third law describes the interaction of two objects or systems in terms of the paired forces that each exerts on the other.
      • Equation: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
    • 2.3.A.2 Interactions between objects within a system (internal forces) do not influence the motion of a system's center of mass.
    • 2.3.A.3 Tension is the macroscopic net result of forces that infinitesimal segments of a string, cable, chain, or similar system exert on each other in response to an external force.
      • 2.3.A.3.i An ideal string has negligible mass and does not stretch when under tension.
      • 2.3.A.3.ii The tension in an ideal string is the same at all points within the string.
      • 2.3.A.3.iii In a string with nonnegligible mass, tension may not be the same at all points within the string.
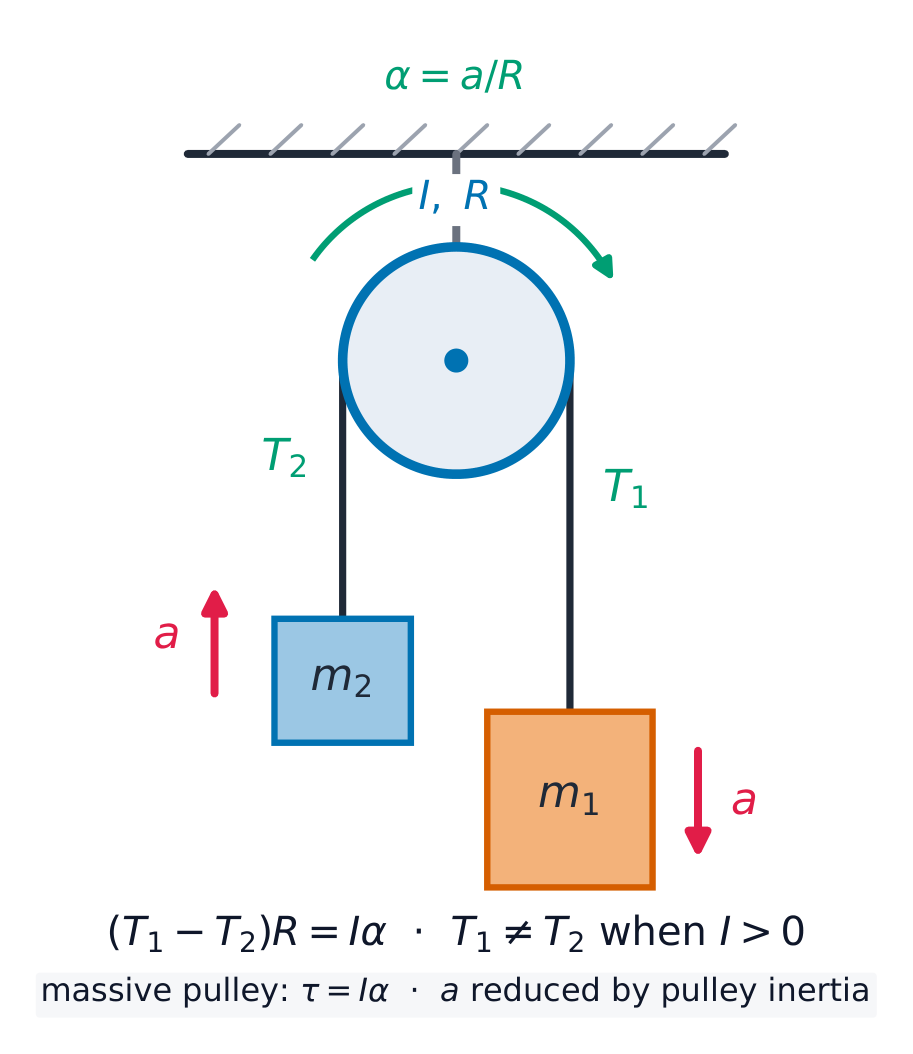
      • 2.3.A.3.iv An ideal pulley is a pulley that has negligible mass and rotates about an axle through its center of mass with negligible friction.
    Русский

    Цель обучения 2.3.A: Описать взаимодействие двух объектов или систем с использованием третьего закона Ньютона и представления парных сил, действующих на каждый объект или систему.

    • 2.3.A.1 Третий закон Ньютона описывает взаимодействие двух объектов или систем через парные силы, которые каждое из них оказывает на другое.
      • Уравнение: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
    • 2.3.A.2 Взаимодействия между объектами внутри системы (внутренние силы) не влияют на движение центра масс системы.
    • 2.3.A.3 Натяжение является макроскопическим результатом сил, которые бесконечно малые участки нити, троса, цепи или аналогичной системы оказывают друг на друга в ответ на внешнюю силу.
      • 2.3.A.3.i Идеальная нить имеет пренебрежимо малую массу и не растягивается под действием натяжения.
      • 2.3.A.3.ii Натяжение в идеальной нити одинаково во всех её точках.
      • 2.3.A.3.iii В нити с непренебрежимо малой массой натяжение может быть различным во всех её точках.
      • 2.3.A.3.iv Идеальный блок — это блок, имеющий пренебрежимо малую массу и вращающийся вокруг оси, проходящей через его центр масс, при пренебрежимо малом трении.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

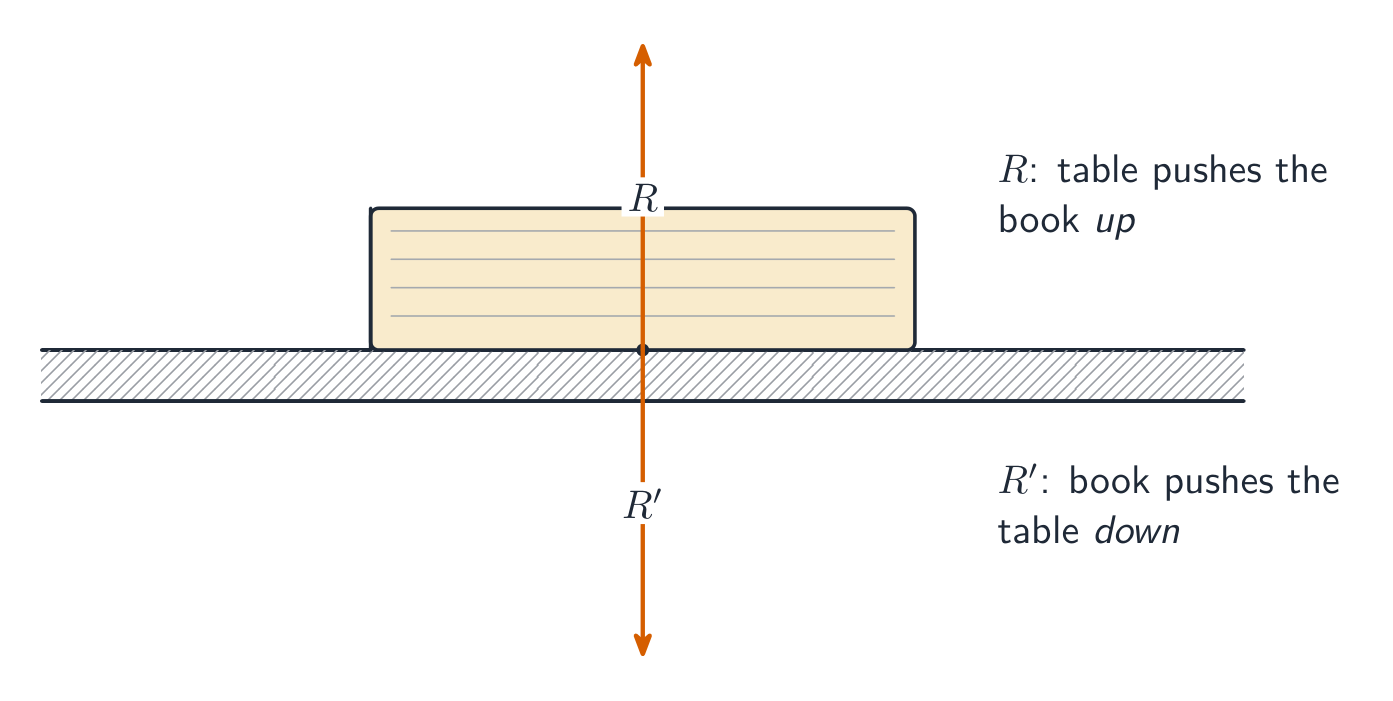
    Newton's third law 牛顿第三定律: A pushes B, B pushes back equally and oppositely. The pair acts on different objects, so it never cancels within one free-body diagram.

    A Newton's third-law pair: equal and opposite forces on two different objects
    A Newton's third-law pair: equal and opposite forces on two different objects
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Newton's third law/ˈnjuːtnz θɜːd lɔː/ третьего закона Ньютона
    2.4

    Newton's First Law

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.4.A: Describe the conditions under which a system's velocity remains constant.

    • 2.4.A.1 The net force on a system is the vector sum of all forces exerted on the system.
    • 2.4.A.2 Translational equilibrium is the configuration of forces such that the net force exerted on a system is zero.
      • Derived equation: $\sum \vec{F}_i = 0$
    • 2.4.A.3 Newton's first law states that if the net force exerted on a system is zero, the velocity of that system will remain constant.
    • 2.4.A.4 Forces may be balanced in one dimension but unbalanced in another. The system's velocity will change only in the direction of the unbalanced force.
    • 2.4.A.5 An inertial reference frame is one from which an observer would verify Newton's first law of motion.
    Русский

    Цель обучения 2.4.A: Описать условия, при которых скорость системы остается постоянной.

    • 2.4.A.1 Равнодействующая сила системы равна векторной сумме всех сил, действующих на систему.
    • 2.4.A.2 Трансляционное равновесие — это конфигурация сил, при которой равнодействующая сила, действующая на систему, равна нулю.
      • Выведенное уравнение: $\sum \vec{F}_i = 0$
    • 2.4.A.3 Первый закон Ньютона гласит, что если равнодействующая сила, действующая на систему, равна нулю, скорость этой системы останется постоянной.
    • 2.4.A.4 Силы могут быть скомпенсированы в одном измерении, но нескомпенсированы в другом. Скорость системы изменится только в направлении нескомпенсированной силы.
    • 2.4.A.5 Инерциальная система отсчета — это такая система, из которой наблюдатель может подтвердить первый закон движения Ньютона.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Newton's first law (inertia 惯性): with zero net force 合力, velocity stays constant – the object is in translational equilibrium 平动平衡.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    inertia/ɪˈnɜːʃə/ инерция
    net force/net fɔːs/ равнодействующая сила
    translational equilibrium/trænˈsleɪʃənl ˌiːkwɪˈlɪbrɪəm/ трансляционное равновесие
    2.5

    Newton's Second Law

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.5.A: Describe the conditions under which a system's velocity changes.

    • 2.5.A.1 Unbalanced forces are a configuration of forces such that the net force exerted on a system is not equal to zero.
    • 2.5.A.2 Newton's second law of motion states that the acceleration of a system's center of mass has a magnitude proportional to the magnitude of the net force exerted on the system and is in the same direction as that net force.
      • Equation: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
    • 2.5.A.3 The velocity of a system's center of mass will only change if a nonzero net external force is exerted on that system.
    Русский

    Цель обучения 2.5.A: Описать условия, при которых скорость системы изменяется.

    • 2.5.A.1 Нескомпенсированные силы — это конфигурация сил, при которой равнодействующая сила, действующая на систему, не равна нулю.
    • 2.5.A.2 Второй закон Ньютона гласит, что ускорение центра масс системы по модулю пропорционально модулю равнодействующей силы, действующей на систему, и направлено в ту же сторону, что и эта равнодействующая сила.
      • Уравнение: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
    • 2.5.A.3 Скорость центра масс системы изменится только тогда, когда на эту систему действует ненулевая внешняя равнодействующая сила.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    The general form uses momentum:

    $$\sum\vec{F}=\frac{d\vec{p}}{dt}=m\vec{a}\ \ (\text{for constant mass}).$$
    Apply it one axis at a time. When forces depend on velocity or position, this becomes a differential equation 微分方程 to solve.

    Worked example. A $2.0\ \text{kg}$ block slides down a frictionless incline 斜面 at $30^{\circ}$. Only the along-ramp component of gravity drives it, so $a=g\sin30^{\circ}=9.8(0.5)=4.9\ \text{m/s}^2$, independent of the mass.

    Worked example (two bodies). A $6.0\ \text{kg}$ cart on a frictionless table is pulled by a string over a light pulley to a hanging $2.0\ \text{kg}$ mass. Treat the pair as one system: only the hanging weight drives it, so $a=\dfrac{2.0(9.8)}{8.0}=2.45\ \text{m/s}^2$. Then isolate the cart alone to find the string tension 张力: $T=6.0(2.45)\approx15\ \text{N}$. System first for $a$, single body for internal forces – that two-step is the standard pattern.

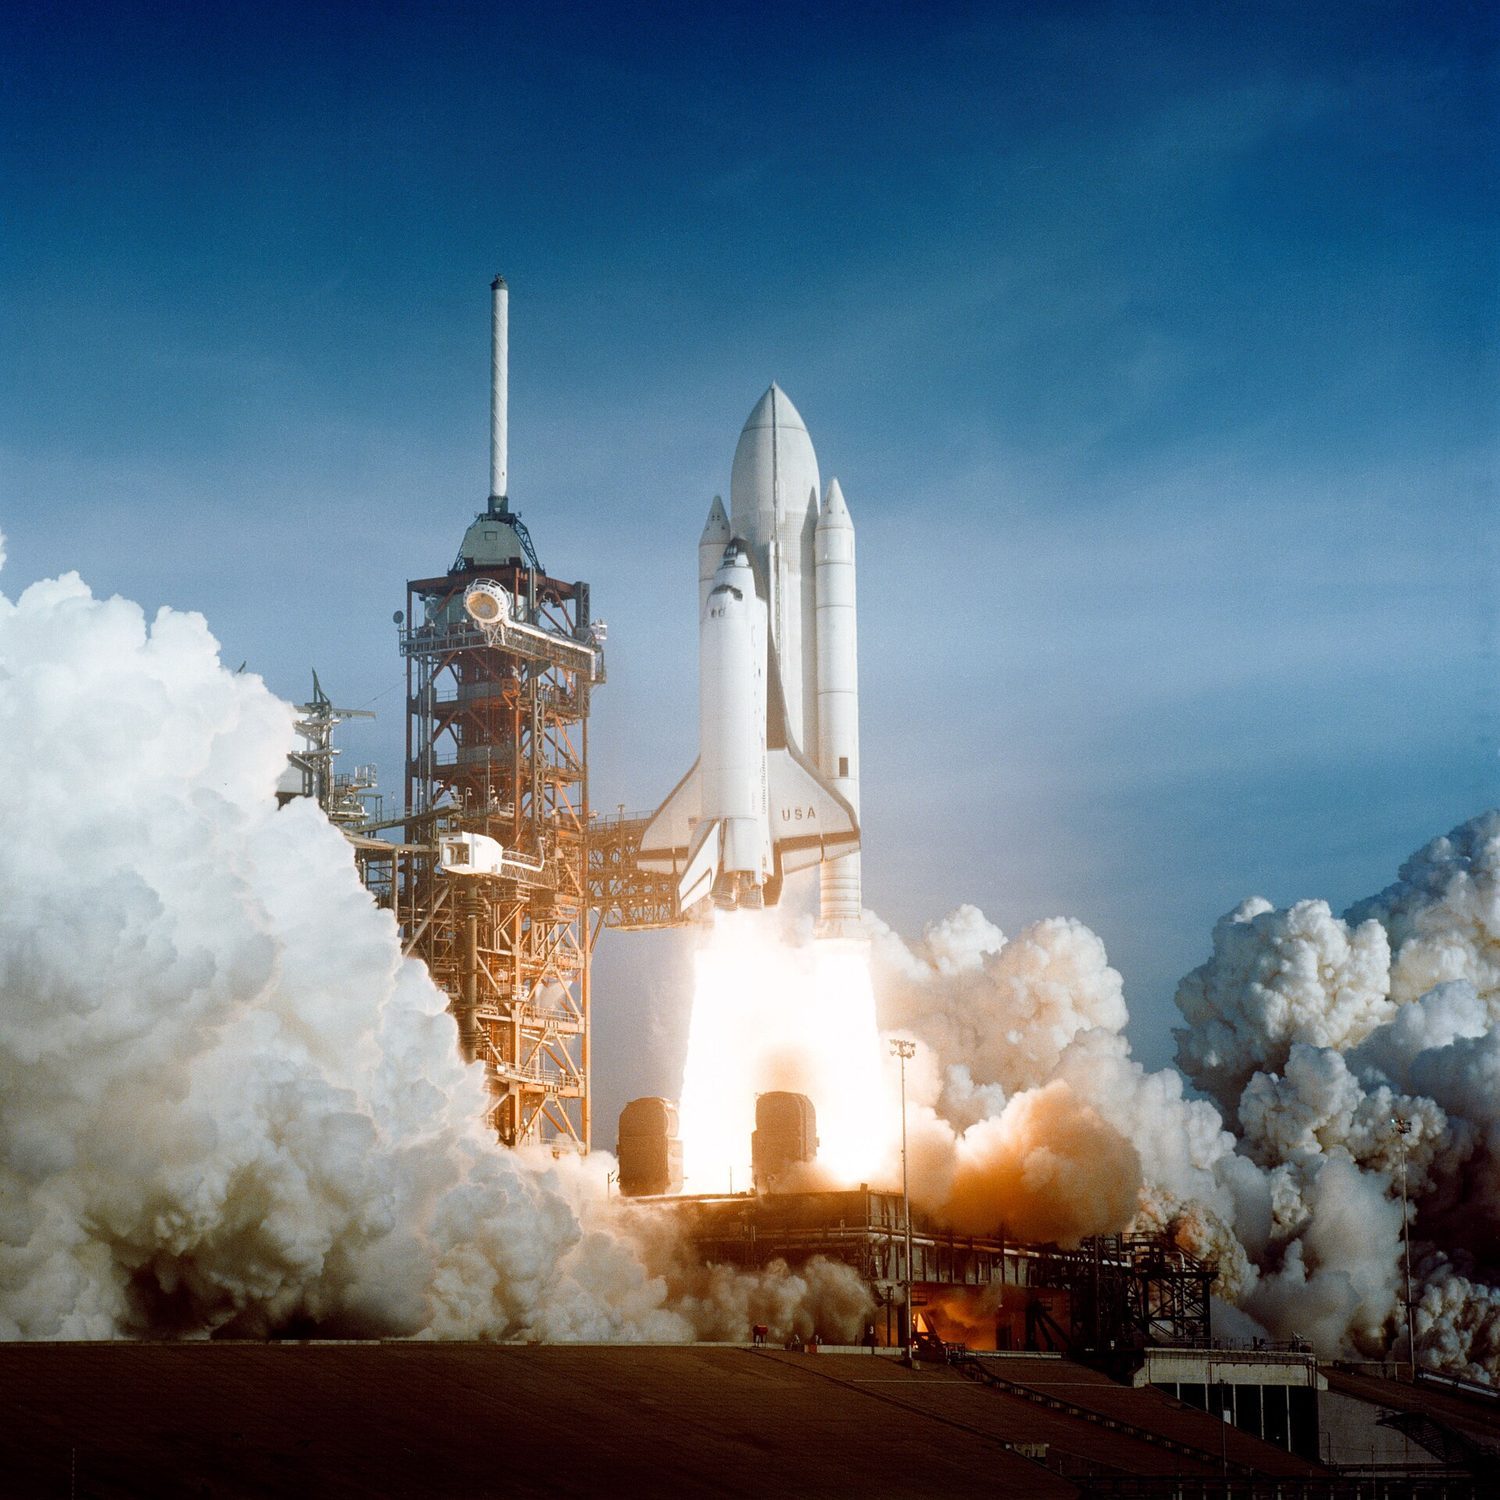
    A rocket launch: net force changes momentum — F_net = ma for translational dynamics
    A rocket launch: net force changes momentum — F_net = ma for translational dynamics
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ дифференциальное уравнение
    incline/ɪnˈklaɪn/ наклонная плоскость
    tension/ˈtenʃn/ натяжение
    2.6

    Gravitational Force

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.6.A: Describe the gravitational interaction between two objects or systems with mass.

    • 2.6.A.1 Newton's law of universal gravitation describes the gravitational force between two objects or systems as directly proportional to each of their masses and inversely proportional to the square of the distance between the systems' centers of mass.
      • Equation: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
      • 2.6.A.1.i The gravitational force is attractive.
      • 2.6.A.1.ii The gravitational force is always exerted along the line connecting the center of mass of the two interacting systems.
      • 2.6.A.1.iii The gravitational force on a system can be considered to be exerted on the system's center of mass.
    • 2.6.A.2 A field models the effects of a noncontact force exerted on an object at various positions in space.
      • 2.6.A.2.i The magnitude of the gravitational field created by a system of mass $M$ at a point in space is equal to the ratio of the gravitational force exerted by the system on a test object of mass $m$ to the mass of the test object.
        • Derived equation: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
      • 2.6.A.2.ii If the gravitational force is the only force exerted on an object, the observed acceleration of the object (in $\text{m/s}^2$) is numerically equal to the magnitude of the gravitational field strength (in $\text{N/kg}$) at that location.
    • 2.6.A.3 The gravitational force exerted by an astronomical body on a relatively small nearby object is called weight.
      • Derived equation: $\text{Weight} = F_g = mg$

    Learning Objective 2.6.B: Describe situations in which the gravitational force can be considered constant.

    • 2.6.B.1 If the gravitational force between two systems' centers of mass has a negligible change as the relative position of the two systems changes, the gravitational force can be considered constant at all points between the initial and final positions of the systems.
    • 2.6.B.2 Near the surface of Earth, the strength of the gravitational field is
      • Equation: $g \approx 10\ \text{N/kg}$

    Learning Objective 2.6.C: Describe the conditions under which the magnitude of a system's apparent weight is different from the magnitude of the gravitational force exerted on that system.

    • 2.6.C.1 The magnitude of the apparent weight of a system is the magnitude of the normal force exerted on the system.
    • 2.6.C.2 If the system is accelerating, the apparent weight of the system is not equal to the magnitude of the gravitational force exerted on the system.
    • 2.6.C.3 A system appears weightless when there are no forces exerted on the system or when the force of gravity is the only force exerted on the system.
    • 2.6.C.4 The equivalence principle states that an observer in a noninertial reference frame is unable to distinguish between an object's apparent weight and the gravitational force exerted on the object by a gravitational field.

    Learning Objective 2.6.D: Describe inertial and gravitational mass.

    • 2.6.D.1 Objects have inertial mass, or inertia, a property that determines how much an object's motion resists changes when interacting with another object.
    • 2.6.D.2 Gravitational mass is related to the force of attraction between two systems with mass.
    • 2.6.D.3 Inertial mass and gravitational mass have been experimentally verified to be equivalent.

    Learning Objective 2.6.E: Describe the gravitational force exerted on an object by a uniform spherical distribution of mass.

    • 2.6.E.1 The net gravitational force exerted on an object by a uniform spherical distribution of mass is the sum of the individual forces from small differential masses that comprise the distribution.
    • 2.6.E.2 Newton's shell theorem describes the net gravitational force exerted on an object by a uniform spherical shell of mass.
      • 2.6.E.2.i The net gravitational force exerted on an object inside a thin spherical shell is zero.
      • 2.6.E.2.ii The net gravitational force exerted on an object outside a thin spherical shell can be determined by treating the shell as a single massive object located at the center of the shell.
      • 2.6.E.2.iii An object inside a sphere of uniform density experiences a net gravitational force from only a partial mass of the sphere.
      • 2.6.E.2.iv The partial mass of a sphere that contributes to the net gravitational force exerted on an object within that sphere is the portion of the sphere's mass located a distance less than or equal to the object's distance from the center of the sphere and can be calculated using the density of the sphere.
        • Derived equation: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
    • 2.6.E.3 The gravitational force exerted on an object within a uniform sphere can be shown to be proportional to the object's distance from the sphere's center.
      • Derived equation: $F_{g,\text{partial}} = -k r_{\text{partial}}$

    Boundary statement: AP Physics C: Mechanics does not expect students to mathematically prove or derive Newton's shell theorem.

    Русский

    Цель обучения 2.6.A: Описать гравитационное взаимодействие между двумя объектами или системами с массой.

    • 2.6.A.1 Закон всемирного тяготения Ньютона описывает гравитационную силу между двумя объектами или системами как прямо пропорциональную каждой из их масс и обратно пропорциональную квадрату расстояния между центрами масс систем.
      • Уравнение: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
      • 2.6.A.1.i Гравитационная сила является притягивающей.
      • 2.6.A.1.ii Гравитационная сила всегда действует вдоль линии, соединяющей центры масс двух взаимодействующих систем.
      • 2.6.A.1.iii Гравитационную силу, действующую на систему, можно считать приложенной к центру масс этой системы.
    • 2.6.A.2 Поле моделирует эффекты бесконтактной силы, действующей на объект в различных точках пространства.
      • 2.6.A.2.i Модуль гравитационного поля, создаваемого системой массы $M$ в точке пространства, равен отношению гравитационной силы, оказываемой системой на пробный объект массы $m$, к массе пробного объекта.
        • Выведенное уравнение: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
      • 2.6.A.2.ii Если гравитационная сила является единственной силой, действующей на объект, наблюдаемое ускорение объекта (в $\text{m/s}^2$) численно равно модулю напряженности гравитационного поля (в $\text{N/kg}$) в данном месте.
    • 2.6.A.3 Гравитационная сила, оказываемая небесным телом на относительно небольшой близлежащий объект, называется весом.
      • Выведенное уравнение: $\text{Weight} = F_g = mg$

    Цель обучения 2.6.B: Описать ситуации, в которых гравитационную силу можно считать постоянной.

    • 2.6.B.1 Если изменение гравитационной силы между центрами масс двух систем пренебрежимо мало при изменении их относительного положения, гравитационную силу можно считать постоянной во всех точках между начальным и конечным положениями систем.
    • 2.6.B.2 Вблизи поверхности Земли напряженность гравитационного поля равна
      • Уравнение: $g \approx 10\ \text{N/kg}$

    Цель обучения 2.6.C: Описать условия, при которых модуль кажущегося веса системы отличается от модуля гравитационной силы, действующей на эту систему.

    • 2.6.C.1 Модуль кажущегося веса системы равен модулю силы нормальной реакции опоры, действующей на систему.
    • 2.6.C.2 Если система движется с ускорением, её кажущийся вес не равен модулю гравитационной силы, действующей на систему.
    • 2.6.C.3 Система кажется невесомой, когда на неё не действуют силы или когда единственной силой, действующей на систему, является сила тяжести.
    • 2.6.C.4 Принцип эквивалентности гласит, что наблюдатель в неинерциальной системе отсчета не может отличить видимый вес объекта от гравитационной силы, действующей на него со стороны гравитационного поля.

    Цель обучения 2.6.D: Описать инертную и гравитационную массу.

    • 2.6.D.1 Объекты обладают инертной массой, или инерцией, — свойством, определяющим сопротивление изменениям движения при взаимодействии с другими объектами.
    • 2.6.D.2 Гравитационная масса связана с силой притяжения между двумя системами, обладающими массой.
    • 2.6.D.3 Экспериментально подтверждено, что инертная и гравитационная массы эквивалентны.

    Цель обучения 2.6.E: Описать гравитационную силу, действующую на объект со стороны равномерного сферического распределения массы.

    • 2.6.E.1 Равнодействующая гравитационная сила, действующая на объект со стороны равномерного сферического распределения массы, представляет собой сумму отдельных сил от малых дифференциальных масс, составляющих это распределение.
    • 2.6.E.2 Теорема о оболочках Ньютона описывает равнодействующую гравитационную силу, действующую на объект со стороны равномерной сферической оболочки массы.
      • 2.6.E.2.i Равнодействующая гравитационная сила, действующая на объект внутри тонкой сферической оболочки, равна нулю.
      • 2.6.E.2.ii Равнодействующую гравитационную силу, действующую на объект вне тонкой сферической оболочки, можно определить, рассматривая оболочку как единый массивный объект, расположенный в центре оболочки.
      • 2.6.E.2.iii Объект внутри сферы с равномерной плотностью испытывает равнодействующую гравитационную силу только от частичной массы сферы.
      • 2.6.E.2.iv Частичная масса сферы, которая вносит вклад в равнодействующую гравитационную силу, действующую на объект внутри этой сферы, представляет собой часть массы сферы, расположенную на расстоянии меньше или равном расстоянию объекта до центра сферы, и может быть рассчитана с использованием плотности сферы.
        • Выведенное уравнение: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
    • 2.6.E.3 Можно показать, что гравитационная сила, действующая на объект внутри равномерной сферы, пропорциональна расстоянию объекта до центра сферы.
      • Выведенное уравнение: $F_{g,\text{partial}} = -k r_{\text{partial}}$

    Уточнение: AP Physics C: Механика не требует от студентов математически доказывать или выводить теорему о оболочках Ньютона.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

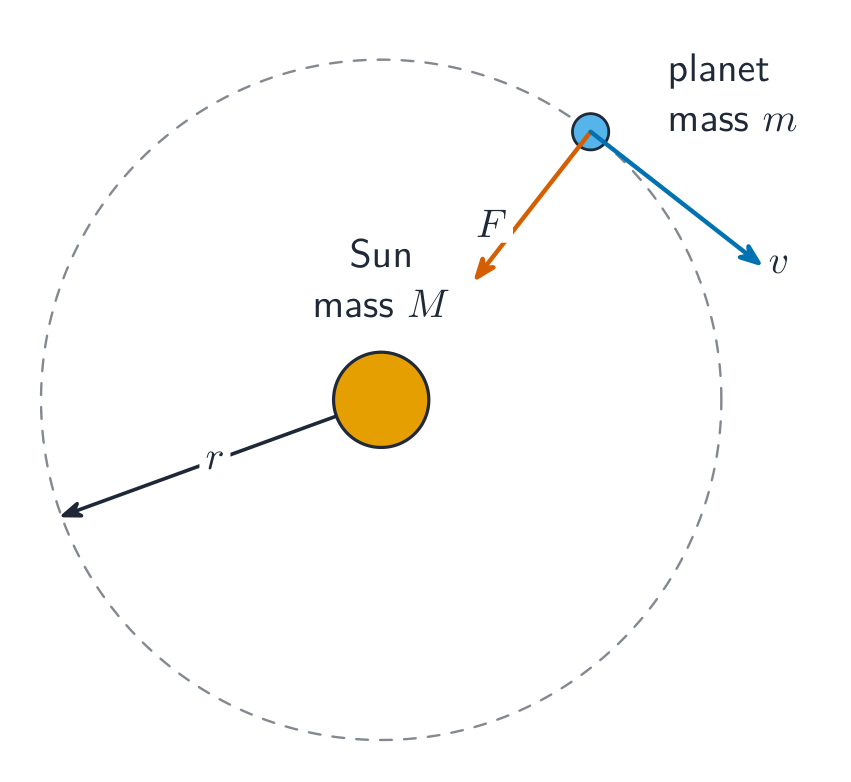
    Orbital motion (Kepler's 2nd law)

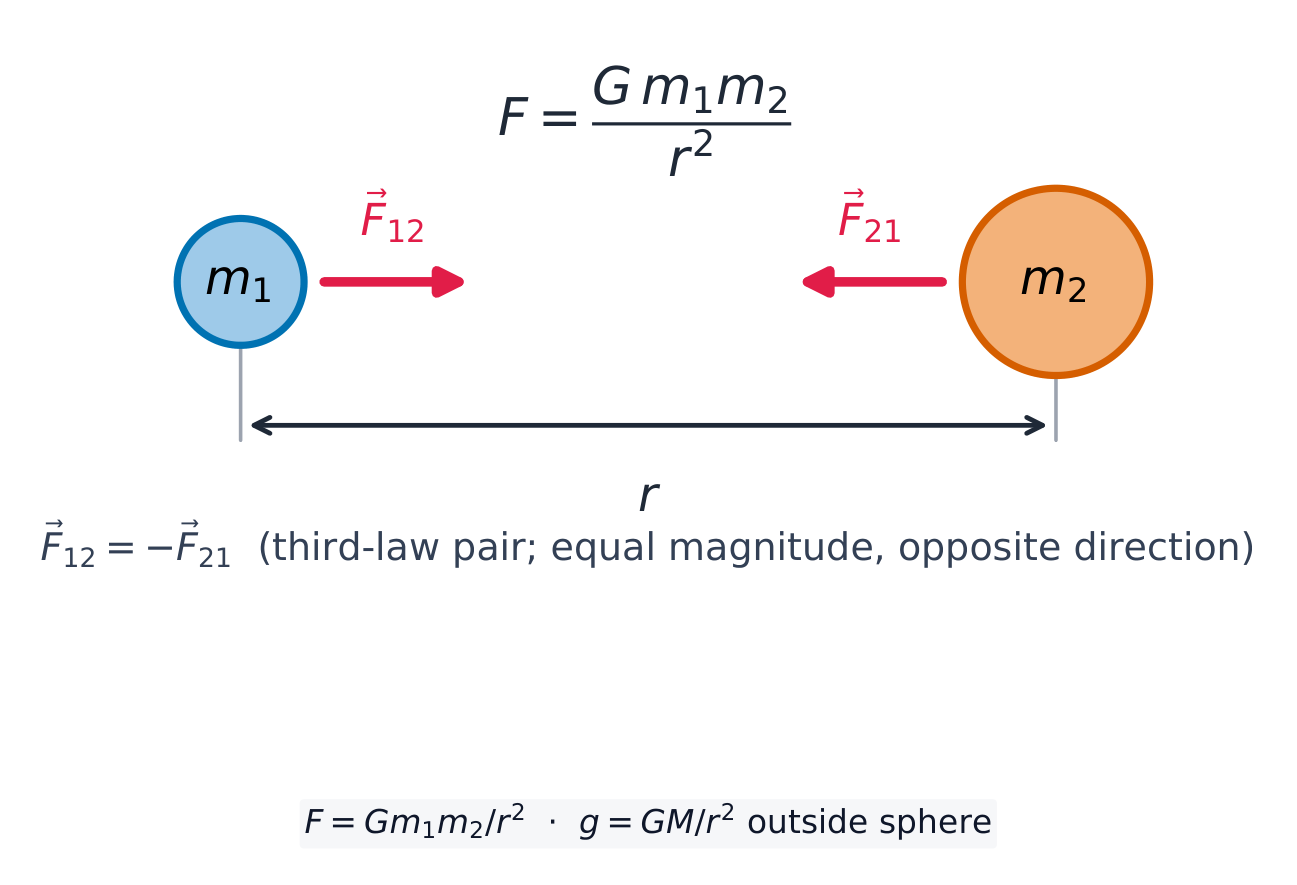
    Near a surface, weight is $F_g=mg$. In general, Newton's law of gravitation 万有引力定律:

    $$F_g=\frac{Gm_1m_2}{r^2},$$
    attractive and inverse-square. The gravitational field is $g=\dfrac{GM}{r^2}$.

    Two masses attract each other with equal, opposite, inverse-square forces along the line joining them
    Two masses attract each other with equal, opposite, inverse-square forces along the line joining them
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Newton's law of gravitation/ˈnjuːtnz lɔː ɒv ˌɡrævɪˈteɪʃn/ Закон всемирного тяготения Ньютона
    2.7

    Kinetic and Static Friction

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.7.A: Describe kinetic friction between two surfaces.

    • 2.7.A.1 Kinetic friction occurs when two surfaces in contact move relative to each other.
      • 2.7.A.1.i The kinetic friction force is exerted in a direction opposite the motion of each surface relative to the other surface.
      • 2.7.A.1.ii The force of friction between two surfaces does not depend on the size of the surface area of contact.
    • 2.7.A.2 The magnitude of the kinetic friction force exerted on an object is the product of the normal force the surface exerts on the object and the coefficient of kinetic friction.
      • Equation: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
      • 2.7.A.2.i The coefficient of kinetic friction depends on the material properties of the surfaces that are in contact.
      • 2.7.A.2.ii Normal force is the perpendicular component of the force exerted on an object by the surface with which it is in contact; it is directed away from the surface.

    Learning Objective 2.7.B: Describe static friction between two surfaces.

    • 2.7.B.1 Static friction may occur between the contacting surfaces of two objects that are not moving relative to each other.
    • 2.7.B.2 Static friction adopts the value and direction required to prevent an object from slipping or sliding on a surface.
      • Equation: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
      • 2.7.B.2.i Slipping and sliding refer to situations in which two surfaces are moving relative to each other.
      • 2.7.B.2.ii There exists a maximum value for which static friction will prevent an object from slipping on a given surface.
        • Derived equation: $F_{f,s,\text{max}} = \mu_s F_N$
    • 2.7.B.3 The coefficient of static friction is typically greater than the coefficient of kinetic friction for a given pair of surfaces.
    Русский

    Цель обучения 2.7.A: Описать кинетическое трение между двумя поверхностями.
    • 2.7.A.1 Кинетическое трение возникает, когда две контактирующие поверхности движутся относительно друг друга.
      • 2.7.A.1.i Сила кинетического трения действует в направлении, противоположном движению каждой поверхности относительно другой поверхности.
      • 2.7.A.1.ii Сила трения между двумя поверхностями не зависит от площади контакта этих поверхностей.
    • 2.7.A.2 Модуль силы кинетического трения, действующей на объект, равен произведению нормальной силы, с которой поверхность действует на объект, на коэффициент кинетического трения.
      • Уравнение: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
      • 2.7.A.2.i Коэффициент кинетического трения зависит от свойств материалов контактирующих поверхностей.
      • 2.7.A.2.ii Нормальная сила — это перпендикулярный компонент силы, с которой поверхность действует на объект; она направлена от поверхности.

    Цель обучения 2.7.B: Описать статическое трение между двумя поверхностями.

    • 2.7.B.1 Статическое трение может возникать между контактирующими поверхностями двух объектов, которые неподвижны относительно друг друга.
    • 2.7.B.2 Статическое трение принимает значение и направление, необходимые для предотвращения скольжения или проскальзывания объекта по поверхности.
      • Уравнение: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
      • 2.7.B.2.i Проскальзывание и скольжение относятся к ситуациям, когда две поверхности движутся относительно друг друга.
      • 2.7.B.2.ii Существует предельное значение, при котором статическое трение предотвращает скольжение объекта по данной поверхности.
        • Выведенное уравнение: $F_{f,s,\text{max}} = \mu_s F_N$
    • 2.7.B.3 Коэффициент статического трения обычно больше коэффициента кинетического трения для данной пары поверхностей.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Friction 摩擦力 opposes sliding along a surface: kinetic 动摩擦 $f_k=\mu_k N$ while sliding, and static 静摩擦 $f_s\le\mu_s N$ up to a maximum before sliding. $N$ is the normal force 法向力. Note the inequality: static friction is only as large as it needs to be, and $\mu_s N$ is its ceiling, not its value.

    Worked example. The same block on the same $30^{\circ}$ incline, now with $\mu_k=0.20$. Perpendicular to the ramp: $N=mg\cos30^{\circ}$. Along the ramp: $ma=mg\sin30^{\circ}-\mu_k mg\cos30^{\circ}$, so $a=g(\sin30^{\circ}-0.20\cos30^{\circ})=9.8(0.500-0.173)=3.2\ \text{m/s}^2$ – the mass cancels again.

    Explore · ⁨Исследовать⁩

    Slide a block down a slope with friction · ⁨Скатить блок по склону с трением⁩

    Friction opposes motion up to a maximum $\mu N$. Tilt the slope until gravity's pull along it beats static friction and the block starts to slide. · ⁨Трение противодействует движению до максимума $\mu N$. Наклоните склон так, чтобытяга гравитации вдоль него превысила трение покоя, и блок начнет скользить.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Friction/ˈfrɪkʃn/ Трение
    kinetic/kɪˈnetɪk/ кинетическая
    static/ˈstætɪk/ статичны
    normal force/ˈnɔːml fɔːs/ сила нормальной реакции опоры
    2.8

    Spring Forces

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.8.A: Describe the force exerted on an object by an ideal spring.

    • 2.8.A.1 An ideal spring has negligible mass and exerts a force that is proportional to the change in its length as measured from its relaxed length. A nonideal spring either has nonnegligible mass or exerts a force that is not proportional to the change in its length as measured from its relaxed length.
    • 2.8.A.2 The magnitude of the force exerted by an ideal spring on an object is given by Hooke's law:
      • Equation: $\vec{F}_s = -k \Delta \vec{x}$
    • 2.8.A.3 The force exerted on an object by a spring is always directed toward the equilibrium position of the object–spring system.

    Learning Objective 2.8.B: Describe the equivalent spring constant of a combination of springs exerting forces on an object.

    • 2.8.B.1 A collection of springs that exert forces on an object may behave as though they were a single spring with an equivalent spring constant $k_{\text{eq}}$.
      • 2.8.B.1.i The inverse of the equivalent spring constant of a set of springs in series is equal to the sum of the inverses of the individual spring constants.
        • Derived equation: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
      • 2.8.B.1.ii The equivalent spring constant of a set of springs arranged in series is smaller than the smallest constituent spring constant.
      • 2.8.B.1.iii The equivalent spring constant of a set of springs arranged in parallel is the sum of the individual spring constants.
        • Derived equation: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$

    Boundary statement: AP Physics C: Mechanics only expects students to find the effective spring constant of systems of springs that are arranged either in series or in parallel and does not expect students to find the effective spring constant of a system in which springs are arranged in both series and parallel.

    Русский

    Цель обучения 2.8.A: Описать силу, действующую на объект со стороны идеальной пружины.

    • 2.8.A.1 Идеальная пружина имеет пренебрежимо малой массой и оказывает силу, пропорциональную изменению ее длины по сравнению с длиной в放松енном состоянии. Неидеальная пружина либо имеет непренебрежимо малой массой, либо оказывает силу, не пропорциональную изменению ее длины по сравнению с длиной в放松енном состоянии.
    • 2.8.A.2 Модуль силы, создаваемой идеальной пружиной на объект, определяется законом Гука:
      • Уравнение: $\vec{F}_s = -k \Delta \vec{x}$
    • 2.8.A.3 Сила, действующая на объект со стороны пружины, всегда направлена к положению равновесия системы «объект–пружина».

    Цель обучения 2.8.B: Описать эквивалентную жесткость комбинации пружин, оказывающих силы на объект.

    • 2.8.B.1 Совоность пружин, действующих на объект, может вести себя так, как будто они являются одной пружиной с эквивалентной жесткостью $k_{\text{eq}}$.
      • 2.8.B.1.i Величина, обратная эквивалентной жесткости набора пружин, соединенных последовательно, равна сумме величин, обратных индивидуальным жесткостям пружин.
        • Выведенное уравнение: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
      • 2.8.B.1.ii Эквивалентная жесткость набора пружин, соединенных последовательно, меньше наименьшей из индивидуальных жесткостей.
      • 2.8.B.1.iii Эквивалентная жесткость набора пружин, соединенных параллельно, равна сумме индивидуальных жесткостей.
        • Выведенное уравнение: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$

    Уточнение: AP Physics C: Механика требует от студентов находить эффективную жесткость систем пружин, соединенных либо последовательно, либо параллельно, и не требует от студентов находить эффективную жесткость систем, в которых пружины соединены как последовательно, так и параллельно.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

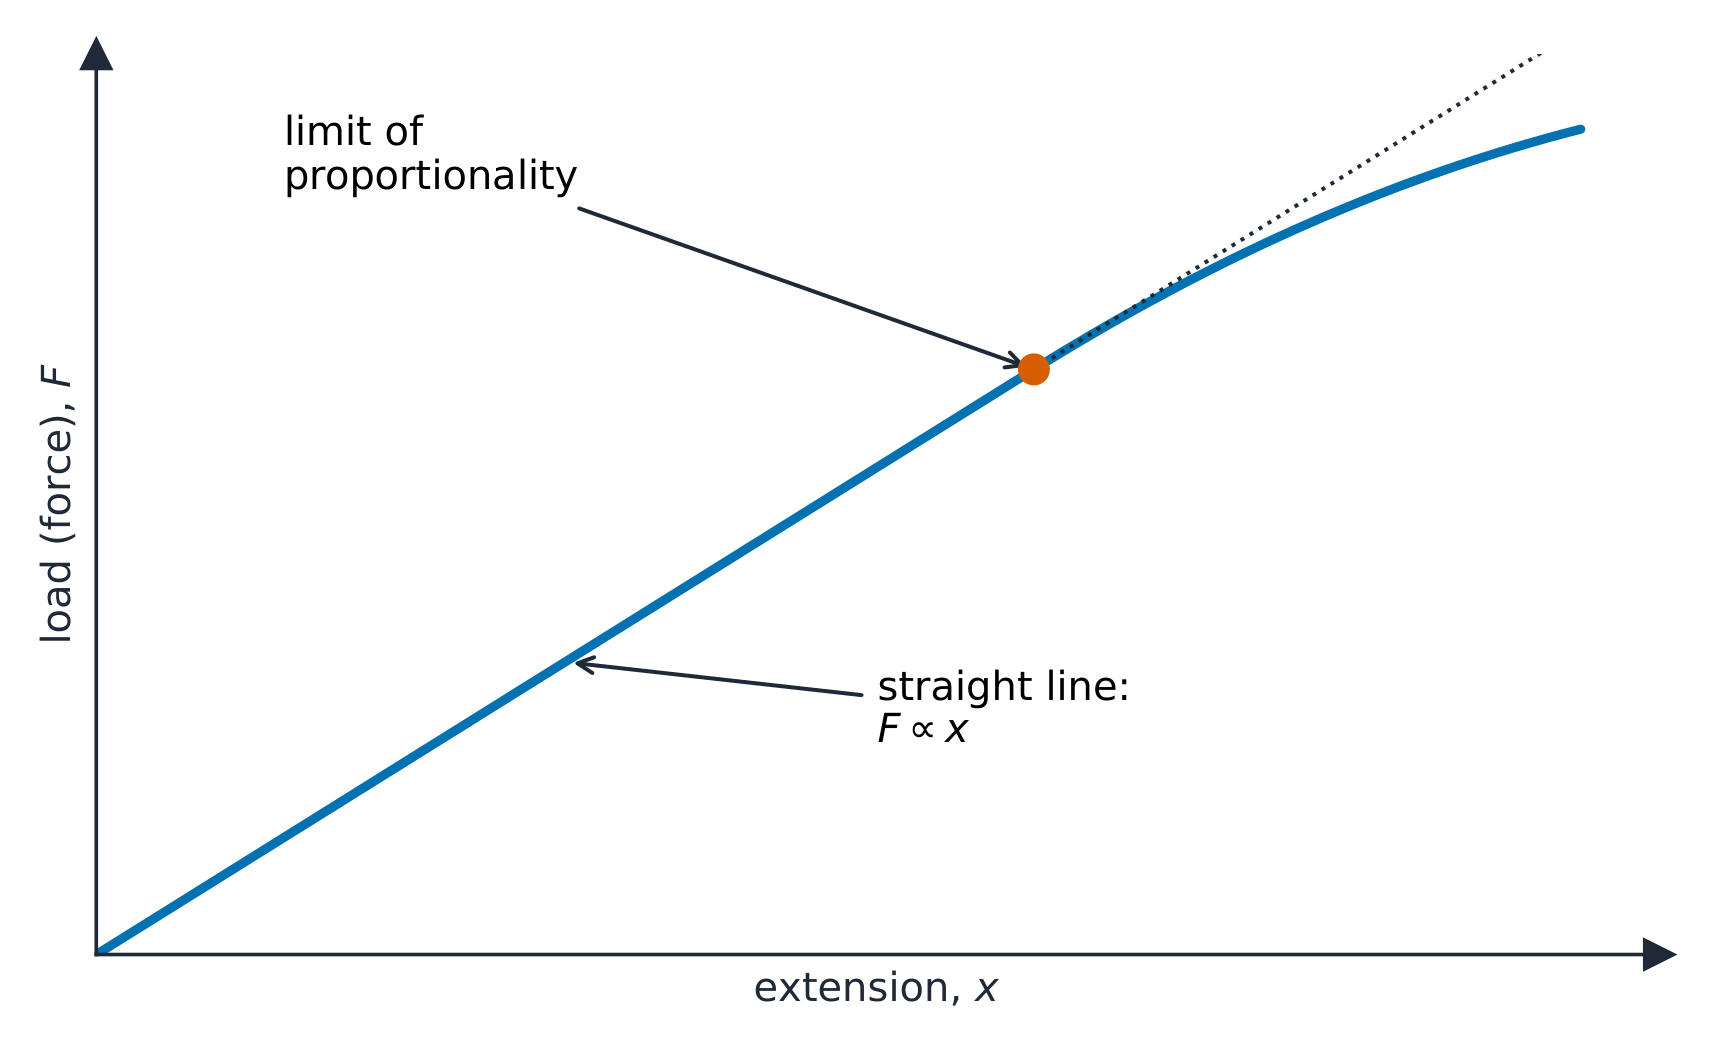
    Hooke's law & the elastic limit

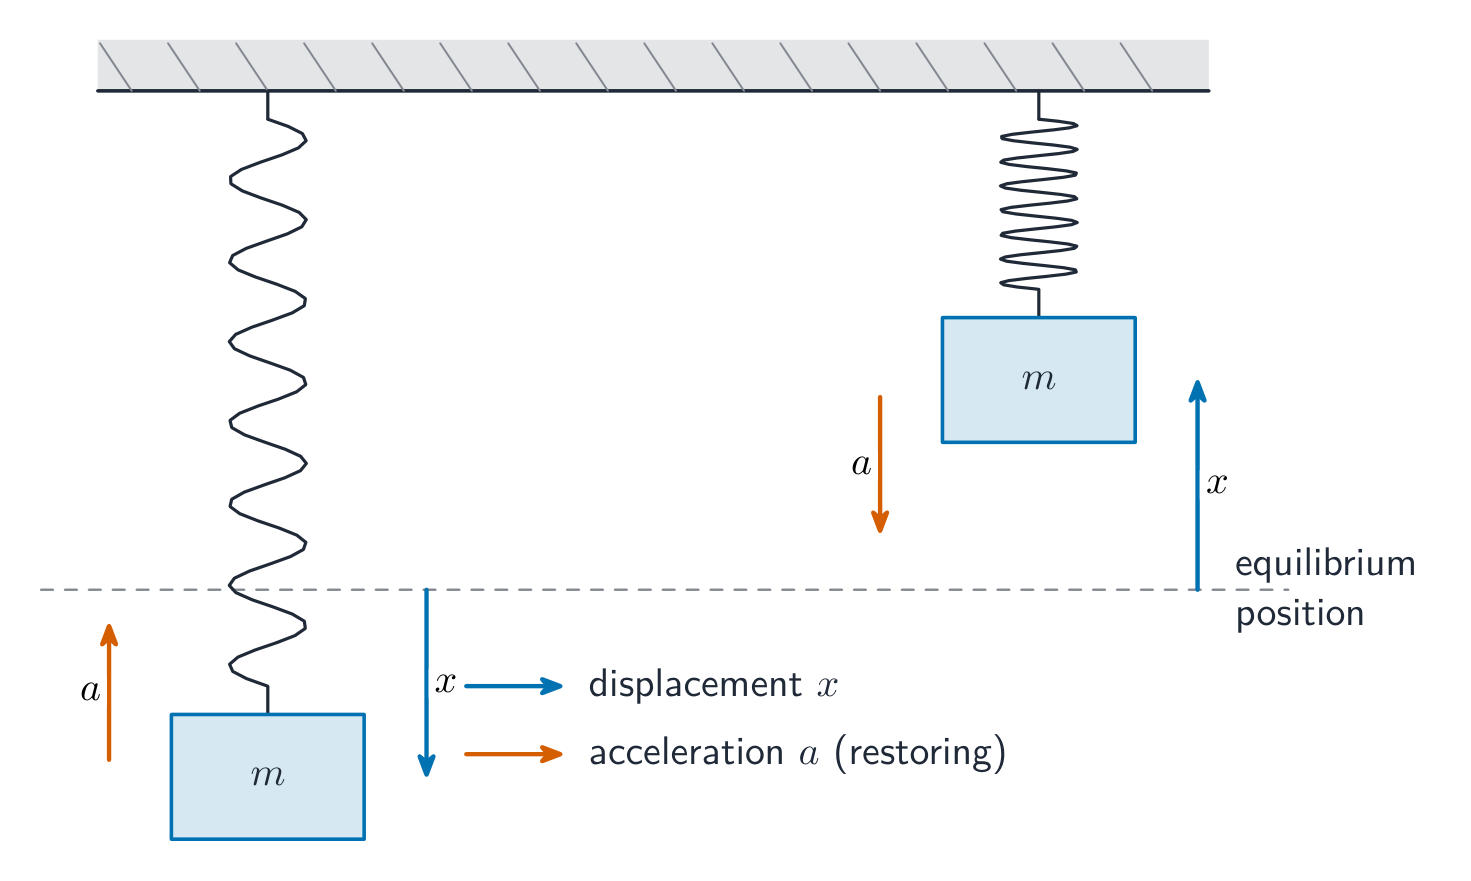
    An ideal spring obeys Hooke's law 胡克定律 $F_s=-kx$, a restoring force set by the spring constant 弹簧劲度系数 $k$. Its stored energy is $U=\tfrac12 kx^2$.

    Hooke's law: extension is proportional to load up to the limit of proportionality
    Hooke's law: extension is proportional to load up to the limit of proportionality

    Combined springs act as one equivalent spring of constant $k_{\text{eq}}$. In parallel (side by side, sharing the load) the constants add, $k_{\text{eq}}=k_1+k_2$ – stiffer than either. In series (end to end) they combine as $\dfrac{1}{k_{\text{eq}}}=\dfrac{1}{k_1}+\dfrac{1}{k_2}$ – softer than the softest one. Two springs pulling a mass from opposite sides also act in parallel, giving a restoring constant $k_1+k_2$. Whichever you have, the SHM period uses $k_{\text{eq}}$: $T=2\pi\sqrt{m/k_{\text{eq}}}$.

    Explore · ⁨Исследовать⁩

    Stretch a spring (Hooke's law) · ⁨Растянуть пружину (закон Гука)⁩

    A spring's force is proportional to its extension, $F=kx$ (Hooke's law). Pull harder and the extension grows in step — until the spring's limit. · ⁨Сила пружины пропорциональна ее удлинению, $F=kx$ (закон Гука). Тяните сильнее, и удлинение растет пропорционально —直到弹簧的极限。⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Hooke's law/hʊks lɔː/ Закон Гука
    spring constant/sprɪŋ ˈkɒnstənt/ жёсткость пружины
    2.9

    Resistive Forces

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.9.A: Describe the motion of an object subject to a resistive force.

    • 2.9.A.1 A resistive force is defined as a velocity-dependent force in the opposite direction of an object's velocity, for example:
      • Equation: $\vec{F}_r = -k\vec{v}$
    • 2.9.A.2 Applying Newton's second law to an object upon which a resistive force is exerted results in a differential equation for velocity.
      • 2.9.A.2.i Using the method of separation of variables, the velocity can be determined by integrating over the proper limits of integration.
      • 2.9.A.2.ii The acceleration or position of a moving object that is subject to a velocity-dependent force may be determined using initial conditions of the object and methods of calculus, once a function for velocity is determined.
      • 2.9.A.2.iii The position, velocity, and acceleration as functions of time of an object under the influence of a resistive force of the form $\vec{F}_r = -k\vec{v}$ are exponential and have asymptotes that are determined by the initial conditions of the object and the forces exerted on the object.
    • 2.9.A.3 Terminal velocity is defined as the maximum speed achieved by an object moving under the influence of a constant force and a resistive force that are exerted on the object in opposite directions. The terminal condition is reached when the net force exerted on the object is zero.
    Русский

    Цель обучения 2.9.A: Описать движение объекта, подверженного сопротивляющей силе.

    • 2.9.A.1 Сопротивляющая сила определяется как зависящая от скорости сила, направленная в сторону, противоположную вектору скорости объекта, например:
      • Уравнение: $\vec{F}_r = -k\vec{v}$
    • 2.9.A.2 Применение второго закона Ньютона к объекту, на который действует сила сопротивления, приводит к дифференциальному уравнению для скорости.
      • 2.9.A.2.i Используя метод разделения переменных, скорость можно определить интегрированием по соответствующим пределам интегрирования.
      • 2.9.A.2.ii Ускорение или положение движущегося объекта, подверженного силе, зависящей от скорости, могут быть определены с использованием начальных условий объекта и методов математического анализа после определения функции скорости.
      • 2.9.A.2.iii Положение, скорость и ускорение как функции времени объекта под действием силы сопротивления вида $\vec{F}_r = -k\vec{v}$ являются экспоненциальными и имеют асимптоты, определяемые начальными условиями объекта и силами, действующими на объект.
    • 2.9.A.3 Терминальная скорость определяется как максимальная скорость, достигаемая объектом, движущимся под действием постоянной силы и силы сопротивления, которые действуют на объект в противоположных направлениях. Терминальное состояние достигается, когда результирующая сила, действующая на объект, равна нулю.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

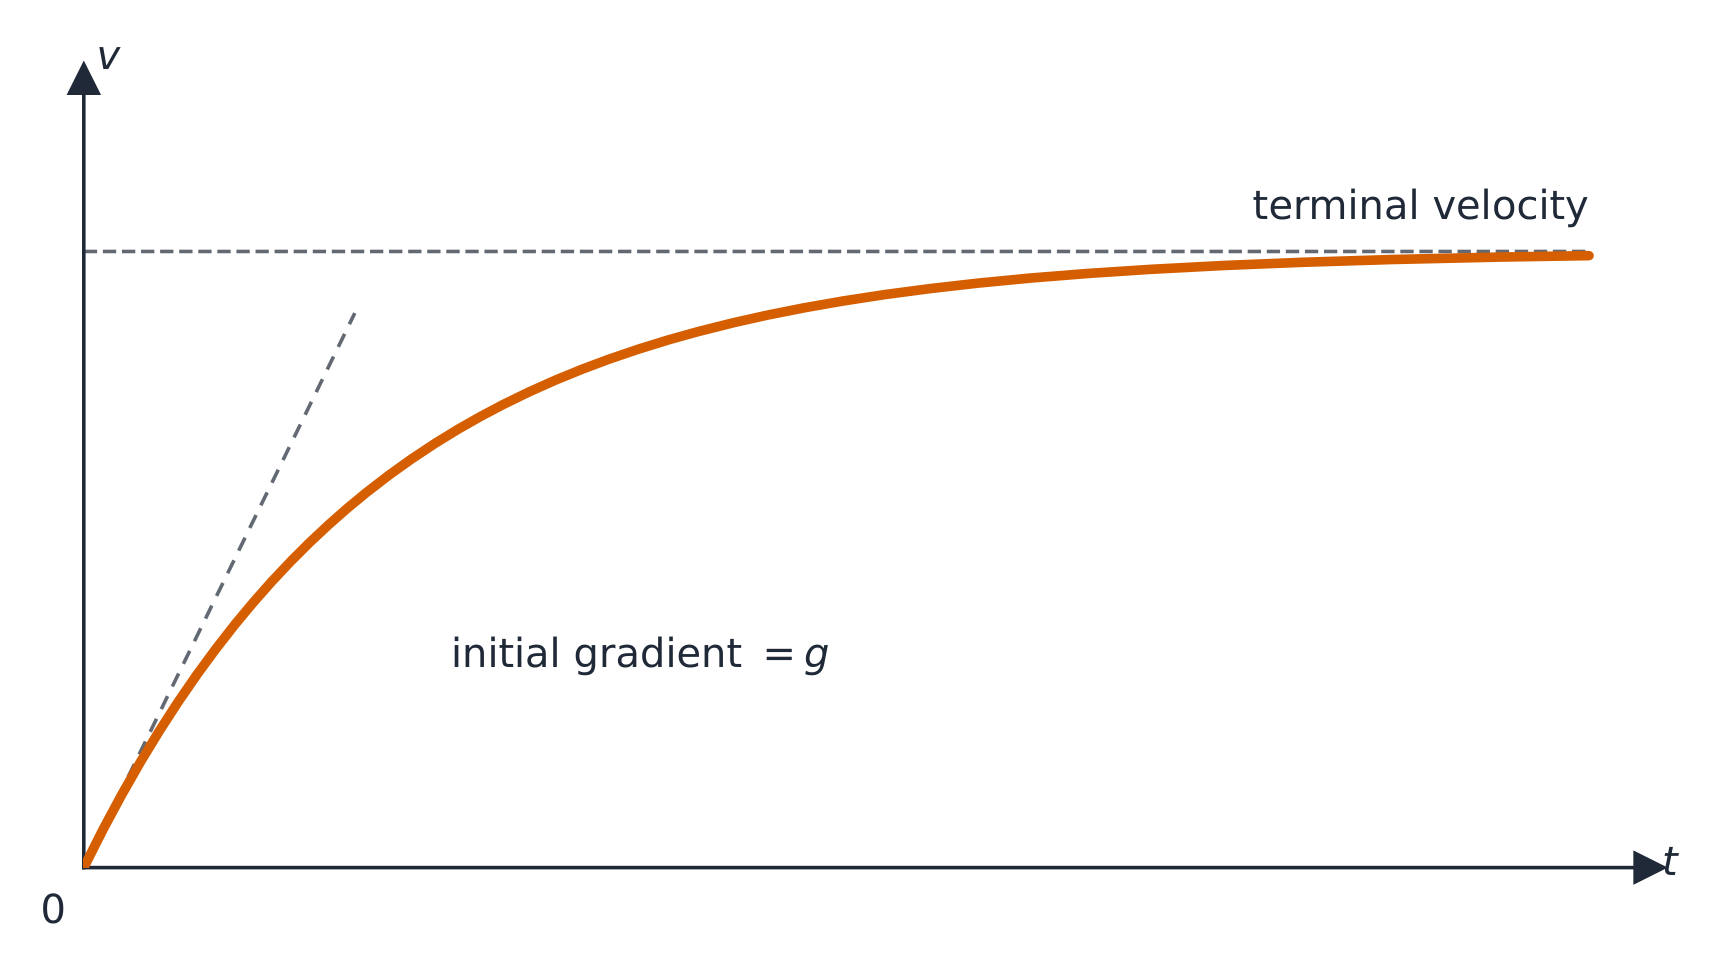
    A resistive force 阻力 (drag) opposes motion through a fluid and grows with speed, often modeled as $F=-bv$ or $F=-cv^2$. Newton's second law then gives a differential equation, e.g. $m\dfrac{dv}{dt}=mg-bv$ for a falling object. As speed rises, drag builds until it balances the driving force; the object then stops accelerating and moves at a constant terminal velocity 终极速度, found by setting the net force (and $dv/dt$) to zero.

    Worked example. For a falling object with $m\dfrac{dv}{dt}=mg-bv$, the terminal velocity is where $\dfrac{dv}{dt}=0$: $mg=bv_T$, so $v_T=\dfrac{mg}{b}$. With $m=0.10\ \text{kg}$ and $b=0.50\ \text{kg/s}$, $v_T=\dfrac{0.10(9.8)}{0.50}=2.0\ \text{m/s}$.

    To get the full motion $v(t)$, separate the variables 分离变量 and integrate from rest:

    $$\int_0^{v}\frac{dv'}{mg-bv'}=\int_0^{t}\frac{dt'}{m}\;\Rightarrow\;-\frac{1}{b}\ln\!\frac{mg-bv}{mg}=\frac{t}{m},$$
    which rearranges to $v(t)=v_T\left(1-e^{-bt/m}\right)$ – the speed rising exponentially toward $v_T$. Showing this integration is the calculus skill a Physics C free-response rewards, not just quoting the final formula.

    An object falling through a fluid speeds up to a terminal velocity
    An object falling through a fluid speeds up to a terminal velocity
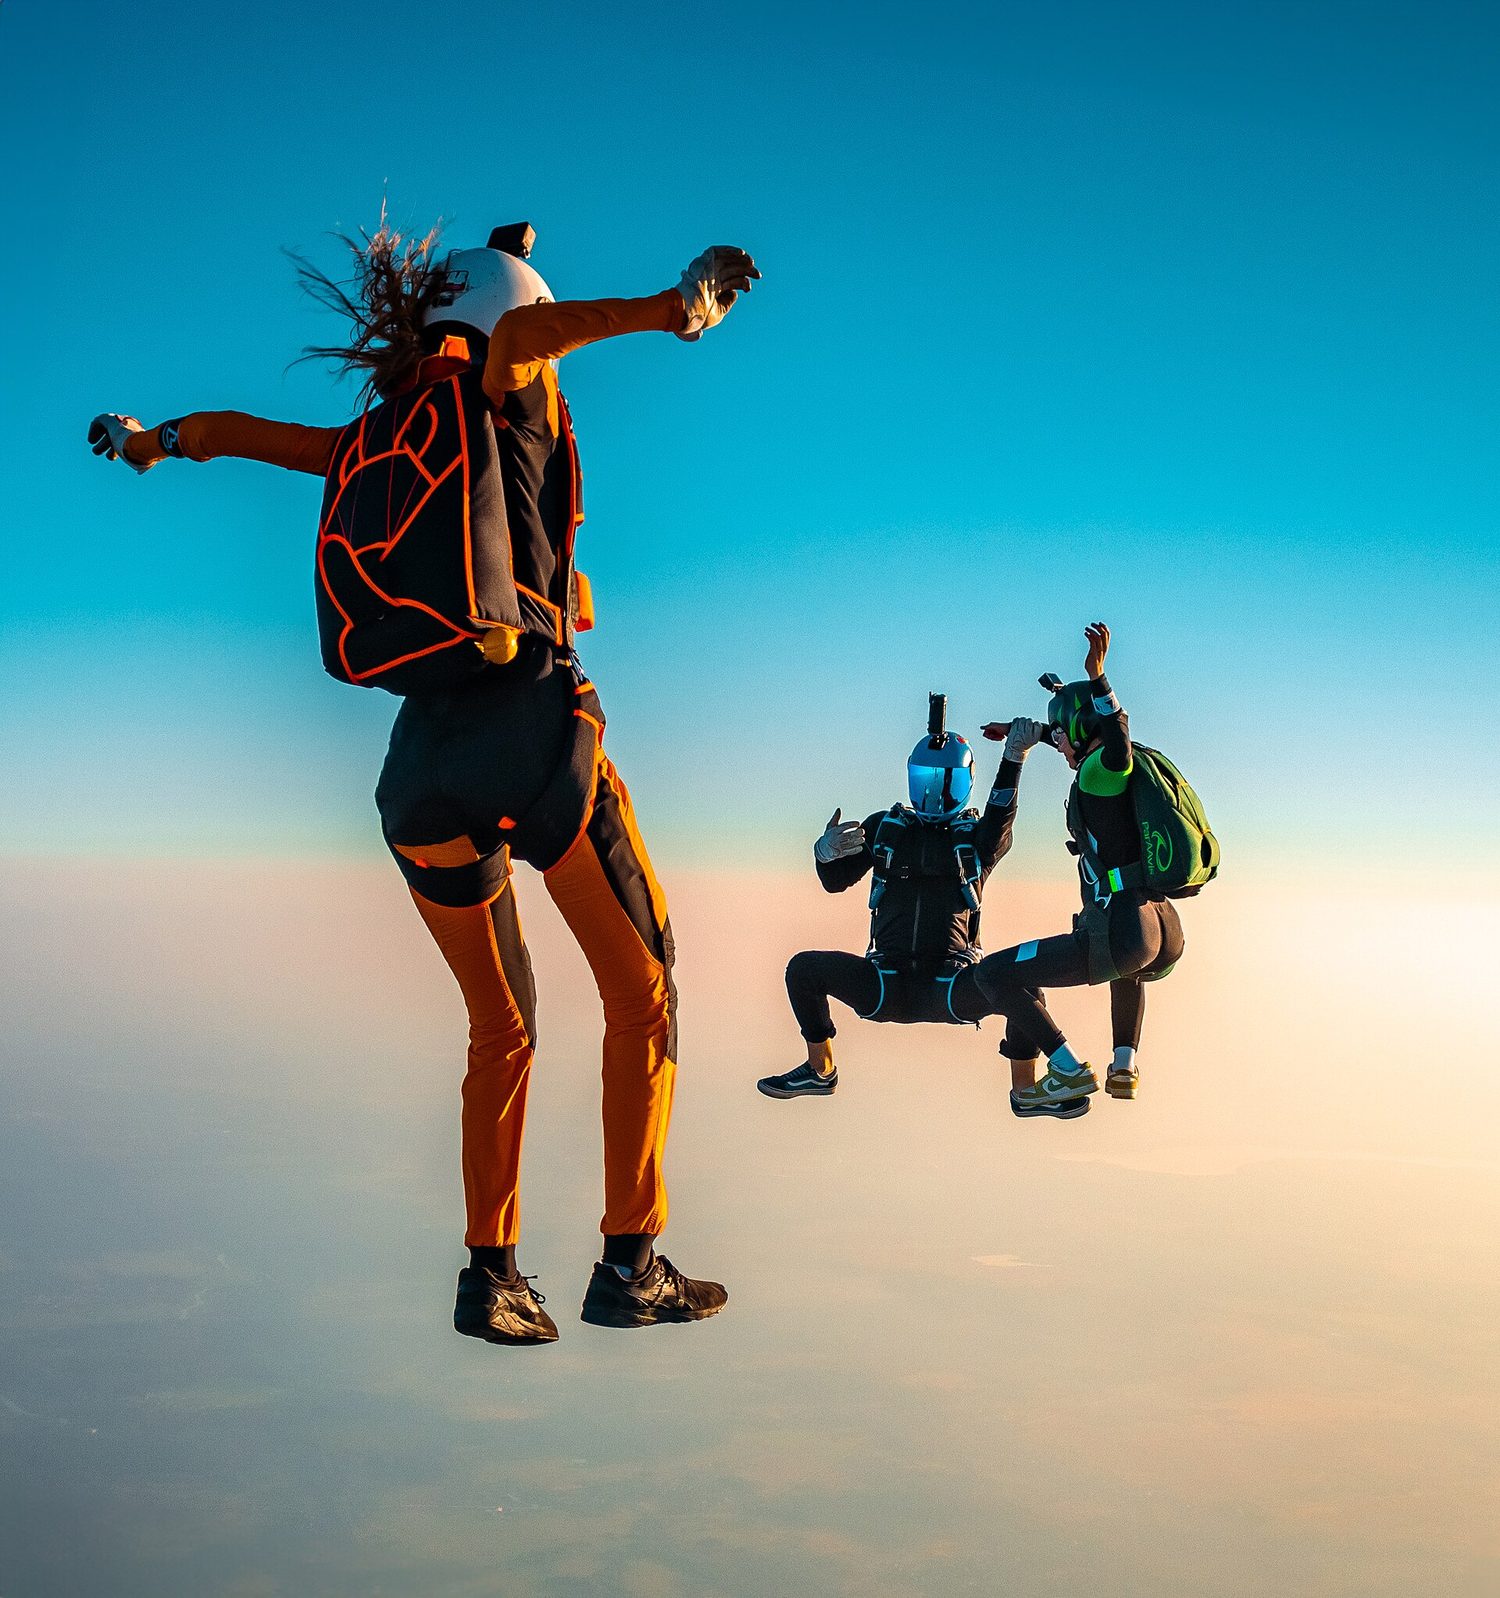
    Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity
    Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    resistive force/rɪˈzɪstɪv fɔːs/ сопротивляющая сила
    terminal velocity/ˈtɜːmɪnl vəˈlɒsɪti/ terminal velocity
    separate the variables/ˈseprət ðə ˈveərɪəblz/ разделить переменные
    2.10

    Circular Motion

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 2.10.A: Describe the motion of an object traveling in a circular path.

    • 2.10.A.1 Centripetal acceleration is the component of an object's acceleration directed toward the center of the object's circular path.
      • 2.10.A.1.i The magnitude of centripetal acceleration for an object moving in a circular path is the ratio of the object's tangential speed squared to the radius of the circular path.
        • Equation: $a_c = \dfrac{v^2}{r}$
      • 2.10.A.1.ii Centripetal acceleration is directed toward the center of an object's circular path.
    • 2.10.A.2 Centripetal acceleration can result from a single force, more than one force, or components of forces that are exerted on an object in circular motion.
      • 2.10.A.2.i At the top of a vertical, circular loop, an object requires a minimum speed to maintain circular motion. At this point, and with this minimum velocity, the gravitational force is the only force that causes the centripetal acceleration.
        • Derived equation: $v = \sqrt{gr}$
      • 2.10.A.2.ii Components of the static friction force and the normal force can contribute to the net force producing centripetal acceleration of an object traveling in a circle on a banked surface.
      • 2.10.A.2.iii A component of tension contributes to the net force producing centripetal acceleration experienced by a conical pendulum.
    • 2.10.A.3 Tangential acceleration is the rate at which an object's speed changes and is directed tangent to the object's circular path.
    • 2.10.A.4 The net acceleration of an object moving in a circle is the vector sum of the centripetal acceleration and tangential acceleration.
    • 2.10.A.5 The revolution of an object traveling in a circular path at a constant speed (uniform circular motion) can be described using period and frequency.
      • 2.10.A.5.i The time to complete one full circular path, one full rotation, or a full cycle of oscillatory motion is defined as period, $T$.
      • 2.10.A.5.ii The rate at which an object is completing revolutions is defined as frequency, $f$.
        • Equation: $T = \dfrac{1}{f}$
      • 2.10.A.5.iii For an object traveling at a constant speed in a circular path, the period is given by the derived equation
        • Derived equation: $T = \dfrac{2\pi r}{v}$

    Learning Objective 2.10.B: Describe circular orbits using Kepler's third law.

    • 2.10.B.1 For a satellite in circular orbit around a central body, the satellite's centripetal acceleration is caused only by gravitational attraction. The period and radius of the circular orbit are related to the mass of the central body.
      • Derived equation: $T^2 = \dfrac{4\pi^2}{GM} R^3$

    Boundary statement: AP Physics C: Mechanics does not expect students to know Kepler's first or second laws of planetary motion.

    Русский

    Цель обучения 2.10.A: Описать движение объекта, движущегося по круговой траектории.

    • 2.10.A.1 Центростремительное ускорение — это компонента ускорения объекта, направленная к центру его круговой траектории.
      • 2.10.A.1.i Модуль центростремительного ускорения объекта, движущегося по круговой траектории, равен отношению квадрата тангенциальной скорости объекта к радиусу круговой траектории.
        • Уравнение: $a_c = \dfrac{v^2}{r}$
      • 2.10.A.1.ii Центростремительное ускорение направлено к центру круговой траектории объекта.
    • 2.10.A.2 Центростремительное ускорение может возникать под действием одной силы, нескольких сил или компонент сил, действующих на объект при круговом движении.
      • 2.10.A.2.i В верхней точке вертикальной круговой петли объекту необходима минимальная скорость для поддержания кругового движения. В этой точке и при этой минимальной скорости сила тяжести является единственной силой, вызывающей центростремительное ускорение.
        • Выведенное уравнение: $v = \sqrt{gr}$
      • 2.10.A.2.ii Компоненты силы трения покоя и нормальной реакции опоры могут вносить вклад в результирующую силу, создающую центростремительное ускорение объекта, движущегося по окружности на наклонной поверхности.
      • 2.10.A.2.iii Компонента силы натяжения вносит вклад в результирующую силу, создающую центростремительное ускорение, испытываемое коническим маятником.
    • 2.10.A.3 Тангенциальное ускорение — это скорость изменения скорости объекта и направлена касательно круговой траектории объекта.
    • 2.10.A.4 Результирующее ускорение объекта, движущегося по окружности, является векторной суммой центростремительного и тангенциального ускорений.
    • 2.10.A.5 Оборот объекта, движущегося по круговой траектории с постоянной скоростью (равномерное круговое движение), можно описать с помощью периода и частоты.
      • 2.10.A.5.i Время, необходимое для завершения одного полного кругового пути, одного полного оборота или полного цикла колебательного движения, определяется как период, $T$.
      • 2.10.A.5.ii Скорость, с которой объект совершает обороты, называется частотой, $f$.
        • Уравнение: $T = \dfrac{1}{f}$
      • 2.10.A.5.iii Для объекта, движущегося с постоянной скоростью по круговой траектории, период задается выведенным уравнением
        • Выведенное уравнение: $T = \dfrac{2\pi r}{v}$

    Цель обучения 2.10.B: Описать круговые орбиты с использованием третьего закона Кеплера.

    • 2.10.B.1 Для спутника на круговой орбите вокруг центрального тела центростремительное ускорение спутника вызвано исключительно гравитационным притяжением. Период и радиус круговой орбиты связаны с массой центрального тела.
      • Выведенное уравнение: $T^2 = \dfrac{4\pi^2}{GM} R^3$

    Уточнение: AP Physics C: Механика не требует от студентов знания первого или второго законов Кеплера о движении планет.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

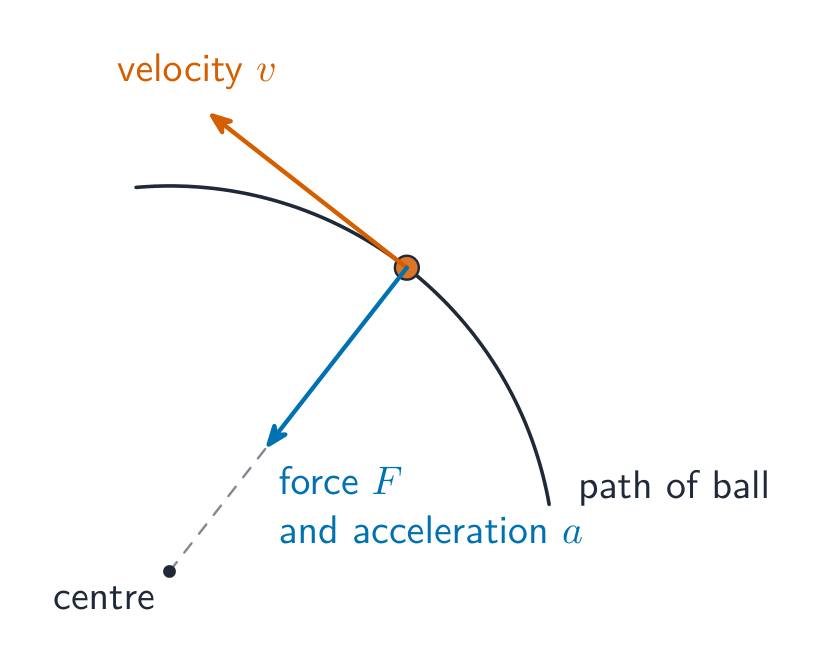
    Uniform circular motion

    Uniform circular motion has a centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}$ pointing to the center, requiring a net inward force $F_c=\dfrac{mv^2}{r}$ supplied by a real force (tension, gravity, friction, normal). There is no outward force. For vertical circles and banked curves, decompose the real forces to find which provides the centripetal requirement.

    Worked example. A $0.50\ \text{kg}$ ball is whirled on a $1.0\ \text{m}$ string in a horizontal circle at $3.0\ \text{m/s}$. The string tension supplies the whole centripetal force: $T=\dfrac{mv^2}{r}=\dfrac{0.50(3.0)^2}{1.0}=4.5\ \text{N}$.

    Worked example (vertical circle). At the top of a vertical loop of radius $r$, gravity and the normal force both point toward the center: $N+mg=\dfrac{mv^2}{r}$. The slowest possible speed at the top is where the track pushes with nothing at all ($N=0$): $v_{\min}=\sqrt{gr}$. For $r=2.5\ \text{m}$: $v_{\min}=\sqrt{9.8(2.5)}=4.9\ \text{m/s}$. Any slower and the cart leaves the track before the top.

    The velocity points along the tangent; the centripetal force points to the centre
    The velocity points along the tangent; the centripetal force points to the centre
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ центростремительное ускорение
    2.10

    Exam tips

    • Locate the center of mass with $x_{cm}=\tfrac{1}{M}\int x\,dm$ (or $\tfrac{\sum m_i x_i}{\sum m_i}$ for point masses) and use $\lambda,\sigma,\rho$ for the mass element.
    • The net external force moves the center of mass as if all mass sat there: $\vec F_{net}=M\vec a_{cm}$.
    • Define your system clearly — internal forces cancel, so only external forces change its momentum.
    • Exploit symmetry to shortcut a center-of-mass integral.
    • Distinguish center of mass from center of gravity (identical in a uniform field).
  • 3

    Work, Energy, and Power · ⁨Работа, энергия и мощность⁩

    Watch lesson · ⁨Смотреть урок⁩
    3.1

    Translational Kinetic Energy · ⁨Трансляционная кинетическая энергия⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 3.1.A: Describe the translational kinetic energy of an object in terms of the object's mass and velocity.

    • 3.1.A.1 An object's translational kinetic energy is given by the equation
      • Equation: $K = \dfrac{1}{2}mv^2$
    • 3.1.A.2 Translational kinetic energy is a scalar quantity.
    • 3.1.A.3 Different observers may measure different values of the translational kinetic energy of an object, depending on the observer's frame of reference.
    Русский

    Цель обучения 3.1.A: Описать поступательную кинетическую энергию объекта с точки зрения массы и скорости этого объекта.

    • 3.1.A.1 Поступательная кинетическая энергия объекта задается уравнением
      • Уравнение: $K = \dfrac{1}{2}mv^2$
    • 3.1.A.2 Поступательная кинетическая энергия является скалярной величиной.
    • 3.1.A.3 Разные наблюдатели могут измерять различные значения поступательной кинетической энергии объекта в зависимости от системы отсчета наблюдателя.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Kinetic energy 动能 is the energy of motion, a scalar 标量 measured in joules 焦耳 (J):

    $$K=\tfrac{1}{2}mv^2.$$

    It grows with the square of speed – doubling the speed quadruples $K$. One subtlety worth knowing: kinetic energy depends on the observer's reference frame 参考系. A passenger walking down a train has a small $K$ measured inside the train and a huge one measured from the ground – both observers are right, each in their own frame.

    Русский

    Кинетическая энергия — это энергия движения, скалярная величина, измеряемая в джоулях (Дж):

    $$K=\tfrac{1}{2}mv^2.$$

    Она растет пропорционально квадрату скорости — удвоение скорости увеличивает $K$ в четыре раза. Важный нюанс: кинетическая энергия зависит от системы отсчета наблюдателя. Пассажир, идущий по вагону поезда, имеет малую $K$, измеренную внутри поезда, и огромную энергию, измеренную с земли — оба наблюдателя правы, каждый в своей системе отсчета.

    3.2

    Work · ⁨Работа⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 3.2.A: Describe the work done on an object or system by a given force or collection of forces.

    • 3.2.A.1 Work is the amount of energy transferred into or out of a system by a force exerted on that system over a distance.
      • 3.2.A.1.i The work done by a conservative force exerted on a system is path-independent and only depends on the initial and final configurations of that system.
      • 3.2.A.1.ii The work done by a conservative force on a system—or the change in the potential energy of the system—will be zero if the system returns to its initial configuration.
      • 3.2.A.1.iii Potential energies are associated only with conservative forces.
      • 3.2.A.1.iv The work done by a nonconservative force is path-dependent.
      • 3.2.A.1.v The most common nonconservative forces are friction and air resistance.
    • 3.2.A.2 Work is a scalar quantity that may be positive, negative, or zero.
    • 3.2.A.3 The work done on an object by a variable force is calculated using
      • Equation: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, where the integral is taken over the path from point $a$ to point $b$.
      • 3.2.A.3.i The dot product between two vectors, $\vec{A}$ and $\vec{B}$, results in a scalar quantity of magnitude $\vec{A} \cdot \vec{B} = AB\cos\theta$.
      • 3.2.A.3.ii Only the component of the force exerted on a system that is parallel to the displacement of the point of application of the force will change the system's total energy.
      • 3.2.A.3.iii If the component of the force exerted on a system that is parallel to the displacement is constant, the work done on the system by the force is given by the derived equation $W = F_{\parallel}d = Fd\cos\theta$.
      • 3.2.A.3.iv The component of the force exerted on a system perpendicular to the direction of the displacement of the system's center of mass can change the direction of the system's motion without changing the system's kinetic energy.
    • 3.2.A.4 The work–energy theorem states that the change in an object's kinetic energy is equal to the sum of the work (net work) being done by all forces exerted on the object.
      • Equation: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
      • 3.2.A.4.i An external force may change the configuration of a system. The component of the external force parallel to the displacement times the displacement of the point of application of the force gives the change in kinetic energy of the system.
      • 3.2.A.4.ii If the system's center of mass and the point of application of the force move the same distance when a force is exerted on a system, then the system may be modeled as an object, and only the system's kinetic energy can change.
      • 3.2.A.4.iii The energy dissipated by friction is typically equated to the force of friction times the length of the path over which the force is exerted.
        • Equation: $\Delta E_{\text{mech}} = F_f d\cos\theta$
      • 3.2.A.5 Work is equal to the area under the curve of a graph of $F_{\parallel}$ as a function of displacement.

    Boundary statement: AP Physics C: Mechanics only expects students to analyze the transfer of mechanical energy, although students should be aware that mechanical energy may be dissipated in the form of thermal energy or sound.

    Русский

    Цель обучения 3.2.A: Описать работу, совершаемую над объектом или системой данной силой или совокупностью сил.

    • 3.2.A.1 Работа — это количество энергии, переданное в систему или из нее силой, действующей на эту систему на определенном расстоянии.
      • 3.2.A.1.i Работа консервативной силы, действующей на систему, не зависит от пути и определяется только начальным и конечным состояниями этой системы.
      • 3.2.A.1.ii Работа консервативной силы над системой — или изменение потенциальной энергии системы — будет равно нулю, если система возвращается в свое начальное состояние.
      • 3.2.A.1.iii Потенциальные энергии связаны исключительно с консервативными силами.
      • 3.2.A.1.iv Работа неконсервативной силы зависит от пути.
      • 3.2.A.1.v Наиболее распространенными неконсервативными силами являются трение и сопротивление воздуха.
    • 3.2.A.2 Работа — это скалярная величина, которая может быть положительной, отрицательной или равной нулю.
    • 3.2.A.3 Работа, совершенная над объектом переменной силой, вычисляется с помощью
      • Уравнение: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, где интеграл берется по траектории от точки $a$ до точки $b$.
      • 3.2.A.3.i Скалярное произведение двух векторов, $\vec{A}$ и $\vec{B}$, дает скалярную величину величиной $\vec{A} \cdot \vec{B} = AB\cos\theta$.
      • 3.2.A.3.ii Только составляющая силы, действующей на систему, параллельная перемещению точки приложения силы, изменяет полную энергию системы.
      • 3.2.A.3.iii Если составляющая силы, действующей на систему, параллельная перемещению, постоянна, то работа, совершенная над системой этой силой, задается выведенным уравнением $W = F_{\parallel}d = Fd\cos\theta$.
      • 3.2.A.3.iv Составляющая силы, действующей на систему, перпендикулярная направлению перемещения центра масс системы, может изменить направление движения системы, не изменяя ее кинетическую энергию.
    • 3.2.A.4 Теорема о кинетической энергии гласит, что изменение кинетической энергии объекта равно сумме работ (суммарной работе), совершаемых всеми силами, действующими на объект.
      • Уравнение: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
      • 3.2.A.4.i Внешняя сила может изменить конфигурацию системы. Произведение компоненты внешней силы, параллельной перемещению, на перемещение точки приложения силы дает изменение кинетической энергии системы.
      • 3.2.A.4.ii Если центр масс системы и точка приложения силы перемещаются на одинаковое расстояние при действии силы на систему, то систему можно моделировать как объект, и может изменяться только кинетическая энергия системы.
      • 3.2.A.4.iii Энергия, рассеиваемая трением, обычно приравнивается к силе трения, умноженной на длину пути, на котором эта сила действует.
        • Уравнение: $\Delta E_{\text{mech}} = F_f d\cos\theta$
      • 3.2.A.5 Работа равна площади под кривой графика зависимости $F_{\parallel}$ от перемещения.

    Граничное утверждение: AP Physics C: Mechanics требует от студентов только анализа передачи механической энергии, хотя студенты должны знать, что механическая энергия может рассеиваться в виде тепловой энергии или звука.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Work 功 is energy transferred into or out of a system by a force acting over a distance. For a variable force it is an integral 积分 along the path:

    $$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$

    For a constant force this reduces to $W=Fd\cos\theta$; on a force–position graph, work is the area under the curve. Work is a scalar with a sign, and the sign is physics, not bookkeeping:

    • Positive – force has a component along the motion (it speeds the object up).
    • Negative – force opposes the motion (friction 摩擦力 and air drag do negative work).
    • Zero – force perpendicular to the motion (the normal force 法向力 on a sliding block, gravity on a horizontal move, tension in a circular swing).

    The work–energy theorem 动能定理 collects every force's contribution: the net work equals the change in kinetic energy,

    $$W_{\text{net}}=\sum W_i=\Delta K.$$

    Worked example. A variable force $F(x)=3x^2\ \text{N}$ (along the motion) acts from $x=0$ to $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. Acting alone on a body starting from rest, it would raise the kinetic energy to exactly $8\ \text{J}$.

    Русский

    Работа — это энергия, передаваемая в систему или из нее под действием силы на определенном расстоянии. Для переменной силы это интеграл вдоль траектории:

    $$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$

    Для постоянной силы это сводится к $W=Fd\cos\theta$; на графике зависимости силы от координаты работа равна площади под кривой. Работа — скалярная величина со знаком, и этот знак имеет физический смысл, а не является просто бухгалтерским учетом:

    • Положительная — сила имеет компоненту вдоль движения (она ускоряет тело).
    • Отрицательная — сила противодействует движению (трение и сопротивление воздуха совершают отрицательную работу).
    • Нулевая — сила перпендикулярна движению (сила реакции опоры на скользящий блок, гравитация при горизонтальном перемещении, натяжение при круговом качании).
    Только компонента силы вдоль перемещения совершает работу
    Только компонента силы вдоль перемещения совершает работу

    Теорема о работе и энергии объединяет вклад каждой силы: полная работа равна изменению кинетической энергии,

    $$W_{\text{net}}=\sum W_i=\Delta K.$$

    Разобранная задача. Переменная сила $F(x)=3x^2\ \text{N}$ (вдоль движения) действует от $x=0$ до $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. Действуя самостоятельно на тело, начинающее движение из состояния покоя, она увеличила бы его кинетическую энергию ровно до $8\ \text{J}$.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Kinetic energy/kɪˈnetɪk ˈenədʒi/ Кинетическая энергия
    scalar/ˈskeɪlə/ скаляр
    joules/dʒuːlz/ джоули
    reference frame/ˈrefrəns freɪm/ система отсчета
    Work/wɜːk/ Работа
    integral/ˈɪntɪɡrəl/ интеграла
    friction/ˈfrɪkʃn/ трение
    normal force/ˈnɔːml fɔːs/ сила нормальной реакции опоры
    work–energy theorem/wɜːk ˈenədʒi ˈθɪərəm/ теорема о работе и энергии
    3.3

    Potential Energy · ⁨Потенциальная энергия⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 3.3.A: Describe the potential energy of a system.

    • 3.3.A.1 A system composed of two or more objects has potential energy if the objects within that system only interact with each other through conservative forces.
    • 3.3.A.2 Potential energy is a scalar quantity associated with the position of objects within a system.
    • 3.3.A.3 The definition of zero potential energy for a given system is a decision made by the observer considering the situation to simplify or otherwise assist in analysis.
    • 3.3.A.4 The relationship between conservative forces exerted on a system and the system's potential energy is
      • Equation: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
    • 3.3.A.5 The conservative forces exerted on a system in a single dimension can be determined using the slope of the system's potential energy with respect to position in that dimension; these forces point in the direction of decreasing potential energy.
      • Equation: $F_x = -\dfrac{dU(x)}{dx}$
    • 3.3.A.6 Graphs of a system's potential energy as a function of its position can be useful in determining physical properties of that system.
      • 3.3.A.6.i Stable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object opposite to the direction of the small displacement, accelerating the object back toward the equilibrium position.
      • 3.3.A.6.ii Unstable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object in the same direction as the small displacement, accelerating the object away from the equilibrium position.
      • 3.3.A.6.iii In a given dimension, stable equilibrium positions exist at locations where the potential energy as a function of position in that dimension has a local minimum.
      • 3.3.A.6.iv In a given dimension, unstable equilibrium positions occur at locations where the potential energy as a function of position in that dimension has a local maximum.
    • 3.3.A.7 The potential energy of common physical systems can be described using the physical properties of that system.
      • 3.3.A.7.i The elastic potential energy of an ideal spring is given by the following equation, where $\Delta x$ is the distance the spring has been stretched or compressed from its equilibrium length.
        • Equation: $U_s = \dfrac{1}{2}k(\Delta x)^2$
      • 3.3.A.7.ii The general form for the gravitational potential energy of a system consisting of two approximately spherical distributions of mass (e.g., moons, planets, or stars) is given by the equation
        • Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
      • 3.3.A.7.iii Because the gravitational field near the surface of a planet is nearly constant, the change in gravitational potential energy in a system consisting of an object with mass $m$ and a planet with gravitational field of magnitude $g$ when the object is near the surface of the planet may be approximated by the equation
        • Equation: $\Delta U_g = mg\Delta y$
    • 3.3.A.8 The total potential energy of a system containing more than two objects is the sum of the potential energy of each pair of objects within the system.
    Русский

    Цель обучения 3.3.A: Описать потенциальную энергию системы.

    • 3.3.A.1 Система, состоящая из двух или более объектов, обладает потенциальной энергией, если объекты внутри этой системы взаимодействуют друг с другом только через консервативные силы.
    • 3.3.A.2 Потенциальная энергия — это скалярная величина, связанная с положением объектов в системе.
    • 3.3.A.3 Определение нуля потенциальной энергии для данной системы — это решение, принимаемое наблюдателем, рассматривающим ситуацию, для упрощения или иным образом содействия анализу.
    • 3.3.A.4 Связь между консервативными силами, действующими на систему, и потенциальной энергией системы такова:
      • Уравнение: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
    • 3.3.A.5 Консервативные силы, действующие на систему в одном измерении, могут быть определены с помощью наклона потенциальной энергии системы по положению в этом измерении; эти силы направлены в сторону уменьшения потенциальной энергии.
      • Уравнение: $F_x = -\dfrac{dU(x)}{dx}$
    • 3.3.A.6 Графики потенциальной энергии системы как функции ее положения могут быть полезны для определения физических свойств этой системы.
      • 3.3.A.6.i Устойчивое равновесие — это положение, при котором малое смещение объекта вызывает силу, действующую на него в направлении, противоположном малому смещению, ускоряющую объект обратно к положению равновесия.
      • 3.3.A.6.ii Неустойчивое равновесие — это положение, при котором малое смещение объекта вызывает силу, действующую на него в том же направлении, что и малое смещение, ускоряющую объект прочь от положения равновесия.
      • 3.3.A.6.iii В данном измерении положения устойчивого равновесия существуют там, где потенциальная энергия как функция положения в этом измерении имеет локальный минимум.
      • 3.3.A.6.iv В данном измерении положения неустойчивого равновесия возникают там, где потенциальная энергия как функция положения в этом измерении имеет локальный максимум.
    • 3.3.A.7 Потенциальная энергия распространенных физических систем может быть описана с помощью физических свойств этой системы.
      • 3.3.A.7.i Потенциальная энергия упругости идеальной пружины задается следующим уравнением, где $\Delta x$ — расстояние, на которое пружина была растянута или сжата относительно своей длины в состоянии равновесия.
        • Уравнение: $U_s = \dfrac{1}{2}k(\Delta x)^2$
      • 3.3.A.7.ii Общий вид уравнения для гравитационной потенциальной энергии системы, состоящей из двух приблизительно сферических распределений массы (например, лун, планет или звезд), задается уравнением
        • Уравнение: $U_g = -G\dfrac{m_1 m_2}{r}$
      • 3.3.A.7.iii Поскольку гравитационное поле вблизи поверхности планеты почти постоянно, изменение гравитационной потенциальной энергии в системе, состоящей из объекта массой $m$ и планеты с гравитационным полем модуля $g$, когда объект находится вблизи поверхности планеты, может быть приближенно задано уравнением
        • Уравнение: $\Delta U_g = mg\Delta y$
    • 3.3.A.8 Полная потенциальная энергия системы, содержащей более двух объектов, равна сумме потенциальных энергий каждой пары объектов внутри системы.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Potential energy 势能 is energy a system stores by the positions of its parts – it exists only for conservative forces 保守力, whose work is path independent. It is defined through work:

    $$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$

    and you are free to choose where $U=0$ – only changes in $U$ matter, so pick the zero that makes the problem simplest. The standard results:

    • Gravity near a surface: $\Delta U_g=mg\,\Delta y$.
    • Gravity in general: $U_g=-\dfrac{Gm_1m_2}{r}$ (zero at infinite separation).
    • Spring: $U_s=\tfrac12k(\Delta x)^2$, with $\Delta x$ measured from natural length.

    For systems of several objects, add the potential energy of each pair. Turning the definition around, a conservative force is minus the derivative 导数 of its potential energy:

    $$F_x=-\frac{dU}{dx}.$$

    The force points "downhill" on the $U(x)$ curve. Equilibrium sits where the slope is zero: a minimum is a stable equilibrium 稳定平衡 (displaced, the force pushes back), a maximum is an unstable equilibrium 不稳定平衡 (displaced, the force pushes away).

    Worked example. Given $U(x)=2x^3-6x$ (joules), the force is $F=-\dfrac{dU}{dx}=6-6x^2$. Equilibria sit at $F=0$: $x=\pm1$. Since $\dfrac{d^2U}{dx^2}=12x$ is positive at $x=+1$ (a minimum – stable) and negative at $x=-1$ (a maximum – unstable), the two points behave oppositely.

    Русский

    Потенциальная энергия — это энергия, которую система накапливает за счет положения своих частей — она существует только для консервативных сил, работа которых не зависит от пути. Она определяется через работу:

    $$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$

    и вы можете свободно выбрать, где $U=0$ — важны только изменения в $U$, поэтому выбирайте ноль там, где решение задачи становится проще всего. Стандартные результаты:

    • Гравитация вблизи поверхности: $\Delta U_g=mg\,\Delta y$.
    • Гравитация в общем случае: $U_g=-\dfrac{Gm_1m_2}{r}$ (ноль на бесконечном удалении).
    • Пружина: $U_s=\tfrac12k(\Delta x)^2$, где $\Delta x$ измеряется от естественной длины.

    Для систем из нескольких объектов сложите потенциальную энергию каждой пары. Перевернув определение, консервативную силу можно выразить как минус производную её потенциальной энергии:

    $$F_x=-\frac{dU}{dx}.$$

    Сила направлена «вниз» по склону кривой $U(x)$. Равновесие находится там, где наклон равен нулю: минимум — это устойчивое равновесие (при смещении сила возвращает обратно), максимум — неустойчивое равновесие (при смещении сила удаляет дальше).

    На кривой потенциальной энергии сила направлена «в гору» вниз, а E = U обозначает точки разворота
    На кривой потенциальной энергии сила направлена вниз, а E = U обозначает точки разворота

    Разобранная задача. Зная $U(x)=2x^3-6x$ (джоули), сила равна $F=-\dfrac{dU}{dx}=6-6x^2$. Точки равновесия находятся при $F=0$: $x=\pm1$. Поскольку $\dfrac{d^2U}{dx^2}=12x$ положительна при $x=+1$ (минимум — устойчиво) и отрицательна при $x=-1$ (максимум — неустойчиво), эти две точки ведут себя противоположным образом.

    Explore · ⁨Исследовать⁩

    Store elastic potential energy in a spring · ⁨Сохранить упругую потенциальную энергию в пружине⁩

    Stretching a spring stores elastic potential energy $\tfrac12 kx^2$ — the area under the force-extension line. Release it and that energy becomes kinetic. · ⁨Растяжение пружины накапливает упругую потенциальную энергию $\tfrac12 kx^2$ — площадь под графиком зависимости силы от удлинения. Освободите её, и эта энергия превратится в кинетическую.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Potential energy/pəˈtenʃl ˈenədʒi/ Потенциальная энергия
    conservative forces/kənˈsɜːvətɪv ˈfɔːsɪz/ консервативные силы
    derivative/dɪˈrɪvətɪv/ производной
    stable equilibrium/ˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ устойчивого равновесия
    unstable equilibrium/ʌnˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ неустойчивого равновесия
    Mechanical energy/mɪˈkænɪkl ˈenədʒi/ Механическая энергия
    nonconservative forces/ˌnɒŋkənˈsɜːvətɪv ˈfɔːsɪz/ неконсервативные силы
    thermal energy/ˈθɜːml ˈenədʒi/ тепловую энергию
    turning points/ˈtɜːnɪŋ pɔɪnts/ точки разворота
    3.4

    Conservation of Energy · ⁨Сохранение энергии⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 3.4.A: Describe the energies present in a system.

    • 3.4.A.1 A system composed of only a single object can only have kinetic energy.
    • 3.4.A.2 A system that contains objects that interact via conservative forces or that can change its shape reversibly may have both kinetic and potential energies.

    Learning Objective 3.4.B: Describe the behavior of a system using conservation of mechanical energy principles.

    • 3.4.B.1 Mechanical energy is the sum of a system's kinetic and potential energies.
    • 3.4.B.2 Any change to a type of energy within a system must be balanced by an equivalent change of other types of energies within the system or by a transfer of energy between the system and its surroundings.
    • 3.4.B.3 A system may be selected so that the total energy of that system is constant.
    • 3.4.B.4 If the total energy of a system changes, that change will be equivalent to the energy transferred into or out of the system.

    Learning Objective 3.4.C: Describe how the selection of a system determines whether the energy of that system changes.

    • 3.4.C.1 Energy is conserved in all interactions.
    • 3.4.C.2 If the work done on a selected system is zero and there are no nonconservative interactions within the system, the total mechanical energy of the system is constant.
    • 3.4.C.3 If the work done on a selected system is nonzero, energy is transferred between the system and the environment.

    Boundary statement: AP Physics C: Mechanics expects students to know that mechanical energy can be dissipated as thermal energy or sound by nonconservative forces.

    Русский

    Цель обучения 3.4.A: Описать энергии, присутствующие в системе.

    • 3.4.A.1 Система, состоящая только из одного объекта, может иметь только кинетическую энергию.
    • 3.4.A.2 Система, содержащая объекты, взаимодействующие через консервативные силы, или способная обратимо изменять свою форму, может иметь как кинетическую, так и потенциальную энергии.

    Цель обучения 3.4.B: Описать поведение системы, используя принципы сохранения механической энергии.

    • 3.4.B.1 Механическая энергия — это сумма кинетической и потенциальной энергии системы.
    • 3.4.B.2 Любое изменение вида энергии внутри системы должно компенсироваться эквивалентным изменением других видов энергии в системе или передачей энергии между системой и окружающей средой.
    • 3.4.B.3 Можно выбрать систему так, чтобы полная энергия этой системы оставалась постоянной.
    • 3.4.B.4 Если полная энергия системы изменяется, это изменение равно энергии, переданной в систему или выведенной из нее.

    Цель обучения 3.4.C: Описать, как выбор системы определяет, изменяется ли энергия этой системы.

    • 3.4.C.1 Энергия сохраняется во всех взаимодействиях.
    • 3.4.C.2 Если работа, совершенная над выбранной системой, равна нулю, а внутри системы нет неконсервативных взаимодействий, то полная механическая энергия системы постоянна.
    • 3.4.C.3 Если работа, совершенная над выбранной системой, отлична от нуля, энергия передается между системой и окружением.

    Граничное утверждение: AP Physics C: Mechanics ожидает, что студенты будут знать, что механическая энергия может рассеиваться как тепловая энергия или звук под действием неконсервативных сил.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English
    Energy conservation: KE ⇄ PE

    Energy is conserved in all interactions – the question is only where it goes. Mechanical energy 机械能 is the sum $E=K+U$. If the external work on a system is zero and nothing inside it acts through nonconservative forces 非保守力, then

    $$K_1+U_1=K_2+U_2.$$

    When friction or drag act, they convert mechanical energy into thermal energy 热能 ($\Delta E_{\text{mech}}=-F_fd$), and the balance must include that term. If external work is done, the system's total energy changes by exactly the energy transferred: $W_{\text{ext}}=\Delta E_{\text{sys}}$. Choosing the system is choosing the bookkeeping – a single object can only have kinetic energy; include the Earth or the spring and the system can store potential energy too.

    A potential-energy graph is a complete motion map: the horizontal line at height $E$ is the total energy, the gap $E-U(x)$ is the kinetic energy at each $x$, and the crossings $E=U$ are the turning points 转折点 where the object momentarily stops and reverses.

    Worked example. A $2.0\ \text{kg}$ block slides down a ramp from rest at height $1.5\ \text{m}$, arriving at the bottom at $4.0\ \text{m/s}$. Energy accounting: $mgh=29.4\ \text{J}$ available; $\tfrac12mv^2=16\ \text{J}$ arrives as kinetic energy; so friction converted $29.4-16=13\ \text{J}$ into thermal energy along the way.

    Русский
    Сохранение энергии: KE ⇄ PE

    Энергия сохраняется во всех взаимодействиях — вопрос лишь в том, куда она переходит. Механическая энергия — это сумма $E=K+U$. Если внешняя работа над системой равна нулю и внутри неё не действуют неконсервативные силы, то

    $$K_1+U_1=K_2+U_2.$$

    Когда действуют трение или сопротивление, они превращают механическую энергию в тепловую энергию ($\Delta E_{\text{mech}}=-F_fd$), и баланс должен включать этот член. Если внешняя работа совершается, полная энергия системы изменяется точно на переданную энергию: $W_{\text{ext}}=\Delta E_{\text{sys}}$. Выбор системы — это выбор бухгалтерского учета — одно тело может иметь только кинетическую энергию; включите Землю или пружину, и система сможет также накапливать потенциальную энергию.

    Маятник обменивается гравитационной потенциальной энергией на кинетическую и обратно
    Маятник обменивается гравитационной потенциальной энергией на кинетическую и обратно

    График потенциальной энергии представляет собой полную карту движения: горизонтальная линия на высоте $E$ — это полная энергия, зазор $E-U(x)$ — кинетическая энергия в каждой точке $x$, а пересечения $E=U$ — это точки поворота, где тело на мгновение останавливается и меняет направление.

    Разобранная задача. Блок массой $2.0\ \text{kg}$ скользит с поверхности наклонной плоскости из состояния покоя с высоты $1.5\ \text{m}$, достигая дна со скоростью $4.0\ \text{m/s}$. Энергетический баланс: доступно $mgh=29.4\ \text{J}$ потенциальной энергии; к основанию приходит кинетическая энергия в размере $\tfrac12mv^2=16\ \text{J}$; следовательно, трение превратило в тепловую энергию на пути вниз величину $29.4-16=13\ \text{J}$.

    Аттрацион «горки» обменивается энергией туда-обратно: максимальная (наибольшая PE) на вершине, максимальная скорость (наибольшая KE) на дне
    Аттрацион «горки» обменивается энергией туда-обратно: максимальная (наибольшая PE) на вершине, максимальная скорость (наибольшая KE) на дне
    Explore · ⁨Исследовать⁩

    Watch energy convert as an object falls · ⁨Наблюдать за преобразованием энергии при падении объекта⁩

    With no friction, mechanical energy is conserved: as an object falls, gravitational potential energy turns into kinetic energy while the total stays fixed. · ⁨При отсутствии трения механическая энергия сохраняется: при падении объекта гравитационная потенциальная энергия превращается в кинетическую, тогда как общая остается неизменной.⁩

    Watch lesson · ⁨Смотреть урок⁩
    3.5

    Power · ⁨Мощность⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 3.5.A: Describe the transfer of energy into, out of, or within a system in terms of power.

    • 3.5.A.1 Power is the rate at which energy changes with respect to time, either by transfer into or out of a system or by conversion from one type to another within a system.
    • 3.5.A.2 Average power is the amount of energy being transferred or converted, divided by the time it took for that transfer or conversion to occur.
      • Equation: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
    • 3.5.A.3 Because work is the change in energy of an object or system due to a force, average power is the total work done, divided by the time during which that work was done.
      • Equation: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
    • 3.5.A.4 The instantaneous power delivered to an object by a force is given by the equation
      • Equation: $P_{\text{inst}} = \dfrac{dW}{dt}$
    • 3.5.A.5 The instantaneous power delivered to an object by the component of a constant force parallel to the object's velocity can be described with the derived equation
      • Equation: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$
    Русский

    Цель обучения 3.5.A: Описать перенос энергии внутрь системы, из системы или внутри системы через понятие мощности.

    • 3.5.A.1 Мощность — это скорость изменения энергии по времени, будь то перенос энергии в систему или из нее, либо преобразование одного вида энергии в другой внутри системы.
    • 3.5.A.2 Средняя мощность — это количество переданной или преобразованной энергии, деленное на время, за которое произошло этот перенос или преобразование.
      • Уравнение: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
    • 3.5.A.3 Поскольку работа представляет собой изменение энергии объекта или системы под действием силы, средняя мощность равна полной совершенной работе, деленной на время выполнения этой работы.
      • Уравнение: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
    • 3.5.A.4 Мгновенная мощность, передаваемая объекту силой, задается уравнением
      • Уравнение: $P_{\text{inst}} = \dfrac{dW}{dt}$
    • 3.5.A.5 Мгновенная мощность, передаваемая объекту составляющей постоянной силы, параллельной скорости объекта, может быть описана с помощью выведенного уравнения
      • Уравнение: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Power 功率 is the rate of energy transfer, in watts 瓦特 (W):

    $$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$

    It measures how fast work is done, not how much. The dot product matters: only the force component along the velocity delivers power.

    Worked example. A block released from rest at the top of a frictionless $3.0\ \text{m}$-high ramp reaches the bottom at $v=\sqrt{2gh}=7.7\ \text{m/s}$ (from $mgh=\tfrac12mv^2$). A motor that then drives it at a steady $7.7\ \text{m/s}$ against a $20\ \text{N}$ resistance delivers $P=Fv=20(7.7)\approx150\ \text{W}$.

    Worked example. A $1200\ \text{kg}$ car climbs a hill that rises $1.0\ \text{m}$ for every $20\ \text{m}$ of road, at a steady $15\ \text{m/s}$. The engine must supply gravity's power drain: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ – before adding air resistance.

    Exam skill. Energy FRQs reward the accounting sentence: name your system, state which forces do work on it, and write the balance ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$) before plugging in numbers. "Friction is present, so mechanical energy is not conserved" is a scored statement.

    Русский

    Мощность — это скорость передачи энергии, измеряется в ваттах (Вт):

    $$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$

    Она показывает, как быстро совершается работа, а не её объём. Важно скалярное произведение: только компонента силы вдоль скорости создаёт мощность.

    Мощность — это наклон графика зависимости работы от времени: одна и та же работа за меньшее время означает большую мощность
    Мощность — это наклон графика зависимости работы от времени: одна и та же работа за меньшее время означает большую мощность

    Разобранный пример. Блок, отпущенный из состояния покоя с вершины рампы высотой $3.0\ \text{m}$ без трения, достигает дна со скоростью $v=\sqrt{2gh}=7.7\ \text{m/s}$ (из уравнения $mgh=\tfrac12mv^2$). Мотор, который затем приводит его в движение с постоянной скоростью $7.7\ \text{m/s}$ против сопротивления $20\ \text{N}$, развивает мощность $P=Fv=20(7.7)\approx150\ \text{W}$.

    Разобранный пример. Автомобиль массой $1200\ \text{kg}$ поднимается по холму, который поднимается на $1.0\ \text{m}$ каждые $20\ \text{m}$ дороги, с постоянной скоростью $15\ \text{m/s}$. Двигатель должен компенсировать мощность, расходуемую на преодоление гравитации: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ — до учёта сопротивления воздуха.

    Навык для экзамена. Развёрнутые вопросы по энергии (FRQ) оценивают предложение-учёт: назовите свою систему, укажите, какие силы совершают работу над ней, и запишите баланс ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$), прежде чем подставлять числа. Фраза «Присутствует трение, поэтому механическая энергия не сохраняется» является оценочным утверждением.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Power/ˈpaʊə/ Мощность
    watts/wɒts/ ваттах
    3.5

    Exam tips · ⁨Советы для экзамена⁩

    English
    • Use the work–energy theorem $W_{net}=\Delta KE$ and compute work as $W=\int \vec F\cdot d\vec r$ for a variable force.
    • Read work off a force–position graph as the area under the curve.
    • Power is $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$; watch instantaneous vs average.
    • Split forces into conservative (define a potential energy) and non-conservative (dissipate energy).
    • Choose energy methods over kinematics when the force varies or the path is complex.
    Русский
    • Используйте теорему о работе и кинетической энергии $W_{net}=\Delta KE$ и вычисляйте работу как $W=\int \vec F\cdot d\vec r$ для переменной силы.
    • Определяйте работу по графику силы–положения как площадь под кривой.
    • Мощность равна $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$; следите за мгновенной и средней мощностью.
    • Разделите силы на консервативные (определите потенциальную энергию) и неконсервативные (рассеивающие энергию).
    • Выбирайте методы энергии вместо кинематики, когда сила изменяется или траектория сложна.
  • 4

    Linear Momentum · ⁨Импульс⁩

    Watch lesson · ⁨Смотреть урок⁩
    4.1

    Linear Momentum · ⁨Линейный импульс⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 4.1.A: Describe the linear momentum of an object or system.

    • 4.1.A.1 Linear momentum is defined by the equation $\vec{p} = m\vec{v}$.
    • 4.1.A.2 Momentum is a vector quantity and has the same direction as the velocity.
    • 4.1.A.3 Momentum can be used to analyze collisions and explosions.
      • 4.1.A.3.i A collision is a model for an interaction where the forces exerted between the involved objects in the system are much larger than the net external force exerted on those objects during the interaction.
      • 4.1.A.3.ii As only the initial and final states of a collision are analyzed, the object model may be used to analyze collisions.
      • 4.1.A.3.iii An explosion is a model for an interaction in which forces internal to the system move objects within that system apart.
    Русский

    Цель обучения 4.1.A: Описать линейный импульс объекта или системы.

    • 4.1.A.1 Линейный импульс определяется уравнением $\vec{p} = m\vec{v}$.
    • 4.1.A.2 Импульс является векторной величиной и направлен туда же, куда и скорость.
    • 4.1.A.3 Импульс можно использовать для анализа столкновений и взрывов.
      • 4.1.A.3.i Столкновение — это модель взаимодействия, при котором силы, действующие между вовлеченными объектами системы, значительно больше результирующей внешней силы, действующей на эти объекты во время взаимодействия.
      • 4.1.A.3.ii Поскольку анализируются только начальное и конечное состояния столкновения, для их анализа может использоваться модель точечного объекта.
      • 4.1.A.3.iii Взрыв — это модель взаимодействия, при котором внутренние силы системы раздвигают объекты внутри этой системы.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Linear momentum 动量 is mass times velocity:

    $$\vec{p}=m\vec{v}.$$

    It is a vector 矢量 pointing along the velocity, and it is the quantity for analysing collisions 碰撞 and explosions 爆炸. A collection of objects can be treated as one system moving with the velocity of its center of mass 质心:

    $$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$

    so the system's total momentum is its total mass times $\vec{v}_{\text{cm}}$ – one object's worth of bookkeeping for any number of parts.

    Русский

    Линейный импульс равен массе, умноженной на скорость:

    $$\vec{p}=m\vec{v}.$$

    Это вектор, направленный вдоль скорости, и он является основной величиной для анализа столкновений и взрывов. Совокупность тел можно рассматривать как одну систему, движущуюся со скоростью её центра масс:

    $$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$

    поэтому полный импульс системы равен её общей массе, умноженной на $\vec{v}_{\text{cm}}$ — одна строка бухгалтерского учёта для любого количества частей.

    4.2

    Change in Momentum and Impulse · ⁨Изменение импульса и импульс силы⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 4.2.A: Describe the impulse delivered to an object or system.

    • 4.2.A.1 The rate of change of a system's momentum is equal to the net external force exerted on that system.
      • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
    • 4.2.A.2 Impulse is defined as the integral of a force exerted on an object or system over a time interval.
      • Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
    • 4.2.A.3 Impulse is a vector quantity and has the same direction as the net force exerted on the system.
    • 4.2.A.4 The impulse delivered to a system by a net external force is equal to the area under the curve of a graph of the net external force exerted on the system as a function of time.
    • 4.2.A.5 The net external force exerted on a system is equal to the slope of a graph of the momentum of the system as a function of time.

    Learning Objective 4.2.B: Describe the relationship between the impulse exerted on an object or system and the change in momentum of the object or system.

    • 4.2.B.1 Change in momentum is the difference between a system's final momentum and its initial momentum.
      • Equation: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
    • 4.2.B.2 The impulse–momentum theorem relates the impulse delivered to an object and the object's change in momentum.
      • 4.2.B.2.i The impulse exerted on an object is equal to the object's change in momentum.
        • Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
      • 4.2.B.2.ii Newton's second law of motion is a direct result of the impulse–momentum theorem applied to systems with constant mass.
        • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
      • 4.2.B.2.iii The impulse–momentum theorem also describes the behavior of a system in which the velocity is constant but the mass changes with respect to time.
        • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$
    Русский

    Цель обучения 4.2.A: Описать импульс силы, переданный объекту или системе.

    • 4.2.A.1 Скорость изменения импульса системы равна равнодействующей внешней силе, действующей на эту систему.
      • Уравнение: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
    • 4.2.A.2 Импульс силы определяется как интеграл от силы, действующей на тело или систему, по временному интервалу.
      • Уравнение: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
    • 4.2.A.3 Импульс силы является векторной величиной и направлен туда же, куда и результирующая сила, действующая на систему.
    • 4.2.A.4 Импульс силы, переданный системе результирующей внешней силой, равен площади под кривой графика зависимости результирующей внешней силы, действующей на систему, от времени.
    • 4.2.A.5 Результирующая внешняя сила, действующая на систему, равна наклону графика зависимости импульса системы от времени.

    Цель обучения 4.2.B: Описать связь между импульсом силы, действующим на тело или систему, и изменением импульса этого тела или системы.

    • 4.2.B.1 Изменение импульса — это разница между конечным импульсом системы и ее начальным импульсом.
      • Уравнение: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
    • 4.2.B.2 Теорема об импульсе и моменте связывает импульс силы, переданный телу, и изменение его импульса.
      • 4.2.B.2.i Импульс силы, действующий на тело, равен изменению импульса этого тела.
        • Уравнение: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
      • 4.2.B.2.ii Второй закон Ньютона является прямым следствием теоремы об импульсе и моменте, примененной к системам с постоянной массой.
        • Уравнение: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
      • 4.2.B.2.iii Теорема об импульсе и моменте также описывает поведение системы, в которой скорость постоянна, но масса изменяется со временем.
        • Уравнение: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Newton's second law is really a statement about momentum:

    $$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$

    which reduces to $m\vec{a}$ when the mass is constant – and handles a changing mass when it is not (the special case $\vec{F}=\dfrac{dm}{dt}\vec{v}$ holds only when the velocity is constant, e.g. a chain piling onto a scale or sand landing on a belt moving at fixed speed; a rocket does not fit, since it accelerates). The impulse 冲量 delivered by a force is its time integral, and the impulse–momentum theorem 冲量-动量定理 says it equals the change in momentum:

    $$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$

    Impulse is a vector along the net force. Read it off graphs both ways:

    • On a force–time graph, impulse is the area under the curve.
    • On a momentum–time graph, the net force is the slope 斜率 at each instant.

    Spreading the same $\Delta p$ over a longer time lowers the force – that is why airbags, crumple zones, and soft landings work, and why you bend your knees when you land.

    Worked example. A time-varying force $F(t)=10t\ \text{N}$ acts on a $2.0\ \text{kg}$ object for $2.0\ \text{s}$. The impulse is $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, so the speed changes by $\Delta v=J/m=10\ \text{m/s}$.

    Русский

    Второй закон Ньютона на самом деле является утверждением об импульсе:

    $$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$

    который упрощается до $m\vec{a}$ при постоянной массе – и обрабатывает изменяющуюся массу, если она такова (частный случай $\vec{F}=\dfrac{dm}{dt}\vec{v}$ справедлив только при постоянной скорости, например, цепь, сваливающаяся на весы, или песок, падающий на ленту, движущуюся с постоянной скоростью; ракета сюда не подходит, так как она ускоряется). Импульс силы — это её интеграл по времени, а теорема об импульсе и импульсе движения гласит, что он равен изменению импульса:

    $$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$

    Импульс — это вектор вдоль равнодействующей силы. Считывайте его с графиков двумя способами:

    • На графике силы–времени импульс равен площади под кривой.
    • На графике импульса–времени равнодействующая сила равна наклону в каждый момент.
    Импульс силы — это площадь под кривой зависимости силы от времени, равная среднему значению силы, умноженному на время контакта
    Импульс силы — это площадь под кривой зависимости силы от времени, равная среднему значению силы, умноженному на время контакта

    Растягивание одного и того же $\Delta p$ на более длительный срок снижает силу – именно поэтому работают подушки безопасности, зоны деформации и мягкие посадки, а также почему мы сгибаем колени при приземлении.

    Разобранный пример. Переменная по времени сила $F(t)=10t\ \text{N}$ действует на объект массой $2.0\ \text{kg}$ в течение $2.0\ \text{s}$. Импульс составляет $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, поэтому скорость изменяется на $\Delta v=J/m=10\ \text{m/s}$.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Linear momentum/ˈlɪnɪə məʊˈmentəm/ Линейный импульс
    vector/ˈvektə/ векторное
    collisions/kəˈlɪʒnz/ соударения
    explosions/ekˈspləʊʒnz/ взрывы
    center of mass/ˈsentə ɒv mæs/ центр масс
    impulse/ˈɪmpʌls/ импульс
    impulse–momentum theorem/ˈɪmpʌls məʊˈmentəm ˈθɪərəm/ теорема об импульсе и моменте
    slope/sləʊp/ наклоне графика
    conserved/kənˈsɜːvd/ сохраняемым
    kinetic energy/kɪˈnetɪk ˈenədʒi/ кинетическую энергию
    elastic collision/ɪˈlæstɪk kəˈlɪʒn/ упругое столкновение
    inelastic collision/ɪnɪˈlæstɪk kəˈlɪʒn/ неупругое столкновение
    deformation/ˌdiːfɔːˈmeɪʃn/ деформация
    perfectly inelastic collision/ˈpɜːfektlɪ ɪnɪˈlæstɪk kəˈlɪʒn/ абсолютно неупругое столкновение
    4.3

    Conservation of Linear Momentum · ⁨Закон сохранения линейного импульса⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 4.3.A: Describe the behavior of a system using conservation of linear momentum.

    • 4.3.A.1 A collection of objects with individual momenta can be described as one system with one center-of-mass velocity.
      • 4.3.A.1.i For a collection of objects, the velocity of a system's center of mass can be calculated using the equation
        • Equation: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
      • 4.3.A.1.ii The velocity of a system's center of mass is constant in the absence of a net external force.
    • 4.3.A.2 The total momentum of a system is the sum of the momenta of the system's constituent parts.
    • 4.3.A.3 In the absence of net external forces, any change to the momentum of an object within a system must be balanced by an equivalent and opposite change of momentum elsewhere within the system. Any change to the momentum of a system is due to a transfer of momentum between the system and its surroundings.
      • 4.3.A.3.i The impulse exerted by one object on a second object is equal and opposite to the impulse exerted by the second object on the first. This is a direct result of Newton's third law.
      • 4.3.A.3.ii A system may be selected so that the total momentum of that system is constant.
      • 4.3.A.3.iii If the total momentum of a system changes, that change will be equivalent to the impulse exerted on the system.
        • Equation: $\vec{J} = \Delta\vec{p}$
    • 4.3.A.4 Correct application of conservation of momentum can be used to determine the velocity of a system immediately before and immediately after collisions or explosions.

    Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze collisions and interactions in one or two dimensions. Three-dimensional collisions may be analyzed qualitatively.

    Learning Objective 4.3.B: Describe how the selection of a system determines whether the momentum of that system changes.

    • 4.3.B.1 Momentum is conserved in all interactions.
    • 4.3.B.2 If the net external force on the selected system is zero, the total momentum of the system is constant.
    • 4.3.B.3 If the net external force on the selected system is nonzero, momentum is transferred between the system and the environment.
    Русский

    Цель обучения 4.3.A: Описать поведение системы, используя закон сохранения линейного импульса.

    • 4.3.A.1 Совоность объектов с индивидуальными импульсами можно описать как одну систему с одной скоростью центра масс.
      • 4.3.A.1.i Для совокупности объектов скорость центра масс системы можно вычислить, используя следующее уравнение
        • Уравнение: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
      • 4.3.A.1.ii Скорость центра массы системы постоянна при отсутствии результирующей внешней силы.
    • 4.3.A.2 Полный импульс системы равен сумме импульсов составляющих систему частей.
    • 4.3.A.3 При отсутствии результирующих внешних сил любое изменение импульса объекта внутри системы должно компенсироваться эквивалентным и противоположным изменением импульса в другом месте системы. Любое изменение импульса системы обусловлено передачей импульса между системой и окружающей средой.
      • 4.3.A.3.i Импульс силы, оказываемый одним объектом на второй, равен по модулю и противоположен по направлению импульсу силы, оказываемому вторым объектом на первый. Это прямое следствие третьего закона Ньютона.
      • 4.3.A.3.ii Система может быть выбрана таким образом, чтобы полный импульс этой системы оставался постоянным.
      • 4.3.A.3.iii Если полный импульс системы изменяется, это изменение эквивалентно импульсу силы, действующему на систему.
        • Уравнение: $\vec{J} = \Delta\vec{p}$
    • 4.3.A.4 Правильное применение закона сохранения импульса позволяет определить скорость системы непосредственно до и непосредственно после столкновений или взрывов.

    Граничное условие: AP Physics C: Механика требует от студентов только количественного анализа столкновений и взаимодействий в одном или двух измерениях. Трехмерные столкновения могут рассматриваться качественно.

    Цель обучения 4.3.B: Описать, как выбор системы определяет, изменяется ли импульс этой системы.

    • 4.3.B.1 Импульс сохраняется во всех взаимодействиях.
    • 4.3.B.2 Если результирующая внешняя сила, действующая на выбранную систему, равна нулю, полный импульс системы остается постоянным.
    • 4.3.B.3 Если результирующая внешняя сила, действующая на выбранную систему, не равна нулю, происходит перенос импульса между системой и окружающей средой.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Internal forces come in Newton's-third-law pairs, so they cancel inside any system: they can shuffle momentum between parts but never change the total. Momentum only enters or leaves a system through a net external force ($\vec{J}=\Delta\vec{p}$). So, with zero net external force, total momentum is conserved 守恒:

    $$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$

    Momentum is conserved in every collision, however violent – choose the system large enough that the collision forces are internal. Apply conservation separately along each axis; AP asks for quantitative work in one or two dimensions.

    Worked example (explosion). A $6.0\ \text{kg}$ shell at rest splits into a $2.0\ \text{kg}$ piece moving at $9.0\ \text{m/s}$ east and a $4.0\ \text{kg}$ piece. Total momentum stays zero, so the heavy piece moves west at $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. The kinetic energy came from stored (chemical or spring) energy – momentum conservation does not require kinetic-energy conservation.

    Русский

    Внутренние силы образуют пары по третьему закону Ньютона, поэтому они компенсируют друг друга внутри любой системы: они могут перераспределять импульс между частями, но никогда не изменят общий. Импульс входит в систему или выходит из неё только через результирующую внешнюю силу ($\vec{J}=\Delta\vec{p}$). Таким образом, при нулевой результирующей внешней силе полный импульс сохраняется:

    $$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$

    Импульс сохраняется в любом столкновении, каким бы жестким оно ни было – выбирайте систему достаточно большой, чтобы силы столкновения были внутренними. Применяйте сохранение отдельно по каждой оси; AP требует количественных расчетов в одном или двух измерениях.

    Удар в лоб: суммарный импульс до столкновения равен суммарному импульсу после столкновения
    Удар в лоб: суммарный импульс до столкновения равен суммарному импульсу после столкновения

    Разобранный пример (взрыв). Оболочка массой $6.0\ \text{kg}$, покоящаяся, распадается на кусок массой $2.0\ \text{kg}$, движущийся со скоростью $9.0\ \text{m/s}$ на восток, и кусок массой $4.0\ \text{kg}$. Полный импульс остается равным нулю, поэтому тяжелый кусок движется на запад со скоростью $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. Кинетическая энергия поступила из запасенной (химической или пружинной) энергии — закон сохранения импульса не требует сохранения кинетической энергии.

    Explore · ⁨Исследовать⁩

    Collide two carts and conserve momentum · ⁨Столкните две тележки и сохраните импульс⁩

    In any collision the total momentum $\sum mv$ before equals the total after. Set the masses and speeds and check the momentum bookkeeping. · ⁨При любом столкновении полный импульс $\sum mv$ до него равен полному импульсу после. Задайте массы и скорости и проверьте баланс импульсов.⁩

    4.4

    Elastic and Inelastic Collisions · ⁨Упругие и неупругие столкновения⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 4.4.A: Describe whether an interaction between objects is elastic or inelastic.

    • 4.4.A.1 An elastic collision between objects is one in which the initial kinetic energy of the system is equal to the final kinetic energy of the system.
    • 4.4.A.2 In an elastic collision, the final kinetic energies of each of the objects within the system may be different from their initial kinetic energies.
    • 4.4.A.3 An inelastic collision between objects is one in which the total kinetic energy of the system decreases.
    • 4.4.A.4 In an inelastic collision, some of the initial kinetic energy is not restored to kinetic energy but is transformed by nonconservative forces into other forms of energy.
    • 4.4.A.5 In a perfectly inelastic collision, the objects stick together and move with the same velocity after the collision.
    Русский

    Цель обучения 4.4.A: Описать, является ли взаимодействие между объектами упругим или неупругим.

    • 4.4.A.1 Упругое столкновение между объектами — это такое, при котором начальная кинетическая энергия системы равна конечной кинетической энергии системы.
    • 4.4.A.2 При упругом столкновении конечные кинетические энергии каждого из объектов внутри системы могут отличаться от их начальных кинетических энергий.
    • 4.4.A.3 Неупругое столкновение между объектами — это такое, при котором полная кинетическая энергия системы уменьшается.
    • 4.4.A.4 При неупругом столкновении часть начальной кинетической энергии не восстанавливается в виде кинетической энергии, а преобразуется неконсервативными силами в другие формы энергии.
    • 4.4.A.5 При абсолютно неупругом столкновении объекты слипаются и движутся с одинаковой скоростью после столкновения.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English
    Conservation of momentum in a collision

    All collisions conserve momentum; they differ in what happens to the kinetic energy 动能:

    type momentum kinetic energy
    elastic collision 弹性碰撞 conserved total conserved (individual shares may change)
    inelastic collision 非弹性碰撞 conserved decreases – some becomes heat, sound, deformation 形变
    perfectly inelastic collision 完全非弹性碰撞 conserved largest possible loss – the objects stick and share one velocity

    Strategy: always write momentum conservation first; add the kinetic-energy equation only when the problem says "elastic". Two useful elastic facts: equal masses in a 1D elastic collision simply exchange velocities, and in the center-of-mass frame each object just reverses its velocity.

    Worked example. A $1000\ \text{kg}$ car at $20\ \text{m/s}$ strikes a stationary $1500\ \text{kg}$ car and they lock together – perfectly inelastic. Momentum: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Kinetic energy falls from $2.0\times10^5\ \text{J}$ to $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: about $60\%$ is lost, even though momentum is exactly conserved.

    Worked example (2D). A puck moving east at $4.0\ \text{m/s}$ strikes an identical puck at rest; after the glancing hit, one moves at $2.0\ \text{m/s}$ at $60^\circ$ north of east. Conserve each axis: east–west, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, so $v_x=3.0\ \text{m/s}$; north–south, $0=m(2.0)\sin60^\circ-mv_y$, so $v_y=1.7\ \text{m/s}$. The second puck moves at $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, about $30^\circ$ south of east.

    Exam skill. On FRQs, justify with the condition, not the slogan: "the net external force on the two-puck system is zero during the collision, so its total momentum is constant." If asked whether the collision is elastic, compute the kinetic energy before and after and compare – never assume.

    Русский
    Сохранение импульса при столкновении

    Все столкновения сохраняют импульс; они различаются тем, что происходит с кинетической энергией:

    тип импульс кинетическая энергия
    упругое столкновение сохраняется полная сохраняется (индивидуальные доли могут меняться)
    неупругое столкновение сохраняется уменьшается – часть переходит в тепло, звук, деформацию
    абсолютно неупругое столкновение сохраняется максимально возможная потеря – объекты слипаются и движутся с одной скоростью

    Стратегия: всегда сначала записывайте закон сохранения импульса; добавляйте уравнение кинетической энергии только тогда, когда в задаче сказано «упругое». Два полезных факта об упругих столкновениях: при столкновении тел одинаковой массы в 1D они просто меняются скоростями, а в системе отсчета центра масс каждый объект просто меняет направление своей скорости.

    Разобранный пример. Автомобиль массой $1000\ \text{kg}$ со скоростью $20\ \text{m/s}$ врезается в неподвижный автомобиль массой $1500\ \text{kg}$, и они сцепляются – абсолютно неупругое. Импульс: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Кинетическая энергия падает с $2.0\times10^5\ \text{J}$ до $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: около $60\%$ теряется, хотя импульс сохраняется полностью.

    Разобранный пример (2D). Шайба, движущаяся на восток со скоростью $4.0\ \text{m/s}$, ударяет идентичную шайбу в покое; после скользящего удара одна движется со скоростью $2.0\ \text{m/s}$ под углом $60^\circ$ к северу от востока. Сохраняем каждую ось: восток–запад, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, значит $v_x=3.0\ \text{m/s}$; север–юг, $0=m(2.0)\sin60^\circ-mv_y$, значит $v_y=1.7\ \text{m/s}$. Вторая шайба движется со скоростью $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, примерно под углом $30^\circ$ к югу от востока.

    Удар в упругом столкновении, разложенный вдоль двух перпендикулярных осей
    Удар в упругом столкновении, разложенный вдоль двух перпендикулярных осей

    Навык для экзамена. В вопросах с развернутым ответом (FRQ) обосновывайте через условие, а не через лозунг: «суммарная внешняя сила, действующая на систему из двух шайб, равна нулю во время столкновения, поэтому их полный импульс сохраняется». Если спрашивают, является ли столкновение упругим, вычислите кинетическую энергию до и после и сравните – никогда не делайте предположений без расчетов.

    Ньютонский колыбель: пять стальных шаров висят в ряд
    Коробка Ньютона демонстрирует передачу импульса и кинетической энергии при почти упругом столкновении
    Explore · ⁨Исследовать⁩

    Compare elastic and inelastic collisions · ⁨Сравните упругие и неупругие столкновения⁩

    Momentum is always conserved, but kinetic energy is only conserved in an elastic collision. In an inelastic one the carts stick and some energy becomes heat. · ⁨Импульс сохраняется всегда, но кинетическая энергия сохраняется только при упругом столкновении. При неупругом столкновении тележки слипаются, и часть энергии переходит в тепло.⁩

    4.4

    Exam tips · ⁨Советы для экзамена⁩

    English
    • Impulse equals the momentum change: $\vec J=\int \vec F\,dt=\Delta\vec p$, and it is the area under a force–time graph.
    • Momentum is conserved whenever the net external force is zero — always the go-to for collisions.
    • Distinguish elastic (kinetic energy conserved) from inelastic (kinetic energy decreases) collisions; in a perfectly inelastic collision the objects stick and move with one velocity.
    • Apply conservation to each component (x and y) separately in 2-D.
    • Connect to center of mass: total momentum $=M\vec v_{cm}$.
    Русский
    • Импульс силы равен изменению импульса: $\vec J=\int \vec F\,dt=\Delta\vec p$, и он представляет собой площадь под графиком зависимости силы от времени.
    • Импульс сохраняется всегда, когда суммарная внешняя сила равна нулю — это универсальный подход для анализа столкновений.
    • Различайте упругие столкновения (сохраняется кинетическая энергия) и неупругие (кинетическая энергия уменьшается); в абсолютно неупругом столкновении тела слипаются и движутся с одной скоростью.
    • Примените закон сохранения к каждому компоненту (x и y) отдельно в 2-D.
    • Связь с центром масс: полный импульс $=M\vec v_{cm}$.
  • 5

    Torque and Rotational Dynamics · ⁨Момент силы и вращательная динамика⁩

    Watch lesson · ⁨Смотреть урок⁩
    5.1

    Rotational Kinematics

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 5.1.A: Describe the rotation of a system with respect to time using angular displacement, angular velocity, and angular acceleration.

    • 5.1.A.1 Angular displacement is the measurement of the angle, in radians, through which a point on a rigid system rotates about a specified axis.
      • Equation: $\Delta\theta = \theta - \theta_0$
      • 5.1.A.1.i A rigid system is one that holds its shape but in which different points on the system move in different directions during rotation. A rigid system cannot be modeled as an object.
      • 5.1.A.1.ii One direction of angular displacement about an axis of rotation—clockwise or counterclockwise—is typically indicated as mathematically positive, with the other direction becoming mathematically negative.
      • 5.1.A.1.iii If the rotation of a system about an axis may be well described using the motion of the system's center of mass, the system may be treated as a single object. For example, the rotation of Earth about its axis may be considered negligible when considering the revolution of Earth about the center of mass of the Earth–Sun system.
    • 5.1.A.2 Angular velocity is the rate at which angular position changes with respect to time.
      • Equation: $\omega = \dfrac{d\theta}{dt}$
    • 5.1.A.3 Angular acceleration is the rate at which angular velocity changes with respect to time.
      • Equation: $\alpha = \dfrac{d\omega}{dt}$
    • 5.1.A.4 Angular displacement, angular velocity, and angular acceleration around one axis are analogous to linear displacement, velocity, and acceleration in one dimension and demonstrate the same mathematical relationships.
      • 5.1.A.4.i For constant angular acceleration, the mathematical relationships between angular displacement, angular velocity, and angular acceleration can be described with the following equations:
        • $\omega = \omega_0 + \alpha t$
        • $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
        • $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
      • 5.1.A.4.ii Graphs of angular displacement, angular velocity, and angular acceleration as functions of time can be used to find the relationships between those quantities.

    Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of said vectors will not be assessed on the exam.

    Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.

    Русский

    Цель обучения 5.1.A: Описать вращение системы по отношению ко времени с использованием углового перемещения, угловой скорости и углового ускорения.

    • 5.1.A.1 Угловое перемещение — это величина угла (в радианах), на который поворачивается точка на жесткой системе вокруг заданной оси.
      • Уравнение: $\Delta\theta = \theta - \theta_0$
      • 5.1.A.1.i Жесткая система — это та, которая сохраняет свою форму, но при вращении различные точки которой движутся в разных направлениях. Жесткую систему нельзя моделировать как отдельный объект.
      • 5.1.A.1.ii Одно направление углового перемещения вокруг оси вращения — по часовой стрелке или против — обычно принимается математически положительным, а другое направление становится математически отрицательным.
      • 5.1.A.1.iii Если вращение системы вокруг оси можно хорошо описать с помощью движения центра масс системы, то систему можно рассматривать как единый объект. Например, вращение Земли вокруг своей оси можно считать пренебрежимо малым при рассмотрении обращения Земли вокруг центра масс системы Земля–Солнце.
    • 5.1.A.2 Угловая скорость — это скорость изменения углового положения по времени.
      • Уравнение: $\omega = \dfrac{d\theta}{dt}$
    • 5.1.A.3 Угловое ускорение — это скорость изменения угловой скорости по времени.
      • Уравнение: $\alpha = \dfrac{d\omega}{dt}$
    • 5.1.A.4 Угловое перемещение, угловая скорость и угловое ускорение вокруг одной оси аналогичны линейному перемещению, скорости и ускорению в одном измерении и демонстрируют те же математические соотношения.
      • 5.1.A.4.i Для постоянного углового ускорения математические соотношения между угловым перемещением, угловой скоростью и угловым ускорением могут быть описаны следующими уравнениями:
        • $\omega = \omega_0 + \alpha t$
        • $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
        • $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
      • 5.1.A.4.ii Графики углового перемещения, угловой скорости и углового ускорения как функций времени могут использоваться для нахождения взаимосвязей между этими величинами.

    Граничное условие: AP Physics C: Механика ожидает, что студенты смогут математически манипулировать модулями углового перемещения, угловой скорости и углового ускорения, используя векторные конвенции. Однако направления этих векторов не будут проверяться на экзамене.

    Описания направлений кинематических величин вращения для точки или твердого тела ограничиваются顺时针 (по часовой стрелке) и против часовой стрелки относительно данной оси вращения.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Rotation mirrors linear motion with angular quantities, defined as derivatives:

    $$\omega=\frac{d\theta}{dt},\qquad \alpha=\frac{d\omega}{dt}=\frac{d^2\theta}{dt^2}.$$

    Here $\theta$ is angular displacement 角位移 in radians 弧度, $\omega$ the angular velocity 角速度, and $\alpha$ the angular acceleration 角加速度. (AP works with their magnitudes and signs; the 3D vector directions are not assessed.) For constant $\alpha$, the kinematic equations are the linear ones re-lettered:

    $$\omega=\omega_0+\alpha t,\qquad \Delta\theta=\omega_0t+\tfrac12\alpha t^2,\qquad \omega^2=\omega_0^2+2\alpha\,\Delta\theta.$$
    One radian is the angle whose arc length equals the radius
    One radian is the angle whose arc length equals the radius

    Worked example. A fan blade slows from $30\ \text{rad/s}$ to rest with $\alpha=-6.0\ \text{rad/s}^2$: it takes $t=5.0\ \text{s}$ and turns through $\Delta\theta=\dfrac{0-30^2}{2(-6.0)}=75\ \text{rad}$ – about $12$ revolutions.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ углового перемещения
    radians/ˈreɪdɪənz/ радианах
    angular velocity/ˈæŋɡjʊlə vəˈlɒsɪti/ угловой скорости
    angular acceleration/ˈæŋɡjʊlə əkˌseləˈreɪʃn/ угловое ускорение
    5.2

    Connecting Linear and Rotational Motion

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 5.2.A: Describe the linear motion of a point on a rotating rigid system that corresponds to the rotational motion of that point, and vice versa.

    • 5.2.A.1 For a point at a distance $r$ from a fixed axis of rotation, the linear distance $s$ traveled by the point as the system rotates through an angle $\Delta\theta$ is given by the equation $\Delta s = r\Delta\theta$.
    • 5.2.A.2 Derived relationships of linear velocity and of the tangential component of acceleration to their respective angular quantities are given by the following equations:
      • $s = r\theta$
      • $v = r\omega$
      • $a_T = r\alpha$
    • 5.2.A.3 For a rigid system, all points within that system have the same angular velocity and angular acceleration.

    Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of the vectors will not be assessed on the exam.

    Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.

    Русский

    Цель обучения 5.2.A: Описать линейное движение точки на вращающейся жесткой системе, соответствующее вращательному движению этой точки, и наоборот.

    • 5.2.A.1 Для точки на расстоянии $r$ от неподвижной оси вращения линейное расстояние $s$, пройденное точкой при вращении системы на угол $\Delta\theta$, определяется уравнением $\Delta s = r\Delta\theta$.
    • 5.2.A.2 Выведенные соотношения линейной скорости и тангенциальной составляющей ускорения к их соответствующим угловым величинам задаются следующими уравнениями:
      • $s = r\theta$
      • $v = r\omega$
      • $a_T = r\alpha$
    • 5.2.A.3 Для жесткой системы все точки внутри нее имеют одинаковую угловую скорость и угловое ускорение.

    Граничное условие: AP Physics C: Механика ожидает, что студенты смогут математически манипулировать модулями углового перемещения, угловой скорости и углового ускорения, используя векторные конвенции. Однако направления векторов не будут проверяться на экзамене.

    Описания направлений кинематических величин вращения для точки или твердого тела ограничиваются顺时针 (по часовой стрелке) и против часовой стрелки относительно данной оси вращения.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    A point at radius $r$ from the axis moves along its arc with

    $$s=r\theta,\qquad v=r\omega,\qquad a_t=r\alpha,$$

    so points farther out move faster. A rotating point generally has two acceleration components at once: the tangential acceleration 切向加速度 $a_t=r\alpha$ (speeding up along the arc) and the centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}=r\omega^2$ (turning, towards the axis). They are perpendicular, so $a=\sqrt{a_t^2+a_c^2}$.

    As the radius turns through an angle, a point moves along an arc at speed v
    As the radius turns through an angle, a point moves along an arc at speed v
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    tangential acceleration/tænˈdʒenʃl əkˌseləˈreɪʃn/ касательное ускорение
    centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ центростремительное ускорение
    5.3

    Torque

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 5.3.A: Identify the torques exerted on a rigid system.

    • 5.3.A.1 Torque results only from the force component perpendicular to the position vector from the axis of rotation to the point of application of the force.
    • 5.3.A.2 The lever arm is the perpendicular distance from the axis of rotation to the line of action of the exerted force.

    Learning Objective 5.3.B: Describe the torques exerted on a rigid system.

    • 5.3.B.1 Torques can be described using force diagrams.
      • 5.3.B.1.i Force diagrams are similar to free-body diagrams and are used to analyze the torques exerted on a rigid system.
      • 5.3.B.1.ii Similar to free-body diagrams, force diagrams represent the relative magnitude and direction of the forces exerted on a rigid system. Force diagrams also depict the location at which those forces are exerted relative to the axis of rotation.
    • 5.3.B.2 The torque exerted on a rigid system about a chosen pivot point by a given force is described by $\vec{\tau} = \vec{r} \times \vec{F}$.
      • 5.3.B.2.i The cross-product between two vectors, $\vec{A}$ and $\vec{B}$, results in a vector quantity of magnitude $\vec{A} \times \vec{B} = AB\sin\theta$.
      • 5.3.B.2.ii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ is perpendicular to both vectors $\vec{A}$ and $\vec{B}$ and therefore is normal to the plane defined by vectors $\vec{A}$ and $\vec{B}$.
      • 5.3.B.2.iii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ can be qualitatively determined by applying the appropriate right-hand rule.
    Русский

    Цель обучения 5.3.A: Определить моменты сил, действующие на жесткую систему.

    • 5.3.A.1 Момент силы возникает только вследствие компоненты силы, перпендикулярной вектору положения от оси вращения до точки приложения силы.
    • 5.3.A.2 Плечо силы — это перпендикулярное расстояние от оси вращения до линии действия приложенной силы.

    Цель обучения 5.3.B: Описать моменты сил, действующие на жесткую систему.

    • 5.3.B.1 Моменты сил можно описывать с помощью диаграмм сил.
      • 5.3.B.1.i Диаграммы сил похожи на диаграммы свободного тела и используются для анализа моментов сил, действующих на жесткую систему.
      • 5.3.B.1.ii Как и диаграммы свободного тела, диаграммы сил отображают относительную величину и направление сил, действующих на жесткую систему. Диаграммы сил также показывают точки приложения этих сил относительно оси вращения.
    • 5.3.B.2 Момент силы, действующий на жесткую систему относительно выбранной точки опоры заданной силой, описывается формулой $\vec{\tau} = \vec{r} \times \vec{F}$.
      • 5.3.B.2.i Векторное произведение двух векторов, $\vec{A}$ и $\vec{B}$, дает векторную величину модуля $\vec{A} \times \vec{B} = AB\sin\theta$.
      • 5.3.B.2.ii Направление вектора, полученного из векторного произведения векторов $\vec{A}$ и $\vec{B}$, перпендикулярно обоим векторам $\vec{A}$ и $\vec{B}$ и, следовательно, нормально плоскости, определенной векторами $\vec{A}$ и $\vec{B}$.
      • 5.3.B.2.iii Направление вектора, полученного из векторного произведения векторов $\vec{A}$ и $\vec{B}$, можно определитьQualitatively, применив соответствующее правило правой руки.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    The principle of moments (torque)

    Torque 力矩 is the turning effect of a force – the rotational cause, as force is the translational cause. It is a vector product 矢量积:

    $$\vec{\tau}=\vec{r}\times\vec{F},\qquad \tau=rF\sin\theta=F\,r_\perp,$$

    where $r_\perp$, the moment arm 力臂, is the perpendicular distance from the axis to the force's line of action. More force, applied farther from the axis, more perpendicular: more torque. A force pointing straight at (or away from) the axis has zero torque. In a plane, give counterclockwise and clockwise torques opposite signs and add.

    As a vector product, $\vec\tau=\vec r\times\vec F$ points perpendicular to the plane of $\vec r$ and $\vec F$, with its direction fixed by the right-hand rule 右手定则: curl your right fingers from $\vec r$ toward $\vec F$ and your thumb points along $\vec\tau$ – out of the page for a counterclockwise turn, into it for a clockwise one. The same rule gives the direction of angular momentum $\vec L=\vec r\times\vec p$.

    The torque of a force depends on the perpendicular distance from the axis
    The torque of a force depends on the perpendicular distance from the axis
    A gear train: torques and rotational inertia couple through the gear ratio
    A gear train: torques and rotational inertia couple through the gear ratio
    Explore · ⁨Исследовать⁩

    Balance torques on a beam · ⁨Балансируйте моменты сил на балке⁩

    Torque is force times perpendicular distance, $\tau=Fd$. The beam is in rotational equilibrium when the torques on each side are equal. · ⁨Момент силы — это произведение силы на перпендикулярное плечо, $\tau=Fd$. Балка находится в ротационном равновесии, когда моменты сил по обе стороны от опоры равны.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Torque/tɔːk/ Момент силы
    vector product/ˈvektə ˈprɒdʌkt/ векторное произведение
    moment arm/ˈməʊmənt ɑːm/ плечо силы
    right-hand rule/raɪt hænd ruːl/ правило правой руки
    Watch lesson · ⁨Смотреть урок⁩
    5.4

    Rotational Inertia

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 5.4.A: Describe the rotational inertia of a rigid system relative to a given axis of rotation.

    • 5.4.A.1 Rotational inertia measures a rigid system's resistance to changes in rotation and is related to the mass of the system and the distribution of that mass relative to the axis of rotation.
    • 5.4.A.2 The rotational inertia of an object rotating a perpendicular distance $r$ from an axis is described by the equation $I = mr^2$.
    • 5.4.A.3 The total rotational inertia of a collection of objects about an axis is the sum of the rotational inertias of each object about that axis.
      • Equation: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
    • 5.4.A.4 For a solid that can be considered as a collection of differential masses, $dm$, the solid's rotational inertia can be calculated using the equation $I = \int r^2\, dm$, where $r$ is the perpendicular distance from $dm$ to the axis of rotation.

    Learning Objective 5.4.B: Describe the rotational inertia of a rigid system rotating about an axis that does not pass through the system's center of mass.

    • 5.4.B.1 A rigid system's rotational inertia in a given plane is at a minimum when the rotational axis passes through the system's center of mass.
    • 5.4.B.2 The parallel axis theorem uses the following equation to relate the rotational inertia of a rigid system about any axis that is parallel to an axis through its center of mass:
      • Equation: $I' = I_{\text{cm}} + Md^2$

    Boundary statement: AP Physics C: Mechanics only expects students to use calculus in the derivations of the rotational inertia of thin rods of uniform or nonuniform density about an arbitrary axis perpendicular to the rod, as well as derivations of the rotational inertia of a thin cylindrical shell, disk, or rigid bodies that can be considered to be made up of coaxial rings or shells about an axis that passes through their centers (e.g., annular rings).

    Students should have a qualitative understanding of the factors that affect rotational inertia; for example, how rotational inertia is greater when mass is farther from the axis of rotation, which is why a hoop has more rotational inertia than a solid puck of the same mass and radius.

    Русский

    Цель обучения 5.4.A: Описать вращательную инерцию жесткой системы относительно заданной оси вращения.

    • 5.4.A.1 Вращательная инерция характеризует сопротивление жесткой системы изменению состояния вращения и связана с массой системы и распределением этой массы относительно оси вращения.
    • 5.4.A.2 Момент инерции тела, вращающегося на перпендикулярном расстоянии $r$ от оси, описывается уравнением $I = mr^2$.
    • 5.4.A.3 Полный момент инерции совокупности тел относительно оси равен сумме моментов инерции каждого тела относительно этой оси.
      • Уравнение: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
    • 5.4.A.4 Для твердого тела, которое можно рассматривать как совокупность дифференциальных масс, $dm$, момент инерции тела может быть рассчитан с использованием уравнения $I = \int r^2\, dm$, где $r$ — перпендикулярное расстояние от $dm$ до оси вращения.

    Цель обучения 5.4.B: Описать вращательную инерцию жесткой системы, вращающейся вокруг оси, не проходящей через центр масс системы.

    • 5.4.B.1 Вращательная инерция жесткой системы в данной плоскости минимальна, когда ось вращения проходит через центр масс системы.
    • 5.4.B.2 Теорема о параллельных осях использует следующее уравнение для связи вращательной инерции жесткой системы относительно любой оси, параллельной оси, проходящей через центр масс:
      • Уравнение: $I' = I_{\text{cm}} + Md^2$

    Граничное условие: AP Physics C: Механика требует от студентов использования исчислений при выводе формул момента инерции тонких стержней с равномерной или неравномерной плотностью относительно произвольной оси, перпендикулярной стержню, а также выводе момента инерции тонкой цилиндрической оболочки, диска или твердых тел, которые можно считать состоящими из коаксиальных колец или оболочек относительно оси, проходящей через их центры (например, кольцевых дисков).

    Студенты должны иметь качественное понимание факторов, влияющих на момент инерции; например, как момент инерции увеличивается, когда масса находится дальше от оси вращения, поэтому кольцо имеет больший момент инерции, чем сплошной диск той же массы и радиуса.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Rotational inertia 转动惯量 $I$ measures resistance to angular acceleration – the rotational analog of mass, but it depends on where the mass sits. For point masses, $I=\sum m_ir_i^2$; for a continuous body,

    $$I=\int r^2\,dm.$$

    Mass far from the axis dominates, because of the $r^2$.

    Worked example (rod). A uniform rod (mass $M$, length $L$) about its centre: with linear density 线密度 $\lambda=M/L$, $dm=\lambda\,dx$, so $I=\displaystyle\int_{-L/2}^{L/2}x^2\,\frac{M}{L}\,dx=\frac{1}{12}ML^2$. AP also expects nonuniform rods: if $\lambda(x)=cx$ on $[0,L]$, first find $M=\int_0^L cx\,dx=\tfrac12cL^2$, then $I=\int_0^L x^2(cx)\,dx=\tfrac14cL^4=\tfrac12ML^2$ about the light end.

    Worked example (disk from rings). A solid disk is a nest of rings: a ring at radius $r$ of width $dr$ has $dm=\dfrac{M}{\pi R^2}\,2\pi r\,dr$, so

    $$I=\int_0^R r^2\,dm=\frac{2M}{R^2}\int_0^R r^3\,dr=\tfrac12MR^2.$$

    The same coaxial-shell method handles cylindrical shells and annular rings.

    The parallel-axis theorem 平行轴定理 shifts any known $I$ to a parallel axis a distance $d$ away:

    $$I'=I_{\text{cm}}+Md^2.$$

    For the rod about one end: $I=\tfrac1{12}ML^2+M\big(\tfrac{L}{2}\big)^2=\tfrac13ML^2$.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ Момент инерции
    linear density/ˈlɪnɪə ˈdensɪti/ линейная плотность
    parallel-axis theorem/ˈpærəlel ˈæksɪs ˈθɪərəm/ теорема параллельных осей
    5.5

    Rotational Equilibrium

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 5.5.A: Describe the conditions under which a system's angular velocity remains constant.

    • 5.5.A.1 A system may exhibit rotational equilibrium (constant angular velocity) without being in translational equilibrium, and vice versa.
      • 5.5.A.1.i Free-body and force diagrams describe the nature of the forces and torques exerted on an object or rigid system.
      • 5.5.A.1.ii Rotational equilibrium is a configuration of torques such that the net torque exerted on the system is zero.
        • Equation: $\sum \tau_i = 0$
      • 5.5.A.1.iii The rotational analog of Newton's first law is that a system will have a constant angular velocity only if the net torque exerted on the system is zero.
    • 5.5.A.2 A rotational corollary to Newton's second law states that if the torques exerted on a rigid system are not balanced, the system's angular velocity must be changing.

    Boundary statement: AP Physics C: Mechanics does not expect students to simultaneously analyze rotation in multiple planes.

    Русский

    Цель обучения 5.5.A: Описать условия, при которых угловая скорость системы остается постоянной.

    • 5.5.A.1 Система может находиться во вращательном равновесии (постоянная угловая скорость) без нахождения в поступательном равновесии, и наоборот.
      • 5.5.A.1.i Диаграммы свободного тела и диаграммы сил описывают характер сил и моментов, действующих на объект или жесткую систему.
      • 5.5.A.1.ii Вращательное равновесие представляет собой состояние моментов, при котором результирующий момент, действующий на систему, равен нулю.
        • Уравнение: $\sum \tau_i = 0$
      • 5.5.A.1.iii Вращательный аналог первого закона Ньютона гласит, что система будет иметь постоянную угловую скорость только тогда, когда результирующий момент, действующий на нее, равен нулю.
    • 5.5.A.2 Вращательный следствие второго закона Ньютона гласит, что если моменты сил, действующие на жесткую систему, не скомпенсированы, угловая скорость системы должна изменяться.

    Граничное условие: AP Physics C: Механика не ожидает, что студенты будут одновременно анализировать вращение в нескольких плоскостях.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Newton's first law has a rotational form: with zero net torque, angular velocity is constant – an object in rotational equilibrium 转动平衡 either does not rotate or rotates steadily. Full static equilibrium 静平衡 needs both $\sum F=0$ and $\sum\tau=0$ (about any axis). The standard move for beams and ladders: put the axis at the point where an unknown force acts, so that force drops out of the torque equation.

    At balance the clockwise and anticlockwise torques about the axis are equal
    At balance the clockwise and anticlockwise torques about the axis are equal

    Worked example. A uniform $20\ \text{kg}$ beam, $4.0\ \text{m}$ long, is pivoted at its left end and held horizontal by a vertical rope at its right end. A $40\ \text{kg}$ child sits $1.0\ \text{m}$ from the pivot. Torques about the pivot: $T(4.0)=20g(2.0)+40g(1.0)$, so $T=\dfrac{392+392}{4.0}=196\ \text{N}$. Then vertical force balance gives the pivot's upward push: $F_p=(60)(9.8)-196=392\ \text{N}$. Choosing the pivot as the axis removed $F_p$ from the torque equation entirely.

    A beam balance: rotational equilibrium when clockwise and anticlockwise torques match
    A beam balance: rotational equilibrium when clockwise and anticlockwise torques match
    Explore · ⁨Исследовать⁩

    Find the balance point · ⁨Найдите точку баланса⁩

    For rotational equilibrium the total clockwise torque equals the total anticlockwise torque. Move the forces and distances until the beam balances. · ⁨Для ротационного равновесия суммарный момент по часовой стрелке равен суммарному моменту против часовой стрелки. Перемещайте силы и расстояния, пока балка не уравновесится.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    rotational equilibrium/rəʊˈteɪʃənl ˌiːkwɪˈlɪbrɪəm/ ротационное равновесие
    static equilibrium/ˈstætɪk ˌiːkwɪˈlɪbrɪəm/ статическое равновесие
    Watch lesson · ⁨Смотреть урок⁩
    5.6

    Newton's Second Law in Rotational Form

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 5.6.A: Describe the conditions under which a system's angular velocity changes.

    • 5.6.A.1 Angular velocity changes when the net torque exerted on the object or system is not equal to zero.
    • 5.6.A.2 The rate at which the angular velocity of a rigid system changes is directly proportional to the net torque exerted on the rigid system and is in the same direction. The angular acceleration of the rigid system is inversely proportional to the rotational inertia of the rigid system.
      • Equation: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
    • 5.6.A.3 To fully describe a rotating rigid system, linear and rotational analyses may need to be performed independently.
    Русский

    Цель обучения 5.6.A: Описать условия, при которых угловая скорость системы изменяется.

    • 5.6.A.1 Угловая скорость изменяется, когда результирующий момент, действующий на объект или систему, не равен нулю.
    • 5.6.A.2 Скорость изменения угловой скорости жесткой системы прямо пропорциональна результирующему моменту, действующему на жесткую систему, и направлена в ту же сторону. Угловое ускорение жесткой системы обратно пропорционально ее вращательной инерции.
      • Уравнение: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
    • 5.6.A.3 Для полного описания вращающейся жесткой системы могут потребоваться независимые линейный и вращательный анализы.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    A net torque produces angular acceleration in proportion to the rotational inertia:

    $$\alpha=\frac{\sum\tau}{I}\qquad\Big(\text{more generally }\sum\vec{\tau}=\frac{d\vec{L}}{dt}\Big).$$

    Solve rotational dynamics exactly like translational dynamics, with $\tau\leftrightarrow F$, $I\leftrightarrow m$, $\alpha\leftrightarrow a$ – free-body diagram, equations, solve.

    A massive pulley: the two tensions differ because the pulley needs net torque
    A massive pulley: the two tensions differ because the pulley needs net torque

    Worked example (massive pulley). Masses $m_1=4.0\ \text{kg}$ and $m_2=2.0\ \text{kg}$ hang from a rope over a pulley 滑轮 of rotational inertia $I=0.50\ \text{kg}\cdot\text{m}^2$ and radius $R=0.20\ \text{m}$. Three Newton's-law equations, one per body:

    $$m_1g-T_1=m_1a,\qquad T_2-m_2g=m_2a,\qquad (T_1-T_2)R=I\alpha=\frac{Ia}{R}.$$

    Adding them (with $I/R^2=12.5\ \text{kg}$): $a=\dfrac{(m_1-m_2)g}{m_1+m_2+I/R^2}=\dfrac{19.6}{18.5}=1.1\ \text{m/s}^2$. Then $T_1=m_1(g-a)=35\ \text{N}$ and $T_2=m_2(g+a)=22\ \text{N}$. The tensions must differ – otherwise nothing would spin the pulley. (If a problem says the pulley is light, then $I\approx0$ and the tensions become equal again.)

    Exam skill. Rotational FRQs score the setup: separate free-body diagrams for each mass and the pulley, the string constraint $a=R\alpha$ stated, and the sign convention consistent. The single most common error is assuming one tension throughout a rope that passes over a massive pulley.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    pulley/ˈpʊli/ блок (шкив)
    5.6

    Exam tips

    • Use the rotational analogues: $\theta,\omega=\tfrac{d\theta}{dt},\alpha=\tfrac{d\omega}{dt}$, with the constant-$\alpha$ equations mirroring linear kinematics.
    • Convert between linear and angular with $v=r\omega$ and $a_t=r\alpha$ (plus centripetal $a_c=\tfrac{v^2}{r}=\omega^2 r$).
    • Keep radians throughout and fix a positive sense of rotation.
    • Relate torque to angular acceleration through $\tau=I\alpha$.
    • Draw the rotation axis — the moment arm is the perpendicular distance to it.
  • 6

    Energy and Momentum of Rotating Systems · ⁨Энергия и импульс вращающихся систем⁩

    Watch lesson · ⁨Смотреть урок⁩
    6.1

    Rotational Kinetic Energy

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 6.1.A: Describe the rotational kinetic energy of a rigid system in terms of the rotational inertia and angular velocity of that rigid system.

    • 6.1.A.1 The rotational kinetic energy of an object or rigid system is related to the rotational inertia and angular velocity of the rigid system and is given by the equation $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
      • Equation: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
      • 6.1.A.1.i The rotational inertia of an object about a fixed axis can be used to show that the rotational kinetic energy of that object is equivalent to its translational kinetic energy, which is its total kinetic energy.
      • 6.1.A.1.ii The total kinetic energy of a rigid system is the sum of its rotational kinetic energy due to its rotation about its center of mass and the translational kinetic energy due to the linear motion of its center of mass.
    • 6.1.A.2 A rigid system can have rotational kinetic energy while its center of mass is at rest due to the individual points within the rigid system having linear speed and, therefore, kinetic energy.
    • 6.1.A.3 Rotational kinetic energy is a scalar quantity.
    Русский

    Цель обучения 6.1.A: Описать вращательную кинетическую энергию жесткой системы с точки зрения ее вращательной инерции и угловой скорости.

    • 6.1.A.1 Вращательная кинетическая энергия объекта или жесткой системы связана с его вращательной инерцией и угловой скоростью и выражается уравнением $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
      • Уравнение: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
      • 6.1.A.1.i Вращательная инерция объекта относительно фиксированной оси может быть использована для демонстрации того, что вращательная кинетическая энергия этого объекта эквивалентна его поступательной кинетической энергии, которая является его полной кинетической энергией.
      • 6.1.A.1.ii Полная кинетическая энергия жесткой системы равна сумме ее вращательной кинетической энергии, обусловленной вращением вокруг центра масс, и поступательной кинетической энергии, обусловленной линейным движением центра масс.
    • 6.1.A.2 Жесткая система может обладать вращательной кинетической энергией, даже если ее центр масс неподвижен, благодаря тому, что отдельные точки внутри жесткой системы имеют линейную скорость, а следовательно, и кинетическую энергию.
    • 6.1.A.3 Вращательная кинетическая энергия является скалярной величиной.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    A spinning body has rotational kinetic energy 转动动能

    $$K_{\text{rot}}=\tfrac12 I\omega^2,$$

    the rotational twin of $\tfrac12mv^2$, with the rotational inertia 转动惯量 $I$ playing the role of mass. A body that both moves and spins carries both terms:

    $$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$

    Worked example. A uniform cylinder ($I=\tfrac12mr^2$) rolls at speed $v$. Its kinetic energy is $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – one third of it is rotational. The same ball of energy bookkeeping decides every rolling problem.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    rotational kinetic energy/rəʊˈteɪʃənl kɪˈnetɪk ˈenədʒi/ вращательная кинетическая энергия
    rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ момент инерции
    6.2

    Torque and Work

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 6.2.A: Describe the work done on a rigid system by a given torque or collection of torques.

    • 6.2.A.1 A torque can transfer energy into or out of an object or rigid system if the torque is exerted over an angular displacement.
    • 6.2.A.2 The amount of work done on a rigid system by a torque is related to the magnitude of that torque and the angular displacement through which the rigid system rotates during the interval in which that torque is exerted.
      • Equation: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
    • 6.2.A.3 Work done on a rigid system by a given torque can be found from the area under the curve of a graph of the torque as a function of angular position.
    Русский

    Учебная цель 6.2.A: Описать работу, совершенную над жесткой системой заданным моментом силы или совокупностью моментов.

    • 6.2.A.1 Момент силы может передавать энергию в объект или жесткую систему и выводить её из них, если этот момент приложен на угловом перемещении.
    • 6.2.A.2 Величина работы, совершенной над жесткой системой моментом силы, связана с величиной этого момента и угловым перемещением, на которое повернулась жесткая система в течение интервала времени действия этого момента.
      • Уравнение: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
    • 6.2.A.3 Работа, совершенная над жесткой системой заданным моментом силы, может быть найдена как площадь под кривой графика зависимости момента силы от углового положения.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    A torque 力矩 acting through an angular displacement 角位移 does work, and power is torque times angular velocity:

    $$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$

    These are the rotational forms of $W=\int F\,dx$ and $P=Fv$ – the whole translational energy toolkit carries over with $F\to\tau$, $x\to\theta$, $v\to\omega$.

    Worked example. A motor applies a constant $8.0\ \text{N}\cdot\text{m}$ torque to a flywheel for $5.0$ full turns: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, which appears as rotational kinetic energy if friction is negligible.

    Explore · ⁨Исследовать⁩

    Balance torques on a beam · ⁨Балансируйте моменты сил на балке⁩

    Torque is force times perpendicular distance, $\tau=Fd$. Equal torques on each side keep the beam in rotational equilibrium. · ⁨Момент силы равен силе, умноженной на перпендикулярное плечо, $\tau=Fd$. Равные моменты по обе стороны удерживают балку в равновесии.⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    torque/tɔːk/ момента силы
    angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ углового перемещения
    6.3

    Angular Momentum and Angular Impulse

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 6.3.A: Describe the angular momentum of an object or rigid system.

    • 6.3.A.1 The magnitude of the angular momentum of a rigid system about a specific axis can be described with the equation $L = I\omega$.
      • Equation: $L = I\omega$
    • 6.3.A.2 The angular momentum of an object about a given point is $\vec{L} = \vec{r} \times \vec{p}$.
      • Equation: $\vec{L} = \vec{r} \times \vec{p}$
      • 6.3.A.2.i The selection of the axis about which an object is considered to rotate influences the determination of the angular momentum of that object.
      • 6.3.A.2.ii The measured angular momentum of an object traveling in a straight line depends on the distance between the reference point and the object, the mass of the object, the speed of the object, and the angle between the radial distance and the velocity of the object.

    Learning Objective 6.3.B: Describe the angular impulse delivered to an object or rigid system by a torque.

    • 6.3.B.1 Angular impulse is defined as the product of the torque exerted on an object or rigid system and the time interval during which the torque is exerted.
      • Equation: $\text{angular impulse} = \displaystyle\int \tau \, dt$
    • 6.3.B.2 Angular impulse has the same direction as the torque imparting it.
    • 6.3.B.3 The angular impulse delivered to an object or rigid system by a torque can be found from the area under the curve of a graph of the torque as a function of time.

    Learning Objective 6.3.C: Relate the change in angular momentum of an object or rigid system to the angular impulse given to that object or rigid system.

    • 6.3.C.1 The magnitude of the change in angular momentum can be described by comparing the magnitudes of the final and initial momenta of the object or rigid system.
      • Equation: $\Delta L = L - L_0$
    • 6.3.C.2 A rotational form of the impulse–momentum theorem relates the angular impulse delivered to an object or rigid system and the change in angular momentum of that object or rigid system.
      • 6.3.C.2.i The angular impulse exerted on an object or rigid system is equal to the change in angular momentum of that object or rigid system.
        • Equation: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
      • 6.3.C.2.ii The rotational form of the impulse–momentum theorem is a direct result of Newton's second law of motion for cases in which rotational inertia is constant.
        • Equation: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
    • 6.3.C.3 The net torque exerted on an object or rigid system is equal to the slope of the graph of the angular momentum of an object as a function of time.
    • 6.3.C.4 The angular impulse delivered to an object or rigid system is equal to the area under the curve of a graph of the net external torque exerted on an object as a function of time.
    Русский

    Учебная цель 6.3.A: Описать момент импульса объекта или жесткой системы.

    • 6.3.A.1 Величину момента импульса жесткой системы относительно определенной оси можно описать уравнением $L = I\omega$.
      • Уравнение: $L = I\omega$
    • 6.3.A.2 Момент импульса тела относительно данной точки равен $\vec{L} = \vec{r} \times \vec{p}$.
      • Уравнение: $\vec{L} = \vec{r} \times \vec{p}$
      • 6.3.A.2.i Выбор оси, вокруг которой считается вращающимся объект, влияет на определение его момента импульса.
      • 6.3.A.2.ii Измеренный момент импульса объекта, движущегося по прямой, зависит от расстояния между опорной точкой и объектом, массы объекта, скорости объекта и угла между радиус-вектором и скоростью объекта.

    Учебная цель 6.3.B: Описать угловой импульс, переданный объекту или жесткой системе моментом силы.

    • 6.3.B.1 Угловой импульс определяется как произведение момента силы, приложенного к объекту или жесткой системе, и интервала времени, в течение которого этот момент действует.
      • Уравнение: $\text{angular impulse} = \displaystyle\int \tau \, dt$
    • 6.3.B.2 Импульс момента силы имеет то же направление, что и передаваемый им момент силы.
    • 6.3.B.3 Угловой импульс, переданный объекту или жесткой системе моментом силы, может быть найден как площадь под кривой графика зависимости момента силы от времени.

    Учебная цель 6.3.C: Связать изменение момента импульса объекта или жесткой системы с угловым импульсом, переданным этому объекту или системе.

    • 6.3.C.1 Модуль изменения момента импульса можно описать, сравнив модули конечного и начального импульсов тела или жесткой системы.
      • Уравнение: $\Delta L = L - L_0$
    • 6.3.C.2 Вращательная форма теоремы об импульсе и импульсе движения связывает угловой импульс, переданный объекту или жесткой системе, и изменение её момента импульса.
      • 6.3.C.2.i Угловой импульс, действующий на объект или жесткую систему, равен изменению момента импульса этой системы.
        • Уравнение: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
      • 6.3.C.2.ii Вращательная форма теоремы об импульсе и моменте является прямым следствием второго закона Ньютона для случаев, когда момент инерции постоянен.
        • Уравнение: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
    • 6.3.C.3 Равнодействующий момент силы, действующий на тело или жесткую систему, равен наклону графика зависимости момента импульса тела от времени.
    • 6.3.C.4 Импульс момента силы, переданный телу или жесткой системе, равен площади под кривой графика зависимости равнодействующей внешней силы, действующей на тело, от времени.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Angular momentum 角动量 for a particle is

    $$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$

    so even a particle moving in a straight line has angular momentum about any point not on that line ($L=mv\,d$, with $d$ the perpendicular distance). For a rigid body spinning about a fixed axis, $L=I\omega$. Newton's second law in rotational form is

    $$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$

    and a net torque acting over time delivers an angular impulse 角冲量 $\int\tau\,dt=\Delta L$ – the rotational impulse–momentum theorem.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Angular momentum/ˈæŋɡjʊlə məʊˈmentəm/ Импульс момента
    angular impulse/ˈæŋɡjʊlə ˈɪmpʌls/ угловой импульс
    6.4

    Conservation of Angular Momentum

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 6.4.A: Describe the behavior of a system using conservation of angular momentum.

    • 6.4.A.1 The total angular momentum of a system about a rotational axis is the sum of the angular momenta of the system's constituent parts about that rotational axis.
    • 6.4.A.2 Any change to a system's angular momentum must be due to an interaction between the system and its surroundings.
      • 6.4.A.2.i The angular impulse exerted by one object or system on a second object or system is equal and opposite to the angular impulse exerted by the second object or system on the first. This is a direct result of Newton's third law.
      • 6.4.A.2.ii A system may be selected so that the total angular momentum of that system is constant.
      • 6.4.A.2.iii The angular speed of a nonrigid system may change without the angular momentum of the system changing if the system changes shape by moving mass closer to or farther from the rotational axis.
      • 6.4.A.2.iv If the total angular momentum of a system changes, that change will be equivalent to the angular impulse exerted on the system.

    Learning Objective 6.4.B: Describe how the selection of a system determines whether the angular momentum of that system changes.

    • 6.4.B.1 Angular momentum is conserved in all interactions.
    • 6.4.B.2 If the net external torque exerted on a selected object or rigid system is zero, the total angular momentum of that system is constant.
    • 6.4.B.3 If the net external torque exerted on a selected object or rigid system is nonzero, angular momentum is transferred between the system and the environment.
    Русский

    Учебная цель 6.4.A: Описать поведение системы с использованием закона сохранения момента импульса.

    • 6.4.A.1 Полный момент импульса системы относительно оси вращения равен сумме моментов импульса составляющих элементов этой системы относительно данной оси вращения.
    • 6.4.A.2 Любое изменение момента импульса системы должно быть вызвано взаимодействием системы с окружающей средой.
      • 6.4.A.2.i Угловой импульс, оказываемый одним объектом или системой на второй объект или систему, равен по величине и противоположен по направлению угловому импульсу, оказываемому вторым объектом или системой на первый. Это прямое следствие третьего закона Ньютона.
      • 6.4.A.2.ii Можно выбрать такую систему, полный момент импульса которой будет постоянным.
      • 6.4.A.2.iii Угловая скорость нереальной системы может изменяться без изменения углового момента системы, если система меняет форму, перемещая массу ближе к или дальше от оси вращения.
      • 6.4.A.2.iv Если полный момент импульса системы изменяется, это изменение будет эквивалентно угловому импульсу, переданному системе.

    Учебная цель 6.4.B: Описать, как выбор системы определяет, изменяется ли момент импульса этой системы.

    • 6.4.B.1 Момент импульса сохраняется во всех взаимодействиях.
    • 6.4.B.2 Если равнодействующий внешний момент силы, действующий на выбранный объект или жесткую систему, равен нулю, полный момент импульса этой системы постоянен.
    • 6.4.B.3 Если равнодействующий внешний момент силы, действующий на выбранный объект или жесткую систему, отличен от нуля, происходит обмен моментом импульса между системой и окружающей средой.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Angular momentum: pull in, spin faster

    With zero net external torque, total angular momentum is conserved 守恒:

    $$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$

    If $I$ shrinks, $\omega$ grows – a spinning skater speeds up pulling her arms in. The rule survives collisions and shape changes, which is what makes it so useful: pick the axis so that every external force (gravity, the pivot force) exerts no torque about it.

    Worked example. A skater spins at $2.0\ \text{rev/s}$ with $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Pulling in her arms drops it to $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Her kinetic energy rises – the extra energy is the work her muscles do pulling her arms inward.

    Pulling mass inward lowers I, so ω rises to conserve L = Iω
    Pulling mass inward lowers I, so ω rises to conserve L = Iω
    Angular momentum about the pivot is conserved as the bullet embeds in the rod
    Angular momentum about the pivot is conserved as the bullet embeds in the rod

    Worked example (rotational collision). A $0.020\ \text{kg}$ bullet at $300\ \text{m/s}$ strikes the tip of a uniform rod ($M=1.5\ \text{kg}$, length $l=0.60\ \text{m}$) hanging from a pivot, and embeds. About the pivot, gravity and the pivot force exert no torque during the strike, so $L$ is conserved: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Afterwards $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, so $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Linear momentum is not conserved here – the pivot pushes on the rod – and kinetic energy certainly is not: check both before claiming them.)

    Figure skaters performing on the ice
    Figure skating and angular momentum: a skater who pulls their arms in during a spin lowers their rotational inertia, so they spin faster
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    conserved/kənˈsɜːvd/ сохраняемым
    6.5

    Rolling

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 6.5.A: Describe the kinetic energy of a system that has translational and rotational motion.

    • 6.5.A.1 The total kinetic energy of a system is the sum of the system's translational and rotational kinetic energies.
      • Equation: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$

    Learning Objective 6.5.B: Describe the motion of a system that is rolling without slipping.

    • 6.5.B.1 While rolling without slipping, the translational motion of a system's center of mass is related to the rotational motion of the system itself with the following equations:
      • Equation: $\Delta x_{\text{cm}} = r\Delta\theta$
      • Equation: $v_{\text{cm}} = r\omega$
      • Equation: $a_{\text{cm}} = r\alpha$
    • 6.5.B.2 For ideal cases, rolling without slipping implies that the frictional force does not dissipate any energy from the rolling system.

    Learning Objective 6.5.C: Describe the motion of a system that is rolling while slipping.

    • 6.5.C.1 When slipping, the motion of a system's center of mass and the system's rotational motion cannot be directly related.
    • 6.5.C.2 When a rotating system is slipping relative to another surface, the point of application of the force of kinetic friction exerted on the system moves with respect to the surface, so the force of kinetic friction will dissipate energy from the system.

    Boundary statement: Rolling friction is beyond the scope of AP Physics C: Mechanics.

    Русский

    Учебная цель 6.5.A: Описать кинетическую энергию системы, совершающей поступательное и вращательное движение.

    • 6.5.A.1 Полная кинетическая энергия системы равна сумме поступательной и вращательной кинетических энергий системы.
      • Уравнение: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$

    Учебная цель 6.5.B: Описать движение системы, которая катится без проскальзывания.

    • 6.5.B.1 При качении без скольжения поступательное движение центра масс системы связано с вращательным движением самой системы следующими уравнениями:
      • Уравнение: $\Delta x_{\text{cm}} = r\Delta\theta$
      • Уравнение: $v_{\text{cm}} = r\omega$
      • Уравнение: $a_{\text{cm}} = r\alpha$
    • 6.5.B.2 Для идеальных случаев качение без проскальзывания означает, что сила трения не рассеивает энергию катящейся системы.

    Цель обучения 6.5.C: Описать движение системы, которая катится с проскальзыванием.

    • 6.5.C.1 При проскальзывании движение центра масс системы и вращательное движение системы нельзя связать напрямую.
    • 6.5.C.2 Когда вращающаяся система проскальзывает относительно другой поверхности, точка приложения силы трения скольжения, действующей на систему, перемещается относительно этой поверхности, поэтому сила трения скольжения будет рассеивать энергию из системы.

    Граничное утверждение: Трение качения выходит за рамки программы AP Physics C: Mechanics.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Rolling without slipping

    Rolling without slipping 无滑滚动 ties translation to rotation: the contact point is momentarily at rest, so

    $$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$
    In rolling without slipping the contact point is at rest, so v = rω
    In rolling without slipping the contact point is at rest, so v = rω

    Static friction supplies the torque that keeps the spin matched to the motion, but at a point that is not sliding – so for pure rolling, friction does no work, and energy conservation is safe to use. (Rolling friction is beyond the AP course.)

    Racing shapes down an incline shows the energy split. With $I=\beta mr^2$, energy conservation gives

    $$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$

    a sphere ($\beta=\tfrac25$) beats a disk 圆盘 ($\beta=\tfrac12$), which beats a hoop 圆环 ($\beta=1$) – mass and radius cancel completely. More of the hoop's energy is locked in rotation, so its center moves slower.

    Rolling race: the shape with the smallest I/mr² reaches the bottom first
    Rolling race: the shape with the smallest I/mr² reaches the bottom first

    Worked example. A solid sphere rolls from rest down a $30^\circ$ incline: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, versus $4.9\ \text{m/s}^2$ for a frictionless slider – rolling objects always lose the race against sliding ones.

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Rolling without slipping/ˈrəʊlɪŋ wɪˈðaʊt ˈslɪpɪŋ/ Катание без проскальзывания
    disk/dɪsk/ диске
    hoop/huːp/ кольцо
    6.6

    Motion of Orbiting Satellites

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 6.6.A: Describe the motions of a system consisting of two objects or systems interacting only via gravitational forces.

    • 6.6.A.1 In a system consisting only of a massive central object and an orbiting satellite with mass that is negligible in comparison to the central object's mass, the motion of the central object itself is negligible.
    • 6.6.A.2 The motion of satellites in orbits is constrained by conservation laws.
      • 6.6.A.2.i In circular orbits, the system's total mechanical energy, the system's gravitational potential energy, and the satellite's angular momentum and kinetic energy are constant.
      • 6.6.A.2.ii In elliptical orbits, the system's total mechanical energy and the satellite's angular momentum are constant, but the system's gravitational potential energy and the satellite's kinetic energy can each change.
      • 6.6.A.2.iii The gravitational potential energy of a system consisting of a satellite and a massive central object is defined to be zero when the satellite is an infinite distance from the central object.
        • Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
    • 6.6.A.3 The total energy of a system consisting of a satellite orbiting a central object in a circular path can be written in terms of the gravitational potential energy of that system or the kinetic energy of the satellite.
      • Equation: $K = -\dfrac{1}{2}U$
      • Equation: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
    • 6.6.A.4 The escape velocity of a satellite is the satellite's velocity such that the mechanical energy of the satellite–central-object system is equal to zero.
      • 6.6.A.4.i When the only force exerted on a satellite is gravity from a central object, a satellite that reaches escape velocity will move away from the central body until its speed reaches zero at an infinite distance from the central body.
      • 6.6.A.4.ii The escape velocity of a satellite from a central body of mass $M$ can be derived using conservation of energy laws.
        • Equation: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$
    Русский

    Цель обучения 6.6.A: Описывать движения системы, состоящей из двух объектов или систем, взаимодействующих только посредством гравитационных сил.

    • 6.6.A.1 В системе, состоящей только из массивного центрального объекта и орбитирующего спутника, масса которого пренебрежимо мала по сравнению с массой центрального объекта, движение самого центрального объекта является пренебрежимо малым.
    • 6.6.A.2 Движение спутников на орбитах ограничено законами сохранения.
      • 6.6.A.2.i В круговых орбитах полная механическая энергия системы, гравитационный потенциальный энергия системы, а также момент импульса и кинетическая энергия спутника остаются постоянными.
      • 6.6.A.2.ii В эллиптических орбитах полная механическая энергия системы и момент импульса спутника остаются постоянными, но гравитационный потенциальный энергия системы и кинетическая энергия спутника могут изменяться.
      • 6.6.A.2.iii Гравитационный потенциальный энергия системы, состоящей из спутника и массивного центрального объекта, принимается равной нулю, когда спутник находится на бесконечном расстоянии от центрального объекта.
        • Уравнение: $U_g = -G\dfrac{m_1 m_2}{r}$
    • 6.6.A.3 Полная энергия системы, состоящей из спутника, движущегося по круговой орбите вокруг центрального тела, может быть выражена через потенциальную энергию гравитационного взаимодействия этой системы или кинетическую энергию спутника.
      • Уравнение: $K = -\dfrac{1}{2}U$
      • Уравнение: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
    • 6.6.A.4 Скорость убегания спутника — это скорость спутника, при которой механическая энергия системы «спутник–центральное тело» равна нулю.
      • 6.6.A.4.i Когда на спутник действует только сила тяжести со стороны центрального тела, спутник, достигший скорости убегания, будет удаляться от центрального тела до тех пор, пока его скорость не станет равной нулю на бесконечном удалении от него.
      • 6.6.A.4.ii Скорость убегания спутника от центрального тела массой $M$ может быть выведена с использованием законов сохранения энергии.
        • Уравнение: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    Orbital motion (Kepler's 2nd law)

    Gravity supplies the centripetal force 向心力 for a satellite 卫星 in a circular orbit:

    $$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$

    – larger orbits are slower. With gravitational potential energy 引力势能 $U_g=-\dfrac{GMm}{r}$, a circular orbit obeys $K=-\tfrac12U$, so the total mechanical energy 总机械能 is

    $$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$

    negative because the satellite is bound. To escape from radius $r$, total energy must reach zero, giving the escape velocity 逃逸速度

    $$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$
    Gravity provides the centripetal force that keeps a satellite in orbit
    Gravity provides the centripetal force that keeps a satellite in orbit

    In an elliptical orbit 椭圆轨道, $E$ and $L$ are fixed: gravity points at the focus, so it exerts no torque about it. Conserved $L$ means the satellite sweeps equal areas in equal times – Kepler's second law 开普勒第二定律 – and therefore moves fastest at closest approach, slowest at the far point. Energy conservation connects speeds at the two ends.

    Worked example. For a satellite at $r=7.0\times10^{6}\ \text{m}$ around Earth ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): orbital speed $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, while escaping from that radius needs $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – exactly $\sqrt2$ times the circular speed.

    Exam skill. Orbit FRQs are energy-and-angular-momentum problems in disguise: write $E=\tfrac12mv^2-\dfrac{GMm}{r}$ and $L=mvr\sin\theta$ at the two points of interest and solve the pair – never assume the orbit formulae for circles apply to an ellipse.

    Explore · ⁨Исследовать⁩

    Compare orbits at different radii · ⁨Сравните орбиты на разных радиусах⁩

    An orbiting satellite is in free fall, gravity supplying the centripetal force. A larger orbit means a slower speed and longer period (Kepler's third law). · ⁨Орбитирующий спутник находится в свободном падении, гравитация обеспечивает центростремительную силу. Большая орбита означает меньшую скорость и больший период (третий закон Кеплера).⁩

    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    centripetal force/senˈtrɪpɪtl fɔːs/ центробежная сила
    satellite/ˈsætəlaɪt/ спутник
    gravitational potential energy/ˌɡrævɪˈteɪʃənl pəˈtenʃl ˈenədʒi/ гравитационная потенциальная энергия
    total mechanical energy/ˈtəʊtl mɪˈkænɪkl ˈenədʒi/ полная механическая энергия
    escape velocity/eˈskeɪp vəˈlɒsɪti/ скорость убегания
    elliptical orbit/ɪˈlɪptɪkl ˈɔːbɪt/ эллиптическая орбита
    Kepler's second law/ˈkepləz ˈsekənd lɔː/ второй закон Кеплера
    6.6

    Exam tips

    • Compute the moment of inertia $I=\int r^2\,dm$ and shift axes with the parallel-axis theorem $I=I_{cm}+Md^2$.
    • Rotational kinetic energy is $\tfrac12 I\omega^2$; a rolling body has both translational and rotational KE.
    • Conserve angular momentum $L=I\omega$ when net external torque is zero (a spinning skater pulling in).
    • Use energy conservation for rolling-without-slipping problems ($v=r\omega$ ties the two motions).
    • Know standard $I$ values (hoop, disk, rod, sphere) and where the axis is.
  • 7

    Oscillations · ⁨Колебания⁩

    Watch lesson · ⁨Смотреть урок⁩
    7.1

    Defining Simple Harmonic Motion · ⁨Определение гармонических колебаний⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 7.1.A: Describe simple harmonic motion.

    • 7.1.A.1 Simple harmonic motion is a special case of periodic motion.
    • 7.1.A.2 SHM results when the magnitude of the restoring force exerted on an object is proportional to that object's displacement from its equilibrium position.
      • Derived equation: $ma_x = -k\Delta x$
      • 7.1.A.2.i A restoring force is a force that is exerted in a direction opposite to the object's displacement from an equilibrium position.
      • 7.1.A.2.ii An equilibrium position is a location at which the net force exerted on an object or system is zero.
    Русский

    Цель обучения 7.1.A: Описать простое гармоническое движение.

    • 7.1.A.1 Простое гармоническое движение — это частный случай периодического движения.
    • 7.1.A.2 ПГД возникает, когда модуль возвращающей силы, действующей на тело, пропорционален смещению этого тела от положения равновесия.
      • Выведенное уравнение: $ma_x = -k\Delta x$
      • 7.1.A.2.i Возвращающая сила — это сила, которая действует в направлении, противоположном смещению тела от положения равновесия.
      • 7.1.A.2.ii Положение равновесия — это место, в котором равнодействующая сила, действующая на тело или систему, равна нулю.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English
    Simple harmonic motion

    Simple harmonic motion 简谐运动 (SHM) is a special case of periodic motion 周期运动. It appears whenever two things are true: there is an equilibrium 平衡位置 position where the net force is zero, and displacing the object produces a restoring force 回复力 – a force pointing back toward equilibrium – whose magnitude is proportional to the displacement:

    $$F=-k\,\Delta x.$$

    Newton's second law then gives the defining differential equation 微分方程:

    $$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$

    Its solution is sinusoidal, $x(t)=A\cos(\omega t+\phi)$. You do not need to prove this solution – you need to recognise the equation: any system whose motion obeys "$\ddot{x}=-\omega^2x$" is a simple harmonic oscillator, whatever it is made of. (A mass hanging on a vertical spring works the same way: gravity only shifts the equilibrium point; the oscillation about it is unchanged.)

    Русский
    Гармонические колебания

    Механические колебания (SHM) — это частный случай периодического движения. Они возникают всегда, когда выполняются два условия: существует положение равновесия, где результирующая сила равна нулю, а смещение тела вызывает возвращающую силу — силу, направленную обратно к положению равновесия, модуль которой пропорциональна смещению:

    $$F=-k\,\Delta x.$$

    Второй закон Ньютона тогда дает определяющее дифференциальное уравнение:

    $$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$

    Его решение синусоидально, $x(t)=A\cos(\omega t+\phi)$. Вам не нужно доказывать это решение — вам нужно его узнать: любая система, движение которой подчиняется «$\ddot{x}=-\omega^2x$», является гармоническим осциллятором, какой бы ни была ее природа. (Масса, подвешенная на вертикальной пружине, ведет себя аналогичным образом: гравитация лишь смещает точку равновесия; колебания вокруг нее остаются неизменными.)

    В ПГК ускорение всегда направлено обратно к положению равновесия, противоположно смещению
    В ПГК ускорение всегда направлено обратно к положению равновесия, противоположно смещению
    7.2

    Frequency and Period of SHM · ⁨Частота и период ПГК⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 7.2.A: Describe the frequency and period of an object exhibiting SHM.

    • 7.2.A.1 The period of SHM is related to the angular frequency, $\omega$, of the object's motion by the following equation:
      • Equation: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
      • 7.2.A.1.i The period of an object–ideal-spring oscillator is given by the equation
        • Equation: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
      • 7.2.A.1.ii The period of a simple pendulum displaced by a small angle is given by the equation
        • Equation: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$
    Русский

    Цель обучения 7.2.A: Описать частоту и период объекта, совершающего ПГД.

    • 7.2.A.1 Период гармонических колебаний связан с угловой частотой $\omega$ движения объекта следующим уравнением:
      • Уравнение: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
      • 7.2.A.1.i Период осциллятора «объект–идеальная пружина» определяется уравнением
        • Уравнение: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
      • 7.2.A.1.ii Период маятника, отклоненного на малый угол, определяется уравнением
        • Уравнение: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    The angular frequency 角频率 $\omega$ sets the period 周期 and frequency 频率:

    $$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$

    For the two standard systems:

    $$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$

    Two classic conceptual traps: the period of SHM never depends on the amplitude 振幅, and each system ignores one obvious variable – the pendulum's period does not involve its mass, and the spring's period does not involve $g$ (a spring–block oscillator keeps perfect time in orbit; a pendulum clock does not).

    Русский

    Угловая частота $\omega$ определяет период и частоту:

    $$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$

    Для двух стандартных систем:

    $$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$

    Два классических концептуальных ловушки: период SHM никогда не зависит от амплитуды, и каждая система игнорирует одну очевидную переменную — период маятника не включает его массу, а период пружины не включает $g$ (пружинно-массовый осциллятор сохраняет идеальный ход в невесомости; маятниковые часы — нет).

    Explore · ⁨Исследовать⁩

    Time a pendulum's swing · ⁨Замерьте период маятника⁩

    A pendulum's period depends on its length and gravity, not its mass or (small) amplitude: $T=2\pi\sqrt{L/g}$. Lengthen it and each swing takes longer. · ⁨Период маятника зависит от его длины и ускорения свободного падения, но не от массы или (малой) амплитуды: $T=2\pi\sqrt{L/g}$. Увеличьте длину, и каждый взмах займет больше времени.⁩

    7.3

    Representing and Analyzing SHM · ⁨Представление и анализ ПГК⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 7.3.A: Describe the displacement, velocity, and acceleration of an object exhibiting SHM.

    • 7.3.A.1 For an object exhibiting SHM, the displacement of that object measured from its equilibrium position can be represented by the equations $x = A\cos(2\pi ft)$ or $x = A\sin(2\pi ft)$.
      • 7.3.A.1.i Minima, maxima, and zeros of displacement, velocity, and acceleration are features of harmonic motion.
      • 7.3.A.1.ii Recognizing the positions or times at which the displacement, velocity, and acceleration for SHM have extrema or zeros can help in qualitatively describing the behavior of the motion.
    • 7.3.A.2 The position as a function of time for an object exhibiting SHM is a solution of the second-order differential equation derived from the application of Newton's second law.
      • Derived equation: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
    • 7.3.A.3 Characteristics of SHM, such as velocity and acceleration, can be determined by or derived from the equation $x = A\cos(\omega t + \phi).$
      • 7.3.A.3.i The acceleration of an object exhibiting SHM is related to the object's angular frequency and position.
        • Derived equation: $a = -\omega^2 x$
      • 7.3.A.3.ii It can be shown that the maximum velocity and acceleration of an object exhibiting SHM are related to the angular frequency of the object's motion.
        • Derived equations: $v_{\max} = A\omega$
        • $a_{\max} = A\omega^2$
    • 7.3.A.4 In the presence of a sinusoidal external force, a system may exhibit resonance.
      • 7.3.A.4.i Resonance occurs when an external force is exerted at the natural frequency of an oscillating system.
      • 7.3.A.4.ii Resonance increases the amplitude of oscillating motion.
      • 7.3.A.4.iii The natural frequency of a system is the frequency at which the system will oscillate when it is displaced from its equilibrium position.
    • 7.3.A.5 Changing the amplitude of a system exhibiting SHM will not change its period.
    • 7.3.A.6 Properties of SHM can be determined and analyzed using graphical representations.

    Boundary statement: AP Physics C: Mechanics only expects students to know the solution to the second-order differential equation that describes SHM, as well as be able to identify SHM. AP Physics C: Mechanics does not expect students to mathematically prove that the solution is correct.

    Русский

    Цель обучения 7.3.A: Описать смещение, скорость и ускорение объекта, совершающего ПГД.

    • 7.3.A.1 Для объекта, совершающего ПГД, его смещение, измеренное от положения равновесия, может быть представлено уравнениями $x = A\cos(2\pi ft)$ или $x = A\sin(2\pi ft)$.
      • 7.3.A.1.i Минимумы, максимумы и нули смещения, скорости и ускорения являются характеристиками гармонического движения.
      • 7.3.A.1.ii Распознавание положений или моментов времени, когда смещение, скорость и ускорение для ПГД имеют экстремумы или равны нулю, помогает качественно описать поведение движения.
    • 7.3.A.2 Зависимость положения от времени для объекта, совершающего гармонические колебания, является решением дифференциального уравнения второго порядка, полученного путем применения второго закона Ньютона.
      • Выведенное уравнение: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
    • 7.3.A.3 Характеристики гармонических колебаний, такие как скорость и ускорение, могут быть определены или выведены из уравнения $x = A\cos(\omega t + \phi).$
      • 7.3.A.3.i Ускорение объекта, совершающего гармонические колебания, связано с угловой частотой объекта и его положением.
        • Выведенное уравнение: $a = -\omega^2 x$
      • 7.3.A.3.ii Можно показать, что максимальная скорость и ускорение объекта, совершающего гармонические колебания, связаны с угловой частотой движения объекта.
        • Выведенные уравнения: $v_{\max} = A\omega$
        • $a_{\max} = A\omega^2$
    • 7.3.A.4 В присутствии синусоидальной внешней силы система может проявлять резонанс.
      • 7.3.A.4.i Резонанс возникает, когда внешняя сила приложена с частотой, равной собственной частоте колебательной системы.
      • 7.3.A.4.ii Резонанс увеличивает амплитуду колебательного движения.
      • 7.3.A.4.iii Собственная частота системы — это частота, при которой система будет колебаться, если ее вывести из положения равновесия.
    • 7.3.A.5 Изменение амплитуды системы, совершающей гармонические колебания, не изменит её период.
    • 7.3.A.6 Свойства гармонических колебаний можно определить и проанализировать с помощью графических представлений.

    Граничное утверждение: AP Physics C: Mechanics ожидает, что студенты будут знать решение дифференциального уравнения второго порядка, описывающего гармонические колебания, а также смогут их идентифицировать. AP Physics C: Mechanics не требует от студентов математического доказательства правильности этого решения.

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    Differentiate $x(t)=A\cos(\omega t+\phi)$ twice:

    $$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$

    So at the ends of the swing ($x=\pm A$) the speed is zero and the acceleration is largest; passing through equilibrium ($x=0$) the acceleration is zero and the speed is largest, $v_{\max}=A\omega$. The amplitude $A$ and the phase constant 相位常数 $\phi$ come from the initial conditions: where the object starts and how fast it is moving. Eliminating $t$ (or using energy, below) gives speed as a function of position:

    $$v=\pm\,\omega\sqrt{A^2-x^2}.$$

    Worked example. A $0.50\ \text{kg}$ mass on a $k=200\ \text{N/m}$ spring: $\omega=\sqrt{k/m}=20\ \text{rad/s}$, $T=2\pi/\omega=0.31\ \text{s}$. With $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ at equilibrium, and at $x=0.050\ \text{m}$ the speed is $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.

    Русский

    Продифференцируйте $x(t)=A\cos(\omega t+\phi)$ дважды:

    $$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$

    Таким образом, на концах траектории ($x=\pm A$) скорость равна нулю, а ускорение максимально; при прохождении через положение равновесия ($x=0$) ускорение равно нулю, а скорость максимальна, $v_{\max}=A\omega$. Амплитуда $A$ и фазовая постоянная $\phi$ определяются начальными условиями: где находится тело и с какой скоростью оно движется. Исключив $t$ (или используя энергию ниже), получаем зависимость скорости от положения:

    $$v=\pm\,\omega\sqrt{A^2-x^2}.$$
    Смещение изменяется синусоидально во времени при простых гармонических колебаниях
    Перемещение изменяется синусоидально со временем при гармонических колебаниях

    Разобранный пример. Масса $0.50\ \text{kg}$ на пружине жёсткостью $k=200\ \text{N/m}$: $\omega=\sqrt{k/m}=20\ \text{rad/s}$, $T=2\pi/\omega=0.31\ \text{s}$. При $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ в положении равновесия, а при $x=0.050\ \text{m}$ скорость равна $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.

    7.4

    Energy of Simple Harmonic Oscillators · ⁨Энергия простых гармонических осцилляторов⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 7.4.A: Describe the mechanical energy of a system exhibiting SHM.

    • 7.4.A.1 The total energy of a system exhibiting SHM is the sum of the system's kinetic and potential energies.
      • Relevant equation: $E_{\text{total}} = U + K$
    • 7.4.A.2 Conservation of energy indicates that the total energy of a system exhibiting SHM is constant.
    • 7.4.A.3 The kinetic energy of a system exhibiting SHM is at a maximum when the system's potential energy is at a minimum.
    • 7.4.A.4 The potential energy of a system exhibiting SHM is at a maximum when the system's kinetic energy is at a minimum.
      • 7.4.A.4.i The minimum kinetic energy of a system exhibiting SHM is zero.
      • 7.4.A.4.ii Changing the amplitude of a system exhibiting SHM will change the maximum potential energy of the system and, therefore, the total energy of the system.
        • Relevant equation for a spring–object system: $E_{\text{total}} = \dfrac{1}{2}kA^2$
    Русский

    Цель обучения 7.4.A: Описать механическую энергию системы, совершающей ПГД.

    • 7.4.A.1 Полная энергия системы, совершающей ПГД, равна сумме кинетической и потенциальной энергий системы.
      • Соответствующее уравнение: $E_{\text{total}} = U + K$
    • 7.4.A.2 Закон сохранения энергии указывает на то, что полная энергия системы, совершающей ПГД, остается постоянной.
    • 7.4.A.3 Кинетическая энергия системы, совершающей ПГД, максимальна, когда потенциальная энергия системы минимальна.
    • 7.4.A.4 Потенциальная энергия системы, совершающей МП, максимальна, когда кинетическая энергия этой системы минимальна.
      • 7.4.A.4.i Минимальная кинетическая энергия системы, совершающей МП, равна нулю.
      • 7.4.A.4.ii Изменение амплитуды системы, совершающей МП, изменит максимальную потенциальную энергию системы и, следовательно, полную энергию системы.
        • Соответствующее уравнение для системы «пружина–объект»: $E_{\text{total}} = \dfrac{1}{2}kA^2$

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English

    The total energy of the oscillator is the sum $E=U+K$, and with no friction it is constant – energy just trades back and forth between the spring's potential energy and the mass's kinetic energy:

    $$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$

    All potential at the ends (where $K=0$), all kinetic at equilibrium (where $U$ is minimum). Because $E\propto A^2$, doubling the amplitude quadruples the energy.

    Worked example. Where is the energy split evenly? Set $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$, so $x=A/\sqrt2\approx0.71A$ – much closer to the end than to the middle. For the system above ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.

    Left alone, a system oscillates at its own natural frequency 固有频率 (set by $k$ and $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). Drive it with a periodic force at that same frequency and the amplitude grows dramatically – resonance 共振. Each well-timed push adds energy faster than damping removes it, so the driven amplitude peaks sharply when the driving frequency matches $f_0$ (a swing pumped in time, a bridge shaken by wind).

    Русский

    Полная энергия осциллятора равна сумме $E=U+K$, и при отсутствии трения она постоянна — энергия просто обменивается между потенциальной энергией пружины и кинетической энергией массы:

    $$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$

    Вся энергия сосредоточена на концах (где $K=0$), вся кинетическая энергия — в положении равновесия (где $U$ минимальна). Поскольку $E\propto A^2$, удвоение амплитуды увеличивает энергию в четыре раза.

    Обмен кинетической и потенциальной энергией в течение цикла при постоянной полной энергии
    Кинетическая и потенциальная энергия обмениваются друг с другом в течение одного цикла, при этом полная энергия остается постоянной

    Разобранный пример. Где энергия разделена поровну? Положите $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$, тогда $x=A/\sqrt2\approx0.71A$ — гораздо ближе к концу, чем к середине. Для системы выше ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.

    Сам по себе система колеблется со своей собственной частотой (определяемой $k$ и $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). Приведите её в действие периодической силой с той же частотой, и амплитуда резко возрастет — это резонанс. Каждое своевременное толчок добавляет энергию быстрее, чем затухание её рассеивает, поэтому вынужденная амплитуда достигает пика, когда вынуждающая частота совпадает с $f_0$ (качели, разгоняемые в ритме, мост, сотрясаемый ветром).

    Explore · ⁨Исследовать⁩

    Trade kinetic and potential energy in SHM · ⁨Обмен кинетической и потенциальной энергией при МП⁩

    In simple harmonic motion, energy sloshes between kinetic (fastest at the centre) and potential (greatest at the extremes) while the total stays constant. · ⁨При простом гармоническом движении энергия колеблется между кинетической (максимальной в центре) и потенциальной (наибольшей на краях), при этом общая энергия остается постоянной.⁩

    7.5

    Simple and Physical Pendulums · ⁨Математический и физический маятники⁩

    Syllabus · ⁨Программа⁩
    English

    Learning Objective 7.5.A: Describe the properties of a physical pendulum.

    • 7.5.A.1 A physical pendulum is a rigid body that undergoes oscillation about a fixed axis.
    • 7.5.A.2 For small amplitudes of motion, the period of a physical pendulum is derived from the application of Newton's second law in rotational form.
      • Relevant equation: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
      • 7.5.A.2.i When displaced from equilibrium, the gravitational force exerted on a physical pendulum's center of mass provides a restoring torque.
        • Derived equation: $\tau = -mgd\sin\theta$
      • 7.5.A.2.ii For small amplitudes of motion, the small-angle approximation can be applied to the restoring torque.
        • Derived equation: $\sin\theta \approx \theta$
        • $\tau = -mgd\theta = I\alpha$
      • 7.5.A.2.iii The small-angle approximation and Newton's second law in rotational form yield a second-order differential equation that describes SHM:
        • Equation: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
    • 7.5.A.3 A simple pendulum is a special case of physical pendulums in which the hanging object can be modeled as a point mass at a distance, $l$, from the pivot point.
      • Relevant equation: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
    • 7.5.A.4 A torsion pendulum is a case of SHM where the restoring torque is proportional to the angular displacement of a rotating system. For example, a horizontal disk that is suspended from a wire attached to its center of mass may undergo rotational oscillations about the wire in the horizontal plane.
      • Derived equation: $I\alpha = -k\Delta\theta$
    Русский

    Цель обучения 7.5.A: Описывать свойства физического маятника.

    • 7.5.A.1 Физический маятник — это твердое тело, которое совершает колебания вокруг фиксированной оси.
    • 7.5.A.2 Для малых амплитуд движения период физического маятника выводится из применения второго закона Ньютона в вращательной форме.
      • Соответствующее уравнение: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
      • 7.5.A.2.i При выводе из положения равновесия сила тяжести, действующая на центр масс физического маятника, создает возвращающий момент.
        • Выведенное уравнение: $\tau = -mgd\sin\theta$
      • 7.5.A.2.ii Для малых амплитуд движения к возвращающему моменту можно применить приближение малых углов.
        • Выведенное уравнение: $\sin\theta \approx \theta$
        • $\tau = -mgd\theta = I\alpha$
      • 7.5.A.2.iii Приближение малых углов и второй закон Ньютона в вращательной форме дают дифференциальное уравнение второго порядка, описывающее гармонические колебания:
        • Уравнение: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
    • 7.5.A.3 Простой маятник — это частный случай физических маятников, в котором подвешенный объект можно моделировать как точечную массу на расстоянии $l$ от точки подвеса.
      • Соответствующее уравнение: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
    • 7.5.A.4 Торсионный маятник — это случай гармонических колебаний, при котором возвращающий момент пропорционален углу поворота вращающейся системы. Например, горизонтальный диск, подвешенный на проводе, прикрепленном к его центру масс, может совершать вращательные колебания вокруг провода в горизонтальной плоскости.
      • Выведенное уравнение: $I\alpha = -k\Delta\theta$

    Source: College Board AP Course and Exam Description · ⁨Источник: Описание курса и экзамена College Board AP⁩

    English
    Energy conservation: KE ⇄ PE

    A physical pendulum 物理摆 is any rigid body swinging about a fixed pivot. Displace it by an angle $\theta$ and gravity, acting at the center of mass a distance $d$ from the pivot, supplies a restoring torque

    $$\tau=-mgd\sin\theta.$$

    For small angles, apply the small-angle approximation 小角度近似 $\sin\theta\approx\theta$ and Newton's second law in rotational form ($\tau=I\alpha$):

    $$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$

    This is the same "$\ddot\theta=-\omega^2\theta$" pattern as before – recognising it is the derivation. A simple pendulum 单摆 is the special case of a point mass on a light string: $I=m\ell^2$ and $d=\ell$ give $T=2\pi\sqrt{\ell/g}$.

    Worked example. A uniform rod (mass $M$, length $L$) swings from one end: $I=\tfrac13ML^2$, $d=\tfrac{L}{2}$, so

    $$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$

    – shorter than a simple pendulum of length $L$, because the rod's mass sits nearer the pivot.

    A torsion pendulum 扭摆 – a disk hanging from a wire that twists – is SHM one more time: the wire's restoring torque is proportional to the twist angle, $I\alpha=-\kappa\,\Delta\theta$, giving $T=2\pi\sqrt{I/\kappa}$.

    Exam skill. Every pendulum FRQ wants the same three steps: write the restoring torque about the pivot, apply the small-angle approximation, and match the result to $\ddot\theta=-\omega^2\theta$ to read off $\omega$. State the small-angle step explicitly – it is a scored point, and it is why large-amplitude swings are not simple harmonic.

    Русский
    Сохранение энергии: KE ⇄ PE

    Физический маятник — это любое жесткое тело, совершающее колебания вокруг неподвижной точки опоры. Отклоните его на угол $\theta$, и гравитация, действующая в центре масс на расстоянии $d$ от точки опоры, создаст возвращающий момент.

    $$\tau=-mgd\sin\theta.$$

    Для малых углов примените приближение малых углов $\sin\theta\approx\theta$ и второй закон Ньютона в вращательной форме ($\tau=I\alpha$):

    $$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$

    Это та же схема «$\ddot\theta=-\omega^2\theta$», что и раньше — узнавание этого паттерна и есть вывод. Математический маятник — это частный случай точечной массы на невесомой нити: $I=m\ell^2$ и $d=\ell$ дают $T=2\pi\sqrt{\ell/g}$.

    Гравитация, действующая в центре масс, создает возвращающий момент физического маятника
    Гравитация, действующая в центре масс, создает возвращающий момент физического маятника

    Разобранный пример. Равномерный стержень (масса $M$, длина $L$) качается от одного конца: $I=\tfrac13ML^2$, $d=\tfrac{L}{2}$, поэтому

    $$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$

    — короче, чем математический маятник длины $L$, потому что масса стержня расположена ближе к точке опоры.

    Крутильный маятник — диск, подвешенный на проводе, который закручивается, — снова демонстрирует SHM: возвращающий момент провода пропорционален углу закручивания, $I\alpha=-\kappa\,\Delta\theta$, что дает $T=2\pi\sqrt{I/\kappa}$.

    Навык для экзамена. Каждая задача FRQ про маятник требует тех же трех шагов: записать возвращающий момент относительно точки опоры, применить приближение малых углов и сравнить результат с $\ddot\theta=-\omega^2\theta$, чтобы считать $\omega$. Явно укажите шаг приближения малых углов — это балл, и именно поэтому колебания с большой амплитудой не являются простыми гармоническими.

    Большой маятник Фуко, покачивающийся над размеченным полом
    Маятник Фуко: длинный тяжелый маятник, медленные качания которого обнажают вращение Земли под ним
    Vocabulary · ⁨Словарь⁩ Train · ⁨Тренировать⁩
    English Русский
    Simple harmonic motion/ˈsɪmpl hɑːˈmɒnɪk ˈməʊʃn/ Простое гармоническое движение
    periodic motion/ˌpɪərɪˈɒdɪk ˈməʊʃn/ периодическое движение
    equilibrium/ˌiːkwɪˈlɪbrɪəm/ равновесные
    restoring force/rɪˈstɔːrɪŋ fɔːs/ возвращающая сила
    differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ дифференциальное уравнение
    angular frequency/ˈæŋɡjʊlə ˈfriːkwənsi/ угловая частота
    period/ˈpɪərɪəd/ периода
    frequency/ˈfriːkwənsi/ частоту
    amplitude/ˈæmplɪtjuːd/ точке амплитуды
    phase constant/feɪz ˈkɒnstənt/ начальная фаза (постоянная фазы)
    natural frequency/ˈnætʃərəl ˈfriːkwənsi/ собственная частота
    resonance/ˈrezənəns/ резонансом
    physical pendulum/ˈfɪzɪkl ˈpendjʊləm/ физический маятник
    small-angle approximation/smɔːl ˈæŋɡl əˌprɒksɪˈmeɪʃn/ приближение малых углов
    simple pendulum/ˈsɪmpl ˈpendjʊləm/ простой маятник
    torsion pendulum/ˈtɔːʃn ˈpendjʊləm/ крутильный маятник
    7.5

    Exam tips · ⁨Советы для экзамена⁩

    English
    • Identify SHM from a linear restoring force $F=-kx$, which gives $\tfrac{d^2x}{dt^2}=-\omega^2 x$ with $\omega=\sqrt{k/m}$.
    • Write the solution $x=A\cos(\omega t+\phi)$ and get $v,a$ by differentiating; period $T=\tfrac{2\pi}{\omega}$ is amplitude-independent.
    • Energy trades between $\tfrac12 kx^2$ and $\tfrac12 mv^2$, with total $\tfrac12 kA^2$.
    • For a pendulum, use the small-angle approximation $\sin\theta\approx\theta$ to reach SHM.
    • Match phase to the start: released from rest at maximum displacement uses cosine.
    Русский
    • Распознайте SHM по линейной возвращающей силе $F=-kx$, которая дает $\tfrac{d^2x}{dt^2}=-\omega^2 x$ с $\omega=\sqrt{k/m}$.
    • Запишите решение $x=A\cos(\omega t+\phi)$ и найдите $v,a$ дифференцированием; период $T=\tfrac{2\pi}{\omega}$ не зависит от амплитуды.
    • Энергия обменивается между $\tfrac12 kx^2$ и $\tfrac12 mv^2$, общая сумма $\tfrac12 kA^2$.
    • Для маятника используйте приближение малых углов $\sin\theta\approx\theta$ для получения SHM.
    • Скорректируйте фазу под начальное состояние: отпуск из состояния покоя в точке максимального смещения использует косинус.

Log in or create account · ⁨Войти или создать аккаунт⁩

IGCSE, A-Level & AP