Skip to content · ⁨Lompat ke konten⁩
Subjects · ⁨Materi⁩

AP Physics C: Mechanics · ⁨AP Fisika C: Mekanika⁩

Tips

AP Physics C: Mechanics is the calculus-based version: kinematics, forces, work, energy and power, momentum, torque and rotation, and oscillations. It covers less ground than Physics 1 but goes much deeper, and calculus is not decoration — it is how the results are derived and how the exam expects them to be used.

In practice: integrate to get a total from a varying quantity, and differentiate from position to velocity to acceleration, comfortably and without being prompted.

Rotational dynamics is where time goes, because moments of inertia must be set up as integrals rather than recalled.

The notes take each unit in CED order with the calculus set out in full. Released past papers and scoring guidelines sit in the library. Because so many marks ride on the setup rather than the arithmetic, the worked examples deliberately show the integral being built before it is evaluated.

  • 1

    Kinematics · ⁨Kinematika⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    1.1

    Scalars and Vectors

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 1.1.A: Describe a scalar or vector quantity using magnitude and direction, as appropriate.

    • 1.1.A.1 Scalars are quantities described by magnitude only; vectors are quantities described by both magnitude and direction.
    • 1.1.A.2 Vectors can be visually modeled as arrows with appropriate direction and lengths proportional to their magnitude.
    • 1.1.A.3 Distance and speed are examples of scalar quantities, while position, displacement, velocity, and acceleration are examples of vector quantities.
    • 1.1.A.4 Vectors can be expressed in unit vector notation or as a magnitude and a direction.
      • 1.1.A.4.i Unit vector notation can be used to represent vectors as the sum of their constituent components in the $x$-, $y$-, and $z$-directions, denoted by $\hat{i}$, $\hat{j}$, and $\hat{k}$, respectively.
        • Equation: $\vec{r} = \left( A\hat{i} + B\hat{j} + C\hat{k} \right)$
      • 1.1.A.4.ii The position vector of a point is given by $\vec{r}$, and the unit vector in the direction of the position vector is denoted $\hat{r}$.
      • 1.1.A.4.iii A resultant vector is the vector sum of the addend vectors' components.
        • Equation: $\vec{C} = \vec{A} + \vec{B}$
        • Equation: $\vec{C} = \left( A_x + B_x \right)\hat{i} + \left( A_y + B_y \right)\hat{j}$
    • 1.1.A.5 In a given one-dimensional coordinate system, opposite directions are denoted by opposite signs.
    Bahasa Indonesia

    Tujuan Pembelajaran 1.1.A: Deskripsikan besaran skalar atau vektor menggunakan magnitudo dan arah, sesuai dengan kebutuhan.

    • 1.1.A.1 Skalar adalah besaran yang dijelaskan hanya oleh magnitudo; vektor adalah besaran yang dijelaskan oleh magnitudo dan arah.
    • 1.1.A.2 Vektor dapat dimodelkan secara visual sebagai panah dengan arah yang sesuai dan panjang yang proporsional terhadap magnitudonya.
    • 1.1.A.3 Jarak dan kecepatan adalah contoh besaran skalar, sedangkan posisi, perpindahan, kecepatan, dan percepatan adalah contoh besaran vektor.
    • 1.1.A.4 Vektor dapat dinyatakan dalam notasi vektor satuan atau sebagai besaran dan arah.
      • 1.1.A.4.i Notasi vektor satuan dapat digunakan untuk merepresentasikan vektor sebagai jumlah dari komponen-komponen penyusunnya dalam arah $x$-, $y$-, dan $z$-, yang dilambangkan dengan $\hat{i}$, $\hat{j}$, dan $\hat{k}$, berturut-turut.
        • Persamaan: $\vec{r} = \left( A\hat{i} + B\hat{j} + C\hat{k} \right)$
      • 1.1.A.4.ii Vektor posisi suatu titik diberikan oleh $\vec{r}$, dan vektor satuan dalam arah vektor posisi dilambangkan $\hat{r}$.
      • 1.1.A.4.iii Vektor resultan adalah penjumlahan vektor dari komponen-komponen vektor-vektor penjumlah.
        • Persamaan: $\vec{C} = \vec{A} + \vec{B}$
        • Persamaan: $\vec{C} = \left( A_x + B_x \right)\hat{i} + \left( A_y + B_y \right)\hat{j}$
    • 1.1.A.5 Dalam sistem koordinat satu dimensi yang diberikan, arah berlawanan ditandai dengan tanda yang berlawanan.
    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Kinematics 运动学 describes motion. Two kinds of quantity:

    • A scalar 标量 has only size (magnitude 大小): distance, speed, mass, time.
    • A vector 矢量 has magnitude and direction: displacement, velocity, acceleration, force.

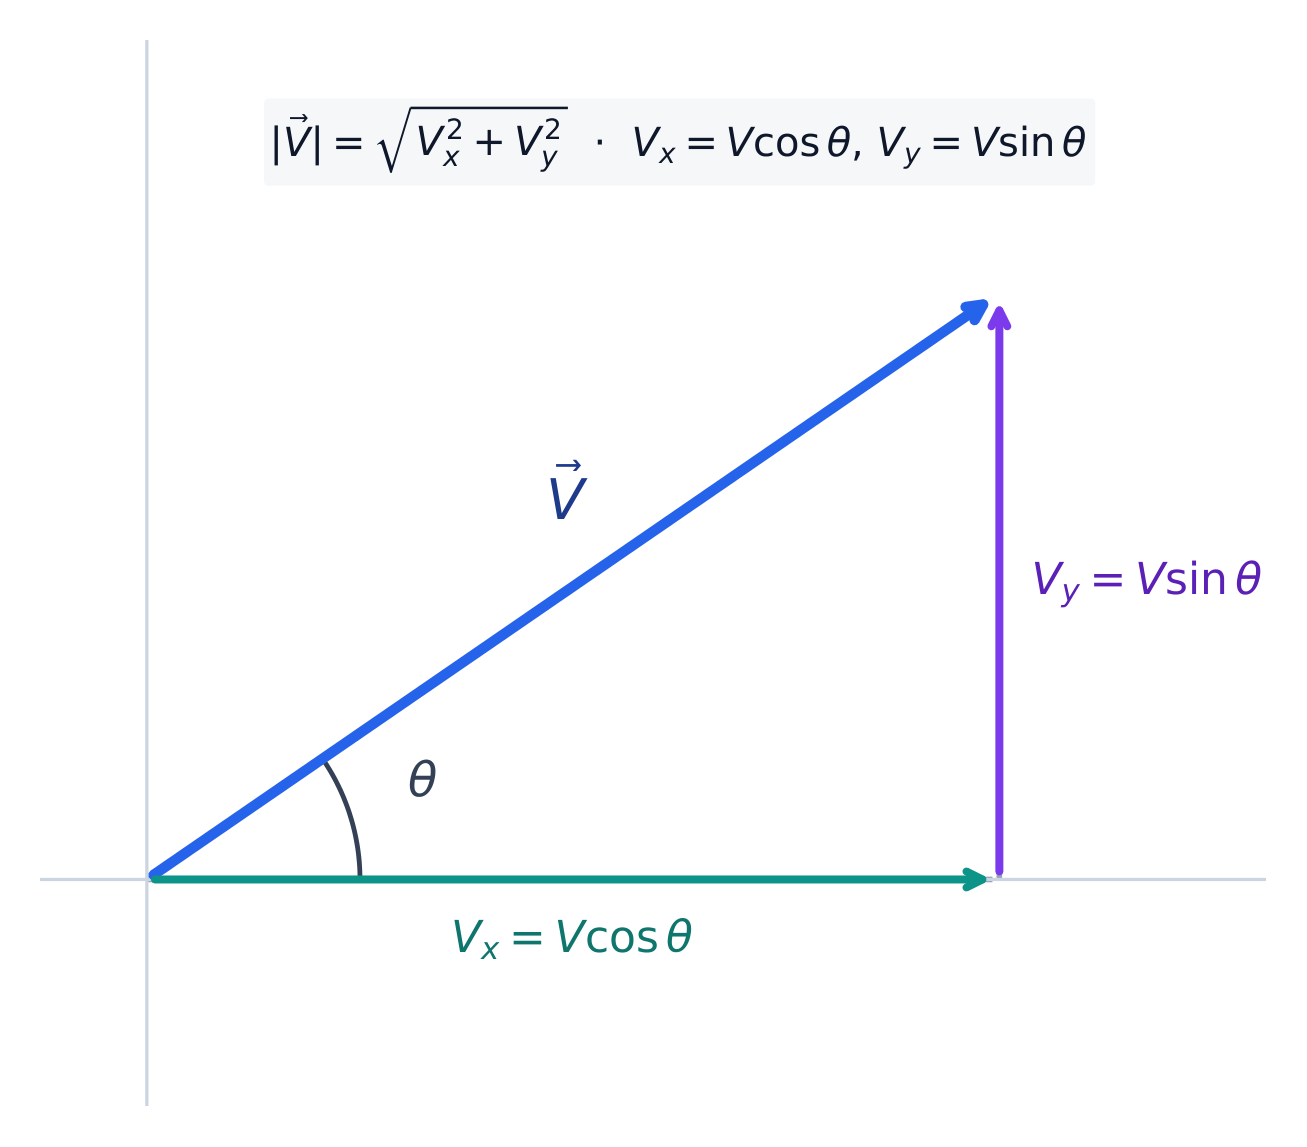
    In this calculus-based course you resolve vectors into components 分量 and add them component by component; a vector's magnitude is $\sqrt{v_x^2+v_y^2+\cdots}$. Physics C also writes vectors with unit vectors 单位矢量: $\vec{v}=v_x\hat{i}+v_y\hat{j}$, where $\hat{i}$ and $\hat{j}$ are directions of length one along $x$ and $y$ – handy because calculus can then act on each component separately.

    Resolving a vector into its x and y components
    Resolving a vector into its x and y components
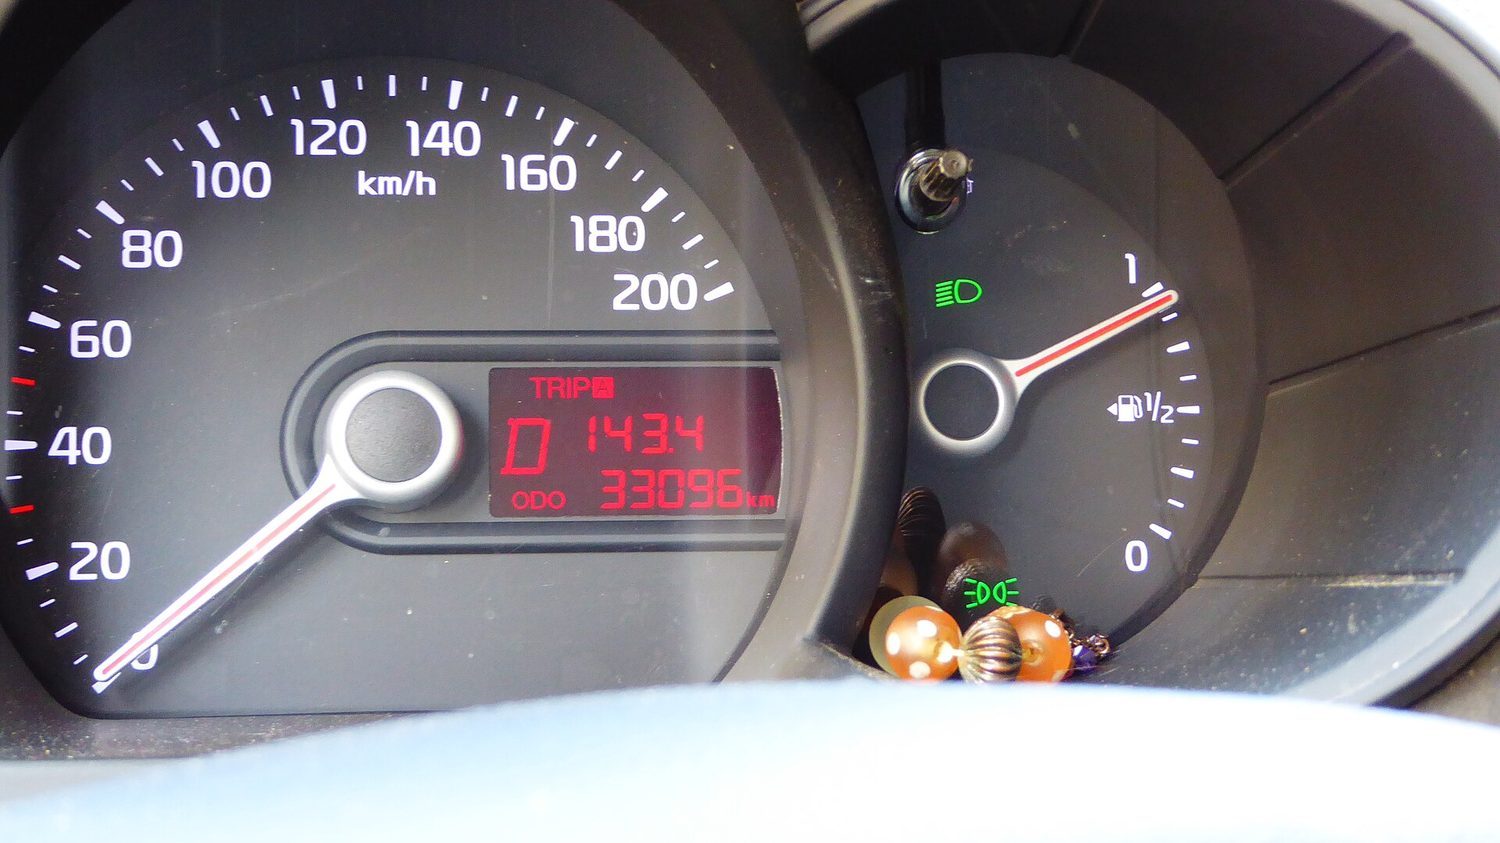
    A car speedometer: speed is the magnitude of velocity — a scalar rate of motion
    A car speedometer: speed is the magnitude of velocity — a scalar rate of motion
    Explore · ⁨Jelajahi⁩

    Explore the dot product · ⁨Jelajahi hasil kali titik⁩

    Drag the components of $\vec{A}$ and $\vec{B}$. The dot product $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ reaches zero exactly when the two vectors are perpendicular — the geometry behind $\cos\theta$. · ⁨Tarik komponen $\vec{A}$ dan $\vec{B}$. Hasil kali titik $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ mencapai nol tepat ketika dua vektor tegak lurus — geometri di balik $\cos\theta$.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Kinematics/ˌkɪnɪˈmætɪks/ Kinematika
    scalar/ˈskeɪlə/ skalar
    magnitude/ˈmæɡnɪtjuːd/ besarnya
    vector/ˈvektə/ vektor
    components/kəmˈpəʊnənts/ komponen
    unit vectors/ˈjuːnɪt ˈvektəz/ Vektor satuan
    1.2

    Displacement, Velocity, and Acceleration

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 1.2.A: Describe a change in an object's position.

    • 1.2.A.1 When using the object model, the size, shape, and internal configuration are ignored. The object may be treated as a single point with extensive properties such as mass and charge.
    • 1.2.A.2 Displacement is the change in an object's position.
      • Equation: $\Delta x = x - x_0$

    Learning Objective 1.2.B: Describe the average velocity and acceleration of an object.

    • 1.2.B.1 Averages of velocity and acceleration are calculated considering the initial and final states of an object over an interval of time.
    • 1.2.B.2 Average velocity is the displacement of an object divided by the interval of time in which that displacement occurs.
      • Equation: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
    • 1.2.B.3 Average acceleration is the change in velocity divided by the interval of time in which that change in velocity occurs.
      • Equation: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
    • 1.2.B.4 An object is accelerating if either the magnitude and/or direction of the object's velocity are changing.
    • 1.2.B.5 Calculating average velocity or average acceleration over a very small time interval yields a value that is very close to the instantaneous velocity or instantaneous acceleration.

    Learning Objective 1.2.C: Describe the instantaneous position, velocity, and acceleration of an object as a function of time.

    • 1.2.C.1 As the time interval used to calculate the average value of a quantity approaches zero, the average value of that quantity approaches the value of the quantity at that instant, called the instantaneous value.
      • 1.2.C.1.i Instantaneous velocity is the rate of change of the object's position, which is equal to the derivative of position with respect to time.
        • Equation: $\vec{v} = \dfrac{d\vec{r}}{dt}$
        • Equation: $v_x = \dfrac{dx}{dt}$
      • 1.2.C.1.ii Instantaneous acceleration is the rate of change of the object's velocity, which is equal to the derivative of velocity with respect to time.
        • Equation: $\vec{a} = \dfrac{d\vec{v}}{dt}$
        • Equation: $a_x = \dfrac{dv_x}{dt}$
    • 1.2.C.2 Time-dependent functions and instantaneous values of position, velocity, and acceleration can be determined using differentiation and integration.
    Bahasa Indonesia

    Tujuan Pembelajaran 1.2.A: Deskripsikan perubahan posisi suatu benda.

    • 1.2.A.1 Saat menggunakan model benda, ukuran, bentuk, dan konfigurasi internal diabaikan. Benda dapat diperlakukan sebagai titik tunggal dengan sifat ekstensif seperti massa dan muatan.
    • 1.2.A.2 Perpindahan adalah perubahan posisi suatu benda.
      • Persamaan: $\Delta x = x - x_0$

    Tujuan Pembelajaran 1.2.B: Deskripsikan kecepatan rata-rata dan percepatan rata-rata suatu benda.

    • 1.2.B.1 Rata-rata kecepatan dan percepatan dihitung dengan mempertimbangkan keadaan awal dan akhir suatu benda selama interval waktu tertentu.
    • 1.2.B.2 Kecepatan rata-rata adalah perpindahan suatu benda dibagi dengan interval waktu di mana perpindahan itu terjadi.
      • Persamaan: $\vec{v}_{\text{avg}} = \dfrac{\Delta \vec{x}}{\Delta t}$
    • 1.2.B.3 Percepatan rata-rata adalah perubahan kecepatan dibagi dengan interval waktu di mana perubahan kecepatan itu terjadi.
      • Persamaan: $\vec{a}_{\text{avg}} = \dfrac{\Delta \vec{v}}{\Delta t}$
    • 1.2.B.4 Suatu benda dipercepat jika baik besaran dan/atau arah kecepatan benda tersebut sedang berubah.
    • 1.2.B.5 Menghitung kecepatan rata-rata atau percepatan rata-rata selama interval waktu yang sangat kecil menghasilkan nilai yang sangat dekat dengan kecepatan sesaat atau percepatan sesaat.

    Tujuan Pembelajaran 1.2.C: Deskripsikan posisi, kecepatan, dan percepatan sesaat dari suatu benda sebagai fungsi waktu.

    • 1.2.C.1 Seiring dengan selang waktu yang digunakan untuk menghitung nilai rata-rata suatu besaran mendekati nol, nilai rata-rata besaran tersebut mendekati nilai besaran pada saat itu, yang disebut nilai sesaat.
      • 1.2.C.1.i Kecepatan sesaat adalah laju perubahan posisi benda, yang sama dengan turunan posisi terhadap waktu.
        • Persamaan: $\vec{v} = \dfrac{d\vec{r}}{dt}$
        • Persamaan: $v_x = \dfrac{dx}{dt}$
      • 1.2.C.1.ii Percepatan sesaat adalah laju perubahan kecepatan benda, yang sama dengan turunan kecepatan terhadap waktu.
        • Persamaan: $\vec{a} = \dfrac{d\vec{v}}{dt}$
        • Persamaan: $a_x = \dfrac{dv_x}{dt}$
    • 1.2.C.2 Fungsi-fungsi yang bergantung pada waktu dan nilai-nilai sesaat dari posisi, kecepatan, dan percepatan dapat ditentukan menggunakan diferensiasi dan integrasi.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Projectile motion is two independent motions

    Because motion can change continuously, define the rates as derivatives 导数:

    $$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$
    Reversing this, integrate to recover velocity and position:
    $$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$
    Distinguish the average from the instantaneous: average velocity 平均速度 is $\Delta x/\Delta t$ over an interval, while instantaneous velocity 瞬时速度 is the derivative at one moment – the slope of the tangent line, and what a speedometer shows.

    For constant acceleration these give the familiar kinematic equations ($v=v_0+at$, $x=x_0+v_0t+\tfrac12at^2$, $v^2=v_0^2+2a\,\Delta x$). The most important constant-$a$ case is free fall 自由落体: near Earth's surface every object, heavy or light, accelerates downward at $g=9.8\ \text{m/s}^2$ once air resistance is negligible. When $a$ or $v$ varies with time, use the integrals directly.

    Worked example. A particle moves with $x(t)=2t^3-3t^2$ (metres). Differentiate for velocity and acceleration:

    $$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$
    At $t=2\ \text{s}$, $v=24-12=12\ \text{m/s}$ and $a=24-6=18\ \text{m/s}^2$. This calculus link – not just the constant-$a$ formulas – is what distinguishes Physics C.

    Worked example. A particle starts from rest at the origin with $a(t)=6t$. Integrate: $v=\int 6t\,dt=3t^2$ and $x=\int 3t^2\,dt=t^3$. At $t=2\ \text{s}$, $v=12\ \text{m/s}$ and $x=8\ \text{m}$.

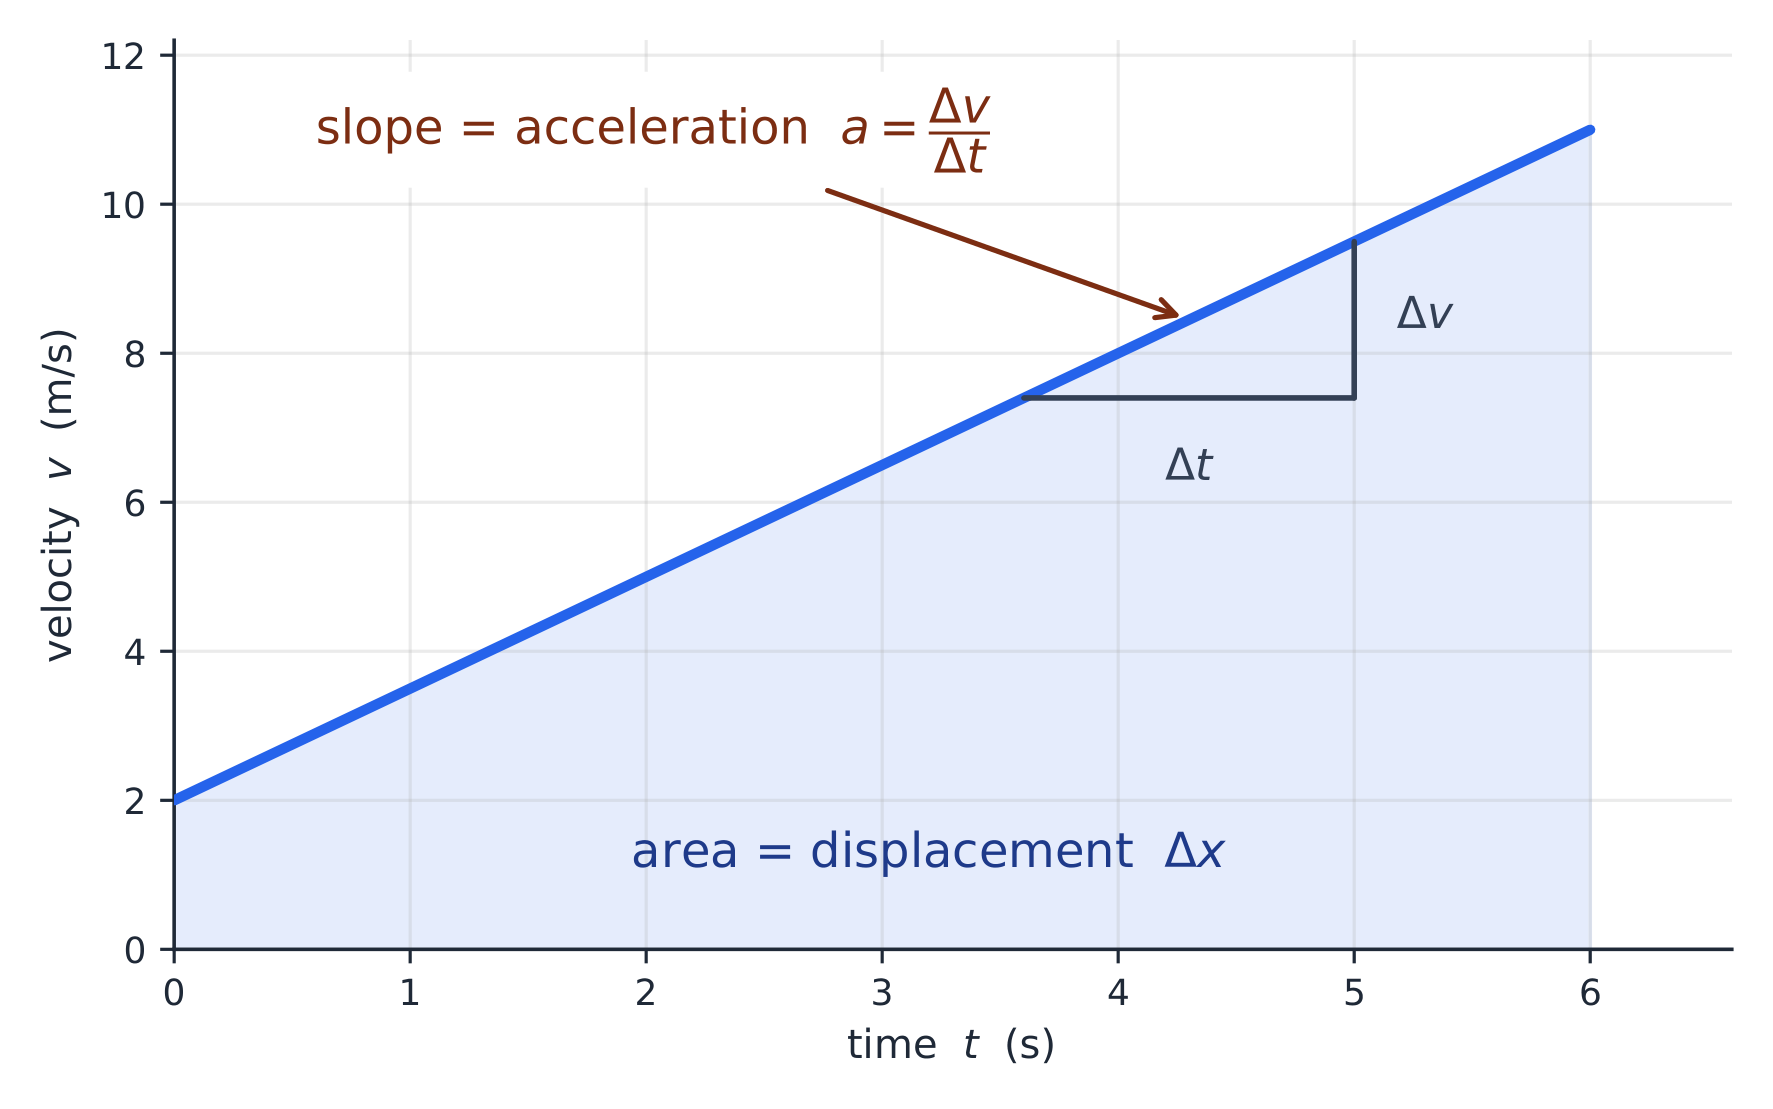
    On a velocity-time graph the gradient is the acceleration and the area is the displacement
    On a velocity-time graph the gradient is the acceleration and the area is the displacement
    A high-speed train: kinematics describes displacement, velocity and acceleration over time
    A high-speed train: kinematics describes displacement, velocity and acceleration over time
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    derivatives/dɪˈrɪvətɪvz/ turunannya
    average velocity/ˈævrɪdʒ vəˈlɒsɪti/ kecepatan rata-rata
    instantaneous velocity/ˌɪnstənˈteɪnɪəs vəˈlɒsɪti/ kecepatan sesaat
    free fall/friː fɔːl/ jatuh bebas
    1.3

    Representing Motion

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 1.3.A: Describe the position, velocity, and acceleration of an object using representations of that object's motion.

    • 1.3.A.1 Motion can be represented by motion diagrams, figures, graphs, equations, and narrative descriptions.
    • 1.3.A.2 For constant acceleration, three kinematic equations can be used to describe instantaneous linear motion in one dimension:
      • Equation: $v_x = v_{x0} + a_x t$
      • Equation: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
      • Equation: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
      • Note: The equations above are written to indicate motion in the $x$-direction, but these equations can be used in any single dimension as appropriate.
    • 1.3.A.3 Near the surface of Earth, the vertical acceleration caused by the force of gravity is downward, constant, and has a measured value approximately equal to
      • Equation: $a_g = g \approx 10 \ \text{m/s}^2$.
    • 1.3.A.4 Graphs of position, velocity, and acceleration as functions of time can be used to find the relationships between those quantities.
      • 1.3.A.4.i An object's instantaneous velocity is the rate of change of the object's position, which is equal to the slope of a line tangent to a point on a graph of the object's position as a function of time.
        • Equation: $v_x = \dfrac{dx}{dt}$
      • 1.3.A.4.ii An object's instantaneous acceleration is the rate of change of the object's velocity, which is equal to the slope of a line tangent to a point on a graph of the object's velocity as a function of time.
        • Equation: $a_x = \dfrac{dv_x}{dt}$
      • 1.3.A.4.iii The displacement of an object during a time interval is equal to the area under the curve of a graph of the object's velocity as a function of time (i.e., the area bounded by the function and the horizontal axis for the appropriate interval).
        • Equation: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
      • 1.3.A.4.iv The change in velocity of an object during a time interval is equal to the area under the curve of a graph of the acceleration of the object as a function of time.
        • Equation: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$

    Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism expects that for all situations in which a numerical quantity is required for g, the value $g \approx 10 \ \text{m/s}^2$ will be used. However, students will not be penalized for correctly using the more precise commonly accepted values of $g = 9.81 \ \text{m/s}^2$ or $g = 9.8 \ \text{m/s}^2$.

    Bahasa Indonesia

    Tujuan Pembelajaran 1.3.A: Deskripsikan posisi, kecepatan, dan percepatan suatu benda menggunakan representasi gerak benda tersebut.

    • 1.3.A.1 Gerak dapat direpresentasikan melalui diagram gerak, gambar, grafik, persamaan, dan deskripsi naratif.
    • 1.3.A.2 Untuk percepatan konstan, tiga persamaan kinematika dapat digunakan untuk menggambarkan gerak linear sesaat dalam satu dimensi:
      • Persamaan: $v_x = v_{x0} + a_x t$
      • Persamaan: $x = x_0 + v_{x0} t + \dfrac{1}{2} a_x t^2$
      • Persamaan: $v_x^2 = v_{x0}^2 + 2a_x \left( x - x_0 \right)$
      • Catatan: Persamaan-persamaan di atas ditulis untuk menunjukkan gerak dalam arah $x$, tetapi persamaan-persamaan ini dapat digunakan dalam satu dimensi mana pun sesuai kebutuhan.
    • 1.3.A.3 Di dekat permukaan Bumi, percepatan vertikal yang disebabkan oleh gaya gravitasi mengarah ke bawah, konstan, dan memiliki nilai terukur sekitar sama dengan
      • Persamaan: $a_g = g \approx 10 \ \text{m/s}^2$.
    • 1.3.A.4 Grafik posisi, kecepatan, dan percepatan sebagai fungsi waktu dapat digunakan untuk menemukan hubungan antar besaran-besaran tersebut.
      • 1.3.A.4.i Kecepatan sesuat benda adalah laju perubahan posisi benda tersebut, yang sama dengan kemiringan garis tangen pada sebuah titik di grafik posisi benda sebagai fungsi waktu.
        • Persamaan: $v_x = \dfrac{dx}{dt}$
      • 1.3.A.4.ii Percepatan sesuat benda adalah laju perubahan kecepatan benda tersebut, yang sama dengan kemiringan garis tangen pada sebuah titik di grafik kecepatan benda sebagai fungsi waktu.
        • Persamaan: $a_x = \dfrac{dv_x}{dt}$
      • 1.3.A.4.iii Perpindahan suatu benda selama interval waktu sama dengan luas di bawah kurva grafik kecepatan benda sebagai fungsi waktu (yaitu, area yang dibatasi oleh fungsi dan sumbu horizontal untuk interval yang sesuai).
        • Persamaan: $\Delta x = \displaystyle\int_{t_1}^{t_2} v_x(t) \ dt$
      • 1.3.A.4.iv Perubahan kecepatan suatu benda selama interval waktu sama dengan luas di bawah kurva grafik percepatan benda sebagai fungsi waktu.
        • Persamaan: $\Delta v_x = \displaystyle\int_{t_1}^{t_2} a_x(t) \ dt$

    Pernyataan Batasan: AP Physics C: Mekanika dan AP Physics C: Listrik dan Magnetisme mengharapkan bahwa untuk semua situasi di mana besaran numerik diperlukan untuk g, nilai $g \approx 10 \ \text{m/s}^2$ akan digunakan. Namun, siswa tidak akan didiskualifikasi karena secara benar menggunakan nilai yang lebih presisi yang umumnya diterima dari $g = 9.81 \ \text{m/s}^2$ atau $g = 9.8 \ \text{m/s}^2$.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Move fluently between description, graph, table, and equation:

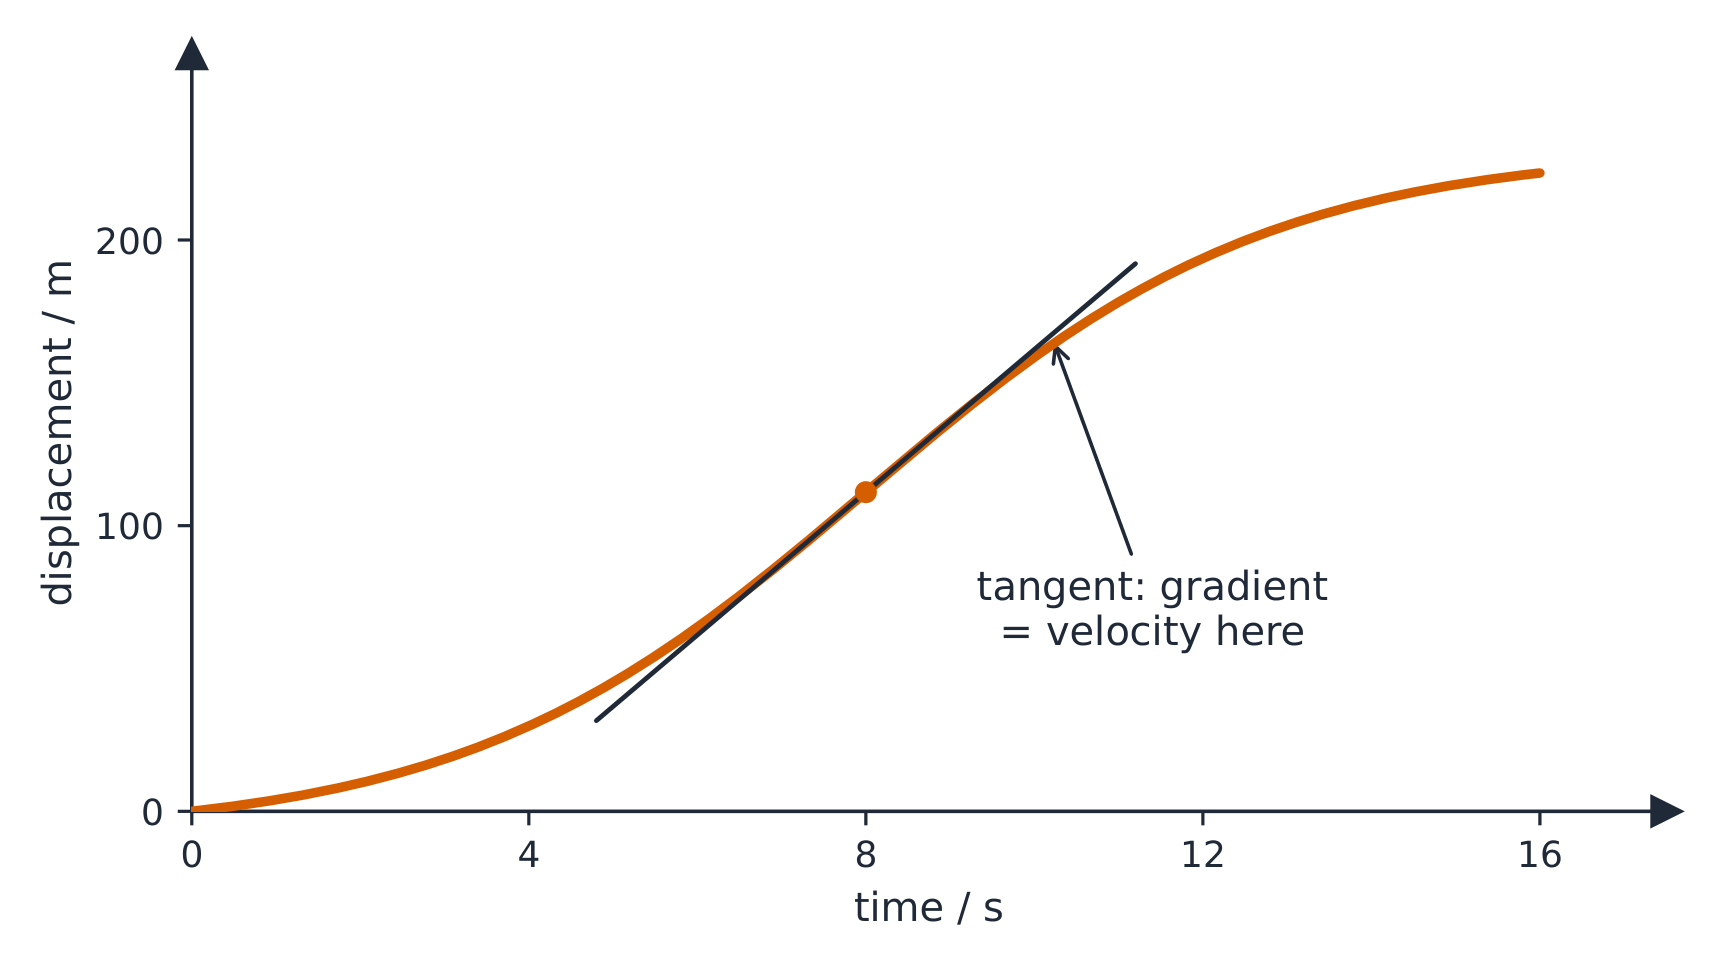
    A displacement-time graph: the slope at any instant is the velocity
    A displacement-time graph: the slope at any instant is the velocity
    • On a position–time graph, the slope ($dx/dt$) is velocity.
    • On a velocity–time graph, the slope is acceleration and the area ($\int v\,dt$) is displacement.
    • On an acceleration–time graph, the area ($\int a\,dt$) is the change in velocity.

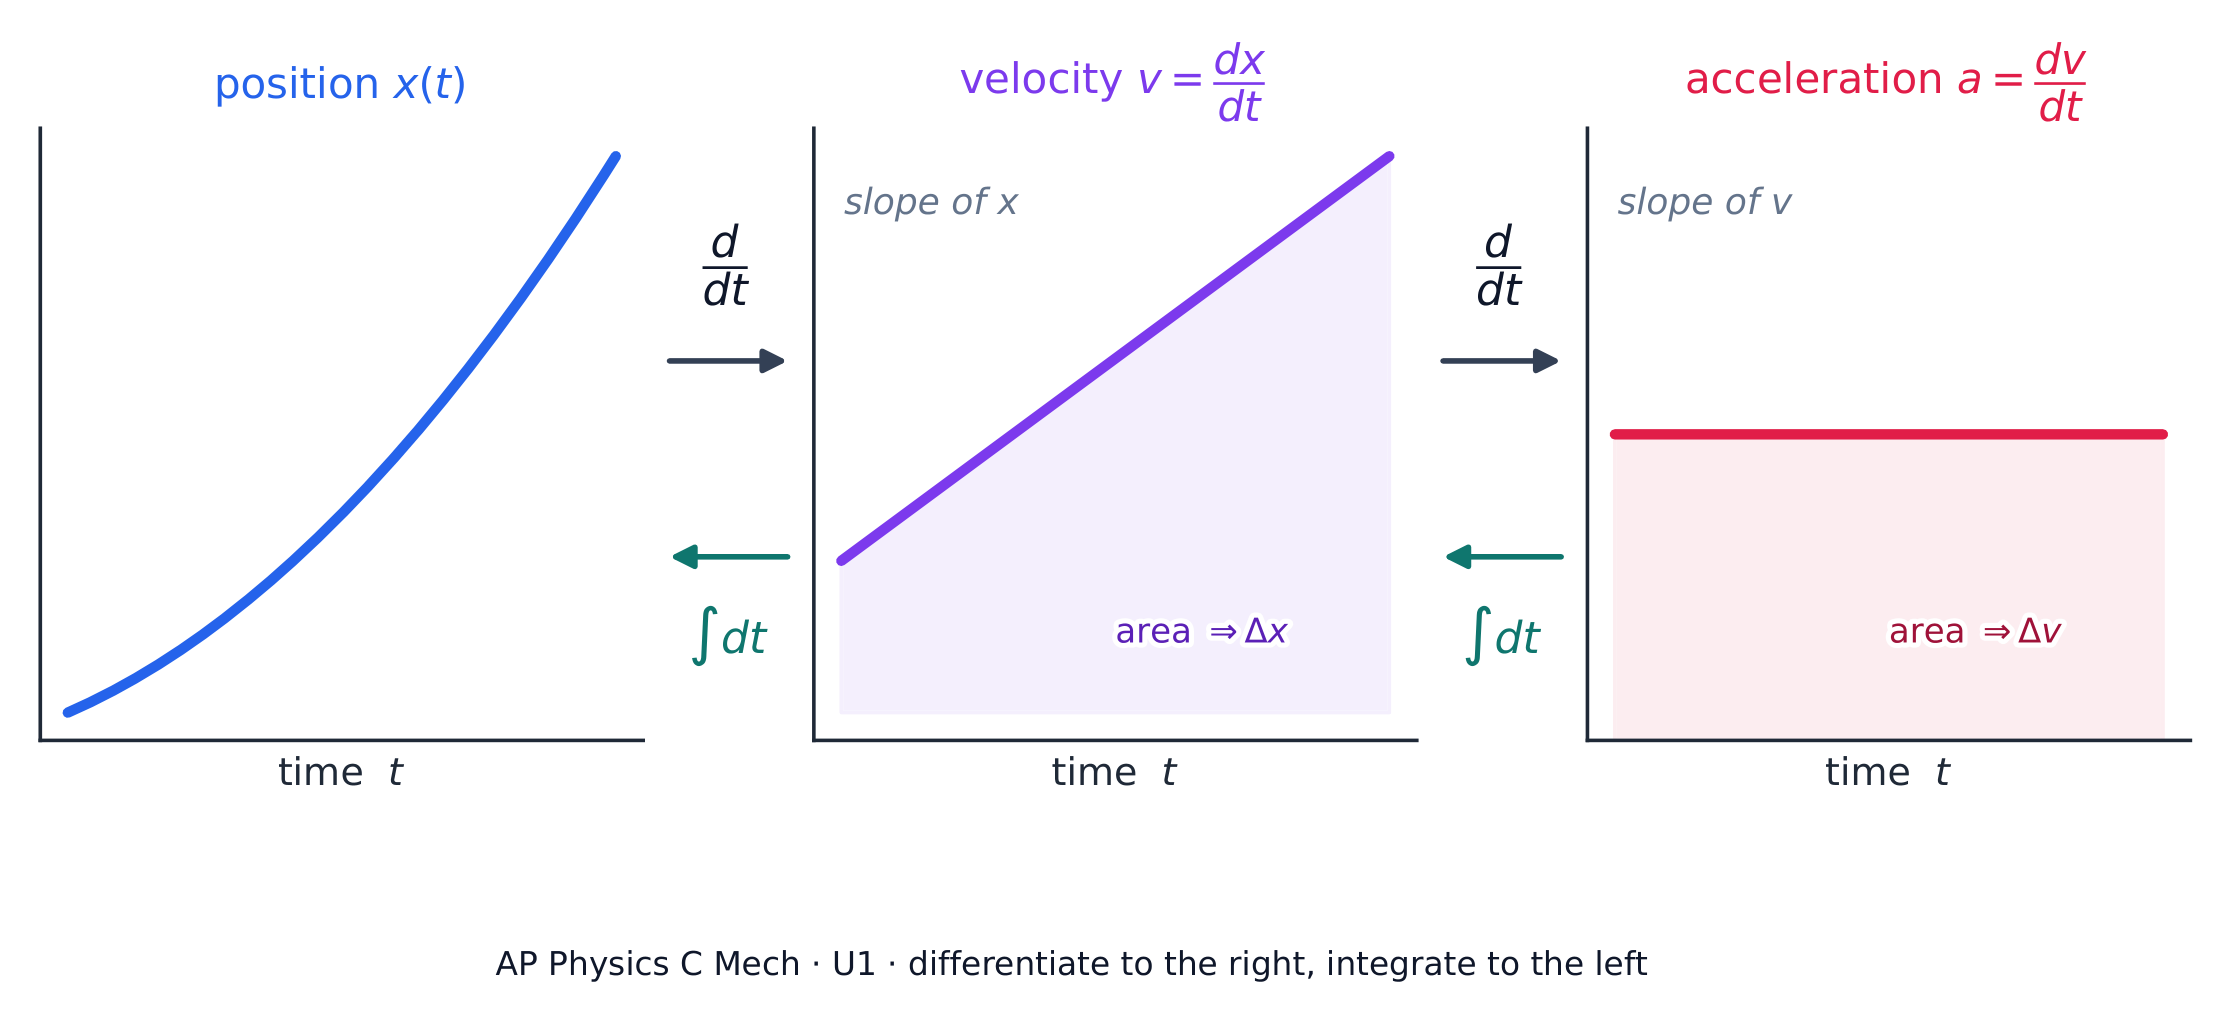
    Slopes are derivatives; areas are integrals – the two are inverse operations here.

    Position, velocity, and acceleration are linked by differentiation
    Position, velocity, and acceleration are linked by differentiation
    Explore · ⁨Jelajahi⁩

    Explore the velocity–time graph · ⁨Jelajahi grafik kecepatan-waktu⁩

    Change the start velocity and acceleration. The slope of a $v$–$t$ line is the acceleration $a=\tfrac{dv}{dt}$, and the area underneath is the displacement $\Delta x=\int v\,dt$ — slope and area are the graphical faces of the derivative and the integral. · ⁨Ubah kecepatan awal dan percepatan. Kemiringan garis $v$–$t$ adalah percepatan $a=\tfrac{dv}{dt}$, dan luas di bawahnya adalah perpindahan $\Delta x=\int v\,dt$ — kemiringan dan luas adalah wajah grafik dari turunan dan integral.⁩

    1.4

    Reference Frames and Relative Motion

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 1.4.A: Describe the reference frame of a given observer.

    • 1.4.A.1 The choice of reference frame will determine the direction and magnitude of quantities measured by an observer in that reference frame.

    Learning Objective 1.4.B: Describe the motion of objects as measured by observers in different inertial reference frames.

    • 1.4.B.1 Measurements from a given reference frame may be converted to measurements from another reference frame.
    • 1.4.B.2 The observed velocity of an object results from the combination of the object's velocity and the velocity of the observer's reference frame.
      • 1.4.B.2.i Combining the motion of an object and the motion of an observer in a given reference frame involves the addition or subtraction of vectors.
      • 1.4.B.2.ii The acceleration of any object is the same as measured from all inertial reference frames.

    Boundary statement: Unless otherwise stated, the frame of reference of any problem may be assumed to be inertial.

    Bahasa Indonesia

    Tujuan Pembelajaran 1.4.A: Deskripsikan kerangka acuan pengamat tertentu.

    • 1.4.A.1 Pemilihan kerangka acuan akan menentukan arah dan besaran kuantitas yang diukur oleh pengamat dalam kerangka acuan tersebut.

    Tujuan Pembelajaran 1.4.B: Deskripsikan gerak benda seperti yang diukur oleh pengamat dalam kerangka acuan inersia yang berbeda.

    • 1.4.B.1 Pengukuran dari suatu kerangka acuan tertentu dapat dikonversi menjadi pengukuran dari kerangka acuan lain.
    • 1.4.B.2 Kecepatan yang diamati dari sebuah benda merupakan hasil kombinasi dari kecepatan benda tersebut dan kecepatan kerangka acuan pengamatnya.
      • 1.4.B.2.i Menggabungkan gerak benda dan gerak pengamat dalam suatu kerangka acuan melibatkan penjumlahan atau pengurangan vektor.
      • 1.4.B.2.ii Percepatan setiap benda adalah sama jika diukur dari semua kerangka acuan inersia.

    Pernyataan Batas: Kecuali dinyatakan lain, kerangka acuan dari setiap masalah dapat diasumsikan sebagai inersia.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    All motion is relative to a reference frame 参考系. Combine velocities by vector addition: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. This handles boats crossing rivers and passengers on moving vehicles – relative motion 相对运动 problems. Read the subscripts as a chain: "A relative to B" plus "B relative to C" gives "A relative to C".

    Worked example. A boat that moves at $4.0\ \text{m/s}$ in still water heads straight across a river flowing at $3.0\ \text{m/s}$. Relative to the ground the boat moves at $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$, angled downstream. If the river is $80\ \text{m}$ wide, the crossing still takes $t=\dfrac{80}{4.0}=20\ \text{s}$ – only the across-stream component crosses the river; the current just carries the boat $60\ \text{m}$ downstream.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    reference frame/ˈrefrəns freɪm/ kerangka acuan
    relative motion/ˈrelətɪv ˈməʊʃn/ Gerak relatif
    1.5

    Motion in Two or Three Dimensions

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 1.5.A: Describe the motion of an object moving in two or three dimensions.

    • 1.5.A.1 Motion in two or three dimensions can be analyzed using one-dimensional kinematic relationships if the motion is separated into components.
    • 1.5.A.2 Velocity and acceleration may be different in each dimension and may be nonuniform.
    • 1.5.A.3 Motion in one dimension may be changed without causing a change in a perpendicular dimension.
    • 1.5.A.4 Projectile motion is a special case of two-dimensional motion that has zero acceleration in one dimension and constant, nonzero acceleration in the second dimension.

    Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze the motion of an object in two dimensions. AP Physics C: Electricity and Magnetism expects students to also qualitatively describe the motion of a particle in three dimensions.

    Bahasa Indonesia

    Tujuan Pembelajaran 1.5.A: Deskripsikan gerak sebuah benda yang bergerak dalam dua atau tiga dimensi.

    • 1.5.A.1 Gerak dalam dua atau tiga dimensi dapat dianalisis menggunakan hubungan kinematika satu dimensi jika geraknya dipisahkan menjadi komponen-komponennya.
    • 1.5.A.2 Kecepatan dan percepatan mungkin berbeda dalam setiap dimensi dan mungkin tidak seragam.
    • 1.5.A.3 Gerak dalam satu dimensi dapat berubah tanpa menyebabkan perubahan pada dimensi yang tegak lurus dengannya.
    • 1.5.A.4 Gerak peluru adalah kasus khusus dari gerak dua dimensi yang memiliki percepatan nol dalam satu dimensi dan percepatan konstan tak-nol dalam dimensi kedua.

    Pernyataan Batasan: AP Physics C: Mekanika hanya mengharapkan siswa menganalisis gerak sebuah benda dalam dua dimensi secara kuantitatif. AP Physics C: Listrik dan Magnetisme mengharapkan siswa juga mendeskripsikan gerak partikel dalam tiga dimensi secara kualitatif.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    In two or three dimensions, position is a vector $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$, and velocity and acceleration are its successive derivatives – each component handled independently.

    Worked example. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (metres). Differentiating each component: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ and $\vec{a}=4\,\hat{i}-6t\,\hat{j}$. At $t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$, so the speed is $\sqrt{17}\approx4.1\ \text{m/s}$ – no new physics, just one derivative per component.

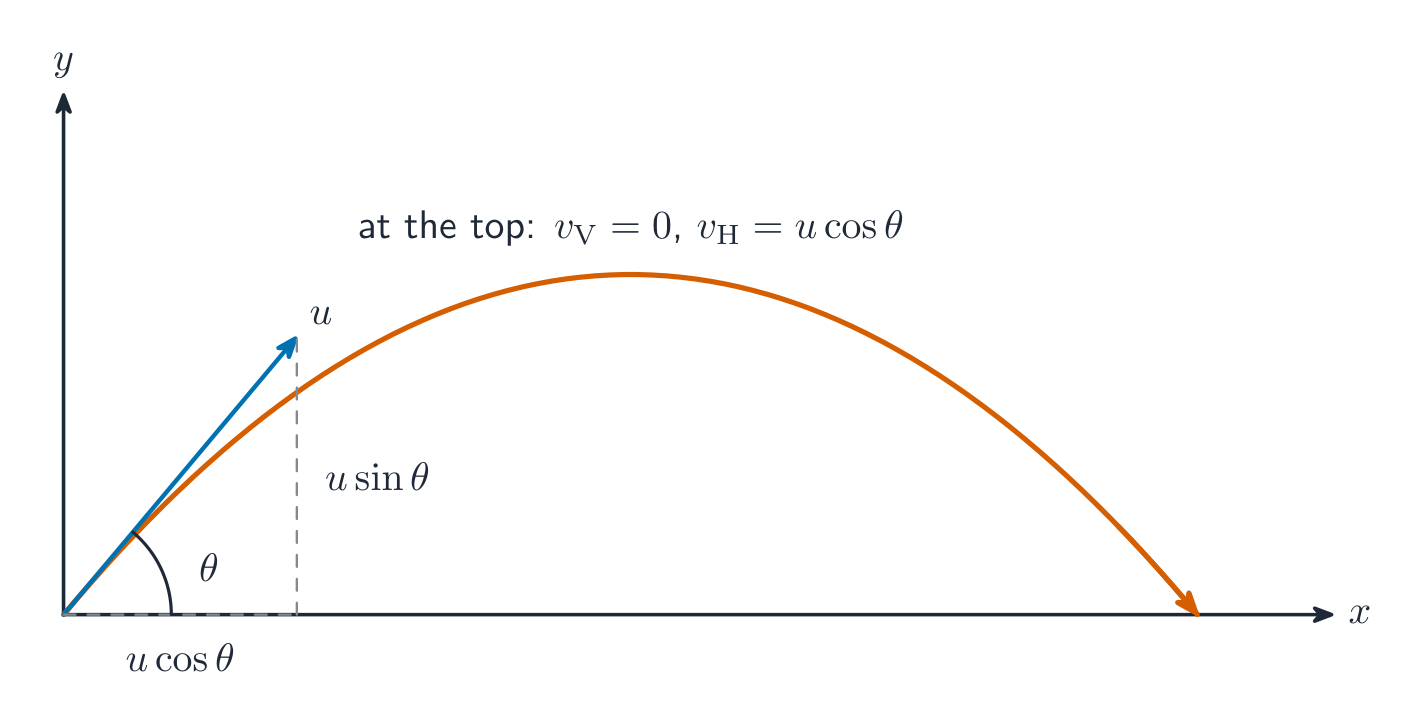
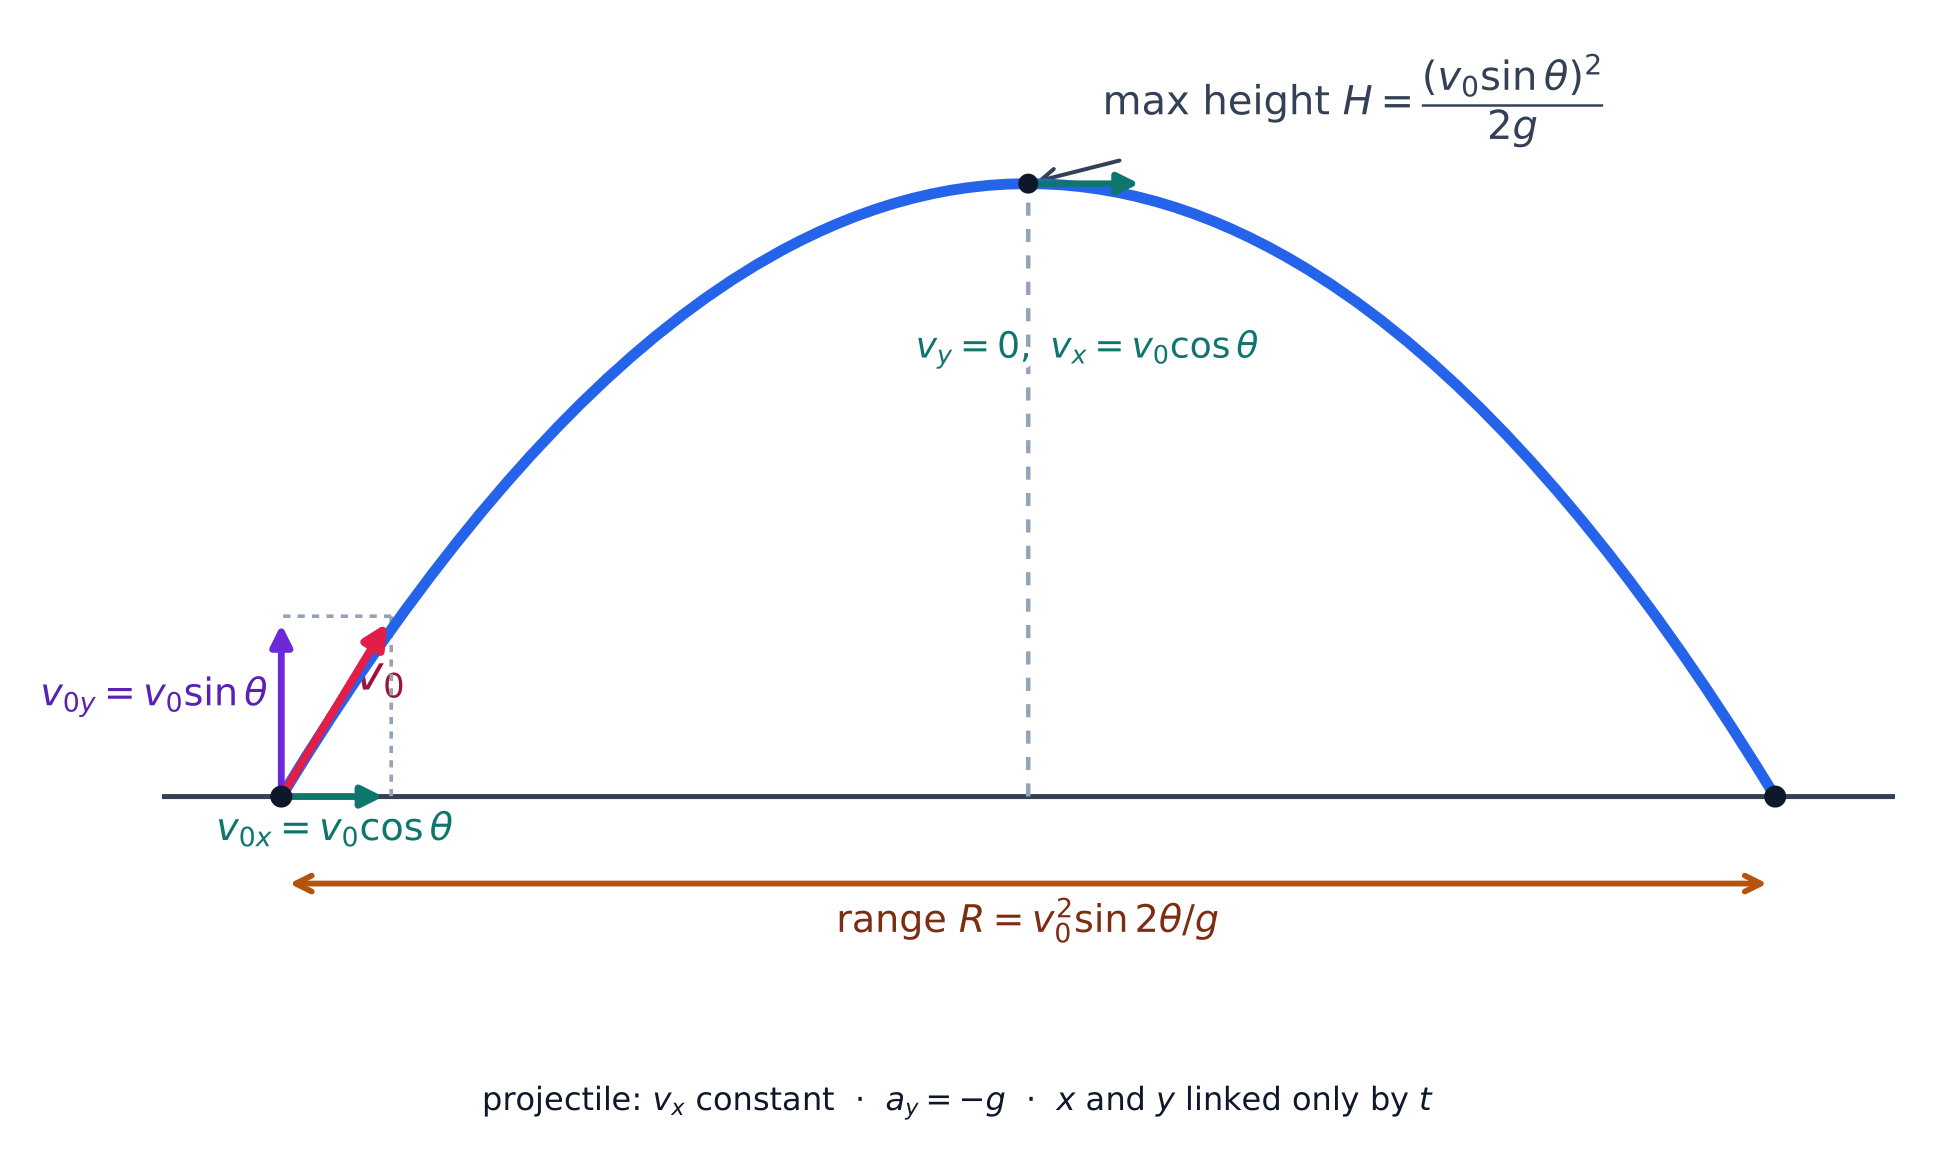
    A projectile launched at an angle: the horizontal and vertical motions are independent
    A projectile launched at an angle: the horizontal and vertical motions are independent

    For projectile motion 抛体运动, horizontal and vertical motions are independent, linked only by time $t$: horizontally $a_x=0$ (constant velocity), vertically $a_y=-g$. The path is a parabola. This component method extends to any two-dimensional motion where the accelerations along each axis are known.

    Worked example. A ball is launched at $20\ \text{m/s}$, $30^{\circ}$ above the horizontal ($g=9.8\ \text{m/s}^2$). The components are $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ and $v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. The vertical motion sets the time: total flight $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$, maximum height $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$, and range $=v_{0x}\times2.0=35\ \text{m}$.

    A projectile launched at an angle: velocity components, maximum height, and range
    A projectile launched at an angle: velocity components, maximum height, and range
    Explore · ⁨Jelajahi⁩

    Explore projectile motion · ⁨Jelajahi gerak peluru⁩

    Fire the projectile, then vary the angle and speed. The horizontal motion is steady while gravity acts only downward — together they trace a parabola. Find the angle that gives the greatest range (it peaks near $45^\circ$), and try the Moon. · ⁨Tembakkan proyektil, lalu ubah sudut dan kecepatan. Gerakan horizontal stabil sementara gravitasi hanya bekerja ke bawah — bersama-sama mereka melacak parabola. Temukan sudut yang memberikan jangkauan terbesar (puncaknya di sekitar $45^\circ$), dan coba di Bulan.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    projectile motion/prəˈdʒektaɪl ˈməʊʃn/ gerak peluru
    1.5

    Exam tips

    • Resolve every vector into components before adding — never add magnitudes at an angle directly.
    • On Physics C you are expected to use calculus: velocity is $\vec v=\tfrac{d\vec r}{dt}$ and acceleration $\vec a=\tfrac{d\vec v}{dt}$; reverse with integration.
    • Carry and check units and treat direction with signs (choose a positive axis and stick to it).
    • Use the dot product for work-type quantities and the cross product for torque and angular momentum.
    • Sketch the vectors — a diagram catches sign and direction errors the algebra hides.
  • 2

    Force and Translational Dynamics · ⁨Gaya dan Dinamika Translasi⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    2.1

    Systems and Center of Mass

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.1.A: Describe the properties and interactions of a system.

    • 2.1.A.1 System properties are determined by the interactions between objects within the system.
    • 2.1.A.2 If the properties or interactions of the constituent objects within a system are not important in modeling the behavior of the macroscopic system, the system can itself be treated as a single object.
    • 2.1.A.3 Systems may allow interactions between constituent parts of the system and the environment, which may result in the transfer of energy or mass.
    • 2.1.A.4 Individual objects within a chosen system may behave differently from each other as well as from the system as a whole.
    • 2.1.A.5 The internal structure of a system affects the analysis of that system.
    • 2.1.A.6 As variables external to a system are changed, the system's substructure may change.

    Learning Objective 2.1.B: Describe the location of a system's center of mass with respect to the system's constituent parts.

    • 2.1.B.1 For objects or systems with symmetrical mass distributions, the center of mass is located on lines of symmetry.
    • 2.1.B.2 The location of a system's center of mass along a given axis can be calculated using the equation
      • Equation: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
    • 2.1.B.3 For a nonuniform solid that can be considered as a collection of differential masses, $dm$, the solid's center of mass can be calculated using the equation
      • Equation: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
      • 2.1.B.3.i The linear mass density of a rod or other linear rigid body is the derivative of the rod's mass with respect to the position of the differential mass element on the rigid body.
        • Equation: $\lambda = \dfrac{d}{d\ell} m(\ell)$
      • 2.1.B.3.ii If a function of mass density is given for a solid, the total mass can be determined by integrating the mass density over the length (one dimension), area (two dimensions), or volume (three dimensions) of the solid. For example:
        • Equation: $M_{\text{total}} = \int \rho(r)\, dV$
    • 2.1.B.4 A system can be modeled as a singular object that is located at the system's center of mass.
    Bahasa Indonesia

    Tujuan Pembelajaran 2.1.A: Deskripsikan sifat-sifat dan interaksi suatu sistem.

    • 2.1.A.1 Sifat-sifat sistem ditentukan oleh interaksi antara objek-objek di dalam sistem.
    • 2.1.A.2 Jika sifat-sifat atau interaksi objek-objek penyusun di dalam sistem tidak penting dalam memodelkan perilaku sistem makroskopis, sistem itu sendiri dapat diperlakukan sebagai satu objek tunggal.
    • 2.1.A.3 Sistem mungkin memungkinkan interaksi antara bagian-bagian penyusun sistem dengan lingkungan, yang dapat menghasilkan transfer energi atau massa.
    • 2.1.A.4 Objek-objek individu di dalam sistem yang dipilih dapat berperilaku berbeda satu sama lain serta berbeda dari sistem secara keseluruhan.
    • 2.1.A.5 Struktur internal sistem mempengaruhi analisis terhadap sistem tersebut.
    • 2.1.A.6 Saat variabel eksternal dari sistem diubah, substruktur sistem mungkin berubah.

    Tujuan Pembelajaran 2.1.B: Deskripsikan lokasi titik massa pusat sistem terkait dengan bagian-bagian penyusun sistem.

    • 2.1.B.1 Untuk benda atau sistem dengan distribusi massa simetris, pusat massa terletak pada garis-garis simetri.
    • 2.1.B.2 Lokasi titik massa pusat sistem sepanjang sumbu tertentu dapat dihitung menggunakan persamaan ⟦number⟧
      • Persamaan: $\vec{x}_{\text{cm}} = \dfrac{\sum m_i \vec{x}_i}{\sum m_i}$
    • 2.1.B.3 Untuk padatan nonuniform yang dapat dianggap sebagai kumpulan massa diferensial, $dm$, pusat massa padatan dapat dihitung menggunakan persamaan
      • Persamaan: $\vec{r}_{\text{cm}} = \dfrac{\int \vec{r}\, dm}{\int dm}$
      • 2.1.B.3.i Kepadatan linear massa dari batang atau benda kaku linear lainnya adalah turunan massa batang terhadap posisi elemen massa diferensial pada benda kaku tersebut.
        • Persamaan: $\lambda = \dfrac{d}{d\ell} m(\ell)$
      • 2.1.B.3.ii Jika fungsi kepadatan massa diberikan untuk sebuah padatan, total massa dapat ditentukan dengan mengintegralkan kepadatan massa sepanjang panjang (satu dimensi), luas (dua dimensi), atau volume (tiga dimensi) dari padatan tersebut. Sebagai contoh:
        • Persamaan: $M_{\text{total}} = \int \rho(r)\, dV$
    • 2.1.B.4 Sebuah sistem dapat dimodelkan sebagai objek tunggal yang terletak pada pusat massa sistem.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    A system 系统 is the object or objects you analyze, treated as a point at its center of mass 质心. For a set of masses, $x_{\text{cm}}=\dfrac{\sum m_i x_i}{\sum m_i}$; for a continuous body, $x_{\text{cm}}=\dfrac{1}{M}\int x\,dm$. Only external forces move the center of mass.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    system/ˈsɪstəm/ sistem
    center of mass/ˈsentə ɒv mæs/ pusat massa
    2.2

    Forces and Free-Body Diagrams

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.2.A: Describe a force as an interaction between two objects or systems

    • 2.2.A.1 Forces are vector quantities that describe the interactions between objects or systems.
      • 2.2.A.1.i A force exerted on an object or system is always due to the interaction of that object or system with another object or system.
      • 2.2.A.1.ii An object or system cannot exert a net force on itself.
    • 2.2.A.2 Contact forces describe the interaction of an object or system touching another object or system and are macroscopic effects of interatomic electric forces.

    Learning Objective 2.2.B: Describe the forces exerted on an object or system using a free-body diagram.

    • 2.2.B.1 Free-body diagrams are useful tools for visualizing forces being exerted on a single object or system and for determining the equations that represent a physical situation.
    • 2.2.B.2 The free-body diagram of an object or system shows each of the forces exerted on the object or system by the environment.
    • 2.2.B.3 Forces exerted on an object or system are represented as vectors originating from the representation of the center of mass, such as a dot. A system is treated as though all of its mass is located at the center of mass.
    • 2.2.B.4 A coordinate system with one axis parallel to the direction of acceleration of the object or system simplifies the translation from free-body diagram to algebraic representation. For example, in a free-body diagram of an object on an inclined plane, it is useful to set one axis parallel to the surface of the incline.

    Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism only expect students to depict the forces exerted on objects, not the force components on free-body diagrams. On the AP Physics exams, individual forces represented on a free-body diagram must be drawn as individual straight arrows, originating on the dot and pointing in the direction of the force. Individual forces that are in the same direction must be drawn side by side, not overlapping.

    Bahasa Indonesia

    Tujuan Pembelajaran 2.2.A: Deskripsikan gaya sebagai interaksi antara dua benda atau sistem

    • 2.2.A.1 Gaya adalah besaran vektor yang menggambarkan interaksi antara objek atau sistem.
      • 2.2.A.1.i Gaya yang diberikan pada suatu benda atau sistem selalu disebabkan oleh interaksi benda atau sistem tersebut dengan benda atau sistem lainnya.
      • 2.2.A.1.ii Suatu objek atau sistem tidak dapat memberikan gaya bersih pada dirinya sendiri.
    • 2.2.A.2 Gaya kontak menggambarkan interaksi objek atau sistem yang menyentuh objek atau sistem lain dan merupakan efek makroskopis dari gaya listrik antaratom.

    Tujuan Pembelajaran 2.2.B: Deskripsikan gaya-gaya yang bekerja pada suatu objek atau sistem menggunakan diagram benda bebas.

    • 2.2.B.1 Diagram benda bebas adalah alat yang berguna untuk memvisualisasikan gaya-gaya yang bekerja pada satu objek atau sistem dan untuk menentukan persamaan yang mewakili situasi fisik.
    • 2.2.B.2 Diagram benda bebas dari suatu benda atau sistem menunjukkan setiap gaya yang diberikan pada benda atau sistem tersebut oleh lingkungan.
    • 2.2.B.3 Gaya-gaya yang bekerja pada objek atau sistem direpresentasikan sebagai vektor yang bermula dari representasi titik massa pusat, seperti sebuah titik. Sebuah sistem diperlakukan seolah-olah seluruh massanya berlokasi di titik massa pusat.
    • 2.2.B.4 Sistem koordinat dengan satu sumbu sejajar dengan arah percepatan objek atau sistem menyederhanakan translasi dari diagram benda bebas ke representasi aljabar. Sebagai contoh, dalam diagram benda bebas objek pada bidang miring, berguna untuk menetapkan satu sumbu sejajar dengan permukaan bidang miring.

    Pernyataan Batas: AP Physics C: Mekanika dan AP Physics C: Listrik dan Magnetisme hanya mengharuskan siswa menggambarkan gaya-gaya yang diberikan pada benda, bukan komponen gaya pada diagram benda bebas. Pada ujian AP Physics, gaya-gaya individu yang diwakili pada diagram benda bebas harus digambar sebagai panah lurus individual, bermula dari titik dan menunjuk ke arah gaya. Gaya-gaya individu yang searah harus digambar berdampingan, tidak saling tumpang tindih.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

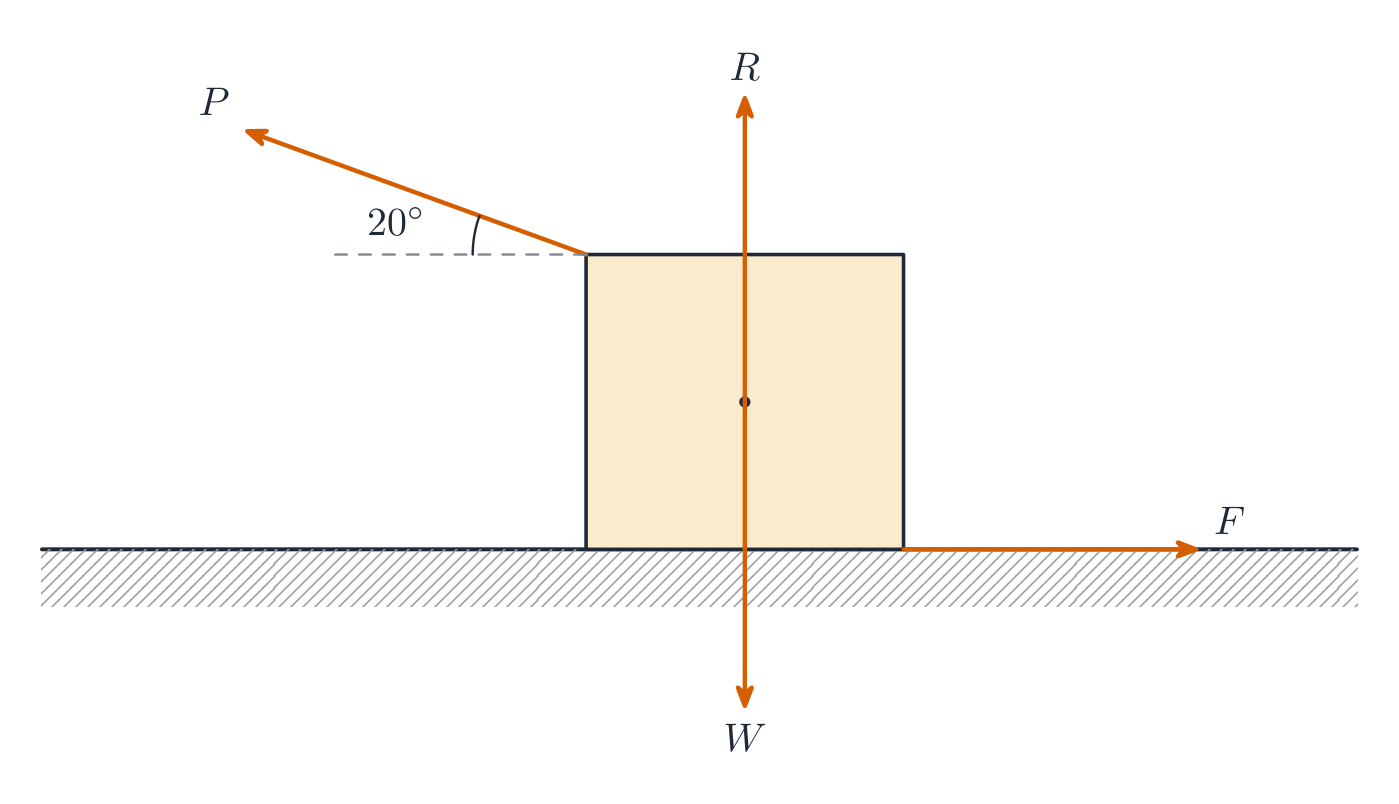
    A force 力 is a push or pull (a vector, in newtons). A free-body diagram 受力图 draws one object with an arrow for every force on it – weight, normal, tension, friction, applied, drag. Draw it first; it sets up every dynamics equation.

    A free-body diagram shows every force acting on one object
    A free-body diagram shows every force acting on one object
    Explore · ⁨Jelajahi⁩

    Balance the forces on a free-body diagram · ⁨Seimbangkan gaya-gaya pada diagram benda bebas⁩

    A free-body diagram shows every force on one object as an arrow. The object accelerates only if the forces don't cancel — the net force sets $a=F/m$. · ⁨Diagram benda bebas menunjukkan setiap gaya yang bekerja pada satu objek sebagai anak panah. Objek hanya berakselerasi jika gaya-gaya tidak saling meniadakan — gaya bersih menentukan $a=F/m$.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    force/fɔːs/ gaya
    free-body diagram/friː ˈbɒdi ˈdaɪəɡræm/ diagram benda bebas
    2.3

    Newton's Third Law

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.3.A: Describe the interaction of two objects or systems using Newton's third law and a representation of paired forces exerted on each object or system.

    • 2.3.A.1 Newton's third law describes the interaction of two objects or systems in terms of the paired forces that each exerts on the other.
      • Equation: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
    • 2.3.A.2 Interactions between objects within a system (internal forces) do not influence the motion of a system's center of mass.
    • 2.3.A.3 Tension is the macroscopic net result of forces that infinitesimal segments of a string, cable, chain, or similar system exert on each other in response to an external force.
      • 2.3.A.3.i An ideal string has negligible mass and does not stretch when under tension.
      • 2.3.A.3.ii The tension in an ideal string is the same at all points within the string.
      • 2.3.A.3.iii In a string with nonnegligible mass, tension may not be the same at all points within the string.
      • 2.3.A.3.iv An ideal pulley is a pulley that has negligible mass and rotates about an axle through its center of mass with negligible friction.
    Bahasa Indonesia

    Tujuan Pembelajaran 2.3.A: Deskripsikan interaksi dua benda atau sistem menggunakan Hukum Ketiga Newton dan representasi pasangan gaya yang diberikan pada masing-masing benda atau sistem.

    • 2.3.A.1 Hukum Ketiga Newton menggambarkan interaksi dua benda atau sistem dalam hal pasangan gaya yang masing-masing memberikan kepada yang lain.
      • Persamaan: $\vec{F}_{\text{A on B}} = -\vec{F}_{\text{B on A}}$
    • 2.3.A.2 Interaksi antara benda-benda dalam suatu sistem (gaya internal) tidak memengaruhi gerak pusat massa sistem tersebut.
    • 2.3.A.3 Tegangan adalah hasil bersih makroskopis dari gaya-gaya yang segmen-segmen tak terhingga kecil dari tali, kabel, rantai, atau sistem serupa memberikan satu sama lain sebagai respons terhadap gaya eksternal.
      • 2.3.A.3.i Tali ideal memiliki massa yang dapat diabaikan dan tidak meregang ketika mengalami tegangan.
      • 2.3.A.3.ii Tegangan pada tali ideal adalah sama di semua titik di dalam tali tersebut.
      • 2.3.A.3.iii Pada tali dengan massa yang tidak dapat diabaikan, tegangan mungkin tidak sama di semua titik di dalam tali tersebut.
      • 2.3.A.3.iv Katrol ideal adalah katrol yang memiliki massa yang dapat diabaikan dan berputar pada sumbu melalui pusat massanya dengan gesekan yang dapat diabaikan.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

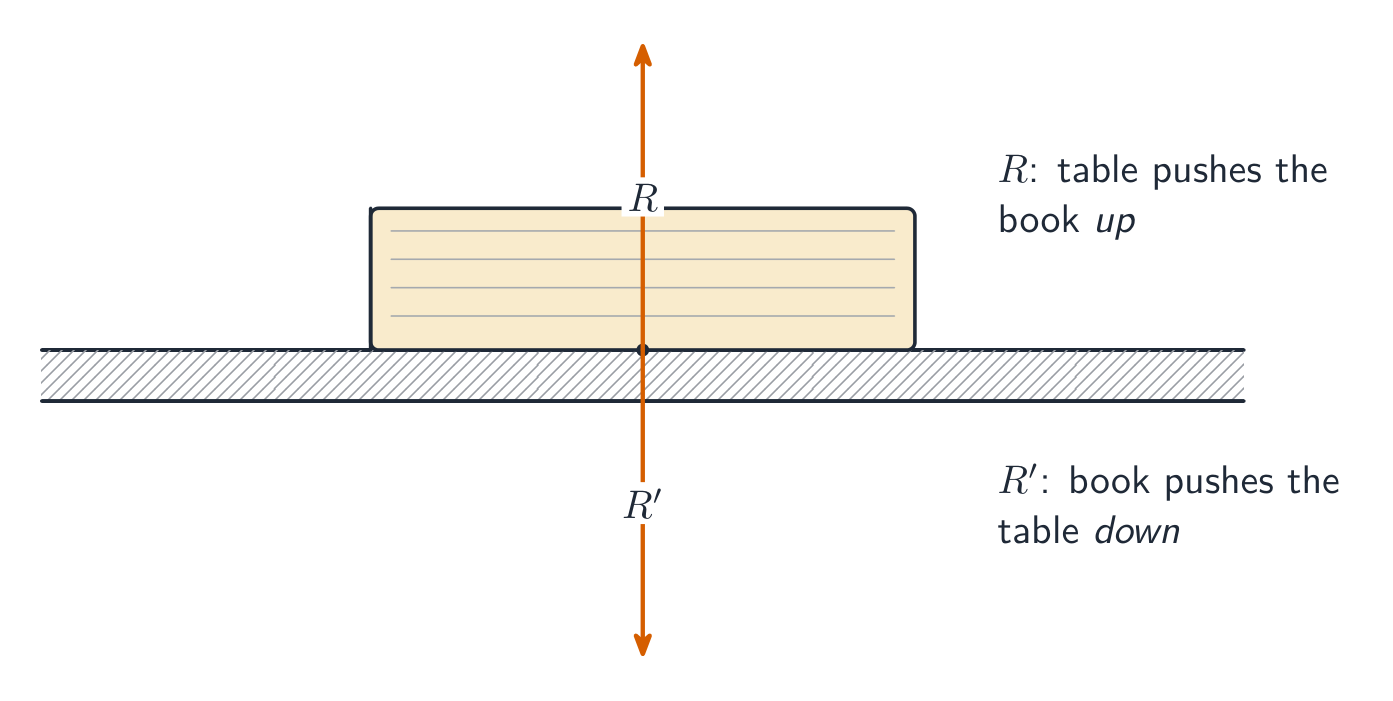
    Newton's third law 牛顿第三定律: A pushes B, B pushes back equally and oppositely. The pair acts on different objects, so it never cancels within one free-body diagram.

    A Newton's third-law pair: equal and opposite forces on two different objects
    A Newton's third-law pair: equal and opposite forces on two different objects
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Newton's third law/ˈnjuːtnz θɜːd lɔː/ hukum ketiga Newton
    2.4

    Newton's First Law

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.4.A: Describe the conditions under which a system's velocity remains constant.

    • 2.4.A.1 The net force on a system is the vector sum of all forces exerted on the system.
    • 2.4.A.2 Translational equilibrium is the configuration of forces such that the net force exerted on a system is zero.
      • Derived equation: $\sum \vec{F}_i = 0$
    • 2.4.A.3 Newton's first law states that if the net force exerted on a system is zero, the velocity of that system will remain constant.
    • 2.4.A.4 Forces may be balanced in one dimension but unbalanced in another. The system's velocity will change only in the direction of the unbalanced force.
    • 2.4.A.5 An inertial reference frame is one from which an observer would verify Newton's first law of motion.
    Bahasa Indonesia

    Tujuan Pembelajaran 2.4.A: Jelaskan kondisi di mana kecepatan suatu sistem tetap konstan.

    • 2.4.A.1 Resultan gaya pada suatu sistem adalah jumlah vektor dari semua gaya yang bekerja pada sistem tersebut.
    • 2.4.A.2 Kesetimbangan translasi adalah konfigurasi gaya sedemikian rupa sehingga gaya bersih yang diberikan pada sistem adalah nol.
      • Persamaan Turunan: $\sum \vec{F}_i = 0$
    • 2.4.A.3 Hukum pertama Newton menyatakan bahwa jika resultan gaya yang bekerja pada suatu sistem adalah nol, maka kecepatan sistem tersebut akan tetap konstan.
    • 2.4.A.4 Gaya-gaya dapat seimbang dalam satu dimensi tetapi tidak seimbang dalam dimensi lain. Kecepatan sistem hanya akan berubah dalam arah gaya yang tidak seimbang.
    • 2.4.A.5 Kerangka acuan inersial adalah kerangka dari mana pengamat akan memverifikasi hukum pertama gerak Newton.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Newton's first law (inertia 惯性): with zero net force 合力, velocity stays constant – the object is in translational equilibrium 平动平衡.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    inertia/ɪˈnɜːʃə/ inersia
    net force/net fɔːs/ gaya bersih
    translational equilibrium/trænˈsleɪʃənl ˌiːkwɪˈlɪbrɪəm/ kesetimbangan translasi
    2.5

    Newton's Second Law

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.5.A: Describe the conditions under which a system's velocity changes.

    • 2.5.A.1 Unbalanced forces are a configuration of forces such that the net force exerted on a system is not equal to zero.
    • 2.5.A.2 Newton's second law of motion states that the acceleration of a system's center of mass has a magnitude proportional to the magnitude of the net force exerted on the system and is in the same direction as that net force.
      • Equation: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
    • 2.5.A.3 The velocity of a system's center of mass will only change if a nonzero net external force is exerted on that system.
    Bahasa Indonesia

    Tujuan Pembelajaran 2.5.A: Jelaskan kondisi di mana kecepatan suatu sistem berubah.

    • 2.5.A.1 Gaya-gaya yang tidak seimbang adalah konfigurasi gaya sedemikian rupa sehingga resultan gaya yang bekerja pada sistem tidak sama dengan nol.
    • 2.5.A.2 Hukum kedua gerak Newton menyatakan bahwa percepatan pusat massa sistem memiliki besaran yang berbanding lurus dengan besaran resultan gaya yang bekerja pada sistem dan berada dalam arah yang sama dengan resultan gaya tersebut.
      • Persamaan: $\vec{a}_{\text{sys}} = \dfrac{\sum \vec{F}}{m_{\text{sys}}} = \dfrac{\vec{F}_{\text{net}}}{m_{\text{sys}}}$
    • 2.5.A.3 Kecepatan pusat massa suatu sistem hanya akan berubah jika ada resultan gaya eksternal tak nol yang bekerja pada sistem tersebut.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    The general form uses momentum:

    $$\sum\vec{F}=\frac{d\vec{p}}{dt}=m\vec{a}\ \ (\text{for constant mass}).$$
    Apply it one axis at a time. When forces depend on velocity or position, this becomes a differential equation 微分方程 to solve.

    Worked example. A $2.0\ \text{kg}$ block slides down a frictionless incline 斜面 at $30^{\circ}$. Only the along-ramp component of gravity drives it, so $a=g\sin30^{\circ}=9.8(0.5)=4.9\ \text{m/s}^2$, independent of the mass.

    Worked example (two bodies). A $6.0\ \text{kg}$ cart on a frictionless table is pulled by a string over a light pulley to a hanging $2.0\ \text{kg}$ mass. Treat the pair as one system: only the hanging weight drives it, so $a=\dfrac{2.0(9.8)}{8.0}=2.45\ \text{m/s}^2$. Then isolate the cart alone to find the string tension 张力: $T=6.0(2.45)\approx15\ \text{N}$. System first for $a$, single body for internal forces – that two-step is the standard pattern.

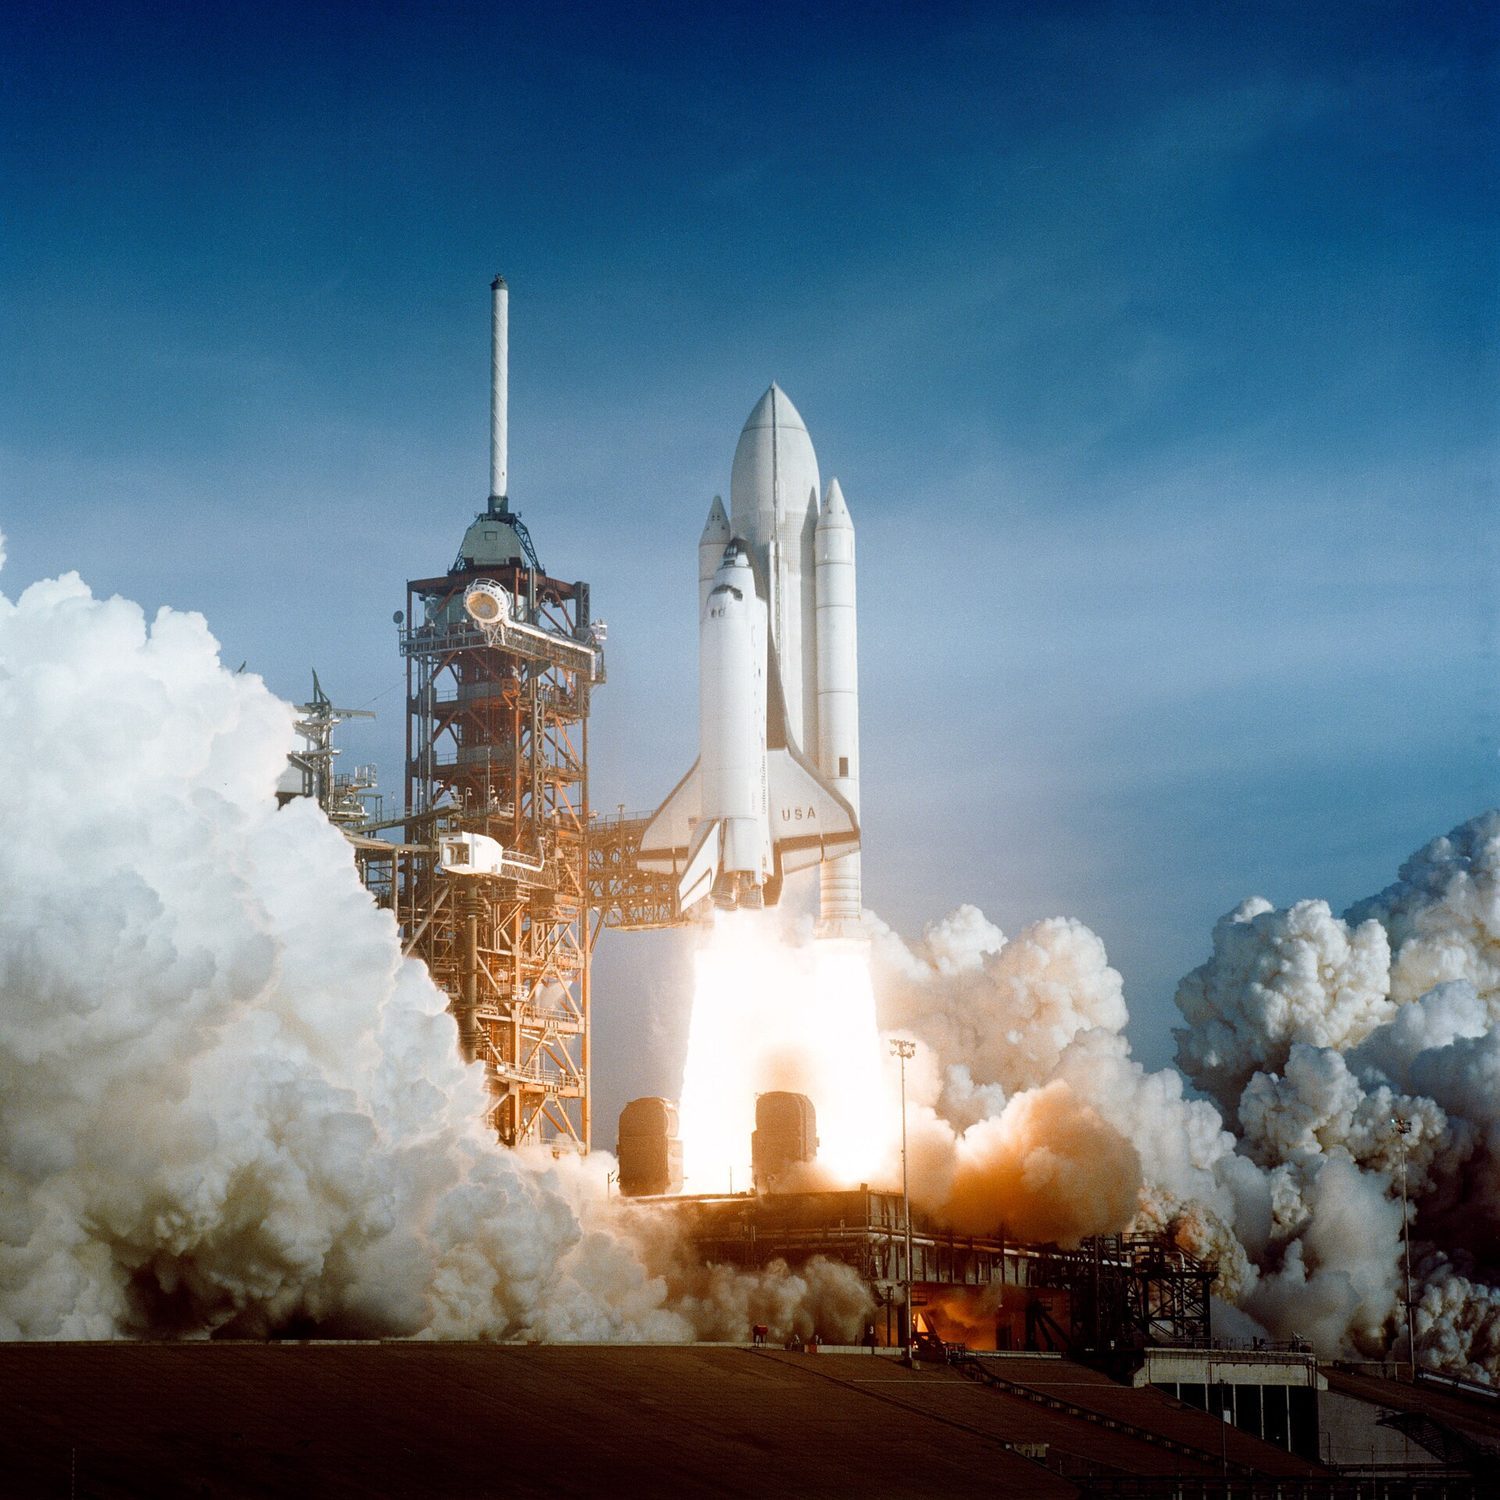
    A rocket launch: net force changes momentum — F_net = ma for translational dynamics
    A rocket launch: net force changes momentum — F_net = ma for translational dynamics
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ persamaan diferensial
    incline/ɪnˈklaɪn/ Kemiringan
    tension/ˈtenʃn/ tegangan
    2.6

    Gravitational Force

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.6.A: Describe the gravitational interaction between two objects or systems with mass.

    • 2.6.A.1 Newton's law of universal gravitation describes the gravitational force between two objects or systems as directly proportional to each of their masses and inversely proportional to the square of the distance between the systems' centers of mass.
      • Equation: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
      • 2.6.A.1.i The gravitational force is attractive.
      • 2.6.A.1.ii The gravitational force is always exerted along the line connecting the center of mass of the two interacting systems.
      • 2.6.A.1.iii The gravitational force on a system can be considered to be exerted on the system's center of mass.
    • 2.6.A.2 A field models the effects of a noncontact force exerted on an object at various positions in space.
      • 2.6.A.2.i The magnitude of the gravitational field created by a system of mass $M$ at a point in space is equal to the ratio of the gravitational force exerted by the system on a test object of mass $m$ to the mass of the test object.
        • Derived equation: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
      • 2.6.A.2.ii If the gravitational force is the only force exerted on an object, the observed acceleration of the object (in $\text{m/s}^2$) is numerically equal to the magnitude of the gravitational field strength (in $\text{N/kg}$) at that location.
    • 2.6.A.3 The gravitational force exerted by an astronomical body on a relatively small nearby object is called weight.
      • Derived equation: $\text{Weight} = F_g = mg$

    Learning Objective 2.6.B: Describe situations in which the gravitational force can be considered constant.

    • 2.6.B.1 If the gravitational force between two systems' centers of mass has a negligible change as the relative position of the two systems changes, the gravitational force can be considered constant at all points between the initial and final positions of the systems.
    • 2.6.B.2 Near the surface of Earth, the strength of the gravitational field is
      • Equation: $g \approx 10\ \text{N/kg}$

    Learning Objective 2.6.C: Describe the conditions under which the magnitude of a system's apparent weight is different from the magnitude of the gravitational force exerted on that system.

    • 2.6.C.1 The magnitude of the apparent weight of a system is the magnitude of the normal force exerted on the system.
    • 2.6.C.2 If the system is accelerating, the apparent weight of the system is not equal to the magnitude of the gravitational force exerted on the system.
    • 2.6.C.3 A system appears weightless when there are no forces exerted on the system or when the force of gravity is the only force exerted on the system.
    • 2.6.C.4 The equivalence principle states that an observer in a noninertial reference frame is unable to distinguish between an object's apparent weight and the gravitational force exerted on the object by a gravitational field.

    Learning Objective 2.6.D: Describe inertial and gravitational mass.

    • 2.6.D.1 Objects have inertial mass, or inertia, a property that determines how much an object's motion resists changes when interacting with another object.
    • 2.6.D.2 Gravitational mass is related to the force of attraction between two systems with mass.
    • 2.6.D.3 Inertial mass and gravitational mass have been experimentally verified to be equivalent.

    Learning Objective 2.6.E: Describe the gravitational force exerted on an object by a uniform spherical distribution of mass.

    • 2.6.E.1 The net gravitational force exerted on an object by a uniform spherical distribution of mass is the sum of the individual forces from small differential masses that comprise the distribution.
    • 2.6.E.2 Newton's shell theorem describes the net gravitational force exerted on an object by a uniform spherical shell of mass.
      • 2.6.E.2.i The net gravitational force exerted on an object inside a thin spherical shell is zero.
      • 2.6.E.2.ii The net gravitational force exerted on an object outside a thin spherical shell can be determined by treating the shell as a single massive object located at the center of the shell.
      • 2.6.E.2.iii An object inside a sphere of uniform density experiences a net gravitational force from only a partial mass of the sphere.
      • 2.6.E.2.iv The partial mass of a sphere that contributes to the net gravitational force exerted on an object within that sphere is the portion of the sphere's mass located a distance less than or equal to the object's distance from the center of the sphere and can be calculated using the density of the sphere.
        • Derived equation: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
    • 2.6.E.3 The gravitational force exerted on an object within a uniform sphere can be shown to be proportional to the object's distance from the sphere's center.
      • Derived equation: $F_{g,\text{partial}} = -k r_{\text{partial}}$

    Boundary statement: AP Physics C: Mechanics does not expect students to mathematically prove or derive Newton's shell theorem.

    Bahasa Indonesia

    Tujuan Pembelajaran 2.6.A: Jelaskan interaksi gravitasi antara dua benda atau sistem yang bermassa.

    • 2.6.A.1 Hukum gravitasi universal Newton menggambarkan gaya gravitasi antara dua benda atau sistem sebagai berbanding lurus dengan masing-masing massanya dan berbanding terbalik dengan kuadrat jarak antara pusat massa sistem tersebut.
      • Persamaan: $\left| \vec{F}_g \right| = G \dfrac{m_1 m_2}{r^2}$
      • 2.6.A.1.i Gaya gravitasi bersifat menarik.
      • 2.6.A.1.ii Gaya gravitasi selalu diberikan sepanjang garis yang menghubungkan pusat massa dari kedua sistem yang berinteraksi.
      • 2.6.A.1.iii Gaya gravitasi pada suatu sistem dapat dianggap bekerja pada pusat massa sistem tersebut.
    • 2.6.A.2 Medan memodelkan efek gaya non-kontak yang bekerja pada objek di berbagai posisi di ruang.
      • 2.6.A.2.i Besaran medan gravitasi yang dihasilkan oleh sistem bermassa $M$ pada suatu titik di ruang sama dengan rasio gaya gravitasi yang diberikan sistem terhadap objek uji bermassa $m$ dibagi dengan massa objek uji tersebut.
        • Persamaan turunan: $\left| \vec{g} \right| = \dfrac{\left| \vec{F}_g \right|}{m} = G \dfrac{M}{r^2}$
      • 2.6.A.2.ii Jika gaya gravitasi adalah satu-satunya gaya yang diberikan pada suatu benda, percepatan yang diamati dari benda tersebut (dalam $\text{m/s}^2$) secara numerik sama dengan besar kuat medan gravitasi (dalam $\text{N/kg}$) di lokasi tersebut.
    • 2.6.A.3 Gaya gravitasi yang diberikan oleh tubuh astronomi terhadap objek kecil di dekatnya disebut berat.
      • Persamaan Turunan: $\text{Weight} = F_g = mg$

    Tujuan Pembelajaran 2.6.B: Jelaskan situasi di mana gaya gravitasi dapat dianggap konstan.

    • 2.6.B.1 Jika perubahan gaya gravitasi antara pusat massa dua sistem sangat kecil seiring dengan perubahan posisi relatif kedua sistem, maka gaya gravitasi dapat dianggap konstan di semua titik antara posisi awal dan akhir sistem.
    • 2.6.B.2 Di dekat permukaan Bumi, kuat medan gravitasi adalah
      • Persamaan: $g \approx 10\ \text{N/kg}$

    Tujuan Pembelajaran 2.6.C: Jelaskan kondisi di mana besaran berat semu suatu sistem berbeda dari besaran gaya gravitasi yang bekerja pada sistem tersebut.

    • 2.6.C.1 Besaran berat semu suatu sistem adalah besaran gaya normal yang bekerja pada sistem tersebut.
    • 2.6.C.2 Jika sistem sedang dipercepat, berat semu sistem tidak sama dengan besaran gaya gravitasi yang bekerja pada sistem.
    • 2.6.C.3 Suatu sistem tampak tanpa berat ketika tidak ada gaya yang bekerja pada sistem atau ketika gaya gravitasi adalah satu-satunya gaya yang bekerja pada sistem.
    • 2.6.C.4 Prinsip ekuivalensi menyatakan bahwa pengamat dalam kerangka acuan non-inersia tidak dapat membedakan antara berat semu suatu benda dan gaya gravitasi yang bekerja pada benda tersebut oleh medan gravitasi.

    Tujuan Pembelajaran 2.6.D: Jelaskan massa inersia dan massa gravitasi.

    • 2.6.D.1 Benda memiliki massa inersia, atau inersia, sebuah sifat yang menentukan seberapa besar gerak benda menahan perubahan ketika berinteraksi dengan benda lain.
    • 2.6.D.2 Massa gravitasi berkaitan dengan gaya tarik-menarik antara dua sistem bermassa.
    • 2.6.D.3 Massa inersia dan massa gravitasi telah diverifikasi secara eksperimental sebagai ekuivalen.

    Tujuan Pembelajaran 2.6.E: Deskripsikan gaya gravitasi yang diberikan pada suatu benda oleh distribusi massa bola seragam.

    • 2.6.E.1 Gaya gravitasi bersih yang diberikan pada suatu benda oleh distribusi massa bola seragam adalah jumlah dari gaya-gaya individu dari massa diferensial kecil yang membentuk distribusi tersebut.
    • 2.6.E.2 Teorema cangkang Newton menggambarkan gaya gravitasi bersih yang diberikan pada suatu benda oleh cangkang bola massa seragam.
      • 2.6.E.2.i Gaya gravitasi bersih yang diberikan pada suatu benda di dalam cangkang bola tipis adalah nol.
      • 2.6.E.2.ii Gaya gravitasi bersih yang diberikan pada suatu benda di luar cangkang bola tipis dapat ditentukan dengan menganggap cangkang tersebut sebagai satu objek bermassa tunggal yang terletak di tengah cangkang.
      • 2.6.E.2.iii Benda di dalam bola dengan densitas seragam mengalami gaya gravitasi bersih hanya dari sebagian massa bola tersebut.
      • 2.6.E.2.iv Bagian massa bola yang berkontribusi pada gaya gravitasi bersih yang diberikan pada benda di dalam bola tersebut adalah bagian dari massa bola yang terletak pada jarak kurang dari atau sama dengan jarak benda dari pusat bola dan dapat dihitung menggunakan densitas bola.
        • Persamaan turunan: $m_{\text{partial}} = \rho \dfrac{4}{3} \pi \left( r_{\text{partial}} \right)^3$
    • 2.6.E.3 Gaya gravitasi yang diberikan pada suatu benda di dalam bola seragam dapat ditunjukkan berbanding lurus dengan jarak benda dari pusat bola.
      • Persamaan Turunan: $F_{g,\text{partial}} = -k r_{\text{partial}}$

    Pernyataan Batas: AP Physics C: Mekanika tidak mengharuskan siswa membuktikan secara matematis atau menurunkan teorema cangkang Newton.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Orbital motion (Kepler's 2nd law)

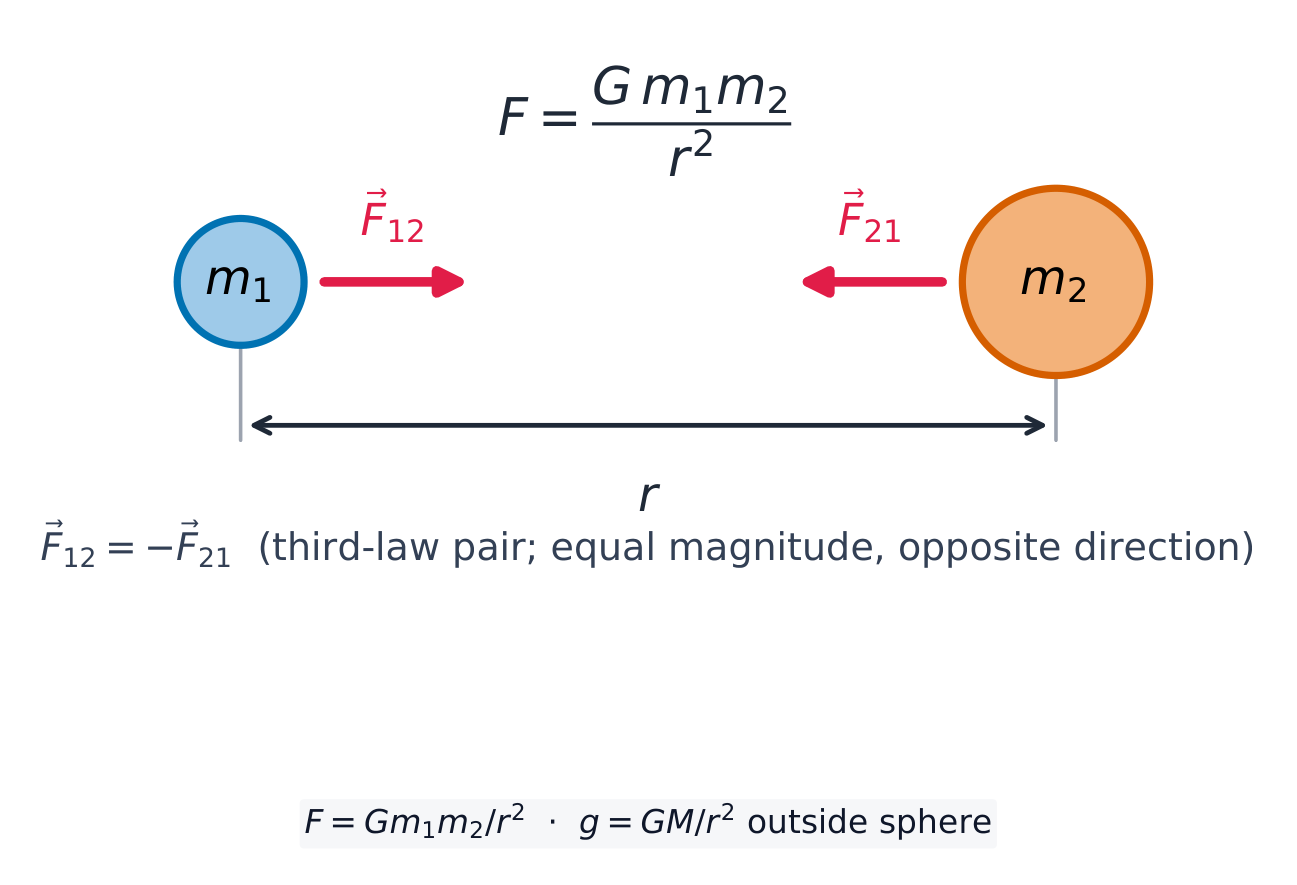
    Near a surface, weight is $F_g=mg$. In general, Newton's law of gravitation 万有引力定律:

    $$F_g=\frac{Gm_1m_2}{r^2},$$
    attractive and inverse-square. The gravitational field is $g=\dfrac{GM}{r^2}$.

    Two masses attract each other with equal, opposite, inverse-square forces along the line joining them
    Two masses attract each other with equal, opposite, inverse-square forces along the line joining them
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Newton's law of gravitation/ˈnjuːtnz lɔː ɒv ˌɡrævɪˈteɪʃn/ Hukum gravitasi Newton
    2.7

    Kinetic and Static Friction

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.7.A: Describe kinetic friction between two surfaces.

    • 2.7.A.1 Kinetic friction occurs when two surfaces in contact move relative to each other.
      • 2.7.A.1.i The kinetic friction force is exerted in a direction opposite the motion of each surface relative to the other surface.
      • 2.7.A.1.ii The force of friction between two surfaces does not depend on the size of the surface area of contact.
    • 2.7.A.2 The magnitude of the kinetic friction force exerted on an object is the product of the normal force the surface exerts on the object and the coefficient of kinetic friction.
      • Equation: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
      • 2.7.A.2.i The coefficient of kinetic friction depends on the material properties of the surfaces that are in contact.
      • 2.7.A.2.ii Normal force is the perpendicular component of the force exerted on an object by the surface with which it is in contact; it is directed away from the surface.

    Learning Objective 2.7.B: Describe static friction between two surfaces.

    • 2.7.B.1 Static friction may occur between the contacting surfaces of two objects that are not moving relative to each other.
    • 2.7.B.2 Static friction adopts the value and direction required to prevent an object from slipping or sliding on a surface.
      • Equation: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
      • 2.7.B.2.i Slipping and sliding refer to situations in which two surfaces are moving relative to each other.
      • 2.7.B.2.ii There exists a maximum value for which static friction will prevent an object from slipping on a given surface.
        • Derived equation: $F_{f,s,\text{max}} = \mu_s F_N$
    • 2.7.B.3 The coefficient of static friction is typically greater than the coefficient of kinetic friction for a given pair of surfaces.
    Bahasa Indonesia

    Tujuan Pembelajaran 2.7.A: Deskripsikan gesekan kinetik antara dua permukaan.

    • 2.7.A.1 Gesekan kinetik terjadi ketika dua permukaan yang bersentuhan bergerak relatif satu sama lain.
      • 2.7.A.1.i Gaya gesekan kinetik diberikan dalam arah berlawanan dengan gerakan setiap permukaan relatif terhadap permukaan lainnya.
      • 2.7.A.1.ii Besar gaya gesekan antara dua permukaan tidak bergantung pada luas area kontak permukaan.
    • 2.7.A.2 Besar gaya gesekan kinetik yang bekerja pada suatu benda adalah hasil kali gaya normal yang diberikan permukaan pada benda dan koefisien gesekan kinetik.
      • Persamaan: $\left| \vec{F}_{f,k} \right| = \left| \mu_k \vec{F}_N \right|$
      • 2.7.A.2.i Koefisien gesekan kinetik bergantung pada sifat material permukaan yang bersentuhan.
      • 2.7.A.2.ii Gaya normal adalah komponen tegak lurus dari gaya yang diberikan pada suatu benda oleh permukaan tempat benda itu bersentuhan; arahnya menjauhi permukaan.

    Tujuan Pembelajaran 2.7.B: Jelaskan gesekan statis antara dua permukaan.

    • 2.7.B.1 Gesekan statis dapat terjadi antara permukaan yang bersentuhan dari dua benda yang tidak bergerak relatif satu sama lain.
    • 2.7.B.2 Gesekan statis mengambil nilai dan arah yang diperlukan untuk mencegah benda tergelincir atau tergelinding di atas permukaan.
      • Persamaan: $\left| \vec{F}_{f,s} \right| \leq \left| \mu_s \vec{F}_n \right|$
      • 2.7.B.2.i Tergelincir dan tergelinding merujuk pada situasi di mana dua permukaan bergerak relatif satu sama lain.
      • 2.7.B.2.ii Terdapat nilai maksimum di mana gesekan statis akan mencegah benda tergelincir di atas suatu permukaan tertentu.
        • Persamaan turunan: $F_{f,s,\text{max}} = \mu_s F_N$
    • 2.7.B.3 Koefisien gesekan statis biasanya lebih besar daripada koefisien gesekan kinetik untuk sepasang permukaan tertentu.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Friction 摩擦力 opposes sliding along a surface: kinetic 动摩擦 $f_k=\mu_k N$ while sliding, and static 静摩擦 $f_s\le\mu_s N$ up to a maximum before sliding. $N$ is the normal force 法向力. Note the inequality: static friction is only as large as it needs to be, and $\mu_s N$ is its ceiling, not its value.

    Worked example. The same block on the same $30^{\circ}$ incline, now with $\mu_k=0.20$. Perpendicular to the ramp: $N=mg\cos30^{\circ}$. Along the ramp: $ma=mg\sin30^{\circ}-\mu_k mg\cos30^{\circ}$, so $a=g(\sin30^{\circ}-0.20\cos30^{\circ})=9.8(0.500-0.173)=3.2\ \text{m/s}^2$ – the mass cancels again.

    Explore · ⁨Jelajahi⁩

    Slide a block down a slope with friction · ⁨Geser balok menuruni lereng dengan gesekan⁩

    Friction opposes motion up to a maximum $\mu N$. Tilt the slope until gravity's pull along it beats static friction and the block starts to slide. · ⁨Gesekan melawan gerakan hingga maksimum tertentu $\mu N$. Condongkan lereng hingga tarikan gravitasi di sepanjangnya mengalahkan gesekan statis dan balok mulai tergelincir.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Friction/ˈfrɪkʃn/ Gesekan
    kinetic/kɪˈnetɪk/ kinetik
    static/ˈstætɪk/ statis
    normal force/ˈnɔːml fɔːs/ gaya normal
    2.8

    Spring Forces

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.8.A: Describe the force exerted on an object by an ideal spring.

    • 2.8.A.1 An ideal spring has negligible mass and exerts a force that is proportional to the change in its length as measured from its relaxed length. A nonideal spring either has nonnegligible mass or exerts a force that is not proportional to the change in its length as measured from its relaxed length.
    • 2.8.A.2 The magnitude of the force exerted by an ideal spring on an object is given by Hooke's law:
      • Equation: $\vec{F}_s = -k \Delta \vec{x}$
    • 2.8.A.3 The force exerted on an object by a spring is always directed toward the equilibrium position of the object–spring system.

    Learning Objective 2.8.B: Describe the equivalent spring constant of a combination of springs exerting forces on an object.

    • 2.8.B.1 A collection of springs that exert forces on an object may behave as though they were a single spring with an equivalent spring constant $k_{\text{eq}}$.
      • 2.8.B.1.i The inverse of the equivalent spring constant of a set of springs in series is equal to the sum of the inverses of the individual spring constants.
        • Derived equation: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
      • 2.8.B.1.ii The equivalent spring constant of a set of springs arranged in series is smaller than the smallest constituent spring constant.
      • 2.8.B.1.iii The equivalent spring constant of a set of springs arranged in parallel is the sum of the individual spring constants.
        • Derived equation: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$

    Boundary statement: AP Physics C: Mechanics only expects students to find the effective spring constant of systems of springs that are arranged either in series or in parallel and does not expect students to find the effective spring constant of a system in which springs are arranged in both series and parallel.

    Bahasa Indonesia

    Tujuan Pembelajaran 2.8.A: Deskripsikan gaya yang diberikan pada suatu benda oleh pegas ideal.

    • 2.8.A.1 Pegas ideal memiliki massa yang dapat diabaikan dan memberikan gaya yang berbanding lurus dengan perubahan panjangnya saat diukur dari panjang rileksnya. Pegas non-ideal baik memiliki massa yang tidak dapat diabaikan atau memberikan gaya yang tidak berbanding lurus dengan perubahan panjangnya saat diukur dari panjang rileksnya.
    • 2.8.A.2 Besar gaya yang diberikan oleh pegas ideal pada suatu benda dinyatakan oleh hukum Hooke:
      • Persamaan: $\vec{F}_s = -k \Delta \vec{x}$
    • 2.8.A.3 Gaya yang diberikan pada suatu benda oleh pegas selalu diarahkan menuju posisi kesetimbangan sistem benda-pegas.

    Tujuan Pembelajaran 2.8.B: Deskripsikan konstanta pegas ekuivalen dari kombinasi pegas yang memberikan gaya pada suatu benda.

    • 2.8.B.1 Kumpulan pegas yang memberikan gaya pada suatu benda dapat berperilaku seolah-olah mereka adalah satu pegas dengan konstanta pegas ekuivalen $k_{\text{eq}}$.
      • 2.8.B.1.i Kebalikan dari konstanta pegas ekuivalen dari sekumpulan pegas yang disusun seri sama dengan jumlah dari kebalikan dari konstanta pegas individu.
        • Persamaan turunan: $\dfrac{1}{k_{\text{eq, series}}} = \sum_i \dfrac{1}{k_i} = \dfrac{1}{k_1} + \dfrac{1}{k_2} + \dots$
      • 2.8.B.1.ii Konstanta pegas ekuivalen dari sekumpulan pegas yang disusun seri lebih kecil daripada konstanta pegas penyusun terkecil.
      • 2.8.B.1.iii Konstanta pegas ekuivalen dari sekumpulan pegas yang disusun paralel adalah jumlah dari konstanta pegas individu.
        • Persamaan turunan: $k_{\text{eq, parallel}} = \sum_i k_i = k_1 + k_2 + \dots$

    Pernyataan Batas: AP Physics C: Mekanika hanya mengharapkan siswa untuk menemukan konstanta pegas efektif dari sistem pegas yang disusun baik secara seri maupun paralel dan tidak mengharapkan siswa untuk menemukan konstanta pegas efektif dari sistem di mana pegas disusun dalam seri dan paralel sekaligus.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Hooke's law & the elastic limit

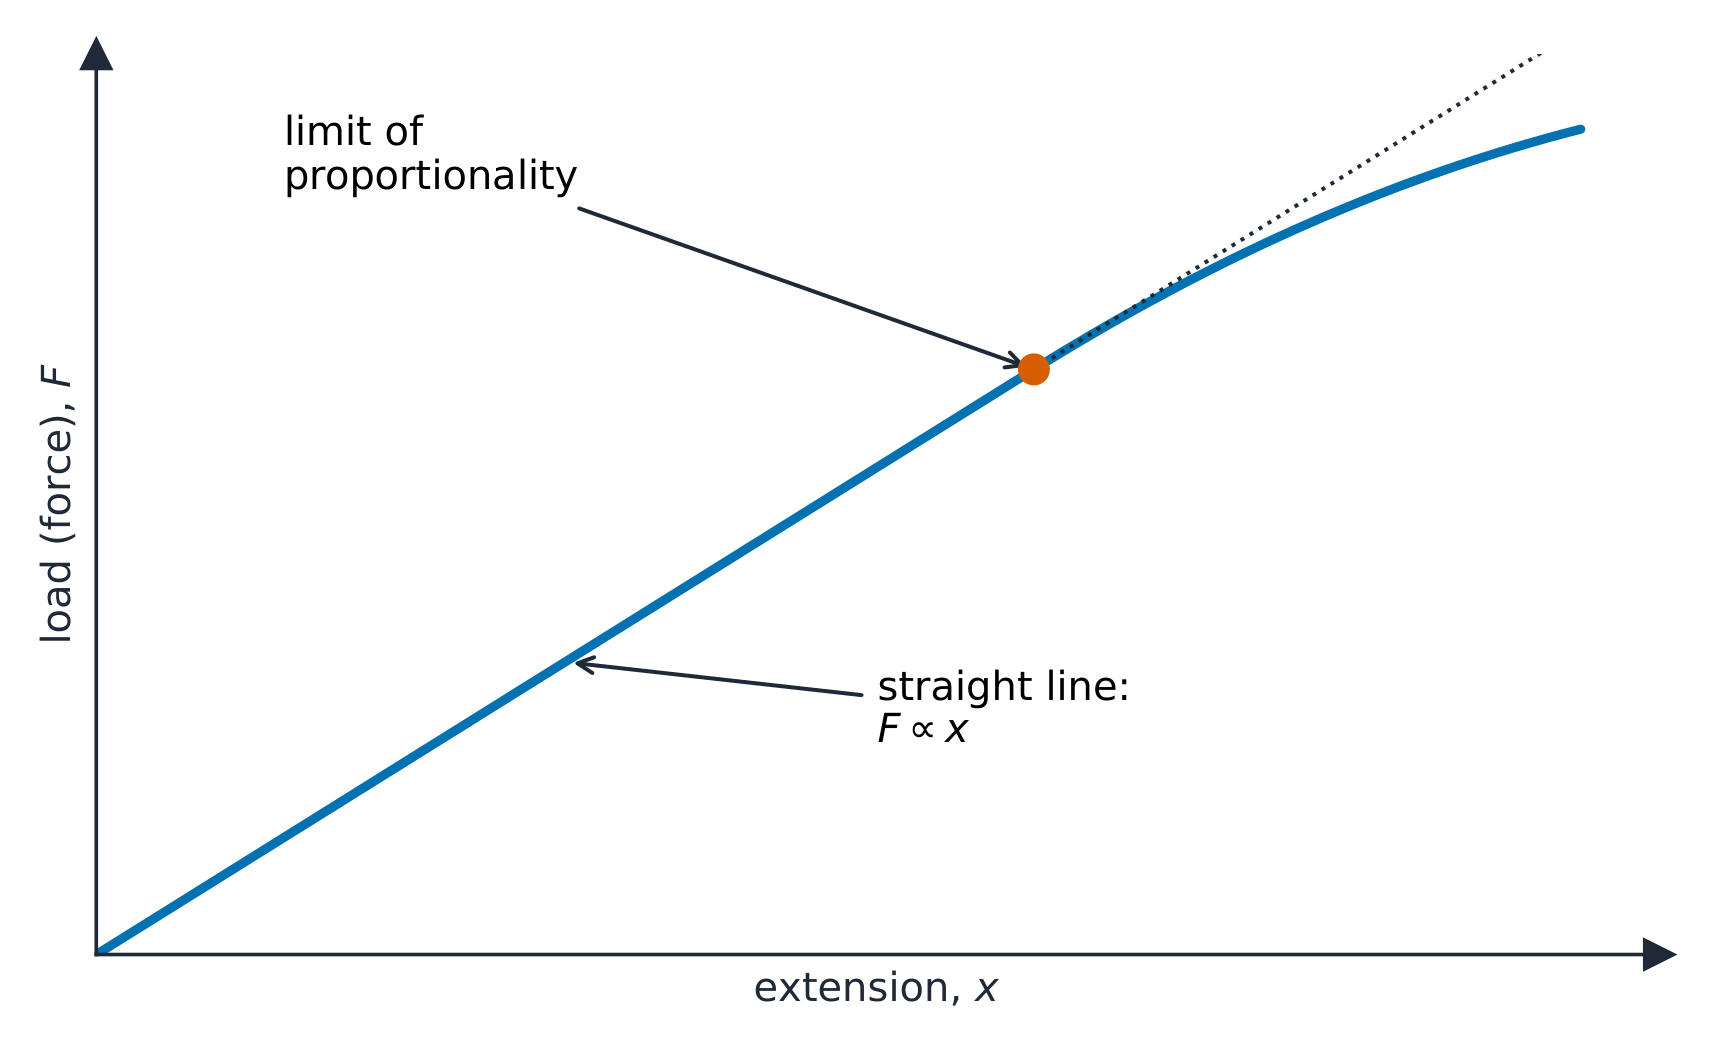
    An ideal spring obeys Hooke's law 胡克定律 $F_s=-kx$, a restoring force set by the spring constant 弹簧劲度系数 $k$. Its stored energy is $U=\tfrac12 kx^2$.

    Hooke's law: extension is proportional to load up to the limit of proportionality
    Hooke's law: extension is proportional to load up to the limit of proportionality

    Combined springs act as one equivalent spring of constant $k_{\text{eq}}$. In parallel (side by side, sharing the load) the constants add, $k_{\text{eq}}=k_1+k_2$ – stiffer than either. In series (end to end) they combine as $\dfrac{1}{k_{\text{eq}}}=\dfrac{1}{k_1}+\dfrac{1}{k_2}$ – softer than the softest one. Two springs pulling a mass from opposite sides also act in parallel, giving a restoring constant $k_1+k_2$. Whichever you have, the SHM period uses $k_{\text{eq}}$: $T=2\pi\sqrt{m/k_{\text{eq}}}$.

    Explore · ⁨Jelajahi⁩

    Stretch a spring (Hooke's law) · ⁨Regangkan pegas (Hukum Hooke)⁩

    A spring's force is proportional to its extension, $F=kx$ (Hooke's law). Pull harder and the extension grows in step — until the spring's limit. · ⁨Gaya pegas berbanding lurus dengan perpanjangan-nya, $F=kx$ (Hukum Hooke). Tarik lebih keras dan perpanjangan bertambah secara proporsional — hingga batas elastis pegas.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Hooke's law/hʊks lɔː/ Hukum Hooke
    spring constant/sprɪŋ ˈkɒnstənt/ konstanta pegas
    2.9

    Resistive Forces

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.9.A: Describe the motion of an object subject to a resistive force.

    • 2.9.A.1 A resistive force is defined as a velocity-dependent force in the opposite direction of an object's velocity, for example:
      • Equation: $\vec{F}_r = -k\vec{v}$
    • 2.9.A.2 Applying Newton's second law to an object upon which a resistive force is exerted results in a differential equation for velocity.
      • 2.9.A.2.i Using the method of separation of variables, the velocity can be determined by integrating over the proper limits of integration.
      • 2.9.A.2.ii The acceleration or position of a moving object that is subject to a velocity-dependent force may be determined using initial conditions of the object and methods of calculus, once a function for velocity is determined.
      • 2.9.A.2.iii The position, velocity, and acceleration as functions of time of an object under the influence of a resistive force of the form $\vec{F}_r = -k\vec{v}$ are exponential and have asymptotes that are determined by the initial conditions of the object and the forces exerted on the object.
    • 2.9.A.3 Terminal velocity is defined as the maximum speed achieved by an object moving under the influence of a constant force and a resistive force that are exerted on the object in opposite directions. The terminal condition is reached when the net force exerted on the object is zero.
    Bahasa Indonesia

    Tujuan Pembelajaran 2.9.A: Deskripsikan gerakan benda yang tunduk pada gaya resistif.

    • 2.9.A.1 Gaya resistif didefinisikan sebagai gaya yang bergantung pada kecepatan dalam arah berlawanan dengan kecepatan benda, misalnya:
      • Persamaan: $\vec{F}_r = -k\vec{v}$
    • 2.9.A.2 Menerapkan hukum kedua Newton pada suatu objek yang dikenai gaya hambat menghasilkan persamaan diferensial untuk kecepatan.
      • 2.9.A.2.i Menggunakan metode pemisahan variabel, kecepatan dapat ditentukan dengan mengintegralkan batas integrasi yang sesuai.
      • 2.9.A.2.ii Percepatan atau posisi objek bergerak yang tunduk pada gaya bergantung-kecepatan dapat ditentukan menggunakan kondisi awal objek dan metode kalkulus, setelah fungsi kecepatan diperoleh.
      • 2.9.A.2.iii Posisi, kecepatan, dan percepatan sebagai fungsi waktu dari sebuah objek di bawah pengaruh gaya hambat berbentuk $\vec{F}_r = -k\vec{v}$ bersifat eksponensial dan memiliki asimtot yang ditentukan oleh kondisi awal objek serta gaya-gaya yang bekerja pada objek tersebut.
    • 2.9.A.3 Kecepatan terminal didefinisikan sebagai kecepatan maksimum yang dicapai oleh objek yang bergerak di bawah pengaruh gaya konstan dan gaya hambat yang bekerja pada objek dalam arah berlawanan. Kondisi terminal tercapai ketika resultan gaya yang bekerja pada objek adalah nol.
    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

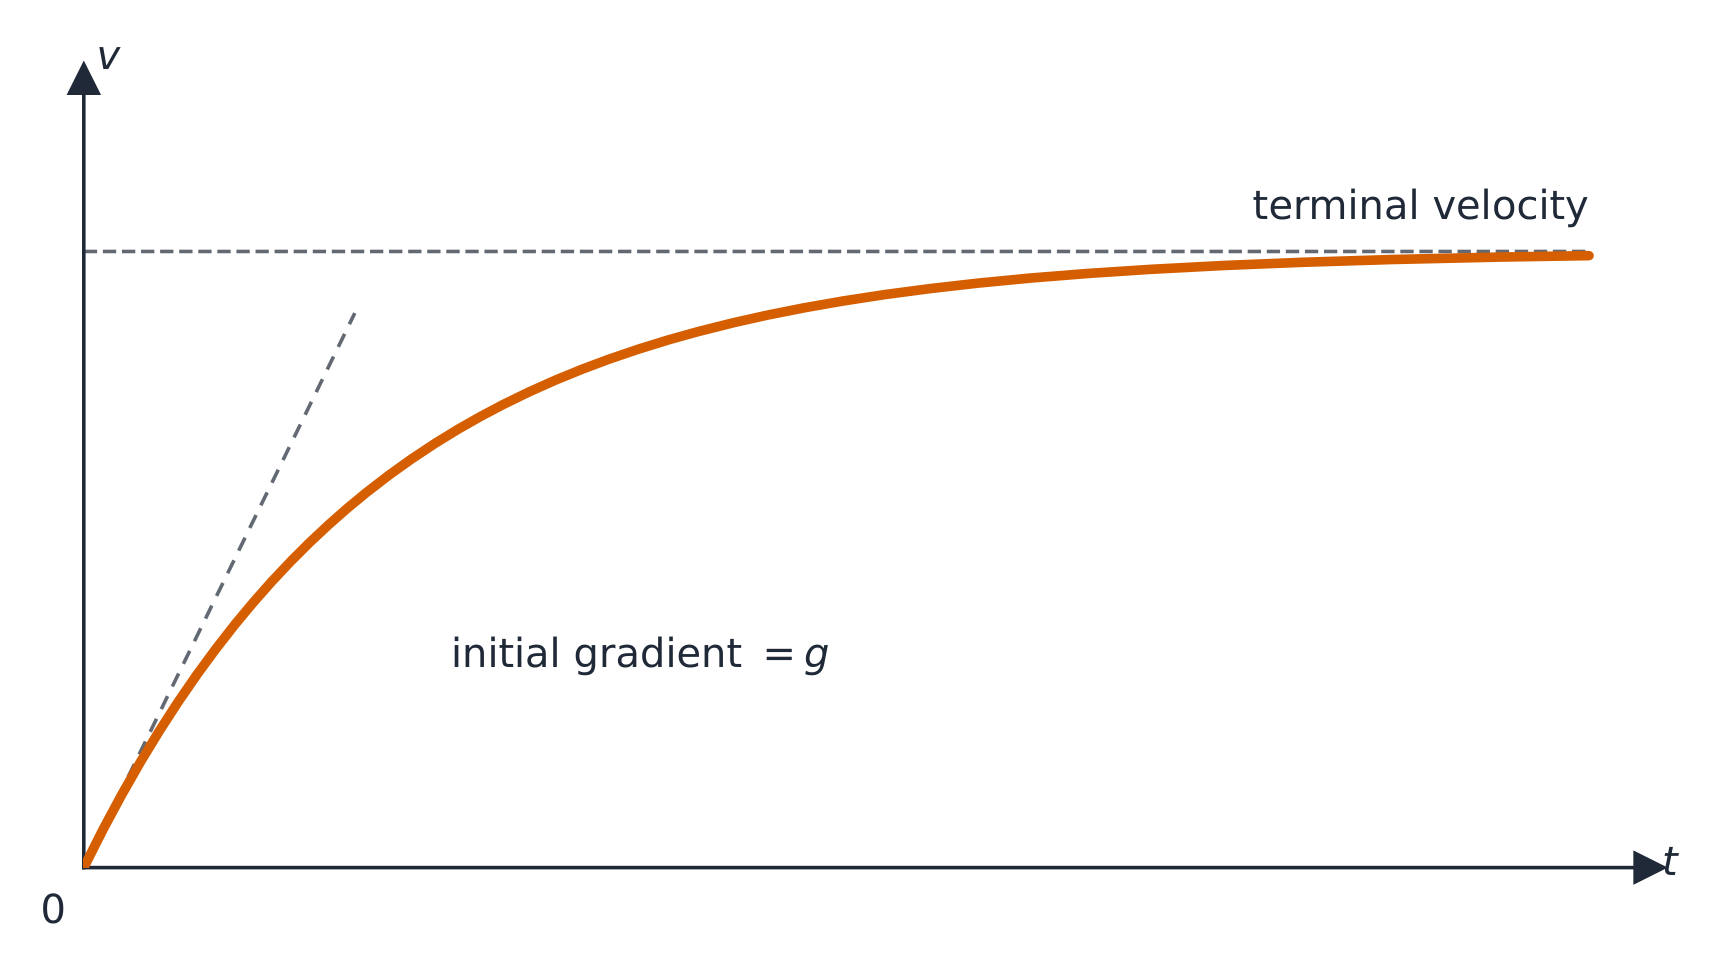
    A resistive force 阻力 (drag) opposes motion through a fluid and grows with speed, often modeled as $F=-bv$ or $F=-cv^2$. Newton's second law then gives a differential equation, e.g. $m\dfrac{dv}{dt}=mg-bv$ for a falling object. As speed rises, drag builds until it balances the driving force; the object then stops accelerating and moves at a constant terminal velocity 终极速度, found by setting the net force (and $dv/dt$) to zero.

    Worked example. For a falling object with $m\dfrac{dv}{dt}=mg-bv$, the terminal velocity is where $\dfrac{dv}{dt}=0$: $mg=bv_T$, so $v_T=\dfrac{mg}{b}$. With $m=0.10\ \text{kg}$ and $b=0.50\ \text{kg/s}$, $v_T=\dfrac{0.10(9.8)}{0.50}=2.0\ \text{m/s}$.

    To get the full motion $v(t)$, separate the variables 分离变量 and integrate from rest:

    $$\int_0^{v}\frac{dv'}{mg-bv'}=\int_0^{t}\frac{dt'}{m}\;\Rightarrow\;-\frac{1}{b}\ln\!\frac{mg-bv}{mg}=\frac{t}{m},$$
    which rearranges to $v(t)=v_T\left(1-e^{-bt/m}\right)$ – the speed rising exponentially toward $v_T$. Showing this integration is the calculus skill a Physics C free-response rewards, not just quoting the final formula.

    An object falling through a fluid speeds up to a terminal velocity
    An object falling through a fluid speeds up to a terminal velocity
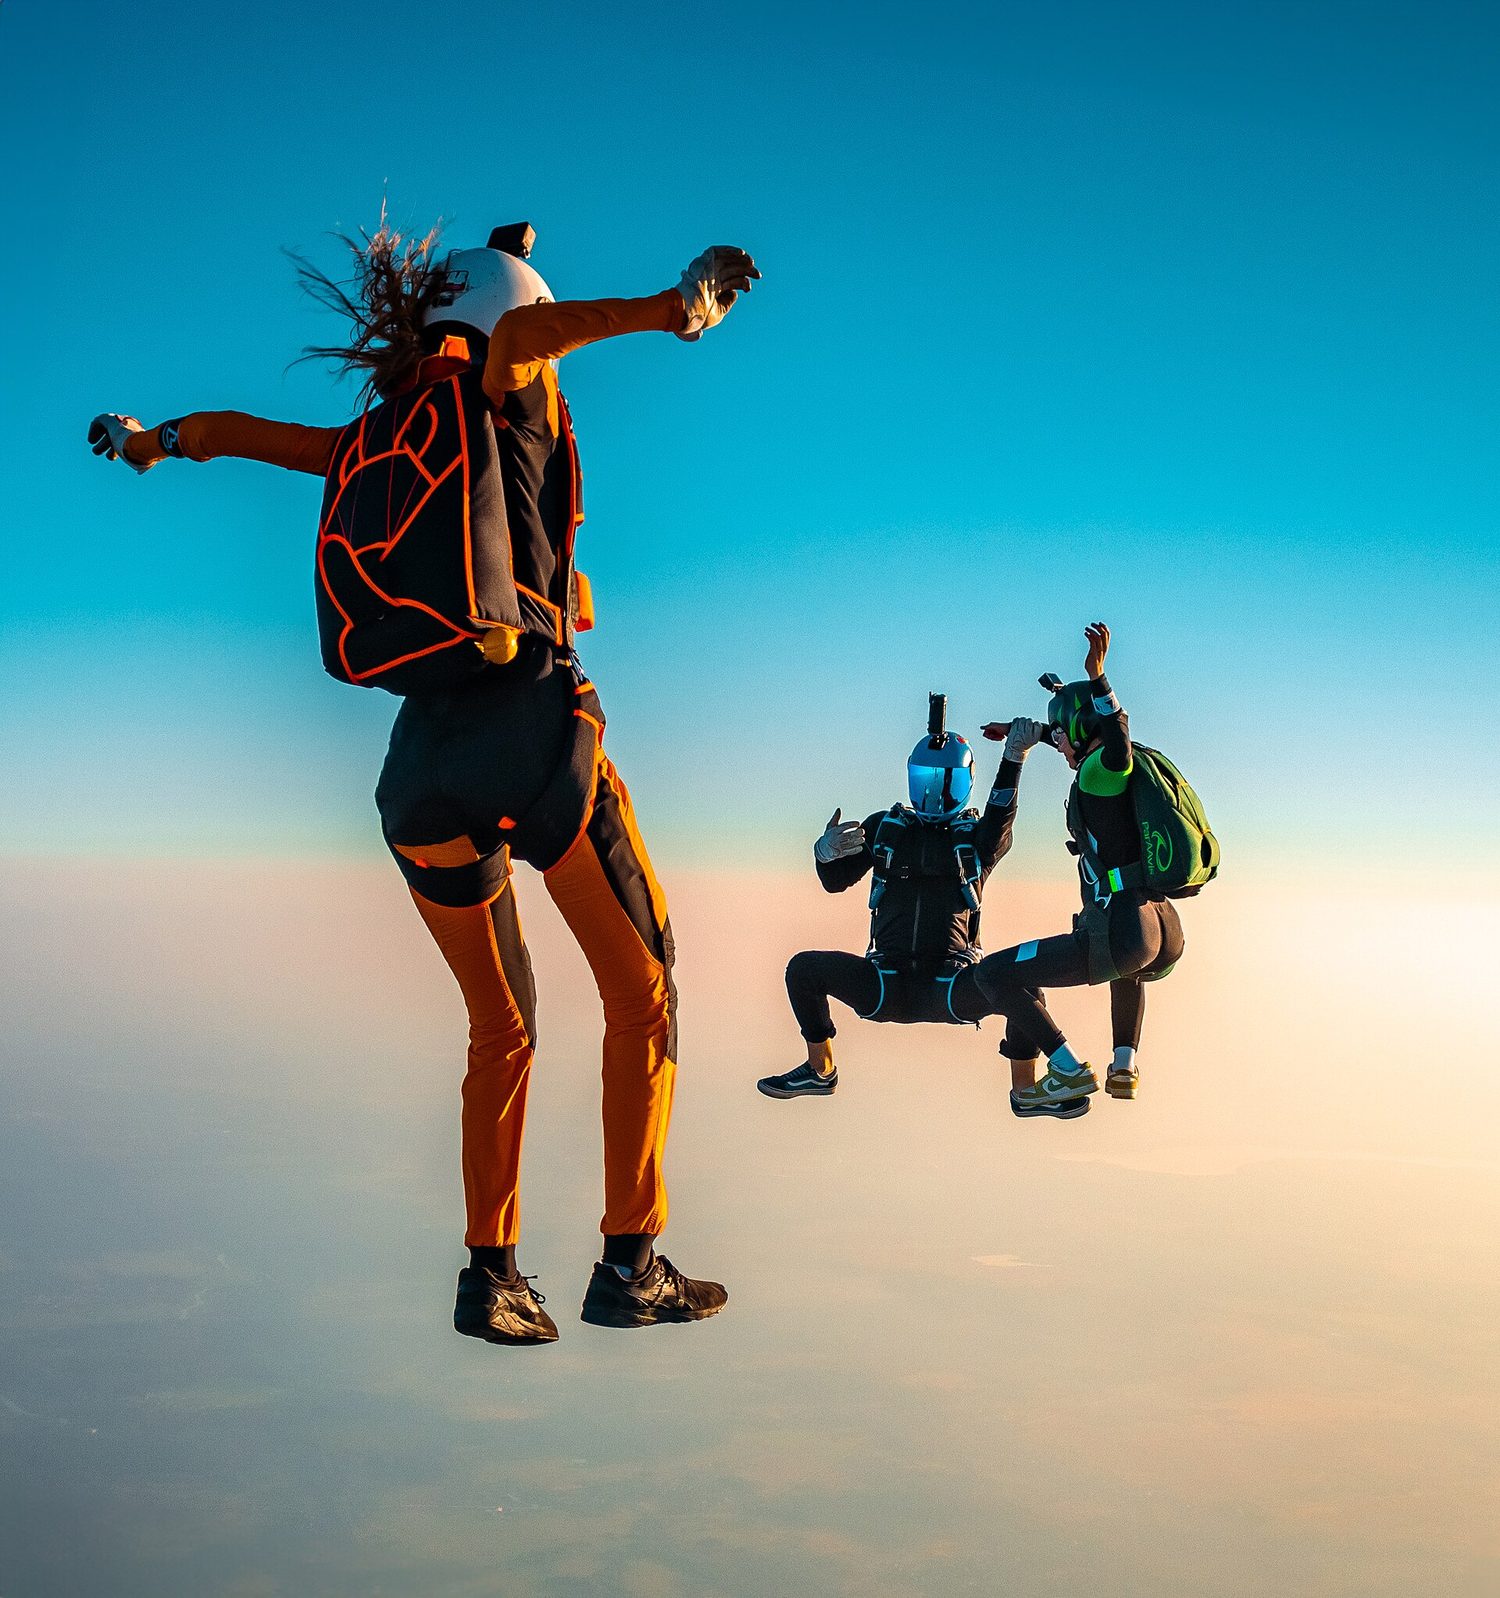
    Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity
    Skydivers in freefall: drag grows with speed until it balances weight at terminal velocity
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    resistive force/rɪˈzɪstɪv fɔːs/ gaya resistif
    terminal velocity/ˈtɜːmɪnl vəˈlɒsɪti/ kecepatan terminal
    separate the variables/ˈseprət ðə ˈveərɪəblz/ Memisahkan variabel
    2.10

    Circular Motion

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 2.10.A: Describe the motion of an object traveling in a circular path.

    • 2.10.A.1 Centripetal acceleration is the component of an object's acceleration directed toward the center of the object's circular path.
      • 2.10.A.1.i The magnitude of centripetal acceleration for an object moving in a circular path is the ratio of the object's tangential speed squared to the radius of the circular path.
        • Equation: $a_c = \dfrac{v^2}{r}$
      • 2.10.A.1.ii Centripetal acceleration is directed toward the center of an object's circular path.
    • 2.10.A.2 Centripetal acceleration can result from a single force, more than one force, or components of forces that are exerted on an object in circular motion.
      • 2.10.A.2.i At the top of a vertical, circular loop, an object requires a minimum speed to maintain circular motion. At this point, and with this minimum velocity, the gravitational force is the only force that causes the centripetal acceleration.
        • Derived equation: $v = \sqrt{gr}$
      • 2.10.A.2.ii Components of the static friction force and the normal force can contribute to the net force producing centripetal acceleration of an object traveling in a circle on a banked surface.
      • 2.10.A.2.iii A component of tension contributes to the net force producing centripetal acceleration experienced by a conical pendulum.
    • 2.10.A.3 Tangential acceleration is the rate at which an object's speed changes and is directed tangent to the object's circular path.
    • 2.10.A.4 The net acceleration of an object moving in a circle is the vector sum of the centripetal acceleration and tangential acceleration.
    • 2.10.A.5 The revolution of an object traveling in a circular path at a constant speed (uniform circular motion) can be described using period and frequency.
      • 2.10.A.5.i The time to complete one full circular path, one full rotation, or a full cycle of oscillatory motion is defined as period, $T$.
      • 2.10.A.5.ii The rate at which an object is completing revolutions is defined as frequency, $f$.
        • Equation: $T = \dfrac{1}{f}$
      • 2.10.A.5.iii For an object traveling at a constant speed in a circular path, the period is given by the derived equation
        • Derived equation: $T = \dfrac{2\pi r}{v}$

    Learning Objective 2.10.B: Describe circular orbits using Kepler's third law.

    • 2.10.B.1 For a satellite in circular orbit around a central body, the satellite's centripetal acceleration is caused only by gravitational attraction. The period and radius of the circular orbit are related to the mass of the central body.
      • Derived equation: $T^2 = \dfrac{4\pi^2}{GM} R^3$

    Boundary statement: AP Physics C: Mechanics does not expect students to know Kepler's first or second laws of planetary motion.

    Bahasa Indonesia

    Tujuan Pembelajaran 2.10.A: Deskripsikan gerak sebuah benda yang bergerak sepanjang lintasan melingkar.

    • 2.10.A.1 Percepatan sentripetal adalah komponen dari percepatan benda yang mengarah ke pusat lintasan melingkarnya.
      • 2.10.A.1.i Besar percepatan sentripetal untuk benda yang bergerak dalam lintasan melingkar adalah rasio kecepatan tangensial benda yang dikuadratkan terhadap jari-jari lintasan melingkar.
        • Persamaan: $a_c = \dfrac{v^2}{r}$
      • 2.10.A.1.ii Percepatan sentripetal mengarah ke pusat lintasan melingkar benda.
    • 2.10.A.2 Percepatan sentripetal dapat dihasilkan oleh satu gaya, lebih dari satu gaya, atau komponen gaya yang bekerja pada benda dalam gerak melingkar.
      • 2.10.A.2.i Di bagian atas lintasan melingkar vertikal, sebuah benda memerlukan kecepatan minimum untuk mempertahankan gerak melingkar. Pada titik ini, dan dengan kecepatan minimum ini, gaya gravitasi adalah satu-satunya gaya yang menyebabkan percepatan sentripetal.
        • Persamaan turunan: $v = \sqrt{gr}$
      • 2.10.A.2.ii Komponen gaya gesekan statis dan gaya normal dapat berkontribusi terhadap gaya total yang menghasilkan percepatan sentripetal bagi benda yang bergerak di lingkaran pada permukaan miring.
      • 2.10.A.2.iii Komponen tegangan berkontribusi terhadap gaya total yang menghasilkan percepatan sentripetal yang dialami oleh pendulum konus.
    • 2.10.A.3 Percepatan tangensial adalah laju perubahan kecepatan benda dan arahnya menyinggung lintasan melingkar benda.
    • 2.10.A.4 Percepatan total benda yang bergerak dalam lingkaran adalah jumlah vektor dari percepatan sentripetal dan percepatan tangensial.
    • 2.10.A.5 Rotasi benda yang bergerak dalam lintasan melingkar dengan kecepatan konstan (gerak melingkar beraturan) dapat dijelaskan menggunakan periode dan frekuensi.
      • 2.10.A.5.i Waktu untuk menyelesaikan satu lintasan melingkar penuh, satu putaran penuh, atau satu siklus lengkap gerakan osilatif didefinisikan sebagai periode, $T$.
      • 2.10.A.5.ii Laju di mana sebuah benda menyelesaikan rotasi didefinisikan sebagai frekuensi, $f$.
        • Persamaan: $T = \dfrac{1}{f}$
      • 2.10.A.5.iii Untuk benda yang bergerak dengan kecepatan konstan dalam lintasan melingkar, periode diberikan oleh persamaan turunan
        • Persamaan turunan: $T = \dfrac{2\pi r}{v}$

    Tujuan Pembelajaran 2.10.B: Deskripsikan orbit melingkar menggunakan hukum ketiga Kepler.

    • 2.10.B.1 Untuk satelit dalam orbit melingkar di sekitar tubuh pusat, percepatan sentripetal satelit hanya disebabkan oleh tarikan gravitasi. Periode dan jari-jari orbit melingkar terkait dengan massa tubuh pusat.
      • Persamaan Turunan: $T^2 = \dfrac{4\pi^2}{GM} R^3$

    Pernyataan Batas: AP Physics C: Mekanika tidak mengharuskan siswa mengetahui hukum pertama atau kedua Kepler tentang gerak planet.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    Uniform circular motion

    Uniform circular motion has a centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}$ pointing to the center, requiring a net inward force $F_c=\dfrac{mv^2}{r}$ supplied by a real force (tension, gravity, friction, normal). There is no outward force. For vertical circles and banked curves, decompose the real forces to find which provides the centripetal requirement.

    Worked example. A $0.50\ \text{kg}$ ball is whirled on a $1.0\ \text{m}$ string in a horizontal circle at $3.0\ \text{m/s}$. The string tension supplies the whole centripetal force: $T=\dfrac{mv^2}{r}=\dfrac{0.50(3.0)^2}{1.0}=4.5\ \text{N}$.

    Worked example (vertical circle). At the top of a vertical loop of radius $r$, gravity and the normal force both point toward the center: $N+mg=\dfrac{mv^2}{r}$. The slowest possible speed at the top is where the track pushes with nothing at all ($N=0$): $v_{\min}=\sqrt{gr}$. For $r=2.5\ \text{m}$: $v_{\min}=\sqrt{9.8(2.5)}=4.9\ \text{m/s}$. Any slower and the cart leaves the track before the top.

    The velocity points along the tangent; the centripetal force points to the centre
    The velocity points along the tangent; the centripetal force points to the centre
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ percepatan sentripetal
    2.10

    Exam tips

    • Locate the center of mass with $x_{cm}=\tfrac{1}{M}\int x\,dm$ (or $\tfrac{\sum m_i x_i}{\sum m_i}$ for point masses) and use $\lambda,\sigma,\rho$ for the mass element.
    • The net external force moves the center of mass as if all mass sat there: $\vec F_{net}=M\vec a_{cm}$.
    • Define your system clearly — internal forces cancel, so only external forces change its momentum.
    • Exploit symmetry to shortcut a center-of-mass integral.
    • Distinguish center of mass from center of gravity (identical in a uniform field).
  • 3

    Work, Energy, and Power · ⁨Usaha, Energi, dan Daya⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    3.1

    Translational Kinetic Energy · ⁨Energi Kinetik Translasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 3.1.A: Describe the translational kinetic energy of an object in terms of the object's mass and velocity.

    • 3.1.A.1 An object's translational kinetic energy is given by the equation
      • Equation: $K = \dfrac{1}{2}mv^2$
    • 3.1.A.2 Translational kinetic energy is a scalar quantity.
    • 3.1.A.3 Different observers may measure different values of the translational kinetic energy of an object, depending on the observer's frame of reference.
    Bahasa Indonesia

    Tujuan Pembelajaran 3.1.A: Jelaskan energi kinetik translasi suatu benda dalam hubungannya dengan massa dan kecepatan benda tersebut.

    • 3.1.A.1 Energi kinetik translasi suatu benda diberikan oleh persamaan
      • Persamaan: $K = \dfrac{1}{2}mv^2$
    • 3.1.A.2 Energi kinetik translasi adalah besaran skalar.
    • 3.1.A.3 Pengamat yang berbeda mungkin mengukur nilai energi kinetik translasi yang berbeda, tergantung pada kerangka acuan pengamat tersebut.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Kinetic energy 动能 is the energy of motion, a scalar 标量 measured in joules 焦耳 (J):

    $$K=\tfrac{1}{2}mv^2.$$

    It grows with the square of speed – doubling the speed quadruples $K$. One subtlety worth knowing: kinetic energy depends on the observer's reference frame 参考系. A passenger walking down a train has a small $K$ measured inside the train and a huge one measured from the ground – both observers are right, each in their own frame.

    Bahasa Indonesia

    Energi kinetik adalah energi gerak, besaran skalar yang diukur dalam joule (J):

    $$K=\tfrac{1}{2}mv^2.$$

    Gaya hambat tumbuh dengan kuadrat kecepatan – menggandakan kecepatan membuat kuadruplikasi $K$. Satu nuansa penting untuk diketahui: energi kinetik bergantung pada kerangka acuan pengamat. Seorang penumpang berjalan di dalam kereta memiliki $K$ kecil yang terukur di dalam kereta dan sangat besar jika diukur dari tanah – kedua pengamat benar, masing-masing dalam kerangka acuannya sendiri.

    3.2

    Work · ⁨Usaha⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 3.2.A: Describe the work done on an object or system by a given force or collection of forces.

    • 3.2.A.1 Work is the amount of energy transferred into or out of a system by a force exerted on that system over a distance.
      • 3.2.A.1.i The work done by a conservative force exerted on a system is path-independent and only depends on the initial and final configurations of that system.
      • 3.2.A.1.ii The work done by a conservative force on a system—or the change in the potential energy of the system—will be zero if the system returns to its initial configuration.
      • 3.2.A.1.iii Potential energies are associated only with conservative forces.
      • 3.2.A.1.iv The work done by a nonconservative force is path-dependent.
      • 3.2.A.1.v The most common nonconservative forces are friction and air resistance.
    • 3.2.A.2 Work is a scalar quantity that may be positive, negative, or zero.
    • 3.2.A.3 The work done on an object by a variable force is calculated using
      • Equation: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, where the integral is taken over the path from point $a$ to point $b$.
      • 3.2.A.3.i The dot product between two vectors, $\vec{A}$ and $\vec{B}$, results in a scalar quantity of magnitude $\vec{A} \cdot \vec{B} = AB\cos\theta$.
      • 3.2.A.3.ii Only the component of the force exerted on a system that is parallel to the displacement of the point of application of the force will change the system's total energy.
      • 3.2.A.3.iii If the component of the force exerted on a system that is parallel to the displacement is constant, the work done on the system by the force is given by the derived equation $W = F_{\parallel}d = Fd\cos\theta$.
      • 3.2.A.3.iv The component of the force exerted on a system perpendicular to the direction of the displacement of the system's center of mass can change the direction of the system's motion without changing the system's kinetic energy.
    • 3.2.A.4 The work–energy theorem states that the change in an object's kinetic energy is equal to the sum of the work (net work) being done by all forces exerted on the object.
      • Equation: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
      • 3.2.A.4.i An external force may change the configuration of a system. The component of the external force parallel to the displacement times the displacement of the point of application of the force gives the change in kinetic energy of the system.
      • 3.2.A.4.ii If the system's center of mass and the point of application of the force move the same distance when a force is exerted on a system, then the system may be modeled as an object, and only the system's kinetic energy can change.
      • 3.2.A.4.iii The energy dissipated by friction is typically equated to the force of friction times the length of the path over which the force is exerted.
        • Equation: $\Delta E_{\text{mech}} = F_f d\cos\theta$
      • 3.2.A.5 Work is equal to the area under the curve of a graph of $F_{\parallel}$ as a function of displacement.

    Boundary statement: AP Physics C: Mechanics only expects students to analyze the transfer of mechanical energy, although students should be aware that mechanical energy may be dissipated in the form of thermal energy or sound.

    Bahasa Indonesia

    Tujuan Pembelajaran 3.2.A: Jelaskan usaha yang dilakukan pada suatu benda atau sistem oleh gaya tertentu atau kumpulan gaya.

    • 3.2.A.1 Usaha adalah jumlah energi yang ditransfer masuk atau keluar dari sebuah sistem melalui gaya yang bekerja pada sistem tersebut sepanjang jarak tempuh.
      • 3.2.A.1.i Usaha yang dilakukan oleh gaya konservatif pada suatu sistem bersifat independen terhadap lintasan dan hanya bergantung pada konfigurasi awal dan akhir sistem tersebut.
      • 3.2.A.1.ii Usaha yang dilakukan oleh gaya konservatif pada suatu sistem—atau perubahan energi potensial sistem—akan bernilai nol jika sistem kembali ke konfigurasi awalnya.
      • 3.2.A.1.iii Energi potensial hanya terkait dengan gaya-gaya konservatif.
      • 3.2.A.1.iv Usaha yang dilakukan oleh gaya nonkonservatif bergantung pada lintasan.
      • 3.2.A.1.v Gaya nonkonservatif yang paling umum adalah gesekan dan hambatan udara.
    • 3.2.A.2 Usaha adalah besaran skalar yang dapat bernilai positif, negatif, atau nol.
    • 3.2.A.3 Usaha yang dilakukan pada objek oleh gaya berubah dihitung menggunakan
      • Persamaan: $W = \displaystyle\int_a^b \vec{F}(r) \cdot d\vec{r}$, di mana integral diambil sepanjang lintasan dari titik $a$ ke titik $b$.
      • 3.2.A.3.i Hasil kali titik antara dua vektor, $\vec{A}$ dan $\vec{B}$, menghasilkan besaran skalar dengan magnitudo $\vec{A} \cdot \vec{B} = AB\cos\theta$.
      • 3.2.A.3.ii Hanya komponen gaya yang bekerja pada sistem yang sejajar dengan perpindahan titik aplikasi gaya yang akan mengubah energi total sistem.
      • 3.2.A.3.iii Jika komponen gaya yang bekerja pada sistem yang sejajar dengan perpindahan adalah konstan, usaha yang dilakukan pada sistem oleh gaya tersebut diberikan oleh persamaan turunan $W = F_{\parallel}d = Fd\cos\theta$.
      • 3.2.A.3.iv Komponen gaya yang bekerja pada sistem tegak lurus terhadap arah perpindahan pusat massa sistem dapat mengubah arah gerak sistem tanpa mengubah energi kinetik sistem.
    • 3.2.A.4 Teorema usaha-energi menyatakan bahwa perubahan energi kinetik objek sama dengan jumlah usaha (usaha bersih) yang dilakukan oleh semua gaya yang bekerja pada objek.
      • Persamaan: $\Delta K = \displaystyle\sum W_i = \sum F_{\parallel,i}\, d_i$
      • 3.2.A.4.i Gaya eksternal dapat mengubah konfigurasi suatu sistem. Komponen gaya eksternal yang sejajar dengan perpindahan dikali perpindahan titik aplikasi gaya memberikan perubahan energi kinetik sistem.
      • 3.2.A.4.ii Jika pusat massa sistem dan titik aplikasi gaya bergerak sejauh yang sama ketika gaya bekerja pada sistem, maka sistem dapat dimodelkan sebagai benda tunggal, dan hanya energi kinetik sistem yang dapat berubah.
      • 3.2.A.4.iii Energi yang terdisipasi oleh gesekan biasanya disamakan dengan gaya gesek dikalikan dengan panjang lintasan tempat gaya tersebut bekerja.
        • Persamaan: $\Delta E_{\text{mech}} = F_f d\cos\theta$
      • 3.2.A.5 Usaha sama dengan luas di bawah kurva grafik $F_{\parallel}$ sebagai fungsi perpindahan.

    Pernyataan Batas: AP Physics C: Mekanika hanya mengharapkan siswa menganalisis transfer energi mekanik, meskipun siswa harus menyadari bahwa energi mekanik dapat terdisipasi dalam bentuk energi termal atau bunyi.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Work 功 is energy transferred into or out of a system by a force acting over a distance. For a variable force it is an integral 积分 along the path:

    $$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$

    For a constant force this reduces to $W=Fd\cos\theta$; on a force–position graph, work is the area under the curve. Work is a scalar with a sign, and the sign is physics, not bookkeeping:

    • Positive – force has a component along the motion (it speeds the object up).
    • Negative – force opposes the motion (friction 摩擦力 and air drag do negative work).
    • Zero – force perpendicular to the motion (the normal force 法向力 on a sliding block, gravity on a horizontal move, tension in a circular swing).

    The work–energy theorem 动能定理 collects every force's contribution: the net work equals the change in kinetic energy,

    $$W_{\text{net}}=\sum W_i=\Delta K.$$

    Worked example. A variable force $F(x)=3x^2\ \text{N}$ (along the motion) acts from $x=0$ to $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. Acting alone on a body starting from rest, it would raise the kinetic energy to exactly $8\ \text{J}$.

    Bahasa Indonesia

    Usaha adalah energi yang ditransfer masuk atau keluar dari sistem oleh gaya yang bekerja sepanjang jarak. Untuk gaya variabel, usaha merupakan integral sepanjang lintasan:

    $$W=\int_a^b \vec{F}\cdot d\vec{r}=\int F\cos\theta\,dr.$$

    Untuk gaya konstan, ini menyederhanakan menjadi $W=Fd\cos\theta$; pada grafik gaya–posisi, usaha adalah luas di bawah kurva. Usaha adalah skalar dengan tanda, dan tanda tersebut bermakna fisika, bukan sekadar pencatatan:

    • Positif – gaya memiliki komponen sejajar dengan gerak (mempercepat benda).
    • Negatif – gaya berlawanan arah dengan gerak (gesekan dan hambat udara melakukan usaha negatif).
    • Nol – gaya tegak lurus terhadap gerak (gaya normal pada balok meluncur, gravitasi pada gerak horizontal, tegangan pada ayunan melingkar).
    Hanya komponen gaya sepanjang perpindahan yang melakukan usaha
    Hanya komponen gaya sepanjang perpindahan yang melakukan usaha

    Teorema usaha-energi menjumlahkan kontribusi setiap gaya: usaha neto sama dengan perubahan energi kinetik,

    $$W_{\text{net}}=\sum W_i=\Delta K.$$

    Contoh terpecahkan. Gaya variabel $F(x)=3x^2\ \text{N}$ (sejajar dengan gerak) bekerja dari $x=0$ hingga $x=2\ \text{m}$: $W=\displaystyle\int_0^2 3x^2\,dx=\big[x^3\big]_0^2=8\ \text{J}$. Bekerja sendirian pada benda yang mulai dari keadaan diam, gaya ini akan menaikkan energi kinetik tepat sebesar $8\ \text{J}$.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Kinetic energy/kɪˈnetɪk ˈenədʒi/ Energi kinetik
    scalar/ˈskeɪlə/ skalar
    joules/dʒuːlz/ joule
    reference frame/ˈrefrəns freɪm/ kerangka acuan
    Work/wɜːk/ Usaha
    integral/ˈɪntɪɡrəl/ integral
    friction/ˈfrɪkʃn/ gesekan
    normal force/ˈnɔːml fɔːs/ gaya normal
    work–energy theorem/wɜːk ˈenədʒi ˈθɪərəm/ Teorema usaha-energi
    3.3

    Potential Energy · ⁨Energi Potensial⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 3.3.A: Describe the potential energy of a system.

    • 3.3.A.1 A system composed of two or more objects has potential energy if the objects within that system only interact with each other through conservative forces.
    • 3.3.A.2 Potential energy is a scalar quantity associated with the position of objects within a system.
    • 3.3.A.3 The definition of zero potential energy for a given system is a decision made by the observer considering the situation to simplify or otherwise assist in analysis.
    • 3.3.A.4 The relationship between conservative forces exerted on a system and the system's potential energy is
      • Equation: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
    • 3.3.A.5 The conservative forces exerted on a system in a single dimension can be determined using the slope of the system's potential energy with respect to position in that dimension; these forces point in the direction of decreasing potential energy.
      • Equation: $F_x = -\dfrac{dU(x)}{dx}$
    • 3.3.A.6 Graphs of a system's potential energy as a function of its position can be useful in determining physical properties of that system.
      • 3.3.A.6.i Stable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object opposite to the direction of the small displacement, accelerating the object back toward the equilibrium position.
      • 3.3.A.6.ii Unstable equilibrium is a location at which a small displacement in an object's position results in a force exerted on the object in the same direction as the small displacement, accelerating the object away from the equilibrium position.
      • 3.3.A.6.iii In a given dimension, stable equilibrium positions exist at locations where the potential energy as a function of position in that dimension has a local minimum.
      • 3.3.A.6.iv In a given dimension, unstable equilibrium positions occur at locations where the potential energy as a function of position in that dimension has a local maximum.
    • 3.3.A.7 The potential energy of common physical systems can be described using the physical properties of that system.
      • 3.3.A.7.i The elastic potential energy of an ideal spring is given by the following equation, where $\Delta x$ is the distance the spring has been stretched or compressed from its equilibrium length.
        • Equation: $U_s = \dfrac{1}{2}k(\Delta x)^2$
      • 3.3.A.7.ii The general form for the gravitational potential energy of a system consisting of two approximately spherical distributions of mass (e.g., moons, planets, or stars) is given by the equation
        • Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
      • 3.3.A.7.iii Because the gravitational field near the surface of a planet is nearly constant, the change in gravitational potential energy in a system consisting of an object with mass $m$ and a planet with gravitational field of magnitude $g$ when the object is near the surface of the planet may be approximated by the equation
        • Equation: $\Delta U_g = mg\Delta y$
    • 3.3.A.8 The total potential energy of a system containing more than two objects is the sum of the potential energy of each pair of objects within the system.
    Bahasa Indonesia

    Tujuan Pembelajaran 3.3.A: Jelaskan energi potensial suatu sistem.

    • 3.3.A.1 Sistem yang terdiri dari dua atau lebih benda memiliki energi potensial jika benda-benda di dalamnya hanya berinteraksi satu sama lain melalui gaya-gaya konservatif.
    • 3.3.A.2 Energi potensial adalah besaran skalar yang terkait dengan posisi benda-benda di dalam suatu sistem.
    • 3.3.A.3 Definisi nol energi potensial untuk suatu sistem tertentu merupakan keputusan yang diambil oleh pengamat berdasarkan situasi untuk menyederhanakan atau membantu analisis.
    • 3.3.A.4 Hubungan antara gaya konservatif yang bekerja pada sistem dan energi potensial sistem adalah
      • Persamaan: $\Delta U = -\displaystyle\int_a^b \vec{F}_{cf}(r) \cdot d\vec{r}$
    • 3.3.A.5 Gaya konservatif yang bekerja pada sistem dalam satu dimensi dapat ditentukan menggunakan kemiringan energi potensial sistem terhadap posisi dalam dimensi tersebut; gaya-gaya ini mengarah pada penurunan energi potensial.
      • Persamaan: $F_x = -\dfrac{dU(x)}{dx}$
    • 3.3.A.6 Grafik energi potensial sistem sebagai fungsi posisinya dapat berguna dalam menentukan sifat fisik dari sistem tersebut.
      • 3.3.A.6.i Kesetimbangan stabil adalah lokasi di mana pergeseran kecil pada posisi objek menghasilkan gaya yang bekerja pada objek berlawanan arah dengan pergeseran kecil tersebut, mempercepat objek kembali menuju posisi kesetimbangan.
      • 3.3.A.6.ii Kesetimbangan tidak stabil adalah lokasi di mana pergeseran kecil pada posisi objek menghasilkan gaya yang bekerja pada objek searah dengan pergeseran kecil tersebut, mempercepat objek menjauhi posisi kesetimbangan.
      • 3.3.A.6.iii Dalam suatu dimensi tertentu, posisi kesetimbangan stabil terdapat di lokasi di mana energi potensial sebagai fungsi posisi dalam dimensi tersebut memiliki nilai minimum lokal.
      • 3.3.A.6.iv Dalam suatu dimensi tertentu, posisi kesetimbangan tidak stabil terjadi di lokasi di mana energi potensial sebagai fungsi posisi dalam dimensi tersebut memiliki nilai maksimum lokal.
    • 3.3.A.7 Energi potensial dari sistem fisika umum dapat dijelaskan menggunakan sifat fisik dari sistem tersebut.
      • 3.3.A.7.i Energi potensial elastis pegas ideal diberikan oleh persamaan berikut, di mana $\Delta x$ adalah jarak pegas telah diregangkan atau ditekan dari panjang kesetimbangannya.
        • Persamaan: $U_s = \dfrac{1}{2}k(\Delta x)^2$
      • 3.3.A.7.ii Bentuk umum untuk energi potensial gravitasi sistem yang terdiri dari distribusi massa yang kira-kira berbentuk bola (misalnya, bulan, planet, atau bintang) diberikan oleh persamaan
        • Persamaan: $U_g = -G\dfrac{m_1 m_2}{r}$
      • 3.3.A.7.iii Karena medan gravitasi di dekat permukaan planet hampir konstan, perubahan energi potensial gravitasi dalam sistem yang terdiri dari objek bermassa $m$ dan planet dengan besar medan gravitasi $g$ ketika objek berada di dekat permukaan planet dapat didekati oleh persamaan
        • Persamaan: $\Delta U_g = mg\Delta y$
    • 3.3.A.8 Total energi potensial sistem yang mengandung lebih dari dua objek adalah jumlah energi potensial dari setiap pasangan objek di dalam sistem.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Potential energy 势能 is energy a system stores by the positions of its parts – it exists only for conservative forces 保守力, whose work is path independent. It is defined through work:

    $$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$

    and you are free to choose where $U=0$ – only changes in $U$ matter, so pick the zero that makes the problem simplest. The standard results:

    • Gravity near a surface: $\Delta U_g=mg\,\Delta y$.
    • Gravity in general: $U_g=-\dfrac{Gm_1m_2}{r}$ (zero at infinite separation).
    • Spring: $U_s=\tfrac12k(\Delta x)^2$, with $\Delta x$ measured from natural length.

    For systems of several objects, add the potential energy of each pair. Turning the definition around, a conservative force is minus the derivative 导数 of its potential energy:

    $$F_x=-\frac{dU}{dx}.$$

    The force points "downhill" on the $U(x)$ curve. Equilibrium sits where the slope is zero: a minimum is a stable equilibrium 稳定平衡 (displaced, the force pushes back), a maximum is an unstable equilibrium 不稳定平衡 (displaced, the force pushes away).

    Worked example. Given $U(x)=2x^3-6x$ (joules), the force is $F=-\dfrac{dU}{dx}=6-6x^2$. Equilibria sit at $F=0$: $x=\pm1$. Since $\dfrac{d^2U}{dx^2}=12x$ is positive at $x=+1$ (a minimum – stable) and negative at $x=-1$ (a maximum – unstable), the two points behave oppositely.

    Bahasa Indonesia

    Energi potensial adalah energi yang disimpan oleh sistem akibat posisi bagian-bagiannya – hanya ada untuk gaya konservatif, yang usahanya tidak bergantung lintasan. Energi ini didefinisikan melalui usaha:

    $$\Delta U=-\int_a^b\vec{F}\cdot d\vec{r},$$

    dan Anda bebas untuk memilih di mana $U=0$ – hanya perubahan $U$ yang penting, jadi pilih nol yang membuat soal paling sederhana. Hasil standar:

    • Gravitasi dekat permukaan: $\Delta U_g=mg\,\Delta y$.
    • Gravitasi umum: $U_g=-\dfrac{Gm_1m_2}{r}$ (nol pada pemisahan tak terhingga).
    • Pegas: $U_s=\tfrac12k(\Delta x)^2$, dengan $\Delta x$ diukur dari panjang alami.

    Untuk sistem beberapa benda, jumlahkan energi potensial dari setiap pasangan. Membalik definisi, gaya konservatif adalah minus turunan dari energi potensinya:

    $$F_x=-\frac{dU}{dx}.$$

    Gaya menunjuk "turun" pada kurva $U(x)$. Keseimbangan berada di tempat kemiringan nol: minimum adalah keseimbangan stabil (digeser, gaya mendorong kembali), maksimum adalah keseimbangan tidak stabil (digeser, gaya mendorong menjauh).

    Pada kurva energi potensial, gaya mengarah ke bawah dan E = U menandai titik balik
    Pada kurva energi potensial gaya menunjuk turun dan E = U menandai titik balik

    Contoh terpecahkan. Diketahui $U(x)=2x^3-6x$ (joule), gayanya adalah $F=-\dfrac{dU}{dx}=6-6x^2$. Keseimbangan berada di $F=0$: $x=\pm1$. Karena $\dfrac{d^2U}{dx^2}=12x$ bernilai positif di $x=+1$ (minimum – stabil) dan negatif di $x=-1$ (maksimum – tidak stabil), kedua titik tersebut berperilaku berlawanan.
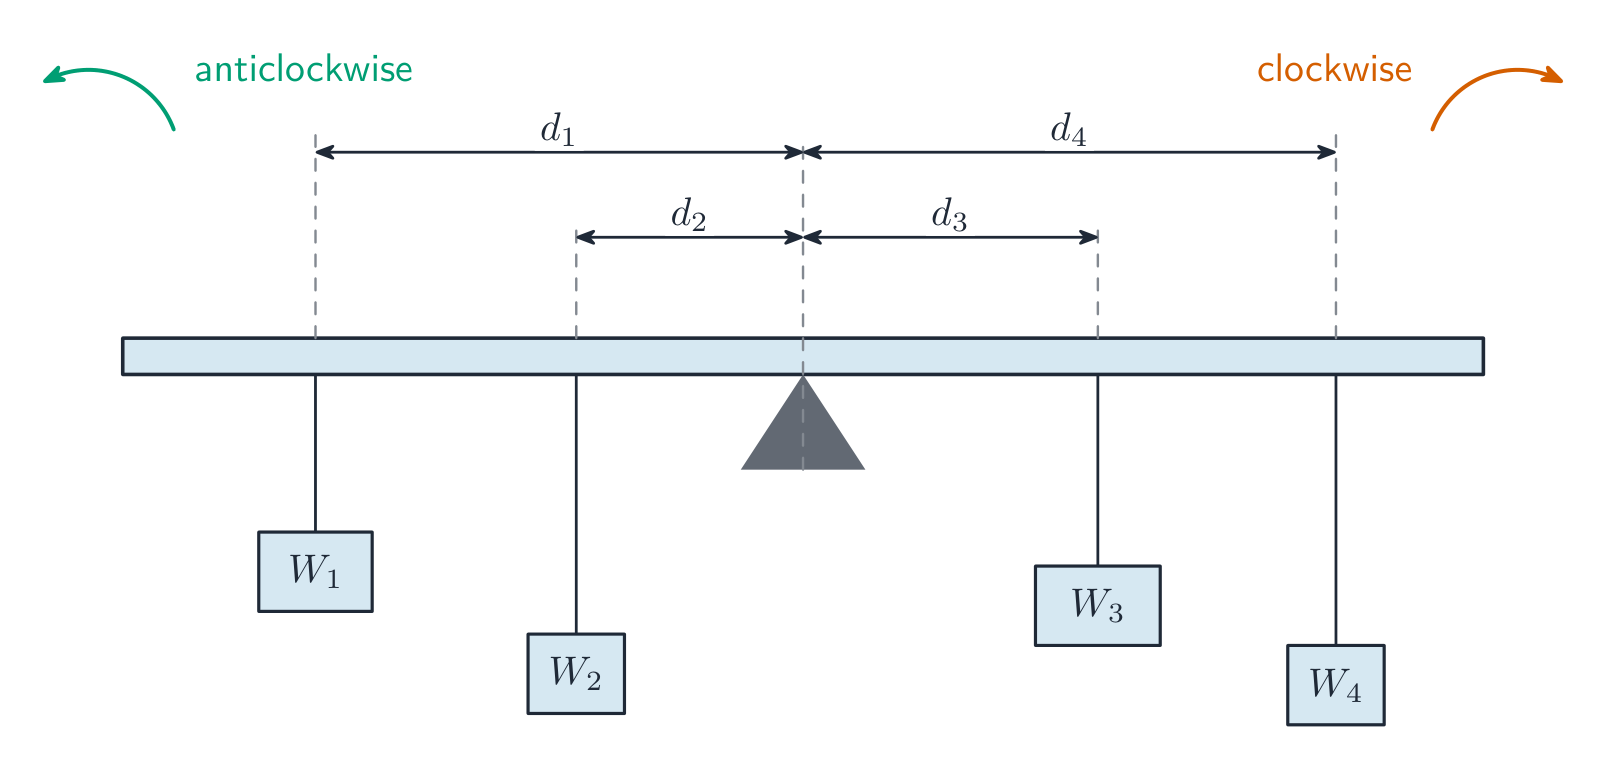
    Explore · ⁨Jelajahi⁩

    Store elastic potential energy in a spring · ⁨Simpan energi potensial elastis dalam pegas⁩

    Stretching a spring stores elastic potential energy $\tfrac12 kx^2$ — the area under the force-extension line. Release it and that energy becomes kinetic. · ⁨Meregangkan pegas menyimpan energi potensial elastis $\tfrac12 kx^2$ — yaitu area di bawah garis gaya-perpanjangan. Lepaskan dan energi tersebut berubah menjadi energi kinetik.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Potential energy/pəˈtenʃl ˈenədʒi/ Energi potensial
    conservative forces/kənˈsɜːvətɪv ˈfɔːsɪz/ Gaya konservatif
    derivative/dɪˈrɪvətɪv/ turunan
    stable equilibrium/ˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ keseimbangan stabil
    unstable equilibrium/ʌnˈsteɪbl ˌiːkwɪˈlɪbrɪəm/ keseimbangan tidak stabil
    Mechanical energy/mɪˈkænɪkl ˈenədʒi/ Energi mekanik
    nonconservative forces/ˌnɒŋkənˈsɜːvətɪv ˈfɔːsɪz/ gaya nonkonservatif
    thermal energy/ˈθɜːml ˈenədʒi/ energi termal
    turning points/ˈtɜːnɪŋ pɔɪnts/ titik balik
    3.4

    Conservation of Energy · ⁨Kekekalan Energi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 3.4.A: Describe the energies present in a system.

    • 3.4.A.1 A system composed of only a single object can only have kinetic energy.
    • 3.4.A.2 A system that contains objects that interact via conservative forces or that can change its shape reversibly may have both kinetic and potential energies.

    Learning Objective 3.4.B: Describe the behavior of a system using conservation of mechanical energy principles.

    • 3.4.B.1 Mechanical energy is the sum of a system's kinetic and potential energies.
    • 3.4.B.2 Any change to a type of energy within a system must be balanced by an equivalent change of other types of energies within the system or by a transfer of energy between the system and its surroundings.
    • 3.4.B.3 A system may be selected so that the total energy of that system is constant.
    • 3.4.B.4 If the total energy of a system changes, that change will be equivalent to the energy transferred into or out of the system.

    Learning Objective 3.4.C: Describe how the selection of a system determines whether the energy of that system changes.

    • 3.4.C.1 Energy is conserved in all interactions.
    • 3.4.C.2 If the work done on a selected system is zero and there are no nonconservative interactions within the system, the total mechanical energy of the system is constant.
    • 3.4.C.3 If the work done on a selected system is nonzero, energy is transferred between the system and the environment.

    Boundary statement: AP Physics C: Mechanics expects students to know that mechanical energy can be dissipated as thermal energy or sound by nonconservative forces.

    Bahasa Indonesia

    Tujuan Pembelajaran 3.4.A: Jelaskan energi-energi yang ada dalam suatu sistem.

    • 3.4.A.1 Sistem yang terdiri hanya dari satu benda hanya dapat memiliki energi kinetik.
    • 3.4.A.2 Sistem yang berisi benda-benda yang berinteraksi melalui gaya konservatif atau yang dapat mengubah bentuknya secara reversibel dapat memiliki energi kinetik maupun potensial.

    Tujuan Pembelajaran 3.4.B: Jelaskan perilaku sistem menggunakan prinsip-prinsip kekekalan energi mekanik.

    • 3.4.B.1 Energi mekanik adalah jumlah energi kinetik dan potensial suatu sistem.
    • 3.4.B.2 Perubahan apa pun pada jenis energi dalam suatu sistem harus seimbang dengan perubahan ekuivalen dari jenis energi lainnya dalam sistem atau melalui perpindahan energi antara sistem dan lingkungannya.
    • 3.4.B.3 Suatu sistem dapat dipilih sedemikian rupa sehingga total energi sistem tersebut konstan.
    • 3.4.B.4 Jika total energi sistem berubah, perubahan tersebut akan setara dengan energi yang ditransfer masuk atau keluar dari sistem.

    Tujuan Pembelajaran 3.4.C: Jelaskan bagaimana pemilihan sistem menentukan apakah energi sistem tersebut berubah.

    • 3.4.C.1 Energi kekal dalam semua interaksi.
    • 3.4.C.2 Jika usaha yang dilakukan pada sistem yang dipilih adalah nol dan tidak ada interaksi nonkonservatif di dalam sistem, maka total energi mekanik sistem adalah konstan.
    • 3.4.C.3 Jika usaha yang dilakukan pada sistem yang dipilih tidak nol, energi ditransfer antara sistem dan lingkungan.

    Pernyataan Batas: AP Physics C: Mekanika mengharapkan siswa mengetahui bahwa energi mekanik dapat terdisipasi menjadi energi termal atau bunyi oleh gaya nonkonservatif.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Energy conservation: KE ⇄ PE

    Energy is conserved in all interactions – the question is only where it goes. Mechanical energy 机械能 is the sum $E=K+U$. If the external work on a system is zero and nothing inside it acts through nonconservative forces 非保守力, then

    $$K_1+U_1=K_2+U_2.$$

    When friction or drag act, they convert mechanical energy into thermal energy 热能 ($\Delta E_{\text{mech}}=-F_fd$), and the balance must include that term. If external work is done, the system's total energy changes by exactly the energy transferred: $W_{\text{ext}}=\Delta E_{\text{sys}}$. Choosing the system is choosing the bookkeeping – a single object can only have kinetic energy; include the Earth or the spring and the system can store potential energy too.

    A potential-energy graph is a complete motion map: the horizontal line at height $E$ is the total energy, the gap $E-U(x)$ is the kinetic energy at each $x$, and the crossings $E=U$ are the turning points 转折点 where the object momentarily stops and reverses.

    Worked example. A $2.0\ \text{kg}$ block slides down a ramp from rest at height $1.5\ \text{m}$, arriving at the bottom at $4.0\ \text{m/s}$. Energy accounting: $mgh=29.4\ \text{J}$ available; $\tfrac12mv^2=16\ \text{J}$ arrives as kinetic energy; so friction converted $29.4-16=13\ \text{J}$ into thermal energy along the way.

    Bahasa Indonesia
    Kekekalan energi: KE ⇄ PE

    Energi kekal dalam semua interaksi – pertanyaannya hanyalah ke mana energi itu pergi. Energi mekanik adalah jumlah $E=K+U$. Jika usaha eksternal pada sistem adalah nol dan tidak ada yang di dalamnya bekerja melalui gaya nonkonservatif, maka

    $$K_1+U_1=K_2+U_2.$$

    Ketika gesekan atau hambat bekerja, mereka mengonversi energi mekanik menjadi energi termal ($\Delta E_{\text{mech}}=-F_fd$), dan neraca harus memasukkan suku tersebut. Jika usaha eksternal dibuat, total energi sistem berubah persis sebesar energi yang ditransfer: $W_{\text{ext}}=\Delta E_{\text{sys}}$. Memilih sistem adalah memilih cara pencatatan – satu benda tunggal hanya dapat memiliki energi kinetik; sertakan Bumi atau pegas agar sistem juga dapat menyimpan energi potensial.

    Ayunan menukar energi potensial gravitasi menjadi energi kinetik dan sebaliknya
    Ayon menukar energi potensial gravitasi menjadi energi kinetik dan sebaliknya

    Grafik energi potensial adalah peta gerak lengkap: garis horizontal pada ketinggian $E$ adalah energi total, celah $E-U(x)$ adalah energi kinetik pada setiap $x$, dan perpotongan $E=U$ adalah titik balik di mana benda berhenti sejenak dan berbalik arah.

    Contoh terpecahkan. Sebuah balok $2.0\ \text{kg}$ meluncur menuruni landai dari keadaan diam pada ketinggian $1.5\ \text{m}$, tiba di bagian bawah dengan kecepatan $4.0\ \text{m/s}$. Akuntansi energi: $mgh=29.4\ \text{J}$ tersedia; $\tfrac12mv^2=16\ \text{J}$ tiba sebagai energi kinetik; sehingga gesekan telah mengonversi $29.4-16=13\ \text{J}$ menjadi energi termal sepanjang perjalanan.
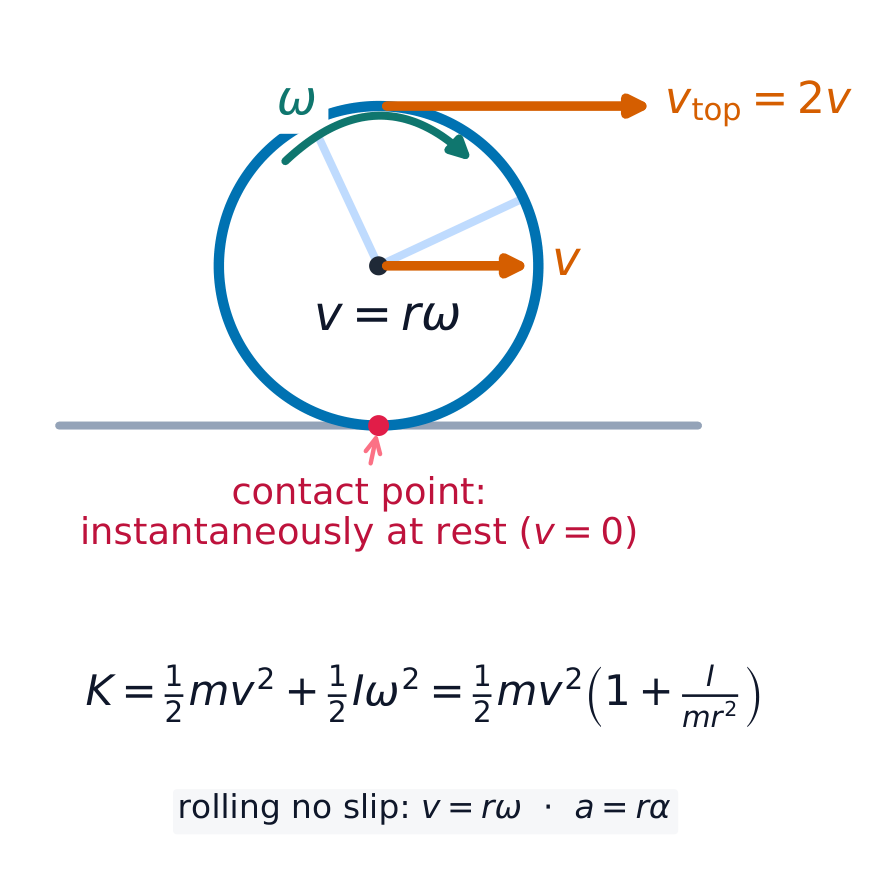
    A roller coaster trades energy back and forth: highest (most PE) at the top, fastest (most KE) at the bottom
    A roller coaster trades energy back and forth: highest (most PE) at the top, fastest (most KE) at the bottom
    Explore · ⁨Jelajahi⁩

    Watch energy convert as an object falls · ⁨Amati konversi energi saat benda jatuh⁩

    With no friction, mechanical energy is conserved: as an object falls, gravitational potential energy turns into kinetic energy while the total stays fixed. · ⁨Tanpa gesekan, energi mekanik kekal: saat benda jatuh, energi potensial gravitasi berubah menjadi energi kinetik sementara totalnya tetap.⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    3.5

    Power · ⁨Daya⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 3.5.A: Describe the transfer of energy into, out of, or within a system in terms of power.

    • 3.5.A.1 Power is the rate at which energy changes with respect to time, either by transfer into or out of a system or by conversion from one type to another within a system.
    • 3.5.A.2 Average power is the amount of energy being transferred or converted, divided by the time it took for that transfer or conversion to occur.
      • Equation: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
    • 3.5.A.3 Because work is the change in energy of an object or system due to a force, average power is the total work done, divided by the time during which that work was done.
      • Equation: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
    • 3.5.A.4 The instantaneous power delivered to an object by a force is given by the equation
      • Equation: $P_{\text{inst}} = \dfrac{dW}{dt}$
    • 3.5.A.5 The instantaneous power delivered to an object by the component of a constant force parallel to the object's velocity can be described with the derived equation
      • Equation: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$
    Bahasa Indonesia

    Tujuan Pembelajaran 3.5.A: Jelaskan perpindahan energi masuk, keluar, atau di dalam suatu sistem dalam istilah daya.

    • 3.5.A.1 Daya adalah laju perubahan energi terhadap waktu, baik melalui transfer masuk atau keluar dari sistem maupun melalui konversi dari satu jenis ke jenis lain di dalam sistem.
    • 3.5.A.2 Daya rata-rata adalah jumlah energi yang ditransfer atau dikonversi, dibagi dengan waktu yang dibutuhkan untuk transfer atau konversi tersebut terjadi.
      • Persamaan: $P_{\text{avg}} = \dfrac{\Delta E}{\Delta t}$
    • 3.5.A.3 Karena usaha adalah perubahan energi suatu objek atau sistem akibat gaya, daya rata-rata adalah total usaha yang dilakukan, dibagi dengan waktu selama usaha itu dilakukan.
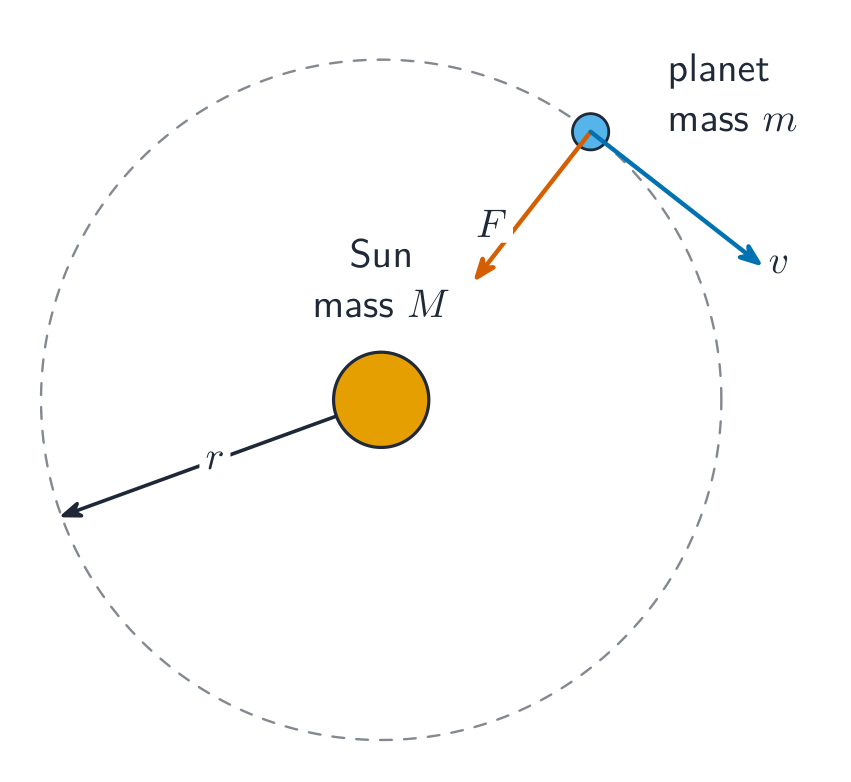
      • Persamaan: $P_{\text{avg}} = \dfrac{W}{\Delta t}$
    • 3.5.A.4 Daya sesaat yang disalurkan kepada objek oleh gaya diberikan oleh persamaan
      • Persamaan: $P_{\text{inst}} = \dfrac{dW}{dt}$
    • 3.5.A.5 Daya sesaat yang disalurkan kepada objek oleh komponen gaya konstan yang sejajar dengan kecepatan objek dapat digambarkan dengan persamaan turunan
      • Persamaan: $P_{\text{inst}} = F_{\parallel}v = Fv\cos\theta$

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Power 功率 is the rate of energy transfer, in watts 瓦特 (W):

    $$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$

    It measures how fast work is done, not how much. The dot product matters: only the force component along the velocity delivers power.

    Worked example. A block released from rest at the top of a frictionless $3.0\ \text{m}$-high ramp reaches the bottom at $v=\sqrt{2gh}=7.7\ \text{m/s}$ (from $mgh=\tfrac12mv^2$). A motor that then drives it at a steady $7.7\ \text{m/s}$ against a $20\ \text{N}$ resistance delivers $P=Fv=20(7.7)\approx150\ \text{W}$.

    Worked example. A $1200\ \text{kg}$ car climbs a hill that rises $1.0\ \text{m}$ for every $20\ \text{m}$ of road, at a steady $15\ \text{m/s}$. The engine must supply gravity's power drain: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ – before adding air resistance.

    Exam skill. Energy FRQs reward the accounting sentence: name your system, state which forces do work on it, and write the balance ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$) before plugging in numbers. "Friction is present, so mechanical energy is not conserved" is a scored statement.

    Bahasa Indonesia

    Daya adalah laju perpindahan energi, dalam satuan watt (W):

    $$P_{\text{avg}}=\frac{\Delta E}{\Delta t}=\frac{W}{\Delta t},\qquad P_{\text{inst}}=\frac{dW}{dt}=\vec{F}\cdot\vec{v}.$$

    Ini mengukur seberapa cepat usaha dilakukan, bukan berapa banyak. Hasil kali titik penting: hanya komponen gaya sepanjang kecepatan yang memberikan daya.

    Daya adalah kemiringan grafik usaha-waktu: usaha yang sama dalam waktu lebih sedikit berarti daya lebih besar
    Daya adalah kemiringan grafik usaha-waktu: usaha yang sama dalam waktu lebih sedikit berarti daya lebih besar

    Contoh terpecahkan. Sebuah balok dilepaskan dari keadaan diam di puncak landai licin setinggi $3.0\ \text{m}$ mencapai bagian bawah dengan kecepatan $v=\sqrt{2gh}=7.7\ \text{m/s}$ (dari $mgh=\tfrac12mv^2$). Motor yang kemudian menggerakkannya pada kecepatan tetap $7.7\ \text{m/s}$ melawan hambatan $20\ \text{N}$ menghasilkan daya $P=Fv=20(7.7)\approx150\ \text{W}$.
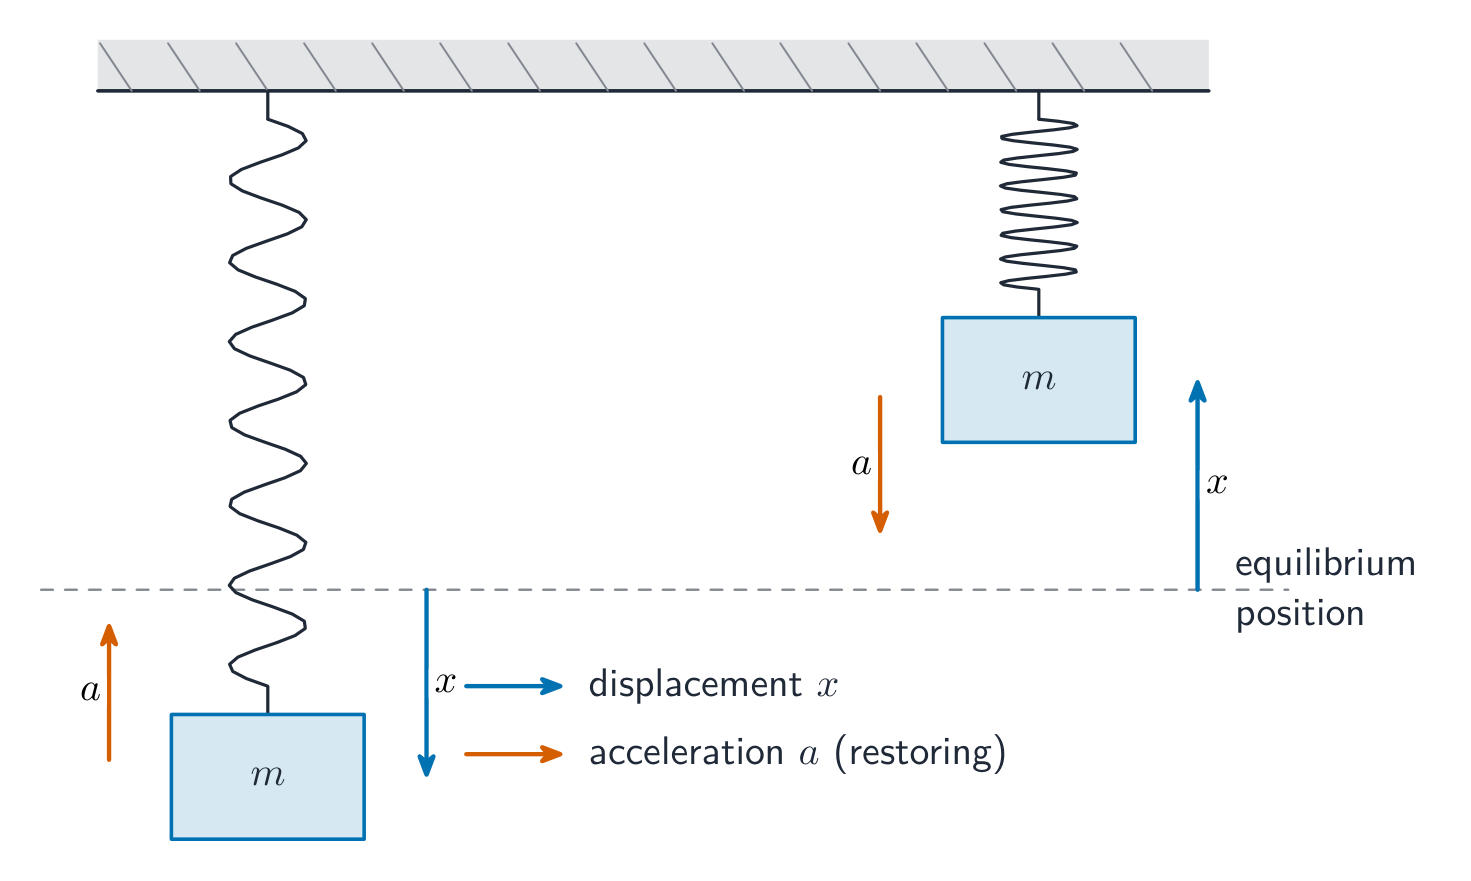
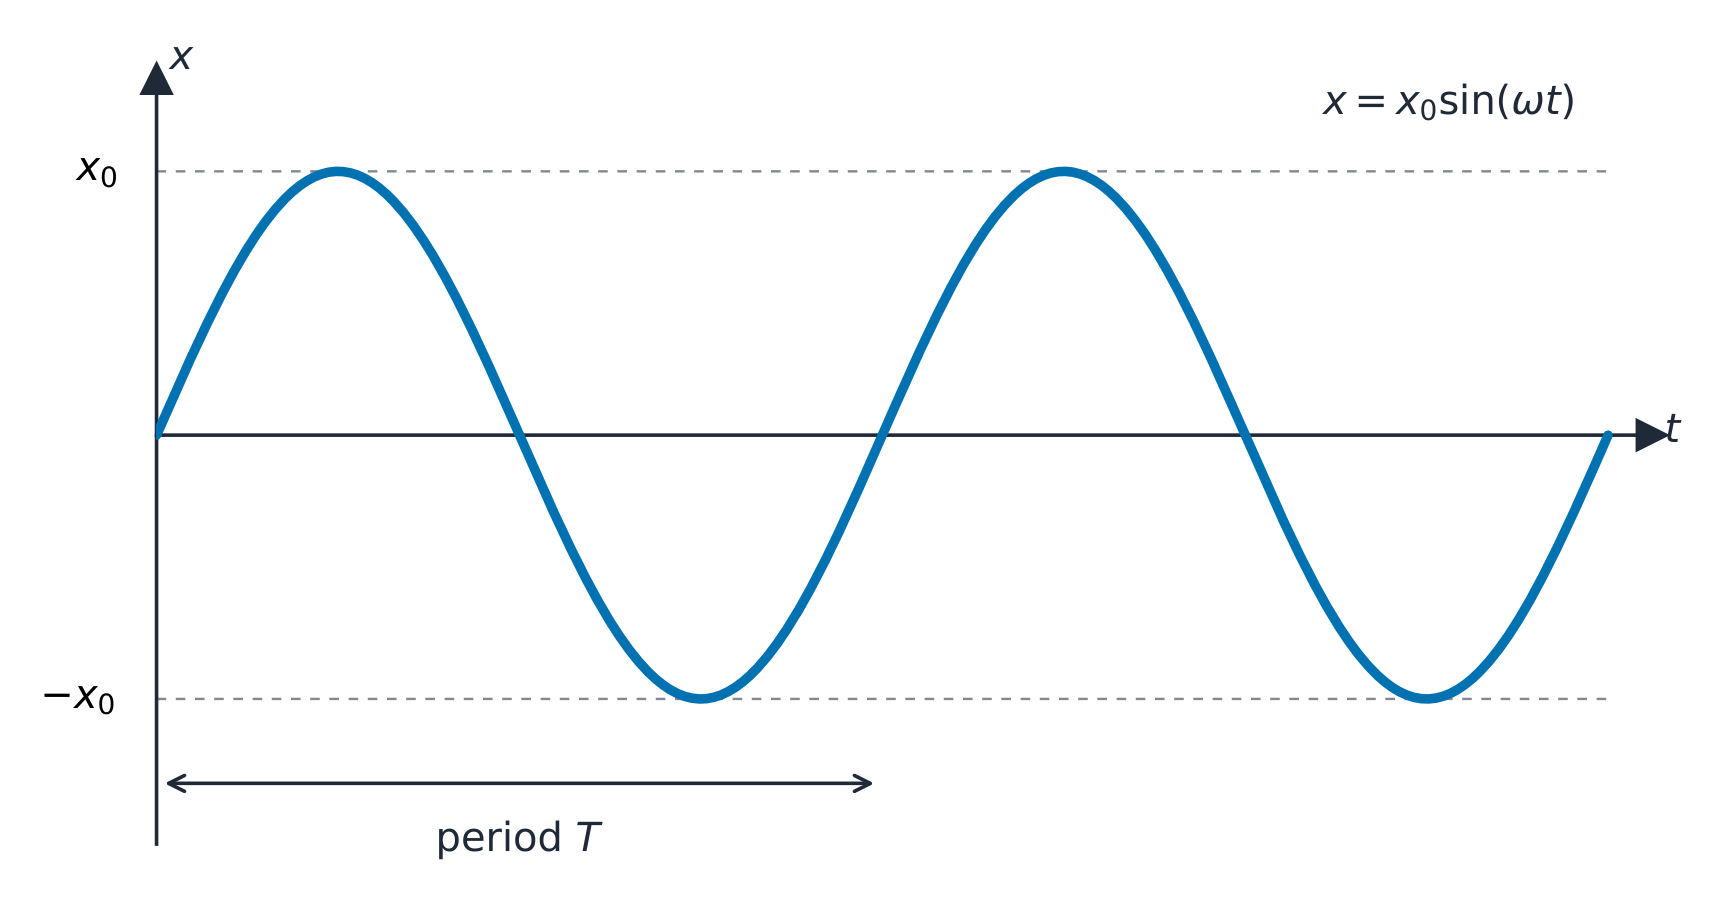
    Contoh terpecahkan. Sebuah mobil $1200\ \text{kg}$ menaiki bukit yang meninggi $1.0\ \text{m}$ untuk setiap $20\ \text{m}$ jalan, dengan kecepatan tetap $15\ \text{m/s}$. Mesin harus menyediakan daya yang dikurangi gravitasi: $P=mg\,v\sin\theta=1200(9.8)(15)\big(\tfrac{1}{20}\big)\approx8.8\ \text{kW}$ – sebelum menambahkan hambatan udara.

    Keterampilan ujian. Soal FRQ energi menghargai kalimat akuntansi: sebutkan sistem Anda, nyatakan gaya mana yang melakukan usaha padanya, dan tulis neranganya ($W_{\text{ext}}=\Delta K+\Delta U+\Delta E_{\text{thermal}}$) sebelum memasukkan angka. "Gesekan ada, sehingga energi mekanik tidak kekal" adalah pernyataan yang bernilai poin.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Power/ˈpaʊə/ Daya
    watts/wɒts/ watt
    3.5

    Exam tips · ⁨Tips ujian⁩

    English
    • Use the work–energy theorem $W_{net}=\Delta KE$ and compute work as $W=\int \vec F\cdot d\vec r$ for a variable force.
    • Read work off a force–position graph as the area under the curve.
    • Power is $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$; watch instantaneous vs average.
    • Split forces into conservative (define a potential energy) and non-conservative (dissipate energy).
    • Choose energy methods over kinematics when the force varies or the path is complex.
    Bahasa Indonesia
    • Gunakan teorema usaha-energi $W_{net}=\Delta KE$ dan hitung usaha sebagai $W=\int \vec F\cdot d\vec r$ untuk gaya variabel.
    • Baca usaha dari grafik gaya-posisi sebagai luas di bawah kurva.
    • Daya adalah $P=\tfrac{dW}{dt}=\vec F\cdot\vec v$; perhatikan antara daya sesaat vs rata-rata.
    • Pisahkan gaya menjadi konservatif (definisikan energi potensial) dan non-konservatif (menghabiskan energi).
    • Pilih metode energi daripada kinematika ketika gayanya berubah atau jalurnya kompleks.
  • 4

    Linear Momentum · ⁨Momentum Linear⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    4.1

    Linear Momentum · ⁨Momentum Linear⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 4.1.A: Describe the linear momentum of an object or system.

    • 4.1.A.1 Linear momentum is defined by the equation $\vec{p} = m\vec{v}$.
    • 4.1.A.2 Momentum is a vector quantity and has the same direction as the velocity.
    • 4.1.A.3 Momentum can be used to analyze collisions and explosions.
      • 4.1.A.3.i A collision is a model for an interaction where the forces exerted between the involved objects in the system are much larger than the net external force exerted on those objects during the interaction.
      • 4.1.A.3.ii As only the initial and final states of a collision are analyzed, the object model may be used to analyze collisions.
      • 4.1.A.3.iii An explosion is a model for an interaction in which forces internal to the system move objects within that system apart.
    Bahasa Indonesia

    Tujuan Pembelajaran 4.1.A: Jelaskan momentum linear suatu objek atau sistem.

    • 4.1.A.1 Momentum linear didefinisikan oleh persamaan $\vec{p} = m\vec{v}$.
    • 4.1.A.2 Momentum adalah besaran vektor dan memiliki arah yang sama dengan kecepatan.
    • 4.1.A.3 Momentum dapat digunakan untuk menganalisis tumbukan dan ledakan.
      • 4.1.A.3.i Tumbukan adalah model interaksi di mana gaya yang dikeluarkan antar objek yang terlibat dalam sistem jauh lebih besar daripada resultan gaya eksternal yang bekerja pada objek-objek tersebut selama interaksi.
      • 4.1.A.3.ii Karena hanya keadaan awal dan akhir tumbukan yang dianalisis, model objek dapat digunakan untuk menganalisis tumbukan.
      • 4.1.A.3.iii Ledakan adalah model interaksi di mana gaya internal sistem memisahkan objek-objek di dalamnya.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Linear momentum 动量 is mass times velocity:

    $$\vec{p}=m\vec{v}.$$

    It is a vector 矢量 pointing along the velocity, and it is the quantity for analysing collisions 碰撞 and explosions 爆炸. A collection of objects can be treated as one system moving with the velocity of its center of mass 质心:

    $$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$

    so the system's total momentum is its total mass times $\vec{v}_{\text{cm}}$ – one object's worth of bookkeeping for any number of parts.

    Bahasa Indonesia

    Momentum linear adalah massa kali kecepatan:

    $$\vec{p}=m\vec{v}.$$

    Ini adalah vektor yang mengarah sepanjang kecepatan, dan merupakan kuantitas utama untuk menganalisis tumbukan dan ledakan. Kumpulan benda dapat diperlakukan sebagai satu sistem yang bergerak dengan kecepatan pusat massanya:

    $$\vec{v}_{\text{cm}}=\frac{\sum m_i\vec{v}_i}{\sum m_i},$$

    sehingga momentum total sistem adalah massa totalnya kali $\vec{v}_{\text{cm}}$ – satu entri pembukuan untuk sejumlah bagian apa pun.

    4.2

    Change in Momentum and Impulse · ⁨Perubahan Momentum dan Impuls⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 4.2.A: Describe the impulse delivered to an object or system.

    • 4.2.A.1 The rate of change of a system's momentum is equal to the net external force exerted on that system.
      • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
    • 4.2.A.2 Impulse is defined as the integral of a force exerted on an object or system over a time interval.
      • Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
    • 4.2.A.3 Impulse is a vector quantity and has the same direction as the net force exerted on the system.
    • 4.2.A.4 The impulse delivered to a system by a net external force is equal to the area under the curve of a graph of the net external force exerted on the system as a function of time.
    • 4.2.A.5 The net external force exerted on a system is equal to the slope of a graph of the momentum of the system as a function of time.

    Learning Objective 4.2.B: Describe the relationship between the impulse exerted on an object or system and the change in momentum of the object or system.

    • 4.2.B.1 Change in momentum is the difference between a system's final momentum and its initial momentum.
      • Equation: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
    • 4.2.B.2 The impulse–momentum theorem relates the impulse delivered to an object and the object's change in momentum.
      • 4.2.B.2.i The impulse exerted on an object is equal to the object's change in momentum.
        • Equation: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
      • 4.2.B.2.ii Newton's second law of motion is a direct result of the impulse–momentum theorem applied to systems with constant mass.
        • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
      • 4.2.B.2.iii The impulse–momentum theorem also describes the behavior of a system in which the velocity is constant but the mass changes with respect to time.
        • Equation: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$
    Bahasa Indonesia

    Tujuan Pembelajaran 4.2.A: Jelaskan impuls yang diberikan kepada objek atau sistem.

    • 4.2.A.1 Laju perubahan momentum suatu sistem sama dengan resultan gaya eksternal yang bekerja pada sistem tersebut.
      • Persamaan: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt}$
    • 4.2.A.2 Impuls didefinisikan sebagai integral dari gaya yang bekerja pada sebuah objek atau sistem selama selang waktu tertentu.
      • Persamaan: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt$
    • 4.2.A.3 Impuls adalah besaran vektor dan memiliki arah yang sama dengan resultan gaya yang diberikan pada sistem.
    • 4.2.A.4 Impuls yang diberikan kepada sistem oleh resultan gaya eksternal sama dengan luas di bawah kurva grafik resultan gaya eksternal yang diberikan pada sistem sebagai fungsi waktu.
    • 4.2.A.5 Resultan gaya eksternal yang diberikan pada sistem sama dengan kemiringan grafik momentum sistem sebagai fungsi waktu.

    Tujuan Pembelajaran 4.2.B: Jelaskan hubungan antara impuls yang diberikan pada sebuah objek atau sistem dengan perubahan momentum objek atau sistem tersebut.

    • 4.2.B.1 Perubahan momentum adalah perbedaan antara momentum akhir sistem dan momentum awalnya.
      • Persamaan: $\Delta\vec{p} = \vec{p} - \vec{p}_0$
    • 4.2.B.2 Teorema impuls-momentum menghubungkan impuls yang diberikan kepada sebuah objek dengan perubahan momentum objek tersebut.
      • 4.2.B.2.i Impuls yang diberikan pada sebuah objek sama dengan perubahan momentum objek tersebut.
        • Persamaan: $\vec{J} = \displaystyle\int_{t_1}^{t_2} \vec{F}_{\text{net}}(t)\,dt = \Delta\vec{p}$
      • 4.2.B.2.ii Hukum kedua Newton tentang gerak merupakan hasil langsung dari teorema impuls-momentum yang diterapkan pada sistem dengan massa konstan.
        • Persamaan: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = m\dfrac{d\vec{v}}{dt} = m\vec{a}$
      • 4.2.B.2.iii Teorema impuls-momentum juga menjelaskan perilaku sistem di mana kecepatannya konstan tetapi massanya berubah terhadap waktu.
        • Persamaan: $\vec{F}_{\text{net}} = \dfrac{d\vec{p}}{dt} = \dfrac{dm}{dt}\vec{v}$

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Newton's second law is really a statement about momentum:

    $$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$

    which reduces to $m\vec{a}$ when the mass is constant – and handles a changing mass when it is not (the special case $\vec{F}=\dfrac{dm}{dt}\vec{v}$ holds only when the velocity is constant, e.g. a chain piling onto a scale or sand landing on a belt moving at fixed speed; a rocket does not fit, since it accelerates). The impulse 冲量 delivered by a force is its time integral, and the impulse–momentum theorem 冲量-动量定理 says it equals the change in momentum:

    $$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$

    Impulse is a vector along the net force. Read it off graphs both ways:

    • On a force–time graph, impulse is the area under the curve.
    • On a momentum–time graph, the net force is the slope 斜率 at each instant.

    Spreading the same $\Delta p$ over a longer time lowers the force – that is why airbags, crumple zones, and soft landings work, and why you bend your knees when you land.

    Worked example. A time-varying force $F(t)=10t\ \text{N}$ acts on a $2.0\ \text{kg}$ object for $2.0\ \text{s}$. The impulse is $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, so the speed changes by $\Delta v=J/m=10\ \text{m/s}$.

    Bahasa Indonesia

    Hukum kedua Newton sebenarnya adalah pernyataan tentang momentum:

    $$\vec{F}_{\text{net}}=\frac{d\vec{p}}{dt},$$

    yang menyederhanakan menjadi $m\vec{a}$ ketika massa konstan – dan menangani massa berubah ketika tidak konstan (kasus khusus $\vec{F}=\dfrac{dm}{dt}\vec{v}$ berlaku hanya ketika kecepatan konstan, mis. rantai menumpuk di atas timbangan atau pasir mendarat di sabuk pengangkut dengan kecepatan tetap; roket tidak masuk akal, karena mengalami percepatan). Impuls yang diberikan oleh suatu gaya adalah integral waktunya, dan teorema impuls-momentum mengatakan bahwa itu sama dengan perubahan momentum:

    $$\vec{J}=\int_{t_1}^{t_2}\vec{F}_{\text{net}}\,dt=\Delta\vec{p}.$$

    Impuls adalah vektor sepanjang gaya resultan. Bacalah dari grafik dengan kedua cara:

    • Pada grafik gaya-waktu, impuls adalah luas di bawah kurva.
    • Pada grafik momentum-waktu, gaya resultan adalah kemiringan pada setiap saat.
    Impuls adalah luas di bawah kurva gaya-waktu, sama dengan gaya rata-rata dikali waktu kontak
    Impuls adalah luas di bawah kurva gaya-waktu, sama dengan gaya rata-rata dikali waktu kontak

    Menyebar $\Delta p$ yang sama selama waktu yang lebih lama menurunkan gaya – itulah mengapa airbag, zona hancur, dan pendaratan lembut bekerja, dan mengapa Anda membungkuk lutut saat mendarat.

    Contoh terpecahkan. Gaya yang berubah terhadap waktu $F(t)=10t\ \text{N}$ bekerja pada objek $2.0\ \text{kg}$ selama $2.0\ \text{s}$. Impulsnya adalah $J=\displaystyle\int_0^2 10t\,dt=\big[5t^2\big]_0^2=20\ \text{N}\cdot\text{s}$, sehingga kecepatannya berubah sebesar $\Delta v=J/m=10\ \text{m/s}$.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Linear momentum/ˈlɪnɪə məʊˈmentəm/ Momentum linear
    vector/ˈvektə/ vektor
    collisions/kəˈlɪʒnz/ Tumbukan
    explosions/ekˈspləʊʒnz/ Ledakan
    center of mass/ˈsentə ɒv mæs/ pusat massa
    impulse/ˈɪmpʌls/ impuls
    impulse–momentum theorem/ˈɪmpʌls məʊˈmentəm ˈθɪərəm/ Teorema impuls-momentum
    slope/sləʊp/ kemiringan grafik
    conserved/kənˈsɜːvd/ terjaga
    kinetic energy/kɪˈnetɪk ˈenədʒi/ energi kinetik
    elastic collision/ɪˈlæstɪk kəˈlɪʒn/ tabrakan elastis
    inelastic collision/ɪnɪˈlæstɪk kəˈlɪʒn/ tabrakan inelastis
    deformation/ˌdiːfɔːˈmeɪʃn/ deformasi
    perfectly inelastic collision/ˈpɜːfektlɪ ɪnɪˈlæstɪk kəˈlɪʒn/ tabrakan inelastis sempurna
    4.3

    Conservation of Linear Momentum · ⁨Kekekalan Momentum Linear⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 4.3.A: Describe the behavior of a system using conservation of linear momentum.

    • 4.3.A.1 A collection of objects with individual momenta can be described as one system with one center-of-mass velocity.
      • 4.3.A.1.i For a collection of objects, the velocity of a system's center of mass can be calculated using the equation
        • Equation: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
      • 4.3.A.1.ii The velocity of a system's center of mass is constant in the absence of a net external force.
    • 4.3.A.2 The total momentum of a system is the sum of the momenta of the system's constituent parts.
    • 4.3.A.3 In the absence of net external forces, any change to the momentum of an object within a system must be balanced by an equivalent and opposite change of momentum elsewhere within the system. Any change to the momentum of a system is due to a transfer of momentum between the system and its surroundings.
      • 4.3.A.3.i The impulse exerted by one object on a second object is equal and opposite to the impulse exerted by the second object on the first. This is a direct result of Newton's third law.
      • 4.3.A.3.ii A system may be selected so that the total momentum of that system is constant.
      • 4.3.A.3.iii If the total momentum of a system changes, that change will be equivalent to the impulse exerted on the system.
        • Equation: $\vec{J} = \Delta\vec{p}$
    • 4.3.A.4 Correct application of conservation of momentum can be used to determine the velocity of a system immediately before and immediately after collisions or explosions.

    Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze collisions and interactions in one or two dimensions. Three-dimensional collisions may be analyzed qualitatively.

    Learning Objective 4.3.B: Describe how the selection of a system determines whether the momentum of that system changes.

    • 4.3.B.1 Momentum is conserved in all interactions.
    • 4.3.B.2 If the net external force on the selected system is zero, the total momentum of the system is constant.
    • 4.3.B.3 If the net external force on the selected system is nonzero, momentum is transferred between the system and the environment.
    Bahasa Indonesia

    Tujuan Pembelajaran 4.3.A: Jelaskan perilaku sistem menggunakan kekekalan momentum linear.

    • 4.3.A.1 Kumpulan objek dengan momentum individu dapat digambarkan sebagai satu sistem dengan satu kecepatan pusat massa.
      • 4.3.A.1.i Untuk sekumpulan objek, kecepatan pusat massa sistem dapat dihitung menggunakan persamaan
        • Persamaan: $\vec{v}_{\text{cm}} = \dfrac{\sum \vec{p}_i}{\sum m_i} = \dfrac{\sum (m_i \vec{v}_i)}{\sum m_i}$
      • 4.3.A.1.ii Kecepatan pusat massa sistem adalah konstan jika tidak ada resultan gaya eksternal.
    • 4.3.A.2 Total momentum sistem adalah jumlah momentum bagian-bagian penyusun sistem.
    • 4.3.A.3 Dalam ketiadaan resultan gaya eksternal, perubahan apa pun pada momentum objek di dalam sistem harus seimbang dengan perubahan momentum yang setara dan berlawanan di tempat lain dalam sistem. Perubahan apa pun pada momentum sistem disebabkan oleh transfer momentum antara sistem dan lingkungannya.
      • 4.3.A.3.i Impuls yang diberikan satu objek kepada objek kedua sama besar dan berlawanan arah dengan impuls yang diberikan objek kedua kepada objek pertama. Ini merupakan hasil langsung dari hukum ketiga Newton.
      • 4.3.A.3.ii Sistem dapat dipilih sedemikian rupa sehingga total momentum sistem tersebut konstan.
      • 4.3.A.3.iii Jika total momentum sistem berubah, perubahan tersebut setara dengan impuls yang diberikan pada sistem.
        • Persamaan: $\vec{J} = \Delta\vec{p}$
    • 4.3.A.4 Penerapan konservasi momentum yang benar dapat digunakan untuk menentukan kecepatan sistem segera sebelum dan segera setelah tabrakan atau ledakan.

    Pernyataan Batas: AP Physics C: Mekanika hanya mengharapkan siswa untuk menganalisis secara kuantitatif tabrakan dan interaksi dalam satu atau dua dimensi. Tabrakan tiga dimensi dapat dianalisis secara kualitatif.

    Tujuan Pembelajaran 4.3.B: Jelaskan bagaimana pemilihan suatu sistem menentukan apakah momentum sistem tersebut berubah.

    • 4.3.B.1 Momentum kekal dalam semua interaksi.
    • 4.3.B.2 Jika resultan gaya eksternal pada sistem yang dipilih adalah nol, total momentum sistem tersebut konstan.
    • 4.3.B.3 Jika resultan gaya eksternal pada sistem yang dipilih bukan nol, momentum ditransfer antara sistem dan lingkungan.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Internal forces come in Newton's-third-law pairs, so they cancel inside any system: they can shuffle momentum between parts but never change the total. Momentum only enters or leaves a system through a net external force ($\vec{J}=\Delta\vec{p}$). So, with zero net external force, total momentum is conserved 守恒:

    $$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$

    Momentum is conserved in every collision, however violent – choose the system large enough that the collision forces are internal. Apply conservation separately along each axis; AP asks for quantitative work in one or two dimensions.

    Worked example (explosion). A $6.0\ \text{kg}$ shell at rest splits into a $2.0\ \text{kg}$ piece moving at $9.0\ \text{m/s}$ east and a $4.0\ \text{kg}$ piece. Total momentum stays zero, so the heavy piece moves west at $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. The kinetic energy came from stored (chemical or spring) energy – momentum conservation does not require kinetic-energy conservation.

    Bahasa Indonesia

    Gaya internal muncul dalam pasangan hukum ketiga Newton, sehingga saling menghilangkan di dalam sistem apa pun: mereka dapat mengacak-aduk momentum antar bagian tetapi tidak pernah mengubah totalnya. Momentum hanya masuk atau keluar dari sistem melalui gaya luar resultan ($\vec{J}=\Delta\vec{p}$). Jadi, dengan nol gaya luar resultan, momentum total kekal:

    $$\sum\vec{p}_{\text{before}}=\sum\vec{p}_{\text{after}}.$$

    Momentum kekal dalam setiap tumbukan, sekejam apa pun – pilih sistem yang cukup besar agar gaya tumbukan bersifat internal. Terapkan kekekalan secara terpisah di sepanjang setiap sumbu; AP meminta pekerjaan kuantitatif dalam satu atau dua dimensi.

    Tabrakan searah: total momentum sebelum sama dengan total momentum setelah
    Tabrakan searah: total momentum sebelum sama dengan total momentum setelah

    Contoh terpecahkan (ledakan). Peluru $6.0\ \text{kg}$ yang diam pecah menjadi fragmen $2.0\ \text{kg}$ yang bergerak dengan kecepatan $9.0\ \text{m/s}$ ke timur dan fragmen $4.0\ \text{kg}$. Total momentum tetap nol, sehingga fragmen berat bergerak ke barat dengan kecepatan $v=\dfrac{2.0(9.0)}{4.0}=4.5\ \text{m/s}$. Energi kinetik berasal dari energi tersimpan (kimia atau pegas) – kekekalan momentum tidak memerlukan kekekalan energi kinetik.

    Explore · ⁨Jelajahi⁩

    Collide two carts and conserve momentum · ⁨Tabrakan dua gerbong dan守恒 momentum⁩

    In any collision the total momentum $\sum mv$ before equals the total after. Set the masses and speeds and check the momentum bookkeeping. · ⁨Dalam tabrakan apa pun, total momentum $\sum mv$ sebelum sama dengan total setelahnya. Tetapkan massa dan kecepatan lalu periksa pencatatan momentum.⁩

    4.4

    Elastic and Inelastic Collisions · ⁨Tabrakan Elastis dan Inelastis⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 4.4.A: Describe whether an interaction between objects is elastic or inelastic.

    • 4.4.A.1 An elastic collision between objects is one in which the initial kinetic energy of the system is equal to the final kinetic energy of the system.
    • 4.4.A.2 In an elastic collision, the final kinetic energies of each of the objects within the system may be different from their initial kinetic energies.
    • 4.4.A.3 An inelastic collision between objects is one in which the total kinetic energy of the system decreases.
    • 4.4.A.4 In an inelastic collision, some of the initial kinetic energy is not restored to kinetic energy but is transformed by nonconservative forces into other forms of energy.
    • 4.4.A.5 In a perfectly inelastic collision, the objects stick together and move with the same velocity after the collision.
    Bahasa Indonesia

    Tujuan Pembelajaran 4.4.A: Jelaskan apakah interaksi antar benda bersifat elastis atau inelastis.

    • 4.4.A.1 Tabrakan elastis antara benda-benda adalah tabrakan di mana energi kinetik awal sistem sama dengan energi kinetik akhir sistem.
    • 4.4.A.2 Dalam tabrakan elastis, energi kinetik akhir dari setiap benda dalam sistem mungkin berbeda dari energi kinetik awalnya.
    • 4.4.A.3 Tabrakan inelastis antara benda-benda adalah tabrakan di mana total energi kinetik sistem berkurang.
    • 4.4.A.4 Dalam tabrakan inelastis, sebagian energi kinetik awal tidak dikembalikan menjadi energi kinetik melainkan diubah oleh gaya non-konservatif menjadi bentuk energi lain.
    • 4.4.A.5 Dalam tabrakan inelastis sempurna, benda-benda saling menempel dan bergerak dengan kecepatan yang sama setelah tabrakan.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Conservation of momentum in a collision

    All collisions conserve momentum; they differ in what happens to the kinetic energy 动能:

    type momentum kinetic energy
    elastic collision 弹性碰撞 conserved total conserved (individual shares may change)
    inelastic collision 非弹性碰撞 conserved decreases – some becomes heat, sound, deformation 形变
    perfectly inelastic collision 完全非弹性碰撞 conserved largest possible loss – the objects stick and share one velocity

    Strategy: always write momentum conservation first; add the kinetic-energy equation only when the problem says "elastic". Two useful elastic facts: equal masses in a 1D elastic collision simply exchange velocities, and in the center-of-mass frame each object just reverses its velocity.

    Worked example. A $1000\ \text{kg}$ car at $20\ \text{m/s}$ strikes a stationary $1500\ \text{kg}$ car and they lock together – perfectly inelastic. Momentum: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Kinetic energy falls from $2.0\times10^5\ \text{J}$ to $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: about $60\%$ is lost, even though momentum is exactly conserved.

    Worked example (2D). A puck moving east at $4.0\ \text{m/s}$ strikes an identical puck at rest; after the glancing hit, one moves at $2.0\ \text{m/s}$ at $60^\circ$ north of east. Conserve each axis: east–west, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, so $v_x=3.0\ \text{m/s}$; north–south, $0=m(2.0)\sin60^\circ-mv_y$, so $v_y=1.7\ \text{m/s}$. The second puck moves at $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, about $30^\circ$ south of east.

    Exam skill. On FRQs, justify with the condition, not the slogan: "the net external force on the two-puck system is zero during the collision, so its total momentum is constant." If asked whether the collision is elastic, compute the kinetic energy before and after and compare – never assume.

    Bahasa Indonesia
    Kekekalan momentum dalam tabrakan

    Semua tumbukan mengawalkan momentum; mereka berbeda dalam apa yang terjadi pada energi kinetik:

    jenis momentum energi kinetik
    tumbukan elastis kekal total kekal (bagian individu mungkin berubah)
    tumbukan inelastis kekal berkurang – sebagian menjadi panas, suara, deformasi
    tumbukan inelastis sempurna kekal kehilangan terbesar yang mungkin – benda-benda tersebut melekat dan berbagi satu kecepatan

    Strategi: selalu tulis kekekalan momentum terlebih dahulu; tambahkan persamaan energi kinetik hanya jika soal berbunyi "elastis". Dua fakta berguna elastis: massa sama dalam tumbukan elastis 1D sekadar menukar kecepatan, dan dalam kerangka pusat massa setiap objek sekadar membalikkan kecepatannya.

    Contoh terpecahkan. Mobil $1000\ \text{kg}$ dengan kecepatan $20\ \text{m/s}$ menabrak mobil diam $1500\ \text{kg}$ dan mereka terkunci bersama – inelastis sempurna. Momentum: $v=\dfrac{1000(20)}{2500}=8.0\ \text{m/s}$. Energi kinetik turun dari $2.0\times10^5\ \text{J}$ ke $\tfrac12(2500)(8.0)^2=8.0\times10^4\ \text{J}$: sekitar $60\%$ hilang, meskipun momentum kekal persis.

    Contoh terpecahkan (2D). Puck bergerak ke timur dengan kecepatan $4.0\ \text{m/s}$ menabrak puck identik yang diam; setelah benturan miring, satu bergerak dengan kecepatan $2.0\ \text{m/s}$ pada sudut $60^\circ$ utara dari timur. Awalkan setiap sumbu: timur-barat, $m(4.0)=m(2.0)\cos60^\circ+mv_x$, jadi $v_x=3.0\ \text{m/s}$; utara-selatan, $0=m(2.0)\sin60^\circ-mv_y$, jadi $v_y=1.7\ \text{m/s}$. Puck kedua bergerak dengan kecepatan $\sqrt{3.0^2+1.7^2}=3.5\ \text{m/s}$, sekitar $30^\circ$ selatan dari timur.

    Tabrakan menyamping, diuraikan sepanjang dua sumbu tegak lurus
    Tabrakan menyamping, diuraikan sepanjang dua sumbu tegak lurus

    Keterampilan ujian. Pada soal FRQ, justifikasikan dengan syarat, bukan slogan: "gaya luar total pada sistem dua puck adalah nol selama tumbukan, sehingga momentum totalnya konstan." Jika ditanya apakah tumbukan tersebut elastis, hitung energi kinetik sebelum dan sesudah lalu bandingkan – jangan pernah berasumsi.

    A Newton's cradle: five steel balls hanging in a row
    A Newton's cradle menunjukkan momentum dan energi kinetik yang merambat melalui tumbukan hampir-elastis
    Explore · ⁨Jelajahi⁩

    Compare elastic and inelastic collisions · ⁨Bandingkan tabrakan elastis dan inelastis⁩

    Momentum is always conserved, but kinetic energy is only conserved in an elastic collision. In an inelastic one the carts stick and some energy becomes heat. · ⁨Momentum selalu守恒, tetapi energi kinetik hanya守恒 dalam tabrakan elastis. Dalam tabrakan inelastis, gerbong saling menempel dan sebagian energi berubah menjadi panas.⁩

    4.4

    Exam tips · ⁨Tips ujian⁩

    English
    • Impulse equals the momentum change: $\vec J=\int \vec F\,dt=\Delta\vec p$, and it is the area under a force–time graph.
    • Momentum is conserved whenever the net external force is zero — always the go-to for collisions.
    • Distinguish elastic (kinetic energy conserved) from inelastic (kinetic energy decreases) collisions; in a perfectly inelastic collision the objects stick and move with one velocity.
    • Apply conservation to each component (x and y) separately in 2-D.
    • Connect to center of mass: total momentum $=M\vec v_{cm}$.
    Bahasa Indonesia
    • Impuls sama dengan perubahan momentum: $\vec J=\int \vec F\,dt=\Delta\vec p$, dan merupakan luas di bawah grafik gaya–waktu.
    • Momentum terpelihara setiap kali gaya luar total adalah nol – selalu menjadi pilihan utama untuk tumbukan.
    • Bedakan elastis (energi kinetik terpelihara) dari inelastis (energi kinetik berkurang); dalam tumbukan inelastis sempurna benda-benda itu menempel dan bergerak dengan satu kecepatan.
    • Terapkan kekekalan pada setiap komponen (x dan y) secara terpisah dalam 2-D.
    • Hubungkan dengan pusat massa: total momentum $=M\vec v_{cm}$.
  • 5

    Torque and Rotational Dynamics · ⁨Torsi dan Dinamika Rotasi⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    5.1

    Rotational Kinematics · ⁨Kinematika Rotasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 5.1.A: Describe the rotation of a system with respect to time using angular displacement, angular velocity, and angular acceleration.

    • 5.1.A.1 Angular displacement is the measurement of the angle, in radians, through which a point on a rigid system rotates about a specified axis.
      • Equation: $\Delta\theta = \theta - \theta_0$
      • 5.1.A.1.i A rigid system is one that holds its shape but in which different points on the system move in different directions during rotation. A rigid system cannot be modeled as an object.
      • 5.1.A.1.ii One direction of angular displacement about an axis of rotation—clockwise or counterclockwise—is typically indicated as mathematically positive, with the other direction becoming mathematically negative.
      • 5.1.A.1.iii If the rotation of a system about an axis may be well described using the motion of the system's center of mass, the system may be treated as a single object. For example, the rotation of Earth about its axis may be considered negligible when considering the revolution of Earth about the center of mass of the Earth–Sun system.
    • 5.1.A.2 Angular velocity is the rate at which angular position changes with respect to time.
      • Equation: $\omega = \dfrac{d\theta}{dt}$
    • 5.1.A.3 Angular acceleration is the rate at which angular velocity changes with respect to time.
      • Equation: $\alpha = \dfrac{d\omega}{dt}$
    • 5.1.A.4 Angular displacement, angular velocity, and angular acceleration around one axis are analogous to linear displacement, velocity, and acceleration in one dimension and demonstrate the same mathematical relationships.
      • 5.1.A.4.i For constant angular acceleration, the mathematical relationships between angular displacement, angular velocity, and angular acceleration can be described with the following equations:
        • $\omega = \omega_0 + \alpha t$
        • $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
        • $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
      • 5.1.A.4.ii Graphs of angular displacement, angular velocity, and angular acceleration as functions of time can be used to find the relationships between those quantities.

    Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of said vectors will not be assessed on the exam.

    Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.

    Bahasa Indonesia

    Tujuan Pembelajaran 5.1.A: Deskripsikan rotasi suatu sistem terhadap waktu menggunakan simpangan sudut, kecepatan sudut, dan percepatan sudut.

    • 5.1.A.1 Simpangan sudut adalah pengukuran sudut, dalam radian, melalui mana sebuah titik pada sistem kaku berotasi sekitar sumbu yang ditentukan.
      • Persamaan: $\Delta\theta = \theta - \theta_0$
      • 5.1.A.1.i Sistem kaku adalah sistem yang mempertahankan bentuknya tetapi di mana titik-titik berbeda pada sistem bergerak ke arah yang berbeda selama rotasi. Sistem kaku tidak dapat dimodelkan sebagai satu objek.
      • 5.1.A.1.ii Salah satu arah simpangan sudut terhadap sumbu rotasi—searah jarum jam atau berlawanan arah jarum jam—biasanya ditunjukkan secara matematis sebagai positif, dengan arah lainnya menjadi negatif secara matematis.
      • 5.1.A.1.iii Jika rotasi sistem terhadap sumbu dapat dijelaskan dengan baik menggunakan gerakan pusat massa sistem, sistem tersebut dapat diperlakukan sebagai satu objek tunggal. Sebagai contoh, rotasi Bumi terhadap porosnya dapat dianggap dapat diabaikan ketika mempertimbangkan revolusi Bumi terhadap pusat massa sistem Bumi-Matahari.
    • 5.1.A.2 Kecepatan sudut adalah laju perubahan posisi sudut terhadap waktu.
      • Persamaan: $\omega = \dfrac{d\theta}{dt}$
    • 5.1.A.3 Percepatan sudut adalah laju perubahan kecepatan sudut terhadap waktu.
      • Persamaan: $\alpha = \dfrac{d\omega}{dt}$
    • 5.1.A.4 Simpangan sudut, kecepatan sudut, dan percepatan sudut di sekitar satu sumbu analog dengan perpindahan linear, kecepatan, dan percepatan dalam satu dimensi dan menunjukkan hubungan matematis yang sama.
      • 5.1.A.4.i Untuk percepatan sudut konstan, hubungan matematis antara simpangan sudut, kecepatan sudut, dan percepatan sudut dapat dijelaskan dengan persamaan berikut:
        • $\omega = \omega_0 + \alpha t$
        • $\theta = \theta_0 + \omega_0 t + \dfrac{1}{2}\alpha t^2$
        • $\omega^2 = \omega_0^2 + 2\alpha(\theta - \theta_0)$
      • 5.1.A.4.ii Grafik simpangan sudut, kecepatan sudut, dan percepatan sudut sebagai fungsi waktu dapat digunakan untuk menemukan hubungan antar besaran tersebut.

    Pernyataan Batas: AP Physics C: Mekanika mengharapkan siswa mampu memanipulasi secara matematis besaran simpangan sudut, kecepatan sudut, dan percepatan sudut menggunakan konvensi vektor. Namun, arah vektor-vektor tersebut tidak akan diujikan dalam ujian.

    Deskripsi arah kuantitas kinematika rotasi untuk sebuah titik atau benda kaku terbatas pada arah searah jarum jam dan berlawanan arah jarum jam relatif terhadap sumbu rotasi tertentu.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Rotation mirrors linear motion with angular quantities, defined as derivatives:

    $$\omega=\frac{d\theta}{dt},\qquad \alpha=\frac{d\omega}{dt}=\frac{d^2\theta}{dt^2}.$$

    Here $\theta$ is angular displacement 角位移 in radians 弧度, $\omega$ the angular velocity 角速度, and $\alpha$ the angular acceleration 角加速度. (AP works with their magnitudes and signs; the 3D vector directions are not assessed.) For constant $\alpha$, the kinematic equations are the linear ones re-lettered:

    $$\omega=\omega_0+\alpha t,\qquad \Delta\theta=\omega_0t+\tfrac12\alpha t^2,\qquad \omega^2=\omega_0^2+2\alpha\,\Delta\theta.$$

    Worked example. A fan blade slows from $30\ \text{rad/s}$ to rest with $\alpha=-6.0\ \text{rad/s}^2$: it takes $t=5.0\ \text{s}$ and turns through $\Delta\theta=\dfrac{0-30^2}{2(-6.0)}=75\ \text{rad}$ – about $12$ revolutions.

    Bahasa Indonesia

    Rotasi memirrorikan gerak linear dengan besaran sudut, didefinisikan sebagai turunan:

    $$\omega=\frac{d\theta}{dt},\qquad \alpha=\frac{d\omega}{dt}=\frac{d^2\theta}{dt^2}.$$

    Di sini $\theta$ adalah pergeseran sudut dalam radian, $\omega$ adalah kecepatan sudut, dan $\alpha$ adalah percepatan sudut. (AP bekerja dengan nilai mutlak dan tanda mereka; arah vektor 3D tidak diujikan.) Untuk konstanta $\alpha$, persamaan kinematika adalah persamaan linear yang ditulis ulang:

    $$\omega=\omega_0+\alpha t,\qquad \Delta\theta=\omega_0t+\tfrac12\alpha t^2,\qquad \omega^2=\omega_0^2+2\alpha\,\Delta\theta.$$
    Satu radian adalah sudut yang panjang busurnya sama dengan jari-jari
    Satu radian adalah sudut yang panjang busurnya sama dengan jari-jari

    Contoh terpecahkan. Baling-baling kipas melambat dari $30\ \text{rad/s}$ hingga berhenti dengan $\alpha=-6.0\ \text{rad/s}^2$: membutuhkan waktu $t=5.0\ \text{s}$ dan berputar sejauh $\Delta\theta=\dfrac{0-30^2}{2(-6.0)}=75\ \text{rad}$ – sekitar $12$ putaran.

    5.2

    Connecting Linear and Rotational Motion · ⁨Menghubungkan Gerak Linear dan Rotasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 5.2.A: Describe the linear motion of a point on a rotating rigid system that corresponds to the rotational motion of that point, and vice versa.

    • 5.2.A.1 For a point at a distance $r$ from a fixed axis of rotation, the linear distance $s$ traveled by the point as the system rotates through an angle $\Delta\theta$ is given by the equation $\Delta s = r\Delta\theta$.
    • 5.2.A.2 Derived relationships of linear velocity and of the tangential component of acceleration to their respective angular quantities are given by the following equations:
      • $s = r\theta$
      • $v = r\omega$
      • $a_T = r\alpha$
    • 5.2.A.3 For a rigid system, all points within that system have the same angular velocity and angular acceleration.

    Boundary statement: AP Physics C: Mechanics expects students to be able to mathematically manipulate the magnitudes of angular displacement, angular velocity, and angular acceleration using vector conventions. However, the directions of the vectors will not be assessed on the exam.

    Descriptions of the directions of rotational kinematics quantities for a point or rigid body are limited to clockwise and counterclockwise with respect to a given axis of rotation.

    Bahasa Indonesia

    Tujuan Pembelajaran 5.2.A: Deskripsikan gerakan linear sebuah titik pada sistem kaku berotasi yang sesuai dengan gerakan rotasi titik tersebut, dan sebaliknya.

    • 5.2.A.1 Untuk sebuah titik pada jarak $r$ dari sumbu rotasi tetap, jarak linear $s$ yang ditempuh oleh titik tersebut saat sistem berotasi sejauh sudut $\Delta\theta$ diberikan oleh persamaan $\Delta s = r\Delta\theta$.
    • 5.2.A.2 Hubungan turunan dari kecepatan linear dan komponen tangensial percepatan terhadap besaran sudut masing-masing diberikan oleh persamaan berikut:
      • $s = r\theta$
      • $v = r\omega$
      • $a_T = r\alpha$
    • 5.2.A.3 Untuk sistem kaku, semua titik di dalamnya memiliki kecepatan sudut dan percepatan sudut yang sama.

    Pernyataan Batas: AP Physics C: Mekanika mengharapkan siswa mampu memanipulasi secara matematis besaran simpangan sudut, kecepatan sudut, dan percepatan sudut menggunakan konvensi vektor. Namun, arah vektor-vektor tersebut tidak akan diujikan dalam ujian.

    Deskripsi arah kuantitas kinematika rotasi untuk sebuah titik atau benda kaku terbatas pada arah searah jarum jam dan berlawanan arah jarum jam relatif terhadap sumbu rotasi tertentu.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    A point at radius $r$ from the axis moves along its arc with

    $$s=r\theta,\qquad v=r\omega,\qquad a_t=r\alpha,$$

    so points farther out move faster. A rotating point generally has two acceleration components at once: the tangential acceleration 切向加速度 $a_t=r\alpha$ (speeding up along the arc) and the centripetal acceleration 向心加速度 $a_c=\dfrac{v^2}{r}=r\omega^2$ (turning, towards the axis). They are perpendicular, so $a=\sqrt{a_t^2+a_c^2}$.

    Bahasa Indonesia

    Sebuah titik pada jari-jari $r$ dari sumbu bergerak sepanjang busurnya dengan

    $$s=r\theta,\qquad v=r\omega,\qquad a_t=r\alpha,$$

    sehingga titik yang lebih jauh bergerak lebih cepat. Sebuah titik yang berotasi umumnya memiliki dua komponen percepatan sekaligus: percepatan tangensial $a_t=r\alpha$ (menambah kecepatan sepanjang busur) dan percepatan sentripetal $a_c=\dfrac{v^2}{r}=r\omega^2$ (berbelok, menuju sumbu). Keduanya tegak lurus, sehingga $a=\sqrt{a_t^2+a_c^2}$.

    As the radius turns through an angle, a point moves along an arc at speed v
    As the radius turns through an angle, a point moves along an arc at speed v
    5.3

    Torque · ⁨Torsi⁩

    Syllabus · ⁨Silabus⁩
    Learning ObjectiveEssential Knowledge

    5.3.A
    Identify the torques exerted on a rigid system.

    • 5.3.A.1 Torque results only from the force component perpendicular to the position vector from the axis of rotation to the point of application of the force.
    • 5.3.A.2 The lever arm is the perpendicular distance from the axis of rotation to the line of action of the exerted force.

    5.3.B
    Describe the torques exerted on a rigid system.

    • 5.3.B.1 Torques can be described using force diagrams.
      • 5.3.B.1.i Force diagrams are similar to free-body diagrams and are used to analyze the torques exerted on a rigid system.
      • 5.3.B.1.ii Similar to free-body diagrams, force diagrams represent the relative magnitude and direction of the forces exerted on a rigid system. Force diagrams also depict the location at which those forces are exerted relative to the axis of rotation.
    • 5.3.B.2 The torque exerted on a rigid system about a chosen pivot point by a given force is described by $\vec{\tau} = \vec{r} \times \vec{F}$.
      • 5.3.B.2.i The cross-product between two vectors, $\vec{A}$ and $\vec{B}$, results in a vector quantity of magnitude $\vec{A} \times \vec{B} = AB\sin\theta$.
      • 5.3.B.2.ii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ is perpendicular to both vectors $\vec{A}$ and $\vec{B}$ and therefore is normal to the plane defined by vectors $\vec{A}$ and $\vec{B}$.
      • 5.3.B.2.iii The direction of the vector resulting from the cross-product of vectors $\vec{A}$ and $\vec{B}$ can be qualitatively determined by applying the appropriate right-hand rule.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    The principle of moments (torque)

    Torque 力矩 is the turning effect of a force – the rotational cause, as force is the translational cause. It is a vector product 矢量积:

    $$\vec{\tau}=\vec{r}\times\vec{F},\qquad \tau=rF\sin\theta=F\,r_\perp,$$

    where $r_\perp$, the moment arm 力臂, is the perpendicular distance from the axis to the force's line of action. More force, applied farther from the axis, more perpendicular: more torque. A force pointing straight at (or away from) the axis has zero torque. In a plane, give counterclockwise and clockwise torques opposite signs and add.

    As a vector product, $\vec\tau=\vec r\times\vec F$ points perpendicular to the plane of $\vec r$ and $\vec F$, with its direction fixed by the right-hand rule 右手定则: curl your right fingers from $\vec r$ toward $\vec F$ and your thumb points along $\vec\tau$ – out of the page for a counterclockwise turn, into it for a clockwise one. The same rule gives the direction of angular momentum $\vec L=\vec r\times\vec p$.

    Bahasa Indonesia
    The principle of moments (torque)

    Torsi adalah efek putaran dari sebuah gaya – penyebab rotasi, sebagaimana gaya adalah penyebab translasi. Ini adalah produk vektor:

    $$\vec{\tau}=\vec{r}\times\vec{F},\qquad \tau=rF\sin\theta=F\,r_\perp,$$

    di mana $r_\perp$, lengan momen, adalah jarak tegak lurus dari sumbu ke garis kerja gaya. Semakin besar gaya, diterapkan semakin jauh dari sumbu, semakin tegak lurus: semakin besar torsi. Gaya yang mengarah lurus ke (atau menjauhi) sumbu memiliki torsi nol. Dalam bidang, berikan tanda yang berlawanan untuk torsi berlawanan jarum jam dan searah jarum jam, lalu jumlahkan.

    Sebagai produk vektor, $\vec\tau=\vec r\times\vec F$ menunjuk tegak lurus terhadap bidang dari $\vec r$ dan $\vec F$, dengan arahnya ditentukan oleh aturan tangan kanan: tekuk jari kanan Anda dari $\vec r$ menuju $\vec F$ dan ibu jari Anda menunjuk sepanjang $\vec\tau$ – keluar dari halaman untuk putaran berlawanan jarum jam, masuk ke dalamnya untuk putaran searah jarum jam. Aturan yang sama memberikan arah momentum sudut $\vec L=\vec r\times\vec p$.

    Torsi dari suatu gaya bergantung pada jarak tegak lurus dari sumbu
    Torsi dari suatu gaya bergantung pada jarak tegak lurus dari sumbu
    Rangkaian gigi: torsi dan inersia rotasi terhubung melalui rasio gigi
    Rangkaian gigi: torsi dan inersia rotasi terhubung melalui rasio gigi
    Explore · ⁨Jelajahi⁩

    Balance torques on a beam · ⁨Seimbangkan torsi pada balok⁩

    Torque is force times perpendicular distance, $\tau=Fd$. The beam is in rotational equilibrium when the torques on each side are equal. · ⁨Torsi adalah gaya dikali jarak tegak lurus, $\tau=Fd$. Balok berada dalam keseimbangan rotasi ketika torsi di kedua sisi sama.⁩

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ pencucupan sudut
    radians/ˈreɪdɪənz/ radian
    angular velocity/ˈæŋɡjʊlə vəˈlɒsɪti/ halaju sudut
    angular acceleration/ˈæŋɡjʊlə əkˌseləˈreɪʃn/ pecutan sudut
    tangential acceleration/tænˈdʒenʃl əkˌseləˈreɪʃn/ pecutan tangensial
    centripetal acceleration/senˈtrɪpɪtl əkˌseləˈreɪʃn/ percepatan sentripetal
    Torque/tɔːk/ Torsi
    vector product/ˈvektə ˈprɒdʌkt/ perkalian vektor
    moment arm/ˈməʊmənt ɑːm/ Lengan momen
    right-hand rule/raɪt hænd ruːl/ aturan tangan kanan
    Rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ Inersia rotasi
    linear density/ˈlɪnɪə ˈdensɪti/ Kepadatan linear
    parallel-axis theorem/ˈpærəlel ˈæksɪs ˈθɪərəm/ teorem sumbu sejajar
    rotational equilibrium/rəʊˈteɪʃənl ˌiːkwɪˈlɪbrɪəm/ keseimbangan rotasi
    static equilibrium/ˈstætɪk ˌiːkwɪˈlɪbrɪəm/ kesetimbangan statis
    Watch lesson · ⁨Tonton pelajaran⁩
    5.4

    Rotational Inertia · ⁨Inersia Rotasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 5.4.A: Describe the rotational inertia of a rigid system relative to a given axis of rotation.

    • 5.4.A.1 Rotational inertia measures a rigid system's resistance to changes in rotation and is related to the mass of the system and the distribution of that mass relative to the axis of rotation.
    • 5.4.A.2 The rotational inertia of an object rotating a perpendicular distance $r$ from an axis is described by the equation $I = mr^2$.
    • 5.4.A.3 The total rotational inertia of a collection of objects about an axis is the sum of the rotational inertias of each object about that axis.
      • Equation: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
    • 5.4.A.4 For a solid that can be considered as a collection of differential masses, $dm$, the solid's rotational inertia can be calculated using the equation $I = \int r^2\, dm$, where $r$ is the perpendicular distance from $dm$ to the axis of rotation.

    Learning Objective 5.4.B: Describe the rotational inertia of a rigid system rotating about an axis that does not pass through the system's center of mass.

    • 5.4.B.1 A rigid system's rotational inertia in a given plane is at a minimum when the rotational axis passes through the system's center of mass.
    • 5.4.B.2 The parallel axis theorem uses the following equation to relate the rotational inertia of a rigid system about any axis that is parallel to an axis through its center of mass:
      • Equation: $I' = I_{\text{cm}} + Md^2$

    Boundary statement: AP Physics C: Mechanics only expects students to use calculus in the derivations of the rotational inertia of thin rods of uniform or nonuniform density about an arbitrary axis perpendicular to the rod, as well as derivations of the rotational inertia of a thin cylindrical shell, disk, or rigid bodies that can be considered to be made up of coaxial rings or shells about an axis that passes through their centers (e.g., annular rings).

    Students should have a qualitative understanding of the factors that affect rotational inertia; for example, how rotational inertia is greater when mass is farther from the axis of rotation, which is why a hoop has more rotational inertia than a solid puck of the same mass and radius.

    Bahasa Indonesia

    Tujuan Pembelajaran 5.4.A: Jelaskan inersia rotasi sistem kaku relatif terhadap sumbu rotasi tertentu.

    • 5.4.A.1 Inersia rotasi mengukur resistensi sistem kaku terhadap perubahan rotasi dan berkaitan dengan massa sistem serta distribusi massa tersebut relatif terhadap sumbu rotasi.
    • 5.4.A.2 Inersia rotasi sebuah objek yang berputar pada jarak tegak lurus $r$ dari sebuah sumbu dijelaskan oleh persamaan $I = mr^2$.
    • 5.4.A.3 Total inersia rotasi dari sekumpulan objek tentang sebuah sumbu adalah jumlah dari inersia rotasi setiap objek tentang sumbu tersebut.
      • Persamaan: $I_{\text{tot}} = \sum I_i = \sum m_i r_i^2$
    • 5.4.A.4 Untuk padatan yang dapat dianggap sebagai kumpulan diferensial massa, $dm$, inersia rotasi padatan tersebut dapat dihitung menggunakan persamaan $I = \int r^2\, dm$, di mana $r$ adalah jarak tegak lurus dari $dm$ ke sumbu rotasi.

    Tujuan Pembelajaran 5.4.B: Jelaskan inersia rotasi sistem kaku yang berotasi tentang sumbu yang tidak melewati pusat massa sistem.

    • 5.4.B.1 Inersia rotasi sistem kaku dalam bidang tertentu mencapai nilai minimum ketika sumbu rotasi melewati pusat massa sistem.
    • 5.4.B.2 Teorem sumbu sejajar menggunakan persamaan berikut untuk menghubungkan inersia rotasi sistem kaku tentang sembarang sumbu yang sejajar dengan sumbu yang melalui pusat massanya:
      • Persamaan: $I' = I_{\text{cm}} + Md^2$

    Pernyataan Batas: AP Physics C: Mekanika hanya mengharapkan siswa menggunakan kalkulus dalam penurunan rumus inersia rotasi batang tipis dengan densitas seragam atau tidak seragam tentang sembarang sumbu tegak lurus batang, serta penurunan rumus inersia rotasi kulit silinder tipis, cakram, atau benda kaku yang dapat dianggap terdiri dari cincin atau cangkang koaksial tentang sumbu yang melalui pusat mereka (misalnya, cincin annular).

    Siswa harus memiliki pemahaman kualitatif mengenai faktor-faktor yang memengaruhi inersia rotasi; misalnya, bagaimana inersia rotasi lebih besar ketika massa berada lebih jauh dari sumbu rotasi, yang menjelaskan mengapa sebuah lingkaran memiliki inersia rotasi lebih besar daripada cakram pekat dengan massa dan jari-jari yang sama.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Rotational inertia 转动惯量 $I$ measures resistance to angular acceleration – the rotational analog of mass, but it depends on where the mass sits. For point masses, $I=\sum m_ir_i^2$; for a continuous body,

    $$I=\int r^2\,dm.$$

    Mass far from the axis dominates, because of the $r^2$.

    Worked example (rod). A uniform rod (mass $M$, length $L$) about its centre: with linear density 线密度 $\lambda=M/L$, $dm=\lambda\,dx$, so $I=\displaystyle\int_{-L/2}^{L/2}x^2\,\frac{M}{L}\,dx=\frac{1}{12}ML^2$. AP also expects nonuniform rods: if $\lambda(x)=cx$ on $[0,L]$, first find $M=\int_0^L cx\,dx=\tfrac12cL^2$, then $I=\int_0^L x^2(cx)\,dx=\tfrac14cL^4=\tfrac12ML^2$ about the light end.

    Worked example (disk from rings). A solid disk is a nest of rings: a ring at radius $r$ of width $dr$ has $dm=\dfrac{M}{\pi R^2}\,2\pi r\,dr$, so

    $$I=\int_0^R r^2\,dm=\frac{2M}{R^2}\int_0^R r^3\,dr=\tfrac12MR^2.$$

    The same coaxial-shell method handles cylindrical shells and annular rings.

    The parallel-axis theorem 平行轴定理 shifts any known $I$ to a parallel axis a distance $d$ away:

    $$I'=I_{\text{cm}}+Md^2.$$

    For the rod about one end: $I=\tfrac1{12}ML^2+M\big(\tfrac{L}{2}\big)^2=\tfrac13ML^2$.

    Bahasa Indonesia

    Inersia rotasi $I$ mengukur resistansi terhadap percepatan sudut – analog rotasi dari massa, tetapi tergantung pada dimana massa berada. Untuk massa titik, $I=\sum m_ir_i^2$; untuk tubuh kontinu,

    $$I=\int r^2\,dm.$$

    Massa jauh dari sumbu mendominasi, karena $r^2$.

    Contoh terpecahkan (batang). Batang seragam (massa $M$, panjang $L$) tentang pusatnya: dengan kerapatan linear $\lambda=M/L$, $dm=\lambda\,dx$, sehingga $I=\displaystyle\int_{-L/2}^{L/2}x^2\,\frac{M}{L}\,dx=\frac{1}{12}ML^2$. AP juga mengharapkan batang tidak seragam: jika $\lambda(x)=cx$ pada $[0,L]$, pertama-tama cari $M=\int_0^L cx\,dx=\tfrac12cL^2$, lalu $I=\int_0^L x^2(cx)\,dx=\tfrac14cL^4=\tfrac12ML^2$ tentang ujung ringan.

    Contoh terpecahkan (cakram dari cincin). Cakram padat adalah sarang cincin: sebuah cincin pada jari-jari $r$ dengan lebar $dr$ memiliki $dm=\dfrac{M}{\pi R^2}\,2\pi r\,dr$, sehingga

    $$I=\int_0^R r^2\,dm=\frac{2M}{R^2}\int_0^R r^3\,dr=\tfrac12MR^2.$$

    Metode cangkang koaksial yang sama menangani cangkang silinder dan cincin annular.

    Teorema sumbu sejajar menggeser setiap $I$ yang diketahui ke sumbu sejajar yang berjarak $d$:

    $$I'=I_{\text{cm}}+Md^2.$$

    Untuk batang tentang salah satu ujung: $I=\tfrac1{12}ML^2+M\big(\tfrac{L}{2}\big)^2=\tfrac13ML^2$.

    5.5

    Rotational Equilibrium · ⁨Kesetimbangan Rotasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 5.5.A: Describe the conditions under which a system's angular velocity remains constant.

    • 5.5.A.1 A system may exhibit rotational equilibrium (constant angular velocity) without being in translational equilibrium, and vice versa.
      • 5.5.A.1.i Free-body and force diagrams describe the nature of the forces and torques exerted on an object or rigid system.
      • 5.5.A.1.ii Rotational equilibrium is a configuration of torques such that the net torque exerted on the system is zero.
        • Equation: $\sum \tau_i = 0$
      • 5.5.A.1.iii The rotational analog of Newton's first law is that a system will have a constant angular velocity only if the net torque exerted on the system is zero.
    • 5.5.A.2 A rotational corollary to Newton's second law states that if the torques exerted on a rigid system are not balanced, the system's angular velocity must be changing.

    Boundary statement: AP Physics C: Mechanics does not expect students to simultaneously analyze rotation in multiple planes.

    Bahasa Indonesia

    Tujuan Pembelajaran 5.5.A: Jelaskan kondisi di mana kecepatan sudut sistem tetap konstan.

    • 5.5.A.1 Suatu sistem dapat menunjukkan kesetimbangan rotasi (kecepatan sudut konstan) tanpa berada dalam kesetimbangan translasi, dan sebaliknya.
      • 5.5.A.1.i Diagram benda bebas dan diagram gaya mendeskripsikan sifat gaya-gaya dan torsi-torsi yang diberikan pada suatu objek atau sistem kaku.
      • 5.5.A.1.ii Kesetimbangan rotasi adalah konfigurasi torsi sedemikian rupa sehingga resultan torsi yang diberikan pada sistem adalah nol.
        • Persamaan: $\sum \tau_i = 0$
      • 5.5.A.1.iii Analog rotasi dari hukum pertama Newton menyatakan bahwa sistem akan memiliki kecepatan sudut konstan hanya jika resultan torsi yang diberikan pada sistem adalah nol.
    • 5.5.A.2 Koreolarium rotasi dari hukum kedua Newton menyatakan bahwa jika torsi-torsi yang diberikan pada sistem kaku tidak seimbang, maka kecepatan sudut sistem harus berubah.

    Pernyataan Batas: AP Physics C: Mekanika tidak mengharapkan siswa untuk secara bersamaan menganalisis rotasi dalam beberapa bidang.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Newton's first law has a rotational form: with zero net torque, angular velocity is constant – an object in rotational equilibrium 转动平衡 either does not rotate or rotates steadily. Full static equilibrium 静平衡 needs both $\sum F=0$ and $\sum\tau=0$ (about any axis). The standard move for beams and ladders: put the axis at the point where an unknown force acts, so that force drops out of the torque equation.

    Worked example. A uniform $20\ \text{kg}$ beam, $4.0\ \text{m}$ long, is pivoted at its left end and held horizontal by a vertical rope at its right end. A $40\ \text{kg}$ child sits $1.0\ \text{m}$ from the pivot. Torques about the pivot: $T(4.0)=20g(2.0)+40g(1.0)$, so $T=\dfrac{392+392}{4.0}=196\ \text{N}$. Then vertical force balance gives the pivot's upward push: $F_p=(60)(9.8)-196=392\ \text{N}$. Choosing the pivot as the axis removed $F_p$ from the torque equation entirely.

    Bahasa Indonesia

    Hukum pertama Newton memiliki bentuk rotasi: dengan torsi neto nol, kecepatan sudut adalah konstan – sebuah objek dalam keseimbangan rotasi tidak berputar atau berputar stabil. Keseimbangan statis penuh membutuhkan kedua $\sum F=0$ dan $\sum\tau=0$ (tentang sumbu apa pun). Langkah standar untuk balok dan tangga: letakkan sumbu di titik di mana gaya tak dikenal bekerja, sehingga gaya itu hilang dari persamaan torsi.

    Pada kesetimbangan, torsi searah jarum jam dan berlawanan arah jarum jam terhadap sumbu adalah sama
    Pada keseimbangan torsi searah jarum jam dan berlawanan jarum jam tentang sumbu adalah sama

    Contoh terpecahkan. Sebuah balok $20\ \text{kg}$ seragam, panjangnya $4.0\ \text{m}$, ditumpukan di ujung kirinya dan dijaga tetap horizontal oleh tali vertikal di ujung kanannya. Seorang anak $40\ \text{kg}$ duduk $1.0\ \text{m}$ dari titik tumpu. Torsi terhadap titik tumpu: $T(4.0)=20g(2.0)+40g(1.0)$, sehingga $T=\dfrac{392+392}{4.0}=196\ \text{N}$. Kemudian keseimbangan gaya vertikal memberikan dorongan ke atas dari titik tumpu: $F_p=(60)(9.8)-196=392\ \text{N}$. Memilih titik tumpu sebagai sumbu sepenuhnya menghilangkan $F_p$ dari persamaan torsi.

    Neraca balok: kesetimbangan rotasi ketika torsi searah dan berlawanan arah jarum jam setara
    Pembalance balok: keseimbangan rotasi ketika torsi searah dan berlawanan jarum jam cocok
    Explore · ⁨Jelajahi⁩

    Find the balance point · ⁨Temukan titik keseimbangan⁩

    For rotational equilibrium the total clockwise torque equals the total anticlockwise torque. Move the forces and distances until the beam balances. · ⁨Untuk keseimbangan rotasi, total torsi searah jarum jam sama dengan total torsi berlawanan arah jarum jam. Gerakkan gaya dan jarak hingga balok seimbang.⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    5.6

    Newton's Second Law in Rotational Form · ⁨Hukum Kedua Newton dalam Bentuk Rotasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 5.6.A: Describe the conditions under which a system's angular velocity changes.

    • 5.6.A.1 Angular velocity changes when the net torque exerted on the object or system is not equal to zero.
    • 5.6.A.2 The rate at which the angular velocity of a rigid system changes is directly proportional to the net torque exerted on the rigid system and is in the same direction. The angular acceleration of the rigid system is inversely proportional to the rotational inertia of the rigid system.
      • Equation: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
    • 5.6.A.3 To fully describe a rotating rigid system, linear and rotational analyses may need to be performed independently.
    Bahasa Indonesia

    Tujuan Pembelajaran 5.6.A: Jelaskan kondisi di mana kecepatan sudut sistem berubah.

    • 5.6.A.1 Kecepatan sudut berubah ketika resultan torsi yang diberikan pada objek atau sistem tidak sama dengan nol.
    • 5.6.A.2 Laju perubahan kecepatan sudut sistem kaku berbanding lurus dengan resultan torsi yang diberikan pada sistem kaku dan berarah sama. Percepatan sudut sistem kaku berbanding terbalik dengan inersia rotasi sistem kaku.
      • Persamaan: $\alpha_{\text{sys}} = \dfrac{\Sigma\tau}{I_{\text{sys}}} = \dfrac{\tau_{\text{net}}}{I_{\text{sys}}}$
    • 5.6.A.3 Untuk mendeskripsikan sepenuhnya sistem kaku yang berotasi, analisis linear dan rotasi mungkin perlu dilakukan secara independen.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    A net torque produces angular acceleration in proportion to the rotational inertia:

    $$\alpha=\frac{\sum\tau}{I}\qquad\Big(\text{more generally }\sum\vec{\tau}=\frac{d\vec{L}}{dt}\Big).$$

    Solve rotational dynamics exactly like translational dynamics, with $\tau\leftrightarrow F$, $I\leftrightarrow m$, $\alpha\leftrightarrow a$ – free-body diagram, equations, solve.

    Worked example (massive pulley). Masses $m_1=4.0\ \text{kg}$ and $m_2=2.0\ \text{kg}$ hang from a rope over a pulley 滑轮 of rotational inertia $I=0.50\ \text{kg}\cdot\text{m}^2$ and radius $R=0.20\ \text{m}$. Three Newton's-law equations, one per body:

    $$m_1g-T_1=m_1a,\qquad T_2-m_2g=m_2a,\qquad (T_1-T_2)R=I\alpha=\frac{Ia}{R}.$$

    Adding them (with $I/R^2=12.5\ \text{kg}$): $a=\dfrac{(m_1-m_2)g}{m_1+m_2+I/R^2}=\dfrac{19.6}{18.5}=1.1\ \text{m/s}^2$. Then $T_1=m_1(g-a)=35\ \text{N}$ and $T_2=m_2(g+a)=22\ \text{N}$. The tensions must differ – otherwise nothing would spin the pulley. (If a problem says the pulley is light, then $I\approx0$ and the tensions become equal again.)

    Exam skill. Rotational FRQs score the setup: separate free-body diagrams for each mass and the pulley, the string constraint $a=R\alpha$ stated, and the sign convention consistent. The single most common error is assuming one tension throughout a rope that passes over a massive pulley.

    Bahasa Indonesia

    Torsi neto menghasilkan percepatan sudut sebanding dengan inersia rotasi:

    $$\alpha=\frac{\sum\tau}{I}\qquad\Big(\text{more generally }\sum\vec{\tau}=\frac{d\vec{L}}{dt}\Big).$$

    Selesaikan dinamika rotasi persis seperti dinamika translasi, dengan $\tau\leftrightarrow F$, $I\leftrightarrow m$, $\alpha\leftrightarrow a$ – diagram benda bebas, persamaan, selesaikan.

    Katrol bermassa: dua tegangan berbeda karena katrol memerlukan torsi bersih
    Katrol bermassa: dua tegangan berbeda karena katrol memerlukan torsi neto

    Contoh terpecahkan (katrol bermassa). Massa $m_1=4.0\ \text{kg}$ dan $m_2=2.0\ \text{kg}$ digantungkan pada tali yang dilintaskan katrol dengan inersia rotasi $I=0.50\ \text{kg}\cdot\text{m}^2$ dan jari-jari $R=0.20\ \text{m}$. Tiga persamaan hukum Newton, satu untuk setiap benda:

    $$m_1g-T_1=m_1a,\qquad T_2-m_2g=m_2a,\qquad (T_1-T_2)R=I\alpha=\frac{Ia}{R}.$$

    Menambahkan keduanya (dengan $I/R^2=12.5\ \text{kg}$): $a=\dfrac{(m_1-m_2)g}{m_1+m_2+I/R^2}=\dfrac{19.6}{18.5}=1.1\ \text{m/s}^2$. Kemudian $T_1=m_1(g-a)=35\ \text{N}$ dan $T_2=m_2(g+a)=22\ \text{N}$. Tegangan harus berbeda – jika tidak, tidak akan ada yang memutar katrol. (Jika soal menyatakan katrolnya ringan, maka $I\approx0$ dan tegangan menjadi sama lagi.)

    Keterampilan ujian. FRQ rotasi menilai penyusunan: diagram benda bebas terpisah untuk setiap massa dan katrol, batasan tali $a=R\alpha$ dinyatakan, serta konvensi tanda konsisten. Kesalahan paling umum adalah mengasumsikan satu tegangan sepanjang tali yang melewati katrol berrate.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    pulley/ˈpʊli/ katrol
    5.6

    Exam tips · ⁨Tips ujian⁩

    English
    • Use the rotational analogues: $\theta,\omega=\tfrac{d\theta}{dt},\alpha=\tfrac{d\omega}{dt}$, with the constant-$\alpha$ equations mirroring linear kinematics.
    • Convert between linear and angular with $v=r\omega$ and $a_t=r\alpha$ (plus centripetal $a_c=\tfrac{v^2}{r}=\omega^2 r$).
    • Keep radians throughout and fix a positive sense of rotation.
    • Relate torque to angular acceleration through $\tau=I\alpha$.
    • Draw the rotation axis — the moment arm is the perpendicular distance to it.
    Bahasa Indonesia
    • Gunakan analogi rotasi: $\theta,\omega=\tfrac{d\theta}{dt},\alpha=\tfrac{d\omega}{dt}$, dengan persamaan konstan-$\alpha$ yang meniru kinematika linear.
    • Konversi antara linear dan sudut dengan $v=r\omega$ dan $a_t=r\alpha$ (ditambah sentripetal $a_c=\tfrac{v^2}{r}=\omega^2 r$).
    • Pertahankan radian sepanjang proses dan tetapkan arah positif rotasi.
    • Hubungkan torsi dengan percepatan sudut melalui $\tau=I\alpha$.
    • Gambar sumbu rotasi – lengan momen adalah jarak tegak lurus ke sana.
  • 6

    Energy and Momentum of Rotating Systems · ⁨Energi dan Momentum Sistem Berputar⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    6.1

    Rotational Kinetic Energy · ⁨Energi Kinetik Rotasi⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 6.1.A: Describe the rotational kinetic energy of a rigid system in terms of the rotational inertia and angular velocity of that rigid system.

    • 6.1.A.1 The rotational kinetic energy of an object or rigid system is related to the rotational inertia and angular velocity of the rigid system and is given by the equation $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
      • Equation: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
      • 6.1.A.1.i The rotational inertia of an object about a fixed axis can be used to show that the rotational kinetic energy of that object is equivalent to its translational kinetic energy, which is its total kinetic energy.
      • 6.1.A.1.ii The total kinetic energy of a rigid system is the sum of its rotational kinetic energy due to its rotation about its center of mass and the translational kinetic energy due to the linear motion of its center of mass.
    • 6.1.A.2 A rigid system can have rotational kinetic energy while its center of mass is at rest due to the individual points within the rigid system having linear speed and, therefore, kinetic energy.
    • 6.1.A.3 Rotational kinetic energy is a scalar quantity.
    Bahasa Indonesia

    Tujuan Pembelajaran 6.1.A: Jelaskan energi kinetik rotasi sistem kaku dalam istilah inersia rotasi dan kecepatan sudut sistem kaku tersebut.

    • 6.1.A.1 Energi kinetik rotasi dari suatu objek atau sistem kaku berkaitan dengan inersia rotasi dan kecepatan sudut sistem kaku tersebut dan diberikan oleh persamaan $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$.
      • Persamaan: $K_{\text{rot}} = \dfrac{1}{2} I \omega^2$
      • 6.1.A.1.i Inersia rotasi dari suatu objek tentang sumbu tetap dapat digunakan untuk menunjukkan bahwa energi kinetik rotasi dari objek tersebut setara dengan energi kinetik translasinya, yaitu total energi kinetiknya.
      • 6.1.A.1.ii Total energi kinetik sistem kaku adalah jumlah dari energi kinetik rotasinya akibat rotasi tentang pusat massanya dan energi kinetik translasinya akibat gerak linear pusat massanya.
    • 6.1.A.2 Sistem kaku dapat memiliki energi kinetik rotasi meskipun pusat massanya diam karena titik-titik individu di dalam sistem kaku memiliki kecepatan linear dan, karenanya, energi kinetik.
    • 6.1.A.3 Energi kinetik rotasi adalah besaran skalar.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    A spinning body has rotational kinetic energy 转动动能

    $$K_{\text{rot}}=\tfrac12 I\omega^2,$$

    the rotational twin of $\tfrac12mv^2$, with the rotational inertia 转动惯量 $I$ playing the role of mass. A body that both moves and spins carries both terms:

    $$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$

    Worked example. A uniform cylinder ($I=\tfrac12mr^2$) rolls at speed $v$. Its kinetic energy is $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – one third of it is rotational. The same ball of energy bookkeeping decides every rolling problem.

    Bahasa Indonesia

    Benda berputar memiliki energi kinetik rotasi

    $$K_{\text{rot}}=\tfrac12 I\omega^2,$$

    kembar rotasi dari $\tfrac12mv^2$, dengan momen inersia $I$ yang berperan sebagai massa. Benda yang bergerak sekaligus berputar membawa kedua suku tersebut:

    $$K=\tfrac12 mv_{\text{cm}}^2+\tfrac12 I\omega^2.$$

    Contoh terpecahkan. Silinder seragam ($I=\tfrac12mr^2$) menggelinding pada kecepatan $v$. Energinya adalah $K=\tfrac12mv^2+\tfrac12\big(\tfrac12mr^2\big)\big(\tfrac{v}{r}\big)^2=\tfrac34mv^2$ – sepertiganya adalah energi rotasi. Buku catatan energi yang sama memutuskan setiap masalah menggelinding.

    6.2

    Torque and Work · ⁨Torsi dan Usaha⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 6.2.A: Describe the work done on a rigid system by a given torque or collection of torques.

    • 6.2.A.1 A torque can transfer energy into or out of an object or rigid system if the torque is exerted over an angular displacement.
    • 6.2.A.2 The amount of work done on a rigid system by a torque is related to the magnitude of that torque and the angular displacement through which the rigid system rotates during the interval in which that torque is exerted.
      • Equation: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
    • 6.2.A.3 Work done on a rigid system by a given torque can be found from the area under the curve of a graph of the torque as a function of angular position.
    Bahasa Indonesia

    Tujuan Pembelajaran 6.2.A: Jelaskan usaha yang dilakukan pada sistem kaku oleh torsi tertentu atau kumpulan torsi.

    • 6.2.A.1 Torsi dapat mentransfer energi masuk ke dalam atau keluar dari suatu objek atau sistem kaku jika torsi tersebut diberikan selama perpindahan sudut.
    • 6.2.A.2 Besarnya usaha yang dilakukan pada sistem kaku oleh sebuah torsi berkaitan dengan besaran torsi tersebut dan perpindahan sudut yang dilalui sistem kaku saat berotasi selama selang waktu torsi diberikan.
      • Persamaan: $W = \displaystyle\int_{\theta_1}^{\theta_2} \tau \, d\theta$
    • 6.2.A.3 Usaha yang dilakukan pada sistem kaku oleh suatu torsi tertentu dapat ditemukan dari luas di bawah kurva grafik torsi sebagai fungsi posisi sudut.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    A torque 力矩 acting through an angular displacement 角位移 does work, and power is torque times angular velocity:

    $$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$

    These are the rotational forms of $W=\int F\,dx$ and $P=Fv$ – the whole translational energy toolkit carries over with $F\to\tau$, $x\to\theta$, $v\to\omega$.

    Worked example. A motor applies a constant $8.0\ \text{N}\cdot\text{m}$ torque to a flywheel for $5.0$ full turns: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, which appears as rotational kinetic energy if friction is negligible.

    Bahasa Indonesia

    Torsi yang bekerja melalui pergeseran sudut melakukan usaha, dan daya adalah torsi dikali kecepatan sudut:

    $$W=\int_{\theta_1}^{\theta_2}\tau\,d\theta,\qquad P=\tau\omega.$$

    Ini adalah bentuk-bentuk rotasi dari $W=\int F\,dx$ dan $P=Fv$ – seluruh paket alat energi translasi dapat diterapkan dengan $F\to\tau$, $x\to\theta$, $v\to\omega$.

    Contoh terpecahkan. Motor menerapkan torsi konstan $8.0\ \text{N}\cdot\text{m}$ pada roda gila selama $5.0$ putaran penuh: $W=\tau\,\Delta\theta=8.0(5.0)(2\pi)=250\ \text{J}$, yang muncul sebagai energi kinetik rotasi jika gesekan dapat diabaikan.

    Explore · ⁨Jelajahi⁩

    Balance torques on a beam · ⁨Seimbangkan torsi pada balok⁩

    Torque is force times perpendicular distance, $\tau=Fd$. Equal torques on each side keep the beam in rotational equilibrium. · ⁨Torsi adalah gaya dikali jarak tegak lurus, $\tau=Fd$. Torsi yang sama di masing-masing sisi menjaga balok dalam kesetimbangan rotasi.⁩

    6.3

    Angular Momentum and Angular Impulse · ⁨Momentum Sudut dan Impuls Sudut⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 6.3.A: Describe the angular momentum of an object or rigid system.

    • 6.3.A.1 The magnitude of the angular momentum of a rigid system about a specific axis can be described with the equation $L = I\omega$.
      • Equation: $L = I\omega$
    • 6.3.A.2 The angular momentum of an object about a given point is $\vec{L} = \vec{r} \times \vec{p}$.
      • Equation: $\vec{L} = \vec{r} \times \vec{p}$
      • 6.3.A.2.i The selection of the axis about which an object is considered to rotate influences the determination of the angular momentum of that object.
      • 6.3.A.2.ii The measured angular momentum of an object traveling in a straight line depends on the distance between the reference point and the object, the mass of the object, the speed of the object, and the angle between the radial distance and the velocity of the object.

    Learning Objective 6.3.B: Describe the angular impulse delivered to an object or rigid system by a torque.

    • 6.3.B.1 Angular impulse is defined as the product of the torque exerted on an object or rigid system and the time interval during which the torque is exerted.
      • Equation: $\text{angular impulse} = \displaystyle\int \tau \, dt$
    • 6.3.B.2 Angular impulse has the same direction as the torque imparting it.
    • 6.3.B.3 The angular impulse delivered to an object or rigid system by a torque can be found from the area under the curve of a graph of the torque as a function of time.

    Learning Objective 6.3.C: Relate the change in angular momentum of an object or rigid system to the angular impulse given to that object or rigid system.

    • 6.3.C.1 The magnitude of the change in angular momentum can be described by comparing the magnitudes of the final and initial momenta of the object or rigid system.
      • Equation: $\Delta L = L - L_0$
    • 6.3.C.2 A rotational form of the impulse–momentum theorem relates the angular impulse delivered to an object or rigid system and the change in angular momentum of that object or rigid system.
      • 6.3.C.2.i The angular impulse exerted on an object or rigid system is equal to the change in angular momentum of that object or rigid system.
        • Equation: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
      • 6.3.C.2.ii The rotational form of the impulse–momentum theorem is a direct result of Newton's second law of motion for cases in which rotational inertia is constant.
        • Equation: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
    • 6.3.C.3 The net torque exerted on an object or rigid system is equal to the slope of the graph of the angular momentum of an object as a function of time.
    • 6.3.C.4 The angular impulse delivered to an object or rigid system is equal to the area under the curve of a graph of the net external torque exerted on an object as a function of time.
    Bahasa Indonesia

    Tujuan Pembelajaran 6.3.A: Jelaskan momentum sudut dari sebuah objek atau sistem kaku.

    • 6.3.A.1 Besar momentum sudut dari sistem kaku terhadap sumbu tertentu dapat dijelaskan dengan persamaan $L = I\omega$.
      • Persamaan: $L = I\omega$
    • 6.3.A.2 Momentum sudut sebuah objek tentang titik tertentu adalah $\vec{L} = \vec{r} \times \vec{p}$.
      • Persamaan: $\vec{L} = \vec{r} \times \vec{p}$
      • 6.3.A.2.i Pemilihan sumbu tentang mana objek dianggap berotasi mempengaruhi penentuan momentum sudut objek tersebut.
      • 6.3.A.2.ii Momentum sudut terukur dari objek yang bergerak lurus bergantung pada jarak antara titik referensi dan objek, massa objek, kecepatan objek, serta sudut antara jarak radial dan kecepatan objek.

    Tujuan Pembelajaran 6.3.B: Jelaskan impuls sudut yang diberikan kepada objek atau sistem kaku oleh torsi.

    • 6.3.B.1 Impuls sudut didefinisikan sebagai hasil kali torsi yang diberikan pada objek atau sistem kaku dengan selang waktu torsi tersebut diberikan.
      • Persamaan: $\text{angular impulse} = \displaystyle\int \tau \, dt$
    • 6.3.B.2 Impuls sudut memiliki arah yang sama dengan torsi yang memberikannya.
    • 6.3.B.3 Impuls sudut yang diberikan kepada objek atau sistem kaku oleh torsi dapat ditemukan dari luas di bawah kurva grafik torsi sebagai fungsi waktu.

    Tujuan Pembelajaran 6.3.C: Hubungkan perubahan momentum sudut dari objek atau sistem kaku dengan impuls sudut yang diberikan kepada objek atau sistem kaku tersebut.

    • 6.3.C.1 Besaran perubahan momentum sudut dapat dijelaskan dengan membandingkan besaran momentum akhir dan awal objek atau sistem kaku tersebut.
      • Persamaan: $\Delta L = L - L_0$
    • 6.3.C.2 Bentuk rotasi dari teorem impuls-momentum menghubungkan impuls sudut yang diberikan kepada objek atau sistem kaku dengan perubahan momentum sudut dari objek atau sistem kaku tersebut.
      • 6.3.C.2.i Impuls sudut yang diberikan pada objek atau sistem kaku sama dengan perubahan momentum sudut dari objek atau sistem kaku tersebut.
        • Persamaan: $\Delta L = \displaystyle\int_{t_1}^{t_2} \tau \, dt$
      • 6.3.C.2.ii Bentuk rotasi dari teorema impuls-momentum merupakan hasil langsung dari hukum kedua Newton tentang gerak untuk kasus di mana inersia rotasi konstan.
        • Persamaan: $\tau_{\text{net}} = \dfrac{dL}{dt} = I\dfrac{d\omega}{dt} = I\alpha$
    • 6.3.C.3 Resultan torsi yang diberikan pada sebuah objek atau sistem kaku sama dengan kemiringan grafik momentum sudut objek sebagai fungsi waktu.
    • 6.3.C.4 Impuls sudut yang diberikan pada sebuah objek atau sistem kaku sama dengan luas di bawah kurva grafik resultan torsi eksternal yang diberikan pada objek sebagai fungsi waktu.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Angular momentum 角动量 for a particle is

    $$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$

    so even a particle moving in a straight line has angular momentum about any point not on that line ($L=mv\,d$, with $d$ the perpendicular distance). For a rigid body spinning about a fixed axis, $L=I\omega$. Newton's second law in rotational form is

    $$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$

    and a net torque acting over time delivers an angular impulse 角冲量 $\int\tau\,dt=\Delta L$ – the rotational impulse–momentum theorem.

    Bahasa Indonesia

    Momentum sudut untuk sebuah partikel adalah

    $$\vec{L}=\vec{r}\times\vec{p},\qquad |L|=mvr\sin\theta,$$

    sehingga bahkan partikel yang bergerak dalam garis lurus memiliki momentum sudut terhadap titik manapun yang tidak berada pada garis itu ($L=mv\,d$, dengan $d$ sebagai jarak tegak lurus). Untuk benda kaku yang berputar tentang sumbu tetap, $L=I\omega$. Hukum kedua Newton dalam bentuk rotasi adalah

    $$\vec{\tau}_{\text{net}}=\frac{d\vec{L}}{dt}\quad(=I\alpha\ \text{when }I\text{ is constant}),$$

    dan torsi bersih yang bekerja selama waktu memberikan impuls angular $\int\tau\,dt=\Delta L$ – teorema impuls-momentum rotasi.

    6.4

    Conservation of Angular Momentum · ⁨Kekekalan Momentum Sudut⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 6.4.A: Describe the behavior of a system using conservation of angular momentum.

    • 6.4.A.1 The total angular momentum of a system about a rotational axis is the sum of the angular momenta of the system's constituent parts about that rotational axis.
    • 6.4.A.2 Any change to a system's angular momentum must be due to an interaction between the system and its surroundings.
      • 6.4.A.2.i The angular impulse exerted by one object or system on a second object or system is equal and opposite to the angular impulse exerted by the second object or system on the first. This is a direct result of Newton's third law.
      • 6.4.A.2.ii A system may be selected so that the total angular momentum of that system is constant.
      • 6.4.A.2.iii The angular speed of a nonrigid system may change without the angular momentum of the system changing if the system changes shape by moving mass closer to or farther from the rotational axis.
      • 6.4.A.2.iv If the total angular momentum of a system changes, that change will be equivalent to the angular impulse exerted on the system.

    Learning Objective 6.4.B: Describe how the selection of a system determines whether the angular momentum of that system changes.

    • 6.4.B.1 Angular momentum is conserved in all interactions.
    • 6.4.B.2 If the net external torque exerted on a selected object or rigid system is zero, the total angular momentum of that system is constant.
    • 6.4.B.3 If the net external torque exerted on a selected object or rigid system is nonzero, angular momentum is transferred between the system and the environment.
    Bahasa Indonesia

    Tujuan Pembelajaran 6.4.A: Jelaskan perilaku sistem menggunakan kekekalan momentum sudut.

    • 6.4.A.1 Total momentum sudut sistem tentang sumbu rotasi adalah jumlah dari momentum sudut bagian-bagian penyusun sistem tersebut tentang sumbu rotasi itu.
    • 6.4.A.2 Setiap perubahan pada momentum sudut sistem harus disebabkan oleh interaksi antara sistem dan lingkungannya.
      • 6.4.A.2.i Impuls sudut yang diberikan oleh satu objek atau sistem kepada objek atau sistem kedua sama besar dan berlawanan arah dengan impuls sudut yang diberikan oleh objek atau sistem kedua kepada yang pertama. Ini merupakan akibat langsung dari hukum ketiga Newton.
      • 6.4.A.2.ii Sistem dapat dipilih sedemikian rupa sehingga total momentum sudut sistem tersebut konstan.
      • 6.4.A.2.iii Kecepatan sudut sistem nonkaku dapat berubah tanpa perubahan momentum sudut sistem jika sistem mengubah bentuk dengan memindahkan massa lebih dekat atau lebih jauh dari sumbu rotasi.
      • 6.4.A.2.iv Jika total momentum sudut sistem berubah, perubahan tersebut akan setara dengan impuls sudut yang diberikan kepada sistem.

    Tujuan Pembelajaran 6.4.B: Jelaskan bagaimana pemilihan sistem menentukan apakah momentum sudut dari sistem tersebut berubah.

    • 6.4.B.1 Momentum sudut kekal dalam semua interaksi.
    • 6.4.B.2 Jika torsi eksternal bersih yang diberikan pada objek atau sistem kaku yang dipilih adalah nol, total momentum sudut sistem tersebut konstan.
    • 6.4.B.3 Jika torsi eksternal bersih yang diberikan pada objek atau sistem kaku yang dipilih tidak nol, momentum sudut ditransfer antara sistem dan lingkungan.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Angular momentum: pull in, spin faster

    With zero net external torque, total angular momentum is conserved 守恒:

    $$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$

    If $I$ shrinks, $\omega$ grows – a spinning skater speeds up pulling her arms in. The rule survives collisions and shape changes, which is what makes it so useful: pick the axis so that every external force (gravity, the pivot force) exerts no torque about it.

    Worked example. A skater spins at $2.0\ \text{rev/s}$ with $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Pulling in her arms drops it to $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Her kinetic energy rises – the extra energy is the work her muscles do pulling her arms inward.

    Worked example (rotational collision). A $0.020\ \text{kg}$ bullet at $300\ \text{m/s}$ strikes the tip of a uniform rod ($M=1.5\ \text{kg}$, length $l=0.60\ \text{m}$) hanging from a pivot, and embeds. About the pivot, gravity and the pivot force exert no torque during the strike, so $L$ is conserved: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Afterwards $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, so $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Linear momentum is not conserved here – the pivot pushes on the rod – and kinetic energy certainly is not: check both before claiming them.)

    Bahasa Indonesia
    Momentum sudut: tarik masuk, putar lebih cepat

    Dengan torsi eksternal bersih nol, total momentum sudut terjaga:

    $$L_{\text{before}}=L_{\text{after}},\qquad I_1\omega_1=I_2\omega_2\ \text{(one rigid body reshaping)}.$$

    Jika $I$ mengecil, $\omega$ meningkat – seorang peluncur es berputar semakin cepat saat menarik lengannya. Aturan ini bertahan pada tabrakan dan perubahan bentuk, yang menjadikannya sangat berguna: pilih sumbu sehingga setiap gaya eksternal (gravitasi, gaya engsel) tidak menghasilkan torsi terhadapnya.

    Contoh terpecahkan. Seorang peluncur berputar pada $2.0\ \text{rev/s}$ dengan $I_1=4.0\ \text{kg}\cdot\text{m}^2$. Menarik lengannya menurunkannya menjadi $I_2=1.6\ \text{kg}\cdot\text{m}^2$: $\omega_2=\dfrac{4.0}{1.6}(2.0)=5.0\ \text{rev/s}$. Energi kinetiknya naik – energi tambahan adalah usaha yang dilakukan ototnya saat menarik lengannya ke dalam.

    Menarik massa ke dalam menurunkan I, sehingga ω naik untuk mengkonservasi L = Iω
    Menarik massa ke dalam menurunkan I, sehingga ω naik untuk mengkonservasi L = Iω
    Momentum sudut terhadap titik tumpu kekal saat peluru tertanam dalam batang
    Momentum sudut terhadap engsel terjaga saat peluru tertanam dalam batang

    Contoh terpecahkan (tabrakan rotasi). Peluru $0.020\ \text{kg}$ pada $300\ \text{m/s}$ mengenai ujung batang seragam ($M=1.5\ \text{kg}$, panjang $l=0.60\ \text{m}$) yang digantung dari engsel, dan tertanam. Terhadap engsel, gravitasi dan gaya engsel tidak menghasilkan torsi selama benturan, jadi $L$ terjaga: $L=mvl=0.020(300)(0.60)=3.6\ \text{kg}\cdot\text{m}^2/\text{s}$. Setelahnya $I=\tfrac13Ml^2+ml^2=0.18+0.0072=0.187\ \text{kg}\cdot\text{m}^2$, sehingga $\omega=\dfrac{3.6}{0.187}\approx19\ \text{rad/s}$. (Momentum linear tidak dijaga di sini – engsel mendorong batang – dan energi kinetik certainly tidak dijaga: periksa keduanya sebelum mengklaim mereka dijaga.)

    Skater yang sedang tampil di atas es
    Seni meluncur dan momentum sudut: peluncur yang menarik lengannya saat berputar menurunkan momen inersianya, sehingga berputar lebih cepat
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    rotational kinetic energy/rəʊˈteɪʃənl kɪˈnetɪk ˈenədʒi/ energi kinetik rotasi
    rotational inertia/rəʊˈteɪʃənl ɪˈnɜːʃə/ inersia rotasi
    torque/tɔːk/ tork
    angular displacement/ˈæŋɡjʊlə dɪˈspleɪsmənt/ pencucupan sudut
    Angular momentum/ˈæŋɡjʊlə məʊˈmentəm/ Momentum sudut
    angular impulse/ˈæŋɡjʊlə ˈɪmpʌls/ impuls sudut
    conserved/kənˈsɜːvd/ terjaga
    6.5

    Rolling · ⁨Pengguliran⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 6.5.A: Describe the kinetic energy of a system that has translational and rotational motion.

    • 6.5.A.1 The total kinetic energy of a system is the sum of the system's translational and rotational kinetic energies.
      • Equation: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$

    Learning Objective 6.5.B: Describe the motion of a system that is rolling without slipping.

    • 6.5.B.1 While rolling without slipping, the translational motion of a system's center of mass is related to the rotational motion of the system itself with the following equations:
      • Equation: $\Delta x_{\text{cm}} = r\Delta\theta$
      • Equation: $v_{\text{cm}} = r\omega$
      • Equation: $a_{\text{cm}} = r\alpha$
    • 6.5.B.2 For ideal cases, rolling without slipping implies that the frictional force does not dissipate any energy from the rolling system.

    Learning Objective 6.5.C: Describe the motion of a system that is rolling while slipping.

    • 6.5.C.1 When slipping, the motion of a system's center of mass and the system's rotational motion cannot be directly related.
    • 6.5.C.2 When a rotating system is slipping relative to another surface, the point of application of the force of kinetic friction exerted on the system moves with respect to the surface, so the force of kinetic friction will dissipate energy from the system.

    Boundary statement: Rolling friction is beyond the scope of AP Physics C: Mechanics.

    Bahasa Indonesia

    Tujuan Pembelajaran 6.5.A: Jelaskan energi kinetik dari sistem yang memiliki gerak translasi dan rotasi.

    • 6.5.A.1 Total energi kinetik dari sistem adalah jumlah dari energi kinetik translasi dan rotasi sistem.
      • Persamaan: $K_{\text{tot}} = K_{\text{trans}} + K_{\text{rot}}$

    Tujuan Pembelajaran 6.5.B: Jelaskan gerak sistem yang menggulung tanpa tergelincir.

    • 6.5.B.1 Saat menggelinding tanpa selip, gerak translasi pusat massa sistem berkaitan dengan gerak rotasi sistem itu sendiri melalui persamaan berikut:
      • Persamaan: $\Delta x_{\text{cm}} = r\Delta\theta$
      • Persamaan: $v_{\text{cm}} = r\omega$
      • Persamaan: $a_{\text{cm}} = r\alpha$
    • 6.5.B.2 Untuk kasus ideal, menggulir tanpa tergelincir berarti gaya gesek tidak meng dissipasi energi dari sistem yang menggulir.

    Tujuan Pembelajaran 6.5.C: Jelaskan gerak sistem yang menggulir sambil tergelincir.

    • 6.5.C.1 Saat tergelincir, gerak pusat massa sistem dan gerak rotasi sistem tidak dapat dihubungkan secara langsung.
    • 6.5.C.2 Ketika sistem berputar tergelincir relatif terhadap permukaan lain, titik aplikasi gaya gesek kinetik yang bekerja pada sistem bergerak relatif terhadap permukaan, sehingga gaya gesek kinetik akan meng dissipasi energi dari sistem.

    Pernyataan Batas: Gesekan rolling berada di luar cakupan AP Physics C: Mechanics.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Rolling without slipping

    Rolling without slipping 无滑滚动 ties translation to rotation: the contact point is momentarily at rest, so

    $$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$

    Static friction supplies the torque that keeps the spin matched to the motion, but at a point that is not sliding – so for pure rolling, friction does no work, and energy conservation is safe to use. (Rolling friction is beyond the AP course.)

    Racing shapes down an incline shows the energy split. With $I=\beta mr^2$, energy conservation gives

    $$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$

    a sphere ($\beta=\tfrac25$) beats a disk 圆盘 ($\beta=\tfrac12$), which beats a hoop 圆环 ($\beta=1$) – mass and radius cancel completely. More of the hoop's energy is locked in rotation, so its center moves slower.

    Worked example. A solid sphere rolls from rest down a $30^\circ$ incline: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, versus $4.9\ \text{m/s}^2$ for a frictionless slider – rolling objects always lose the race against sliding ones.

    Bahasa Indonesia
    Menggelinding tanpa selip

    Menggelinding tanpa selip menghubungkan translasi dengan rotasi: titik kontak berhenti sejenak, sehingga

    $$\Delta x_{\text{cm}}=r\,\Delta\theta,\qquad v_{\text{cm}}=r\omega,\qquad a_{\text{cm}}=r\alpha.$$
    Dalam pengguliran tanpa selip, titik kontak berada dalam keadaan diam, sehingga v = rω
    Dalam pengguliran tanpa selip, titik kontak berada dalam keadaan diam, sehingga v = rω

    Gesekan statis menyediakan torsi yang menjaga putaran sesuai dengan gerakan, tetapi pada titik yang tidak meluncur – sehingga untuk gelinding murni, gesekan tidak melakukan usaha, dan konservasi energi aman digunakan. (Gesekan gelinding berada di luar kurikulum AP.)

    Balapan bentuk turun di bidang miring menunjukkan pembagian energi. Dengan $I=\beta mr^2$, konservasi energi memberikan

    $$a_{\text{cm}}=\frac{g\sin\theta}{1+\beta}:$$

    bola ($\beta=\tfrac25$) mengalahkan cakram ($\beta=\tfrac12$), yang mengalahkan cincin ($\beta=1$) – massa dan jari-jari saling menghilangkan sepenuhnya. Lebih banyak energi cincin terkunci dalam rotasi, sehingga pusatnya bergerak lebih lambat.

    Balapan menggelinding: bentuk dengan I/mr terkecil ² mencapai dasar terlebih dahulu
    Balapan gelinding: bentuk dengan I/mr² terkecil mencapai dasar pertama kali

    Contoh terpecahkan. Bola pejal menggelinding dari keadaan diam di bidang miring $30^\circ$: $a=\dfrac{g\sin30^\circ}{1+\tfrac25}=\dfrac{9.8(0.50)}{1.4}=3.5\ \text{m/s}^2$, dibandingkan dengan $4.9\ \text{m/s}^2$ untuk penggeser tanpa gesekan – objek menggelinding selalu kalah balapan melawan objek yang meluncur.

    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Rolling without slipping/ˈrəʊlɪŋ wɪˈðaʊt ˈslɪpɪŋ/ Bergulir tanpa selip
    disk/dɪsk/ disk
    hoop/huːp/ gelung
    centripetal force/senˈtrɪpɪtl fɔːs/ kekuatan sentripetal
    satellite/ˈsætəlaɪt/ satelit
    gravitational potential energy/ˌɡrævɪˈteɪʃənl pəˈtenʃl ˈenədʒi/ energi potensial gravitasi
    total mechanical energy/ˈtəʊtl mɪˈkænɪkl ˈenədʒi/ Energi mekanik total
    escape velocity/eˈskeɪp vəˈlɒsɪti/ kecepatan lepas
    elliptical orbit/ɪˈlɪptɪkl ˈɔːbɪt/ Orbit elips
    Kepler's second law/ˈkepləz ˈsekənd lɔː/ Hukum kedua Kepler
    6.6

    Motion of Orbiting Satellites · ⁨Gerak Satelit Berorbit⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 6.6.A: Describe the motions of a system consisting of two objects or systems interacting only via gravitational forces.

    • 6.6.A.1 In a system consisting only of a massive central object and an orbiting satellite with mass that is negligible in comparison to the central object's mass, the motion of the central object itself is negligible.
    • 6.6.A.2 The motion of satellites in orbits is constrained by conservation laws.
      • 6.6.A.2.i In circular orbits, the system's total mechanical energy, the system's gravitational potential energy, and the satellite's angular momentum and kinetic energy are constant.
      • 6.6.A.2.ii In elliptical orbits, the system's total mechanical energy and the satellite's angular momentum are constant, but the system's gravitational potential energy and the satellite's kinetic energy can each change.
      • 6.6.A.2.iii The gravitational potential energy of a system consisting of a satellite and a massive central object is defined to be zero when the satellite is an infinite distance from the central object.
        • Equation: $U_g = -G\dfrac{m_1 m_2}{r}$
    • 6.6.A.3 The total energy of a system consisting of a satellite orbiting a central object in a circular path can be written in terms of the gravitational potential energy of that system or the kinetic energy of the satellite.
      • Equation: $K = -\dfrac{1}{2}U$
      • Equation: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
    • 6.6.A.4 The escape velocity of a satellite is the satellite's velocity such that the mechanical energy of the satellite–central-object system is equal to zero.
      • 6.6.A.4.i When the only force exerted on a satellite is gravity from a central object, a satellite that reaches escape velocity will move away from the central body until its speed reaches zero at an infinite distance from the central body.
      • 6.6.A.4.ii The escape velocity of a satellite from a central body of mass $M$ can be derived using conservation of energy laws.
        • Equation: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$
    Bahasa Indonesia

    Tujuan Pembelajaran 6.6.A: Deskripsikan gerak sistem yang terdiri dari dua objek atau sistem yang berinteraksi hanya melalui gaya gravitasi.

    • 6.6.A.1 Dalam sistem yang hanya terdiri dari objek pusat bermassa besar dan satelit pengelilingi yang massanya dapat diabaikan dibandingkan massa objek pusat, gerak objek pusat itu sendiri dapat diabaikan.
    • 6.6.A.2 Gerak satelit dalam orbit dibatasi oleh hukum-hukum kekekalan.
      • 6.6.A.2.i Dalam orbit lingkaran, energi mekanik total sistem, energi potensial gravitasi sistem, serta momentum sudut dan energi kinetik satelit adalah konstan.
      • 6.6.A.2.ii Dalam orbit elips, energi mekanik total sistem dan momentum sudut satelit adalah konstan, tetapi energi potensial gravitasi sistem dan energi kinetik satelit masing-masing dapat berubah.
      • 6.6.A.2.iii Energi potensial gravitasi sistem yang terdiri dari satelit dan objek pusat bermassa besar didefinisikan bernilai nol ketika satelit berada pada jarak tak hingga dari objek pusat.
        • Persamaan: $U_g = -G\dfrac{m_1 m_2}{r}$
    • 6.6.A.3 Energi total sistem yang terdiri dari satelit yang mengorbit benda sentral dalam lintasan lingkaran dapat dituliskan dalam bentuk energi potensial gravitasi sistem tersebut atau energi kinetik satelit.
      • Persamaan: $K = -\dfrac{1}{2}U$
      • Persamaan: $E_{total} = \dfrac{1}{2}U = -\dfrac{GMm}{2r}$
    • 6.6.A.4 Kecepatan lepas sebuah satelit adalah kecepatan satelit sedemikian rupa sehingga energi mekanik sistem satelit–benda sentral sama dengan nol.
      • 6.6.A.4.i Ketika satu-satunya gaya yang bekerja pada satelit adalah gravitasi dari benda sentral, satelit yang mencapai kecepatan lepas akan menjauhi benda sentral hingga kecepatannya mencapai nol pada jarak tak terhingga dari benda sentral.
      • 6.6.A.4.ii Kecepatan lepas satelit dari benda sentral bermassa $M$ dapat diturunkan menggunakan hukum kekekalan energi.
        • Persamaan: $v_{\text{esc}} = \sqrt{\dfrac{2GM}{r}}$

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Orbital motion (Kepler's 2nd law)

    Gravity supplies the centripetal force 向心力 for a satellite 卫星 in a circular orbit:

    $$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$

    – larger orbits are slower. With gravitational potential energy 引力势能 $U_g=-\dfrac{GMm}{r}$, a circular orbit obeys $K=-\tfrac12U$, so the total mechanical energy 总机械能 is

    $$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$

    negative because the satellite is bound. To escape from radius $r$, total energy must reach zero, giving the escape velocity 逃逸速度

    $$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$

    In an elliptical orbit 椭圆轨道, $E$ and $L$ are fixed: gravity points at the focus, so it exerts no torque about it. Conserved $L$ means the satellite sweeps equal areas in equal times – Kepler's second law 开普勒第二定律 – and therefore moves fastest at closest approach, slowest at the far point. Energy conservation connects speeds at the two ends.

    Worked example. For a satellite at $r=7.0\times10^{6}\ \text{m}$ around Earth ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): orbital speed $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, while escaping from that radius needs $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – exactly $\sqrt2$ times the circular speed.

    Exam skill. Orbit FRQs are energy-and-angular-momentum problems in disguise: write $E=\tfrac12mv^2-\dfrac{GMm}{r}$ and $L=mvr\sin\theta$ at the two points of interest and solve the pair – never assume the orbit formulae for circles apply to an ellipse.

    Bahasa Indonesia
    Gerak orbital (Hukum Kepler ke-2)

    Gravitasi menyediakan gaya sentripetal untuk satelit dalam orbit lingkaran:

    $$\frac{GMm}{r^2}=\frac{mv^2}{r}\quad\Rightarrow\quad v=\sqrt{\frac{GM}{r}}$$

    – orbit yang lebih besar lebih lambat. Dengan energi potensial gravitasi $U_g=-\dfrac{GMm}{r}$, orbit lingkaran mematuhi $K=-\tfrac12U$, sehingga energi mekanik total adalah

    $$E=K+U=\frac{U}{2}=-\frac{GMm}{2r},$$

    negatif karena satelit terikat. Untuk lepas dari jari-jari $r$, energi total harus mencapai nol, memberikan kecepatan lepas

    $$v_{\text{esc}}=\sqrt{\frac{2GM}{r}}.$$
    Gravitasi menyediakan gaya sentripetal yang menjaga satelit tetap dalam orbit
    Gravitasi menyediakan gaya sentripetal yang menjaga satelit tetap dalam orbit

    Dalam orbit elips, $E$ dan $L$ tetap: gravitasi mengarah ke fokus, sehingga tidak menghasilkan torsi terhadapnya. Momentum sudut yang dijaga $L$ berarti satelit menyapu area yang sama dalam waktu yang sama – Hukum Kepler kedua – dan karenanya bergerak tercepat saat pendekatan terdekat, terlama di titik terjauh. Konservasi energi menghubungkan kecepatan di kedua ujung.

    Contoh terpecahkan. Untuk satelit pada $r=7.0\times10^{6}\ \text{m}$ mengelilingi Bumi ($GM=4.0\times10^{14}\ \text{m}^3/\text{s}^2$): kecepatan orbit $v=\sqrt{GM/r}=7.6\times10^{3}\ \text{m/s}$, sementara lepas dari jari-jari tersebut membutuhkan $v_{\text{esc}}=\sqrt{2GM/r}=1.1\times10^{4}\ \text{m/s}$ – tepat $\sqrt2$ kali kecepatan lingkaran.

    Keterampilan ujian. Soal FRQ orbit adalah masalah energi dan momentum sudut yang tersembunyi: tulis $E=\tfrac12mv^2-\dfrac{GMm}{r}$ dan $L=mvr\sin\theta$ pada dua titik yang relevan, lalu selesaikan sistem persamaan tersebut – jangan pernah mengasumsikan rumus orbit untuk lingkaran berlaku pada elips.

    Explore · ⁨Jelajahi⁩

    Compare orbits at different radii · ⁨Bandingkan orbit pada jari-jari berbeda⁩

    An orbiting satellite is in free fall, gravity supplying the centripetal force. A larger orbit means a slower speed and longer period (Kepler's third law). · ⁨Satelit yang mengorbit berada dalam jatuh bebas, gravitasi menyediakan gaya sentripetal. Orbit yang lebih besar berarti kecepatan lebih lambat dan periode lebih panjang (hukum Kepler ketiga).⁩

    6.6

    Exam tips · ⁨Tips ujian⁩

    English
    • Compute the moment of inertia $I=\int r^2\,dm$ and shift axes with the parallel-axis theorem $I=I_{cm}+Md^2$.
    • Rotational kinetic energy is $\tfrac12 I\omega^2$; a rolling body has both translational and rotational KE.
    • Conserve angular momentum $L=I\omega$ when net external torque is zero (a spinning skater pulling in).
    • Use energy conservation for rolling-without-slipping problems ($v=r\omega$ ties the two motions).
    • Know standard $I$ values (hoop, disk, rod, sphere) and where the axis is.
    Bahasa Indonesia
    • Hitung momen inersia $I=\int r^2\,dm$ dan geser sumbu dengan menggunakan teorema sumbu sejajar $I=I_{cm}+Md^2$.
    • Energi kinetik rotasi adalah $\tfrac12 I\omega^2$; benda bergulir memiliki energi kinetik translasi maupun rotasi.
    • Konservasi momentum sudut $L=I\omega$ berlaku ketika torsi eksternal bersih bernilai nol (seperti penari es yang menarik lengannya ke dalam).
    • Gunakan kekekalan energi untuk masalah menggelinding tanpa selip ($v=r\omega$ menghubungkan kedua gerakan ini).
    • Hafalkan nilai standar $I$ (cincin, cakram, batang, bola) beserta posisi sumbunya.
  • 7

    Oscillations · ⁨Osilasi⁩

    Watch lesson · ⁨Tonton pelajaran⁩
    7.1

    Defining Simple Harmonic Motion · ⁨Mendefinisikan Gerak Harmonik Sederhana⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 7.1.A: Describe simple harmonic motion.

    • 7.1.A.1 Simple harmonic motion is a special case of periodic motion.
    • 7.1.A.2 SHM results when the magnitude of the restoring force exerted on an object is proportional to that object's displacement from its equilibrium position.
      • Derived equation: $ma_x = -k\Delta x$
      • 7.1.A.2.i A restoring force is a force that is exerted in a direction opposite to the object's displacement from an equilibrium position.
      • 7.1.A.2.ii An equilibrium position is a location at which the net force exerted on an object or system is zero.
    Bahasa Indonesia

    Tujuan Pembelajaran 7.1.A: Jelaskan gerak harmonik sederhana.

    • 7.1.A.1 Gerak harmonik sederhana adalah kasus khusus dari gerak periodik.
    • 7.1.A.2 GHS terjadi ketika besar gaya pemulih yang bekerja pada suatu benda sebanding dengan simpangan benda tersebut dari posisi kesetimbangannya.
      • Persamaan Turunan: $ma_x = -k\Delta x$
      • 7.1.A.2.i Gaya pemulih adalah gaya yang bekerja dalam arah berlawanan dengan simpangan benda dari posisi kesetimbangan.
      • 7.1.A.2.ii Posisi kesetimbangan adalah lokasi di mana resultan gaya yang bekerja pada benda atau sistem adalah nol.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Simple harmonic motion

    Simple harmonic motion 简谐运动 (SHM) is a special case of periodic motion 周期运动. It appears whenever two things are true: there is an equilibrium 平衡位置 position where the net force is zero, and displacing the object produces a restoring force 回复力 – a force pointing back toward equilibrium – whose magnitude is proportional to the displacement:

    $$F=-k\,\Delta x.$$

    Newton's second law then gives the defining differential equation 微分方程:

    $$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$

    Its solution is sinusoidal, $x(t)=A\cos(\omega t+\phi)$. You do not need to prove this solution – you need to recognise the equation: any system whose motion obeys "$\ddot{x}=-\omega^2x$" is a simple harmonic oscillator, whatever it is made of. (A mass hanging on a vertical spring works the same way: gravity only shifts the equilibrium point; the oscillation about it is unchanged.)

    Bahasa Indonesia
    Gerak harmonik sederhana

    Gerak harmonik sederhana (GHS) merupakan kasus khusus dari gerak periodik. GHS muncul apabila dua hal berikut benar: terdapat posisi keseimbangan di mana gaya bersihnya nol, dan menggeser benda menghasilkan gaya pemulih – yaitu gaya yang mengarah kembali menuju keseimbangan – yang besarnya berbanding lurus dengan simpangannya:

    $$F=-k\,\Delta x.$$

    Hukum kedua Newton kemudian memberikan persamaan diferensial pembentuknya:

    $$\frac{d^2x}{dt^2}=-\frac{k}{m}\,x=-\omega^2 x,\qquad \omega=\sqrt{\frac{k}{m}}.$$

    Solusinya bersifat sinusoidal, $x(t)=A\cos(\omega t+\phi)$. Anda tidak perlu membuktikan solusi ini – Anda harus mengenalinya: setiap sistem yang gerakannya mematuhi "$\ddot{x}=-\omega^2x$" adalah osilator harmonik sederhana, apa pun bahan pembentuknya. (Benda bermassa yang digantung pada pegas vertikal bekerja sama cara: gravitasi hanya menggeser titik keseimbangan; osilasi di sekitar titik tersebut tetap tidak berubah.)

    Dalam GHS percepatan selalu mengarah kembali ke kesetimbangan, berlawanan dengan simpangan
    Dalam GHS percepatan selalu mengarah kembali ke kesetimbangan, berlawanan dengan simpangan
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    Simple harmonic motion/ˈsɪmpl hɑːˈmɒnɪk ˈməʊʃn/ Gerak Harmonik Sederhana
    periodic motion/ˌpɪərɪˈɒdɪk ˈməʊʃn/ Gerak periodik
    equilibrium/ˌiːkwɪˈlɪbrɪəm/ kesetimbangan
    restoring force/rɪˈstɔːrɪŋ fɔːs/ gaya pemulih
    differential equation/ˌdɪfəˈrenʃl ɪˈkweɪʒn/ persamaan diferensial
    angular frequency/ˈæŋɡjʊlə ˈfriːkwənsi/ frekuensi sudut
    period/ˈpɪərɪəd/ tempoh
    frequency/ˈfriːkwənsi/ frekuensi
    amplitude/ˈæmplɪtjuːd/ amplitudo
    phase constant/feɪz ˈkɒnstənt/ Konstanta fase
    natural frequency/ˈnætʃərəl ˈfriːkwənsi/ frekuensi alami
    resonance/ˈrezənəns/ resonansi
    7.2

    Frequency and Period of SHM · ⁨Frekuensi dan Periode GHS⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 7.2.A: Describe the frequency and period of an object exhibiting SHM.

    • 7.2.A.1 The period of SHM is related to the angular frequency, $\omega$, of the object's motion by the following equation:
      • Equation: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
      • 7.2.A.1.i The period of an object–ideal-spring oscillator is given by the equation
        • Equation: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
      • 7.2.A.1.ii The period of a simple pendulum displaced by a small angle is given by the equation
        • Equation: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$
    Bahasa Indonesia

    Tujuan Pembelajaran 7.2.A: Jelaskan frekuensi dan periode benda yang mengalami GHS.

    • 7.2.A.1 Periode Gerak Harmonik Sederhana (GHS) berkaitan dengan kecepatan sudut, $\omega$, dari gerak benda melalui persamaan berikut:
      • Persamaan: $T = \dfrac{2\pi}{\omega} = \dfrac{1}{f}$
      • 7.2.A.1.i Periode osilator benda–pegas ideal diberikan oleh persamaan
        • Persamaan: $T_s = 2\pi\sqrt{\dfrac{m}{k}}.$
      • 7.2.A.1.ii Periode ayunan sederhana yang menyimpang dengan sudut kecil diberikan oleh persamaan
        • Persamaan: $T_p = 2\pi\sqrt{\dfrac{l}{g}}.$

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    The angular frequency 角频率 $\omega$ sets the period 周期 and frequency 频率:

    $$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$

    For the two standard systems:

    $$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$

    Two classic conceptual traps: the period of SHM never depends on the amplitude 振幅, and each system ignores one obvious variable – the pendulum's period does not involve its mass, and the spring's period does not involve $g$ (a spring–block oscillator keeps perfect time in orbit; a pendulum clock does not).

    Bahasa Indonesia

    Kecepatan sudut $\omega$ menentukan periode dan frekuensi:

    $$T=\frac{2\pi}{\omega}=\frac{1}{f}.$$

    Untuk dua sistem standar:

    $$T_{\text{spring}}=2\pi\sqrt{\frac{m}{k}},\qquad T_{\text{pendulum}}=2\pi\sqrt{\frac{\ell}{g}}.$$

    Dua jebakan konseptual klasik: periode GHS tidak pernah bergantung pada amplitudo, dan setiap sistem mengabaikan satu variabel yang terlihat jelas – periode ayunan tidak melibatkan massanya, dan periode pegas tidak melibatkan $g$ (osilator pegas-blok dapat menjaga waktu yang sempurna di orbit; jam bandul tidak bisa).

    Explore · ⁨Jelajahi⁩

    Time a pendulum's swing · ⁨Ukur waktu ayunan bandul⁩

    A pendulum's period depends on its length and gravity, not its mass or (small) amplitude: $T=2\pi\sqrt{L/g}$. Lengthen it and each swing takes longer. · ⁨Periode bandul bergantung pada panjang dan gravitasi, bukan massa atau amplitudonya (kecil): $T=2\pi\sqrt{L/g}$. Perpanjang bandul dan setiap ayunan akan memakan waktu lebih lama.⁩

    7.3

    Representing and Analyzing SHM · ⁨Representasi dan Analisis GHS⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 7.3.A: Describe the displacement, velocity, and acceleration of an object exhibiting SHM.

    • 7.3.A.1 For an object exhibiting SHM, the displacement of that object measured from its equilibrium position can be represented by the equations $x = A\cos(2\pi ft)$ or $x = A\sin(2\pi ft)$.
      • 7.3.A.1.i Minima, maxima, and zeros of displacement, velocity, and acceleration are features of harmonic motion.
      • 7.3.A.1.ii Recognizing the positions or times at which the displacement, velocity, and acceleration for SHM have extrema or zeros can help in qualitatively describing the behavior of the motion.
    • 7.3.A.2 The position as a function of time for an object exhibiting SHM is a solution of the second-order differential equation derived from the application of Newton's second law.
      • Derived equation: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
    • 7.3.A.3 Characteristics of SHM, such as velocity and acceleration, can be determined by or derived from the equation $x = A\cos(\omega t + \phi).$
      • 7.3.A.3.i The acceleration of an object exhibiting SHM is related to the object's angular frequency and position.
        • Derived equation: $a = -\omega^2 x$
      • 7.3.A.3.ii It can be shown that the maximum velocity and acceleration of an object exhibiting SHM are related to the angular frequency of the object's motion.
        • Derived equations: $v_{\max} = A\omega$
        • $a_{\max} = A\omega^2$
    • 7.3.A.4 In the presence of a sinusoidal external force, a system may exhibit resonance.
      • 7.3.A.4.i Resonance occurs when an external force is exerted at the natural frequency of an oscillating system.
      • 7.3.A.4.ii Resonance increases the amplitude of oscillating motion.
      • 7.3.A.4.iii The natural frequency of a system is the frequency at which the system will oscillate when it is displaced from its equilibrium position.
    • 7.3.A.5 Changing the amplitude of a system exhibiting SHM will not change its period.
    • 7.3.A.6 Properties of SHM can be determined and analyzed using graphical representations.

    Boundary statement: AP Physics C: Mechanics only expects students to know the solution to the second-order differential equation that describes SHM, as well as be able to identify SHM. AP Physics C: Mechanics does not expect students to mathematically prove that the solution is correct.

    Bahasa Indonesia

    Tujuan Pembelajaran 7.3.A: Jelaskan simpangan, kecepatan, dan percepatan benda yang mengalami GHS.

    • 7.3.A.1 Untuk benda yang mengalami GHS, simpangan benda tersebut diukur dari posisi kesetimbangannya dapat direpresentasikan oleh persamaan $x = A\cos(2\pi ft)$ atau $x = A\sin(2\pi ft)$.
      • 7.3.A.1.i Minimum, maksimum, dan nol dari simpangan, kecepatan, dan percepatan merupakan fitur dari gerak harmonik.
      • 7.3.A.1.ii Mengenali posisi atau waktu di mana simpangan, kecepatan, dan percepatan untuk GHS memiliki nilai ekstrem atau nol dapat membantu dalam mendeskripsikan perilaku gerak secara kualitatif.
    • 7.3.A.2 Posisi sebagai fungsi waktu untuk benda yang mengalami GHS merupakan solusi dari persamaan diferensial orde dua yang diturunkan dari penerapan Hukum Kedua Newton.
      • Persamaan Turunan: $\dfrac{d^2 x}{dt^2} = -\omega^2 x$
    • 7.3.A.3 Karakteristik GHS, seperti kecepatan dan percepatan, dapat ditentukan atau diturunkan dari persamaan $x = A\cos(\omega t + \phi).$
      • 7.3.A.3.i Percepatan benda yang mengalami GHS berkaitan dengan kecepatan sudut dan posisi benda tersebut.
        • Persamaan turunan: $a = -\omega^2 x$
      • 7.3.A.3.ii Dapat ditunjukkan bahwa kecepatan maksimum dan percepatan maksimum dari benda yang mengalami GHS berkaitan dengan kecepatan sudut gerak benda.
        • Persamaan Turunan: $v_{\max} = A\omega$
        • $a_{\max} = A\omega^2$
    • 7.3.A.4 Dalam kehadiran gaya eksternal sinusoidal, suatu sistem dapat menunjukkan resonansi.
      • 7.3.A.4.i Resonansi terjadi ketika gaya eksternal diterapkan pada frekuensi alami sistem bergetar.
      • 7.3.A.4.ii Resonansi meningkatkan amplitudo gerak bergetar.
      • 7.3.A.4.iii Frekuensi alami suatu sistem adalah frekuensi di mana sistem akan bergetar ketika disimpangkan dari posisi kesetimbangannya.
    • 7.3.A.5 Mengubah amplitudo sistem yang mengalami GHS tidak akan mengubah periodenya.
    • 7.3.A.6 Properti GHS dapat ditentukan dan dianalisis menggunakan representasi grafik.

    Pernyataan Batas: AP Physics C: Mechanics hanya mengharapkan siswa mengetahui solusi persamaan diferensial orde dua yang mendeskripsikan GHS, serta mampu mengidentifikasi GHS. AP Physics C: Mechanics tidak mengharapkan siswa membuktikan secara matematis bahwa solusi tersebut benar.

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    Differentiate $x(t)=A\cos(\omega t+\phi)$ twice:

    $$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$

    So at the ends of the swing ($x=\pm A$) the speed is zero and the acceleration is largest; passing through equilibrium ($x=0$) the acceleration is zero and the speed is largest, $v_{\max}=A\omega$. The amplitude $A$ and the phase constant 相位常数 $\phi$ come from the initial conditions: where the object starts and how fast it is moving. Eliminating $t$ (or using energy, below) gives speed as a function of position:

    $$v=\pm\,\omega\sqrt{A^2-x^2}.$$

    Worked example. A $0.50\ \text{kg}$ mass on a $k=200\ \text{N/m}$ spring: $\omega=\sqrt{k/m}=20\ \text{rad/s}$, $T=2\pi/\omega=0.31\ \text{s}$. With $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ at equilibrium, and at $x=0.050\ \text{m}$ the speed is $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.

    Bahasa Indonesia

    Turunkan $x(t)=A\cos(\omega t+\phi)$ sebanyak dua kali:

    $$v=-A\omega\sin(\omega t+\phi),\qquad a=-A\omega^2\cos(\omega t+\phi)=-\omega^2x.$$

    Jadi, di ujung-ujung ayunan ($x=\pm A$), kecepatannya nol dan percepatan paling besar; saat melewati kesetimbangan ($x=0$), percepatan nol dan kecepatannya paling besar, $v_{\max}=A\omega$. Amplitudo ($A$) dan konstanta fase ($\phi$) berasal dari kondisi awal: di mana benda dimulai dan seberapa cepat ia bergerak. Mengeliminasi ($t$) (atau menggunakan energi, di bawah) memberikan kecepatan sebagai fungsi posisi:

    $$v=\pm\,\omega\sqrt{A^2-x^2}.$$

    Simpangan bervariasi secara sinusoidal terhadap waktu dalam gerak harmonik sederhana *Sesar berubah secara sinusoidal terhadap masa dalam gerakan harmonik mudah

    Contoh kerja. Sebuah massa $0.50\ \text{kg}$ pada pegas $k=200\ \text{N/m}$: $\omega=\sqrt{k/m}=20\ \text{rad/s}$, $T=2\pi/\omega=0.31\ \text{s}$. Dengan $A=0.10\ \text{m}$: $v_{\max}=A\omega=2.0\ \text{m/s}$ di kesetimbangan, dan pada $x=0.050\ \text{m}$ kecepatannya adalah $v=\omega\sqrt{A^2-x^2}=20\sqrt{0.10^2-0.050^2}=1.7\ \text{m/s}$.

    7.4

    Energy of Simple Harmonic Oscillators · ⁨Energi Osilator Harmonik Sederhana⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 7.4.A: Describe the mechanical energy of a system exhibiting SHM.

    • 7.4.A.1 The total energy of a system exhibiting SHM is the sum of the system's kinetic and potential energies.
      • Relevant equation: $E_{\text{total}} = U + K$
    • 7.4.A.2 Conservation of energy indicates that the total energy of a system exhibiting SHM is constant.
    • 7.4.A.3 The kinetic energy of a system exhibiting SHM is at a maximum when the system's potential energy is at a minimum.
    • 7.4.A.4 The potential energy of a system exhibiting SHM is at a maximum when the system's kinetic energy is at a minimum.
      • 7.4.A.4.i The minimum kinetic energy of a system exhibiting SHM is zero.
      • 7.4.A.4.ii Changing the amplitude of a system exhibiting SHM will change the maximum potential energy of the system and, therefore, the total energy of the system.
        • Relevant equation for a spring–object system: $E_{\text{total}} = \dfrac{1}{2}kA^2$
    Bahasa Indonesia

    Tujuan Pembelajaran 7.4.A: Jelaskan energi mekanik sistem yang mengalami GHS.

    • 7.4.A.1 Energi total sistem yang mengalami GHS adalah jumlah dari energi kinetik dan potensial sistem.
      • Persamaan relevan: $E_{\text{total}} = U + K$
    • 7.4.A.2 Hukum kekekalan energi menunjukkan bahwa energi total sistem yang mengalami GHS adalah konstan.
    • 7.4.A.3 Energi kinetik sistem yang mengalami GHS mencapai maksimum ketika energi potensial sistem berada pada minimum.
    • 7.4.A.4 Energi potensial sistem yang menunjukkan Gerak Harmonik Sederhana (GHS) berada pada maksimum ketika energi kinetik sistem berada pada minimum.
      • 7.4.A.4.i Energi kinetik minimum dari sistem yang menunjukkan GHS adalah nol.
      • 7.4.A.4.ii Mengubah amplitudo sistem yang menunjukkan GHS akan mengubah energi potensial maksimum sistem dan, oleh karena itu, juga mengubah energi total sistem.
        • Persamaan Relevan untuk sistem pegas–benda: $E_{\text{total}} = \dfrac{1}{2}kA^2$

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English

    The total energy of the oscillator is the sum $E=U+K$, and with no friction it is constant – energy just trades back and forth between the spring's potential energy and the mass's kinetic energy:

    $$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$

    All potential at the ends (where $K=0$), all kinetic at equilibrium (where $U$ is minimum). Because $E\propto A^2$, doubling the amplitude quadruples the energy.

    Worked example. Where is the energy split evenly? Set $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$, so $x=A/\sqrt2\approx0.71A$ – much closer to the end than to the middle. For the system above ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.

    Left alone, a system oscillates at its own natural frequency 固有频率 (set by $k$ and $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). Drive it with a periodic force at that same frequency and the amplitude grows dramatically – resonance 共振. Each well-timed push adds energy faster than damping removes it, so the driven amplitude peaks sharply when the driving frequency matches $f_0$ (a swing pumped in time, a bridge shaken by wind).

    Bahasa Indonesia

    Energi total osilator adalah jumlah $E=U+K$, dan tanpa gesekan energi ini konstan – energi hanya bolak-balik antara energi potensial pegas dan energi kinetik benda:

    $$E=\tfrac12kA^2=\tfrac12kx^2+\tfrac12mv^2.$$

    Semua energi tersimpan sebagai potensial di ujung-ujung (di mana $K=0$), semua energi berupa kinetik di titik keseimbangan (di mana $U$ minimum). Karena $E\propto A^2$, menggandakan amplitudo akan kuadruplikasi energinya.

    Pertukaran energi kinetik dan potensial sepanjang siklus sementara energi total tetap konstan
    Energi kinetik dan potensial bertukar selama satu siklus sementara energi total tetap konstan

    Contoh soal. Di mana energi terbagi merata? Tetapkan $\tfrac12kx^2=\tfrac12E=\tfrac14kA^2$, sehingga $x=A/\sqrt2\approx0.71A$ – jauh lebih dekat ke ujung daripada ke tengah. Untuk sistem di atas ($A=0.10\ \text{m}$): $x=0.071\ \text{m}$.

    Dibiarkan sendiri, sebuah sistem bergetar pada frekuensi alaminya (ditentukan oleh $k$ dan $m$: $f_0=\frac{1}{2\pi}\sqrt{k/m}$). Doronglah dengan gaya periodik pada frekuensi yang sama dan amplitudonya akan meningkat drastis – resonansi. Setiap dorongan yang tepat waktu menambahkan energi lebih cepat daripada redaman menghilangkannya, sehingga amplitudo terdorong memuncak tajam ketika frekuensi penggerak sesuai dengan $f_0$ (ayunan yang dipompa seirama, jembatan yang diguncang angin).

    Explore · ⁨Jelajahi⁩

    Trade kinetic and potential energy in SHM · ⁨Tukar energi kinetik dan potensial dalam Osilasi Harmonik Sederhana⁩

    In simple harmonic motion, energy sloshes between kinetic (fastest at the centre) and potential (greatest at the extremes) while the total stays constant. · ⁨Dalam osilasi harmonik sederhana, energi bolak-balik antara energi kinetik (paling cepat di tengah) dan potensial (terbesar di ujung), sementara totalnya tetap konstan.⁩

    7.5

    Simple and Physical Pendulums · ⁨Bandul Sederhana dan Bandul Fisika⁩

    Syllabus · ⁨Silabus⁩
    English

    Learning Objective 7.5.A: Describe the properties of a physical pendulum.

    • 7.5.A.1 A physical pendulum is a rigid body that undergoes oscillation about a fixed axis.
    • 7.5.A.2 For small amplitudes of motion, the period of a physical pendulum is derived from the application of Newton's second law in rotational form.
      • Relevant equation: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
      • 7.5.A.2.i When displaced from equilibrium, the gravitational force exerted on a physical pendulum's center of mass provides a restoring torque.
        • Derived equation: $\tau = -mgd\sin\theta$
      • 7.5.A.2.ii For small amplitudes of motion, the small-angle approximation can be applied to the restoring torque.
        • Derived equation: $\sin\theta \approx \theta$
        • $\tau = -mgd\theta = I\alpha$
      • 7.5.A.2.iii The small-angle approximation and Newton's second law in rotational form yield a second-order differential equation that describes SHM:
        • Equation: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
    • 7.5.A.3 A simple pendulum is a special case of physical pendulums in which the hanging object can be modeled as a point mass at a distance, $l$, from the pivot point.
      • Relevant equation: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
    • 7.5.A.4 A torsion pendulum is a case of SHM where the restoring torque is proportional to the angular displacement of a rotating system. For example, a horizontal disk that is suspended from a wire attached to its center of mass may undergo rotational oscillations about the wire in the horizontal plane.
      • Derived equation: $I\alpha = -k\Delta\theta$
    Bahasa Indonesia

    Tujuan Pembelajaran 7.5.A: Deskripsikan properti ayunan fisik.

    • 7.5.A.1 Ayunan fisik adalah benda kaku yang mengalami osilasi tentang sumbu tetap.
    • 7.5.A.2 Untuk amplitudo gerak yang kecil, periode ayunan fisik diturunkan dari penerapan Hukum Kedua Newton dalam bentuk rotasi.
      • Persamaan relevan: $T_{\text{phys}} = 2\pi\sqrt{\dfrac{I}{mgd}}$
      • 7.5.A.2.i Ketika disimpangkan dari kesetimbangan, gaya gravitasi yang bekerja pada pusat massa ayunan fisik memberikan torsi pemulih.
        • Persamaan turunan: $\tau = -mgd\sin\theta$
      • 7.5.A.2.ii Untuk amplitudo gerak yang kecil, pendekatan sudut kecil dapat diterapkan pada torsi pemulih.
        • Persamaan turunan: $\sin\theta \approx \theta$
        • $\tau = -mgd\theta = I\alpha$
      • 7.5.A.2.iii Pendekatan sudut kecil dan Hukum Kedua Newton dalam bentuk rotasi menghasilkan persamaan diferensial orde dua yang mendeskripsikan GHS:
        • Persamaan: $\dfrac{d^2\theta}{dt^2} = -\omega^2\theta$
    • 7.5.A.3 Ayunan sederhana adalah kasus khusus dari ayunan fisik di mana benda yang digantung dapat dimodelkan sebagai massa titik pada jarak, $l$, dari titik gantungan.
      • Persamaan relevan: $T_p = 2\pi\sqrt{\dfrac{\ell}{g}}$
    • 7.5.A.4 Ayunan torsi adalah kasus GHS di mana torsi pemulih sebanding dengan simpangan sudut dari sistem berputar. Misalnya, cakram horizontal yang digantung dari kawat yang melekat pada pusat massanya dapat mengalami osilasi rotasi tentang kawat tersebut dalam bidang horizontal.
      • Persamaan Turunan: $I\alpha = -k\Delta\theta$

    Source: College Board AP Course and Exam Description · ⁨Sumber: Deskripsi Kursus dan Ujian College Board AP⁩

    English
    Energy conservation: KE ⇄ PE

    A physical pendulum 物理摆 is any rigid body swinging about a fixed pivot. Displace it by an angle $\theta$ and gravity, acting at the center of mass a distance $d$ from the pivot, supplies a restoring torque

    $$\tau=-mgd\sin\theta.$$

    For small angles, apply the small-angle approximation 小角度近似 $\sin\theta\approx\theta$ and Newton's second law in rotational form ($\tau=I\alpha$):

    $$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$

    This is the same "$\ddot\theta=-\omega^2\theta$" pattern as before – recognising it is the derivation. A simple pendulum 单摆 is the special case of a point mass on a light string: $I=m\ell^2$ and $d=\ell$ give $T=2\pi\sqrt{\ell/g}$.

    Worked example. A uniform rod (mass $M$, length $L$) swings from one end: $I=\tfrac13ML^2$, $d=\tfrac{L}{2}$, so

    $$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$

    – shorter than a simple pendulum of length $L$, because the rod's mass sits nearer the pivot.

    A torsion pendulum 扭摆 – a disk hanging from a wire that twists – is SHM one more time: the wire's restoring torque is proportional to the twist angle, $I\alpha=-\kappa\,\Delta\theta$, giving $T=2\pi\sqrt{I/\kappa}$.

    Exam skill. Every pendulum FRQ wants the same three steps: write the restoring torque about the pivot, apply the small-angle approximation, and match the result to $\ddot\theta=-\omega^2\theta$ to read off $\omega$. State the small-angle step explicitly – it is a scored point, and it is why large-amplitude swings are not simple harmonic.

    Bahasa Indonesia
    Kekekalan energi: KE ⇄ PE

    Bandul fisika adalah benda kaku apa pun yang berayun mengelilingi poros tetap. Geserkan benda sebesar sudut $\theta$, dan gravitasi yang bekerja pada pusat massa sejauh $d$ dari poros, menyediakan torsi pemulih

    $$\tau=-mgd\sin\theta.$$

    Untuk sudut kecil, terapkan pendekatan sudut kecil $\sin\theta\approx\theta$ dan hukum kedua Newton dalam bentuk rotasi ($\tau=I\alpha$):

    $$\frac{d^2\theta}{dt^2}=-\frac{mgd}{I}\,\theta=-\omega^2\theta\quad\Rightarrow\quad T_{\text{phys}}=2\pi\sqrt{\frac{I}{mgd}}.$$

    Ini adalah pola "$\ddot\theta=-\omega^2\theta$" yang sama seperti sebelumnya – mengenali polanya merupakan proses penurunan rumusnya. Bandul sederhana adalah kasus khusus dari benda titik pada tali ringan: $I=m\ell^2$ dan $d=\ell$ menghasilkan $T=2\pi\sqrt{\ell/g}$.

    Gravitasi yang bekerja pada pusat massa menyediakan torsi pemulih bagi bandul fisika
    Gravitasi yang bekerja pada pusat massa menyediakan torsi pemulih bagi bandul fisika

    Contoh kerja. Sebuah batang seragam (massa $M$, panjang $L$) berayun dari salah satu ujungnya: $I=\tfrac13ML^2$, $d=\tfrac{L}{2}$, sehingga

    $$T=2\pi\sqrt{\frac{\tfrac13ML^2}{Mg\,\tfrac{L}{2}}}=2\pi\sqrt{\frac{2L}{3g}}$$

    – lebih pendek dari bandul sederhana sepanjang $L$, karena massa batang berada lebih dekat ke poros.

    Bandul torsi – sebuah cakram yang tergantung pada kawat yang melilit – kembali menunjukkan GHS: torsi pemulih kawat berbanding lurus dengan sudut lilitan, $I\alpha=-\kappa\,\Delta\theta$, menghasilkan $T=2\pi\sqrt{I/\kappa}$.

    Keterampilan ujian. Setiap soal FRQ bandul meminta tiga langkah yang sama: tuliskan torsi pemulih terhadap poros, terapkan pendekatan sudut kecil, dan samakan hasilnya dengan $\ddot\theta=-\omega^2\theta$ untuk membaca $\omega$. Nyatakan langkah pendekatan sudut secara eksplisit – ini adalah poin penilaian, dan inilah alasan mengapa ayunan beramplitudo besar bukan gerak harmonik sederhana.

    Bandul Foucault yang besar berayun di atas lantai bertanda
    Bandul Foucault: bandul panjang dan berat yang ayunannya lambat mengungkapkan bumi berputar di bawahnya
    Vocabulary · ⁨Kosa kata⁩ Train · ⁨Latih⁩
    English Bahasa Indonesia
    physical pendulum/ˈfɪzɪkl ˈpendjʊləm/ bandul fisik
    small-angle approximation/smɔːl ˈæŋɡl əˌprɒksɪˈmeɪʃn/ Pendekatan sudut kecil
    simple pendulum/ˈsɪmpl ˈpendjʊləm/ bandul sederhana
    torsion pendulum/ˈtɔːʃn ˈpendjʊləm/ Pendulum torsion
    7.5

    Exam tips · ⁨Tips ujian⁩

    English
    • Identify SHM from a linear restoring force $F=-kx$, which gives $\tfrac{d^2x}{dt^2}=-\omega^2 x$ with $\omega=\sqrt{k/m}$.
    • Write the solution $x=A\cos(\omega t+\phi)$ and get $v,a$ by differentiating; period $T=\tfrac{2\pi}{\omega}$ is amplitude-independent.
    • Energy trades between $\tfrac12 kx^2$ and $\tfrac12 mv^2$, with total $\tfrac12 kA^2$.
    • For a pendulum, use the small-angle approximation $\sin\theta\approx\theta$ to reach SHM.
    • Match phase to the start: released from rest at maximum displacement uses cosine.
    Bahasa Indonesia
    • Identifikasi GHS dari gaya pemulih linear $F=-kx$, yang menghasilkan $\tfrac{d^2x}{dt^2}=-\omega^2 x$ dengan $\omega=\sqrt{k/m}$.
    • Tuliskan solusinya $x=A\cos(\omega t+\phi)$ dan dapatkan $v,a$ dengan menurunkan; periode $T=\tfrac{2\pi}{\omega}$ tidak bergantung pada amplitudo.
    • Energi bolak-balik antara $\tfrac12 kx^2$ dan $\tfrac12 mv^2$, dengan total $\tfrac12 kA^2$.
    • Untuk bandul, gunakan pendekatan sudut kecil $\sin\theta\approx\theta$ untuk mencapai GHS.
    • Sesuaikan fase dengan kondisi awal: dilepaskan dari keadaan diam pada simpangan maksimum menggunakan fungsi kosinus.

Log in or create account · ⁨Masuk atau buat akun⁩

IGCSE, A-Level & AP