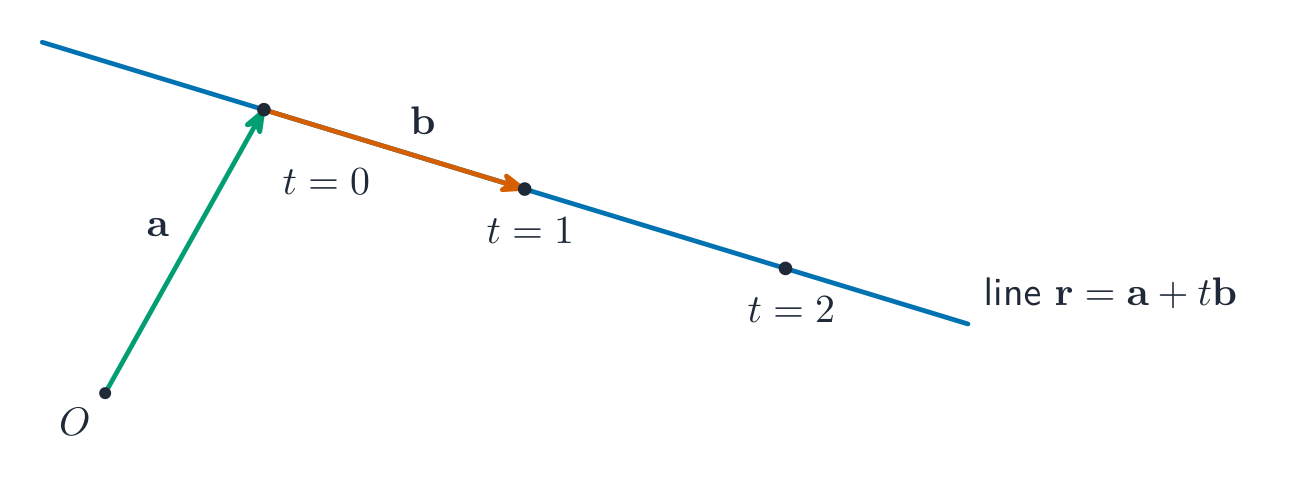
Skip to content · ⁨דלג לתוכן⁩

Functions Involving Parameters, Vectors, and Matrices · ⁨פונקציות הכוללות פרמטרים, וקטורים ומטריצות⁩

AP Precalculus · ⁨פרי-קלקולוס - AP⁩ · Topic 4 · ⁨נושא 4⁩

Video lesson for this topic · ⁨שיעור וידאו לנושא זה⁩ Open the video page · ⁨פתח את עמוד הוידאו⁩
8:04

פונקציות הכוללות פרמטרים, וקטורים ומטריצות

הסתכל על גלגלת הזו. בכל רגע לרכב יש שני פרטים: איפה הוא נמצא, ואילו כיוון הוא נוסע. משוואה אחת לא יכולה לחזיק את השניים. כוכב לכת זה מפעיל…

English narration · English + 中文 subtitles burned in · ⁨קריאת קול באנגלית · תרגום אנגלי + סינית שרוף בתוך הסרטון⁩

4.1

Parametric Functions · ⁨פונקציות פרמטריות⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.1.A: Construct a graph or table of values for a parametric function represented analytically.

  • 4.1.A.1 A parametric function in $\mathbb{R}^2$, the set of all ordered pairs of two real numbers, consists of a set of two parametric equations in which two dependent variables, $x$ and $y$, are dependent on a single independent variable, $t$, called the parameter.
  • 4.1.A.2 Because variables $x$ and $y$ are dependent on the independent variable, $t$, the coordinates $(x_i,\, y_i)$ at time $t_i$ can be written as functions of $t$ and can be expressed as the single parametric function $f(t) = (x(t),\, y(t))$, where in this case $x$ and $y$ are names of two functions.
  • 4.1.A.3 A numerical table of values can be generated for the parametric function $f(t) = (x(t),\, y(t))$ by evaluating $x_i$ and $y_i$ at several values of $t_i$ within the domain.
  • 4.1.A.4 A graph of a parametric function can be sketched by connecting several points from the numerical table of values in order of increasing value of $t$.
  • 4.1.A.5 The domain of the parametric function $f$ is often restricted, which results in start and end points on the graph of $f$.
עברית

מטרת הלמידה 4.1.A: לבנות גרף או טבלת ערכים לפונקציה פרמטרית המוצגת אנליטית.

  • 4.1.A.1 פונקציה פרמטרית ב$\mathbb{R}^2$, קבוצת כל הזוגות הסדורים של שני מספרים ממשיים, מורכבת מאוסף של שתי משוואות פרמטריות שבהם שני משתנים תלויים, $x$ ו$y$, תלויים במשתנה חופשי יחיד, $t$, הנקרא פרמטר.
  • 4.1.A.2 מכיוון שמשתנים $x$ ו$y$ תלויים במשתנה החופשי, $t$, הקואורדינטות $(x_i,\, y_i)$ בזמן $t_i$ ניתנות לכתיבה כפונקציות של $t$ וניתנות לביטוי כפונקציה פרמטרית אחת, $f(t) = (x(t),\, y(t))$, כאשר במקרה זה $x$ ו$y$ הן שמותיהם של שתי פונקציות.
  • 4.1.A.3 ניתן ליצור טבלת ערכים מספרית לפונקציה הפרמטרית $f(t) = (x(t),\, y(t))$ על ידי חישוב ערכי $x_i$ ו$y_i$ עבור מספר ערכים של $t_i$ בתחום.
  • 4.1.A.4 ניתן לשרטט גרף של פונקציה פרמטרית על ידי חיבור מספר נקודות מטבלת הערכים המספרית בסדר ערכים עולים של $t$.
  • 4.1.A.5 תחום הפונקציה הפרמטרית $f$ מוגבל לעיתים קרובות, מה שגורם לקיומו של נקודת התחלה ונקודת סיום בגרף של $f$.
Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

Unit 4 is part of the course but is not assessed on the AP Precalculus Exam (which covers only Units 1–3); it builds tools used in later courses.

A parametric function 参数函数 describes a curve by giving both coordinates as functions of a third variable, the parameter 参数 $t$: $\big(x(t),\,y(t)\big)$. As $t$ runs through its domain, the point traces a path – and, unlike $y=f(x)$, the path may loop or cross itself.

עברית
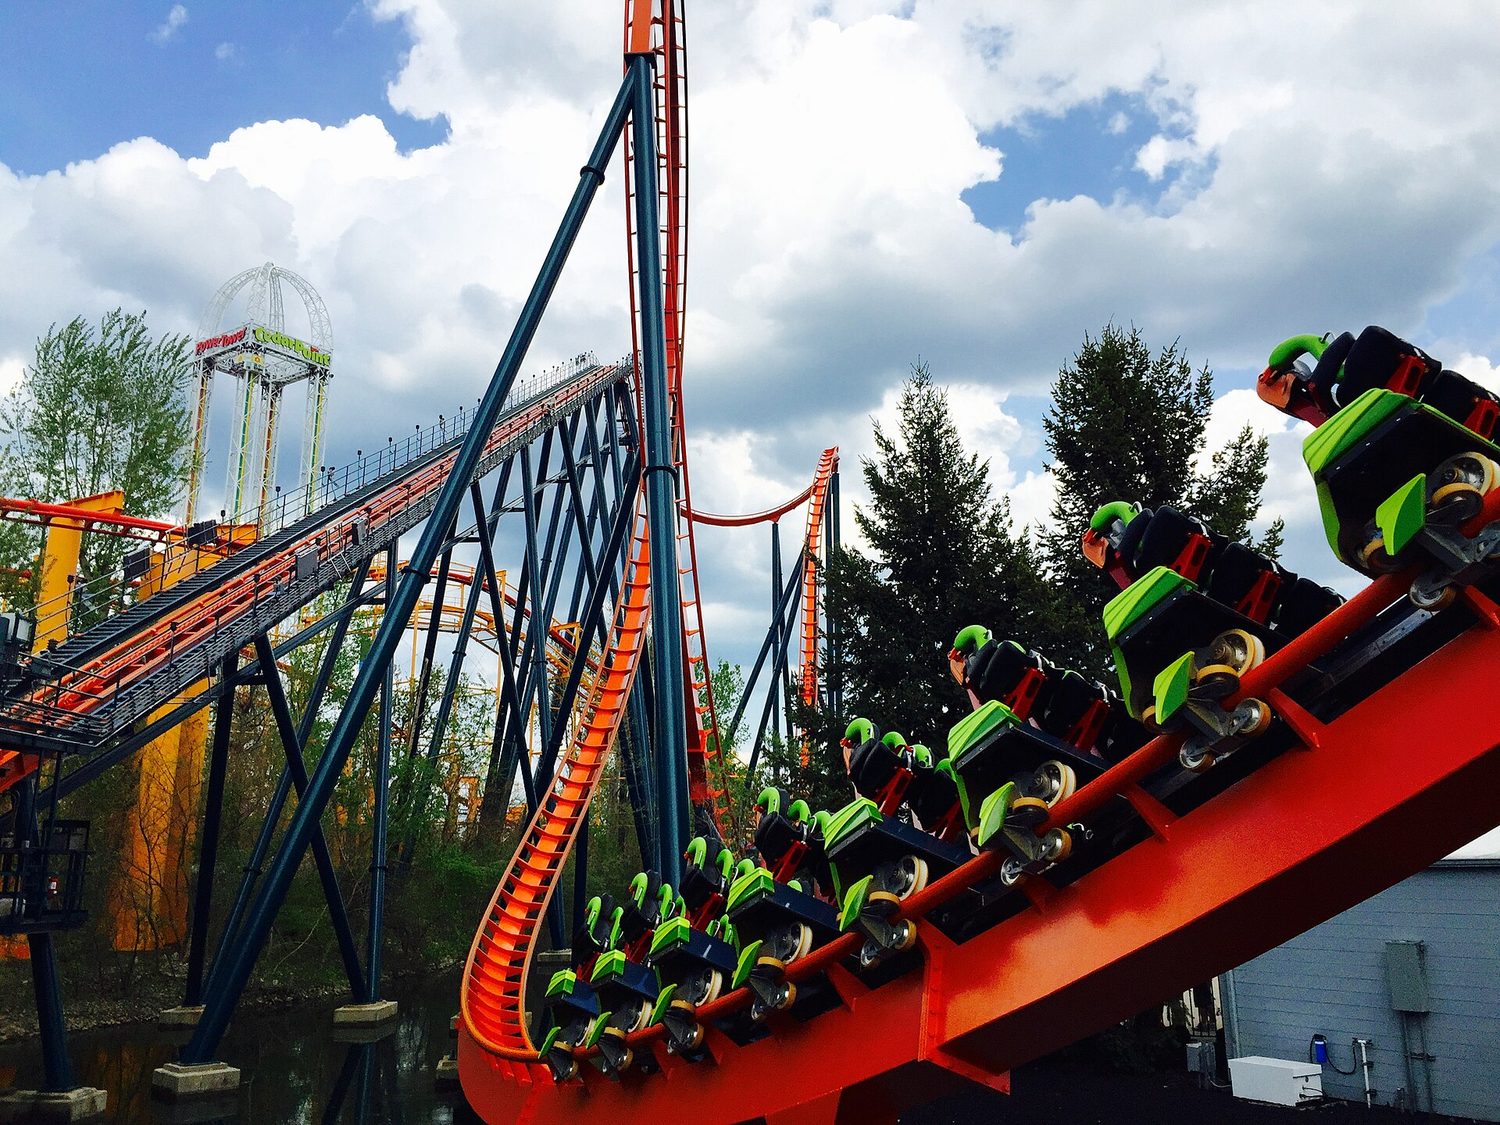
מסלול רכבת הרים: וקטורים ותנועה פרמטרית מתארים יחד את המסלול והמהירות

יחידה 4 היא חלק מהקורס אך אינה נבדקת במבחן AP Precalculus (המכסה רק יחידות 1–3); היא בונה כלים המשמשים בקורסים מאוחרים.

פונקציה פרמטרית מתארת עקומה על ידי מתן שני הקואורדינטות כפונקציות של משתנה שלישי, ה-פרמטר $t$: $\big(x(t),\,y(t)\big)$. כאשר $t$ עובר דרך תחום ההגדרה שלו, הנקודת צירת מסלול – ובניגוד ל$y=f(x)$, המסלול עשוי להיות מעוגל או לחתוך את עצמו.

Vocabulary · ⁨מילון מונחים⁩ Train · ⁨אימון⁩
English עברית
vector/ˈvektə/ מסיר מחלות
magnitude/ˈmæɡnɪtjuːd/ גודל
vector-valued function/ˈvektə ˈvæljuːd ˈfʌŋkʃn/ פונקציה בעלת ערך וקטורי
4.2

Parametric Functions and Planar Motion · ⁨פונקציות פרמטריות ותנועה במישור⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.2.A: Identify key characteristics of a parametric planar motion function that are related to position.

  • 4.2.A.1 A parametric function given by $f(t) = (x(t),\, y(t))$ can be used to model particle motion in the plane. The graph of this function indicates the position of a particle at time $t$.
  • 4.2.A.2 The horizontal and vertical extrema of a particle's motion can be determined by identifying the maximum and minimum values of the functions $x(t)$ and $y(t)$, respectively.
  • 4.2.A.3 The real zeros of the function $x(t)$ correspond to $y$-intercepts, and the real zeros of $y(t)$ correspond to $x$-intercepts.
עברית

מטרת הלמידה 4.2.A: זיהוי מאפיין מרכזיים של פונקציית תנועה פרמטרית במישור הקשורים למיקום.

  • 4.2.A.1 פונקציה פרמטרית נתונה על ידי $f(t) = (x(t),\, y(t))$ יכולה לשמש כדי לדמות תנועת חלקיק במישור. הגרף של פונקציה זו מראה את מיקום החלקיק בזמן $t$.
  • 4.2.A.2 האקסטרום האופקי והאנכי של תנועת חלקיק ניתן לקביעה על ידי זיהוי הערכים המקסימליים והמינימליים של הפונקציות $x(t)$ ו-$y(t)$ בהתאמה.
  • 4.2.A.3 האפסים הממשיים של הפונקציה $x(t)$ מתאימים לחיתוך עם ציר ⟨$y$⟩, והאפסים הממשיים של $y(t)$ מתאימים לחיתוך עם ציר ⟨$x$⟩.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

Reading $t$ as time, a parametric function models motion in the plane. $x(t)$ and $y(t)$ give the horizontal and vertical position; the point's direction of travel is the order in which the curve is drawn as $t$ increases (mark it with arrows).

עברית

כאשר קוראים את $t$ כ-זמן, פונקציה פרמטרית מדגמת תנועה במישור. $x(t)$ ו-$y(t)$ נותנים את המיקום האופקי והאנכי; הכיוון התנועה של הנקודה הוא הסדר שבו העקומה מצוירת כאשר $t$ גדל (סימן זאת בחצים).

4.3

Parametric Functions and Rates of Change · ⁨פונקציות פרמטריות וקצבי שינוי⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.3.A: Identify key characteristics of a parametric planar motion function that are related to direction and rate of change.

  • 4.3.A.1 As the parameter increases, the direction of planar motion of a particle can be analyzed in terms of $x$ and $y$ independently. If $x(t)$ is increasing or decreasing, the direction of motion is to the right or left, respectively. If $y(t)$ is increasing or decreasing, the direction of motion is up or down, respectively.
  • 4.3.A.2 At any given point in the plane, the direction of planar motion may be different for different values of $t$.
  • 4.3.A.3 The same curve in the plane can be parametrized in different ways and can be traversed in different directions with different parametric functions.
  • 4.3.A.4 Over a given interval $[t_1,\, t_2]$ within the domain, the average rate of change can be computed for $x(t)$ and $y(t)$ independently. The ratio of the average rate of change of $y$ to the average rate of change of $x$ gives the slope of the graph between the points on the curve corresponding to $t_1$ and $t_2$, so long as the average rate of change of $x(t) \neq 0$.
עברית

מטרת הלמידה 4.3.A: זיהוי מאפיין מרכזיים של פונקציית תנועה פרמטרית במישור הקשורים לכיוון ולקצב השינוי.

  • 4.3.A.1 ככל שהפרמטר גדל, ניתן לנתח את כיוון התנועה במישור של חלקיק בתלות ב-$x$ וב-$y$ בצורה עצמאית. אם $x(t)$ עולה או יורד, כיוון התנועה הוא ימינה או שמאלה בהתאמה. אם $y(t)$ עולה או יורד, כיוון התנועה הוא למעלה או למטה בהתאמה.
  • 4.3.A.2 בכל נקודה נתונה במישור, כיוון התנועה במישור עשוי להיות שונה עבור ערכים שונים של $t$.
  • 4.3.A.3 אותו עקומה במישור ניתן לפרמטריזציה בדרכים שונות, וניתן לעבור עליה בכיוונים שונים עם פונקציות פרמטריות שונות.
  • 4.3.A.4 על פני מרווח נתון $[t_1,\, t_2]$ בתחום ההגדרה, ניתן לחשב את קצב השינוי הממוצע עבור $x(t)$ ו-$y(t)$ בנפרד. היחס בין קצב השינוי הממוצע של $y$ לקצב השינוי הממוצע של $x$ נותן את שיפוע הגרף בין הנקודות על העקומה המתאימות ל-$t_1$ ול-$t_2$, כל עוד קצב השינוי הממוצע של $x(t) \neq 0$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

Over an interval of $t$, the average rate of change of $x$ is $\dfrac{\Delta x}{\Delta t}$ and of $y$ is $\dfrac{\Delta y}{\Delta t}$. Their signs tell you which way the point moves (right/left, up/down); together they describe the motion's speed and direction along the path.

עברית

על מרווח של $t$, קצב השינוי הממוצע של $x$ הוא $\dfrac{\Delta x}{\Delta t}$ ועל $y$ הוא $\dfrac{\Delta y}{\Delta t}$. הסימנים שלהם אומרים לאיזה כיוון הנקודה נעה (ימינה/שמאלה, למעלה/למטה); יחד הם מתארים את מהירות התנועה וכיוונה לאורך המסלול.

4.4

Parametrically Defined Circles and Lines · ⁨עיגולים וקווים מוגדרים פרמטרית⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.4.A: Express motion around a circle or along a line segment parametrically.

  • 4.4.A.1 A complete counterclockwise revolution around the unit circle that starts and ends at $(1,\, 0)$ and is centered at the origin can be modeled by $(x(t),\, y(t)) = (\cos t,\, \sin t)$ with domain $0 \leq t \leq 2\pi$.
  • 4.4.A.2 Transformations of the parametric function $(x(t),\, y(t)) = (\cos t,\, \sin t)$ can model any circular path traversed in the plane.
  • 4.4.A.3 A linear path along the line segment from the point $(x_1,\, y_1)$ to the point $(x_2,\, y_2)$ can be parametrized many ways, including using an initial position $(x_1,\, y_1)$ and rates of change for $x$ with respect to $t$ and $y$ with respect to $t$.
עברית

מטרת למידה 4.4.A: לבטא תנועה סביב מעגל או לאורך קטע ישר באופן פרמטרי.

  • 4.4.A.1 סיבוב מלא נגד כיוון השעון סביב המעגל היחידה שמתחיל ומסתיים ב-$(1,\, 0)$ וממוקם במרכז הצירים ניתן לדגם על ידי $(x(t),\, y(t)) = (\cos t,\, \sin t)$ עם תחום הגדרה $0 \leq t \leq 2\pi$.
  • 4.4.A.2 טרנספורמציות של הפונקציה הפרמטרית $(x(t),\, y(t)) = (\cos t,\, \sin t)$ יכולות לדגם כל מסלול עגול שעובר במישור.
  • 4.4.A.3 מסלול ליניני לאורך קטע הישר מהנקודה $(x_1,\, y_1)$ לנקודה $(x_2,\, y_2)$ ניתן להזדקן בדרכים רבות, כולל השימוש במיקום התחלתי $(x_1,\, y_1)$ ובקצבי שינוי עבור $x$ ביחס ל-$t$ ועבור $y$ ביחס ל-$t$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

A circle of radius $R$ centered at $(h,k)$ is $x=h+R\cos t,\ y=k+R\sin t$. A line through $(x_0,y_0)$ with direction $(a,b)$ is $x=x_0+at,\ y=y_0+bt$. Adjusting the coefficients changes the start point, speed, and direction of tracing.

עברית

עיגול ברדיוס $R$ שמרכזו ב-$(h,k)$ הוא $x=h+R\cos t,\ y=k+R\sin t$. קו העובר דרך $(x_0,y_0)$ עם כיוון $(a,b)$ הוא $x=x_0+at,\ y=y_0+bt$. התאמת המקדמים משנה את נקודת ההתחלה, המהירות וכיוון הציור.

4.5

Implicitly Defined Functions · ⁨פונקציות המוגדרות באופן גלוי⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.5.A: Construct a graph of an equation involving two variables.

  • 4.5.A.1 An equation involving two variables can implicitly describe one or more functions.
  • 4.5.A.2 An equation involving two variables can be graphed by finding solutions to the equation.
  • 4.5.A.3 Solving for one of the variables in an equation involving two variables can define a function whose graph is part or all of the graph of the equation.

Learning Objective 4.5.B: Determine how the two quantities related in an implicitly defined function vary together.

  • 4.5.B.1 For ordered pairs on the graph of an implicitly defined function that are close together, if the ratio of the change in the two variables is positive, then the two variables simultaneously increase or both decrease; conversely, if the ratio is negative, then as one variable increases, the other decreases.
  • 4.5.B.2 The rate of change of $x$ with respect to $y$ or of $y$ with respect to $x$ can be zero, indicating vertical or horizontal intervals, respectively.
עברית

מטרת למידה 4.5.A: לבנות גרף של משוואה הכוללת שני משתנים.

  • 4.5.A.1 משוואה הכוללת שני משתנים יכולה לתאר בפונקציות אינליציטיות אחת או יותר.
  • 4.5.A.2 ניתן לגרף משוואה הכוללת שני משתנים על ידי מציאת פתרונות למשוואה.
  • 4.5.A.3 פתרון אחד מהמשתנים במשוואה הכוללת שני משתנים יכול להגדיר פונקציה שהגרף שלה הוא חלק או כולו בגרף של המשוואה.

מטרת למידה 4.5.B: לקבוע כיצד שתי הכמויות הקשורות בפונקציה המוגדרת אינליציטית משתנות יחד.

  • 4.5.B.1 עבור זוגות מסודרים על גרף של פונקציה המוגדרת אינליציטית הקרובים זה לזה, אם היחס בין השינוי בשני המשתנים הוא חיובי, אזי שני המשתנים גדלים בו-זמנית או שניהם קטנים; להפך, אם היחס שלילי, אזי כאשר משתנה אחד גדל, השני קטן.
  • 4.5.B.2 קצב השינוי של $x$ ביחס ל-$y$ או של $y$ ביחס ל-$x$ יכול להיות אפס, מה שמעיד על מקטעים אנכיים או אופקיים בהתאמה.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

An implicit 隐式 equation relates $x$ and $y$ without solving for either, such as $x^2+y^2=25$. Its graph may fail the vertical-line test (not a function), so it is often split into pieces or described parametrically.

עברית

משוואה גלויה מקשרת בין $x$ ל-$y$ ללא פתרון עבור אחת מהן, כמו $x^2+y^2=25$. הגרף שלה עשוי שלא לעמוד במבחן הקו האנכי (ולכן אינו פונקציה), ולכן לעיתים קרובות מחולק לחלקים או מתואר פרמטרית.

4.6

Conic Sections · ⁨חתכי קונוס⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.6.A: Represent conic sections with horizontal or vertical symmetry analytically.

  • 4.6.A.1 A parabola with vertex $(h,\, k)$ can, if $a \neq 0$, be represented analytically as $x - h = a(y - k)^2$ if it opens left or right, or as $y - k = a(x - h)^2$ if it opens up or down.
  • 4.6.A.2 An ellipse centered at $(h,\, k)$ with horizontal radius $a$ and vertical radius $b$ can be represented analytically as $\dfrac{(x - h)^2}{a^2} + \dfrac{(y - k)^2}{b^2} = 1$. A circle is a special case of an ellipse where $a = b$.
  • 4.6.A.3 A hyperbola centered at $(h,\, k)$ with vertical and horizonal lines of symmetry can be represented algebraically as $\dfrac{(x - h)^2}{a^2} - \dfrac{(y - k)^2}{b^2} = 1$ for a hyperbola opening left and right, or as $\dfrac{(y - k)^2}{b^2} - \dfrac{(x - h)^2}{a^2} = 1$ for a hyperbola opening up and down. The asymptotes are $y - k = \pm \dfrac{b}{a}(x - h)$.
עברית

מטרת למידה 4.6.A: לייצג קטעי חרוט בעל סימטריה אופקית או אנכית באופן אנליטי.

  • 4.6.A.1 פרבולה עם קודקוד $(h,\, k)$ יכולה, אם $a \neq 0$, להיות מיוצגת אנליטית כ-$x - h = a(y - k)^2$ אם היא נפתחת שמאלה או ימינה, או כ-$y - k = a(x - h)^2$ אם היא נפתחת למעלה או למטה.
  • 4.6.A.2 אלipse ממוקמת במרכז $(h,\, k)$ עם רדיוס אופקי $a$ ורדיו אנכי $b$ יכולה להתבטא אנליטית כ-$\dfrac{(x - h)^2}{a^2} + \dfrac{(y - k)^2}{b^2} = 1$. עיגול הוא מקרה פרטי של אלipse כאשר $a = b$.
  • 4.6.A.3 היפרבולה הממוקמת ב-$(h,\, k)$ עם צירי סימטריה אנכיים ואופקיים יכולה להיות מיוצגת אלגברית כ-$\dfrac{(x - h)^2}{a^2} - \dfrac{(y - k)^2}{b^2} = 1$ עבור היפרבולה הנפתחת שמאלה וימינה, או כ-$\dfrac{(y - k)^2}{b^2} - \dfrac{(x - h)^2}{a^2} = 1$ עבור היפרבולה הנפתחת למעלה ולמטה. האסימפטוטות הן $y - k = \pm \dfrac{b}{a}(x - h)$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English
Conic sections: one cone, four curves

Conic sections 圆锥曲线 – circles, ellipses, parabolas, and hyperbolas – are the curves from slicing a cone, each given by a quadratic equation in $x$ and $y$. Their standard forms reveal centers, vertices, axes, and asymptotes.

עברית
חתכי קונוס: קונוס אחד, ארבע עקומות

חתכי קונוס – עיגולים, אלipses, פרבולות והיפרבולות – הם העקומות שנוצרות מחיתוך קונוס, כל אחת נתונה על ידי משוואה ריבועית ב-$x$ ו-$y$. הצורות הסטנדרטיות שלהם חושפות מרכזים, קודקודים, צירים ואסימפטוטות.

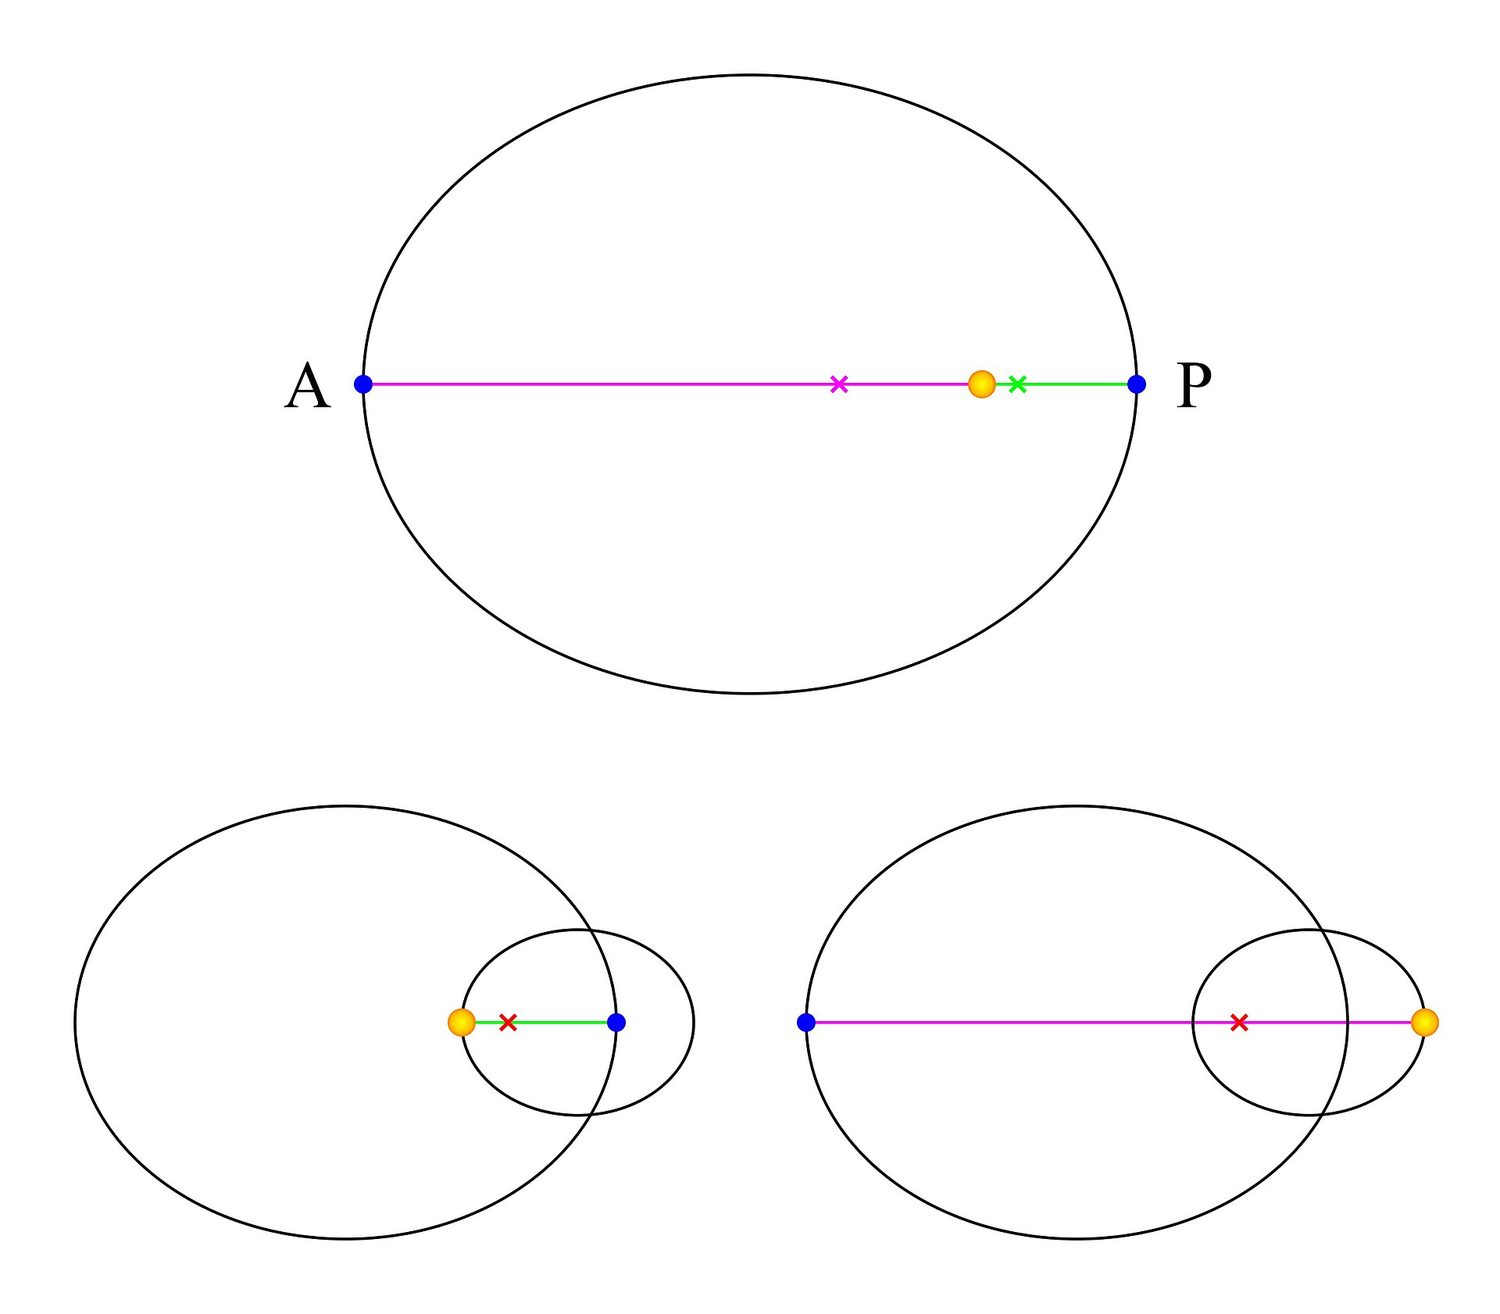
מסילות אליפטיות: חתכי קונוס מתארים מסילות סגורות עם שני מוקדים – מודל פרמטרי מרכזי
מסלולים אליפטיים: חתכי קונוס מתארים מסלולים סגורים עם שני מוקדים — מודל פרמטרי מרכזי
Vocabulary · ⁨מילון מונחים⁩ Train · ⁨אימון⁩
English עברית
parametric function/ˌpærəˈmetrɪk ˈfʌŋkʃn/ פונקציה פרמטרית
parameter/pəˈræmɪtə/ פרמטר
implicit/ɪmˈplɪsɪt/ אינפלסיטי
Conic sections/ˈkɒnɪk ˈsekʃnz/ חצאי-קונות
4.7

Parametrizing Implicit Curves · ⁨פרמטרization של עקומות גלויות⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.7.A: Represent a curve in the plane parametrically.

  • 4.7.A.1 A parametrization $(x(t),\, y(t))$ for an implicitly defined function will, when $x(t)$ and $y(t)$ are substituted for $x$ and $y$, respectively, satisfy the corresponding equation for every value of $t$ in the domain.
  • 4.7.A.2 If $f$ is a function of $x$, then $y = f(x)$ can be parametrized as $(x(t),\, y(t)) = (t, f(t))$. If $f$ is invertible, its inverse can be parametrized as $(x(t),\, y(t)) = (f(t),\, t)$ for an appropriate interval of $t$.

Learning Objective 4.7.B: Represent conic sections parametrically.

  • 4.7.B.1 A parabola can be parametrized in the same way that any equation that can be solved for $x$ or $y$ can be parametrized. Equations that can be solved for $x$ can be parametrized as $(x(t),\, y(t)) = (f(t),\, t)$ by solving for $x$ and replacing $y$ with $t$. Equations that can be solved for $y$ can be parametrized as $(x(t),\, y(t)) = (t, f(t))$ by solving for $y$ and replacing $x$ with $t$.
  • 4.7.B.2 An ellipse can be parametrized using the trigonometric functions $x(t) = h + a\cos t$ and $y(t) = k + b\sin t$ for $0 \leq t \leq 2\pi$.
  • 4.7.B.3 A hyperbola can be parametrized using trigonometric functions. For a hyperbola that opens left and right, the functions are $x(t) = h + a\sec t$ and $y(t) = k + b\tan t$ for $0 \leq t \leq 2\pi$. For a hyperbola that opens up and down, the functions are $x(t) = h + a\tan t$ and $y(t) = k + b\sec t$ for $0 \leq t \leq 2\pi$.
עברית

מטרת הלמידה 4.7.A: נציג עקומה במישור באופן פרמטרי.

  • 4.7.A.1 פאראמיטרציה $(x(t),\, y(t))$ לפונקציה המוגדרת אי-אקספליסיטית תענה, כאשר $x(t)$ ו$y(t)$ מוחלפים ב$x$ וב$y$ בהתאמה, במשוואה המתאימה עבור כל ערך של $t$ בתחום ההגדרה.
  • 4.7.A.2 אם $f$ היא פונקציה של $x$, אזי ניתן לפארמיטר את $y = f(x)$ כ$(x(t),\, y(t)) = (t, f(t))$. אם $f$ מתהפכת, ניתן לפארמיטר את ההתהפכות שלה כ$(x(t),\, y(t)) = (f(t),\, t)$ עבור טווח מתאים של $t$.

מטרת הלמידה 4.7.B: נציג חתכי קonus באופן פרמטרי.

  • 4.7.B.1 פרבולה ניתן לפארמיטר באותו אופן כמו כל משוואה שניתן לפתור עבורה ל$x$ או ל$y$. משוואות שניתן לפתור עבורה ל$x$ ניתן לפארמיטר כ$(x(t),\, y(t)) = (f(t),\, t)$ על ידי פתרון עבור$x$ והחלפת $y$ ב$t$. משוואות שניתן לפתור עבורה ל$y$ ניתן לפארמיטר כ$(x(t),\, y(t)) = (t, f(t))$ על ידי פתרון עבור$y$ והחלפת $x$ ב$t$.
  • 4.7.B.2 אלipse ניתן לפארמיטר באמצעות הפונקציות הטריגונומטריות $x(t) = h + a\cos t$ ו$y(t) = k + b\sin t$ עבור$0 \leq t \leq 2\pi$.
  • 4.7.B.3 היפרבולה ניתן לפארמיטר באמצעות פונקציות טריגונומטריות. עבור היפרבולה הנפתחת ימינה ושמאלה, הפונקציות הן $x(t) = h + a\sec t$ ו$y(t) = k + b\tan t$ עבור$0 \leq t \leq 2\pi$. עבור היפרבולה הנפתחת למעלה ולמטה, הפונקציות הן $x(t) = h + a\tan t$ ו$y(t) = k + b\sec t$ עבור$0 \leq t \leq 2\pi$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

Many implicit curves can be parametrized – rewritten as $\big(x(t),y(t)\big)$ – which makes them easier to graph and to treat as motion. The circle above is the basic example; ellipses use $x=h+A\cos t,\ y=k+B\sin t$.

עברית

מספר עקומות גלויות יכולות להיות פרמטרized – מוכנות מחדש כ$\big(x(t),y(t)\big)$ – מה שהופך אותן לקלות יותר לגרף ולטיפול בתנועה. העיגול למעלה הוא הדוגמה הבסיסית; אלipses משתמשות ב$x=h+A\cos t,\ y=k+B\sin t$.

4.8

Vectors · ⁨וקטורים⁩

Syllabus · ⁨סיילבוס⁩
Learning ObjectiveEssential Knowledge

4.8.A
Identify characteristics of a vector.

  • 4.8.A.1 A vector is a directed line segment. When a vector is placed in the plane, the point at the beginning of the line segment is called the tail, and the point at the end of the line segment is called the head. The length of the line segment is the magnitude of the vector.
  • 4.8.A.2 A vector $\overrightarrow{P_1 P_2}$ with two components can be plotted in the $xy$-plane from $P_1 = (x_1, y_1)$ to $P_2 = (x_2, y_2)$. The vector is identified by $a$ and $b$, where $a = x_2 - x_1$ and $b = y_2 - y_1$. The vector can be expressed as $\langle a,\, b \rangle$. A zero vector $\langle 0,\, 0 \rangle$ is the trivial case when $P_1 = P_2$.
  • 4.8.A.3 The direction of the vector is parallel to the line segment from the origin to the point with coordinates $(a,\, b)$. The magnitude of the vector is the square root of the sum of the squares of the components.
  • 4.8.A.4 For a vector represented geometrically in the plane, the components of the vector can be found using trigonometry.

4.8.B
Determine sums and products involving vectors.

  • 4.8.B.1 The multiplication of a constant and a vector results in a new vector whose components are found by multiplying the constant by each of the components of the original vector. The new vector is parallel to the original vector.
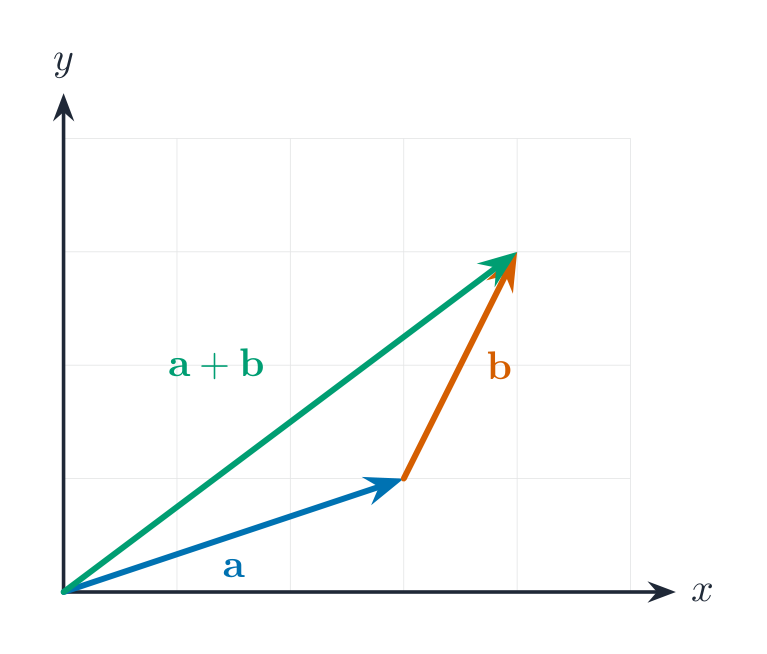
  • 4.8.B.2 The sum of two vectors in $\mathbb{R}^2$ is a new vector whose components are found by adding the corresponding components of the original vectors. The new vector can be represented graphically as a vector whose tail corresponds to the tail of the first vector and whose head corresponds to the head of the second vector when the second vector's tail is located at the first vector's head.
  • 4.8.B.3 The dot product of two vectors is the sum of the products of their corresponding components. That is, $\langle a_1,\, b_1 \rangle \cdot \langle a_2,\, b_2 \rangle = a_1 a_2 + b_1 b_2$.

4.8.C
Determine a unit vector for a given vector.

  • 4.8.C.1 A unit vector is a vector of magnitude $1$. A unit vector in the same direction as a given nonzero vector can be found by scalar multiplying the vector by the reciprocal of its magnitude.
  • 4.8.C.2 The vector $\langle a,\, b \rangle$ can be expressed as $a\vec{i} + b\vec{j}$ in $\mathbb{R}^2$, where $\vec{i}$ and $\vec{j}$ are unit vectors in the $x$ and $y$ directions, respectively. That is, $\vec{i} = \langle 1,\, 0 \rangle$ and $\vec{j} = \langle 0,\, 1 \rangle$.

4.8.D
Determine angle measures between vectors and magnitudes of vectors involved in vector addition.

  • 4.8.D.1 The dot product is geometrically equivalent to the product of the magnitudes of the two vectors and the cosine of the angle between them. Therefore, if the dot product of two nonzero vectors is zero, then the vectors are perpendicular.
  • 4.8.D.2 The Law of Sines and Law of Cosines can be used to determine side lengths and angle measures of triangles formed by vector addition.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English
Resolving a vector into components

A vector 向量 has both magnitude 大小 (length) and direction. Write it by components $\langle a,b\rangle$. Add vectors component-by-component; scale by multiplying each component; the magnitude is $\sqrt{a^2+b^2}$. Vectors model displacements, velocities, and forces.

עברית
פירוק וקטור למרכיבים

וקטור הוא גודל פיזיקלי בעל גם גודל (אורך) וגם כיוון. כותבים אותו באמצעות רכיבים $\langle a,b\rangle$. מחברים וקטורים רכיב-ברכיב; מכפילים בקנה מידה על ידי הכפלת כל רכיב; הגודל הוא $\sqrt{a^2+b^2}$. וקטורים מדגימים הזזות, מהירויות וכוחות.

חיבור וקטורים לפי חוק המשולש
Explore · ⁨חקור⁩

Add two vectors tip to tail · ⁨חבר שני וקטורים קצה-לקצה⁩

A vector has magnitude and direction. Adding two vectors places them tip to tail; the resultant runs from the first tail to the last tip. Drag each to see the sum. · ⁨וקטור יש לו גודל וכיוון. חיבור שני וקטורים מניח אותם ראש-עקב; הווקטור השקול רץ מהעקב הראשון עד לראש האחרון. גרור כל אחד כדי לראות את הסכום.⁩

4.9

Vector-Valued Functions · ⁨פונקציות בעלות ערך וקטורי⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.9.A: Represent planar motion in terms of vector-valued functions.

  • 4.9.A.1 The position of a particle moving in a plane that is given by the parametric function $f(t) = (x(t),\, y(t))$ may be expressed as a vector-valued function, $p(t) = x(t)\vec{i} + y(t)\vec{j}$ or $p(t) = \langle x(t),\, y(t) \rangle$. The magnitude of the position vector at time $t$ gives the distance of the particle from the origin.
  • 4.9.A.2 The vector-valued function $v(t) = \langle x(t),\, y(t) \rangle$ can be used to express the velocity of a particle moving in a plane at different times, $t$. At time $t$, the sign of $x(t)$ indicates if the particle is moving right or left, and the sign of $y(t)$ indicates if the particle is moving up or down. The magnitude of the velocity vector at time $t$ gives the speed of the particle.
עברית

מטרות למידה 4.9.A: ייצוג תנועה במישור באמצעות פונקציות בעלות ערך וקטורי.

  • 4.9.A.1 מיקום חלקיק הנע במישור והנתון על ידי הפונקציה הפרמטרית $f(t) = (x(t),\, y(t))$ יכול להיות מיוצג כפונקציה בעלת ערך וקטורי, $p(t) = x(t)\vec{i} + y(t)\vec{j}$ או $p(t) = \langle x(t),\, y(t) \rangle$. הגודל של וקטור המיקום בזמן $t$ נותן את המרחק מהחלקיק למקור.
  • 4.9.A.2 הפונקציה בעלת הערך הוקטורי $v(t) = \langle x(t),\, y(t) \rangle$ יכולה לשמש ליצוג מהירות החלקיק הנע במישור בזמנים שונים, $t$. בזמן $t$, סימן ה-$x(t)$ מצביע אם החלקיק נע מימינה או משמאלו, וסימן ה-$y(t)$ מצביע אם החלקיק נע למעלה או למטה. הגודל של וקטור המהירות בזמן $t$ נותן את המהירות (השגב) של החלקיק.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

A vector-valued function 向量值函数 outputs a vector for each input, e.g. $\vec{r}(t)=\langle x(t),y(t)\rangle$ – the same information as a parametric function, packaged as a moving position vector.

עברית

פונקציה בעלת ערך וקטורי מחזירה וקטור עבור כל כניסה, לדוגמה $\vec{r}(t)=\langle x(t),y(t)\rangle$ – אותה מידע כמו בפונקציה פרמטרית, ארוז בתוך וקטור מיקום נע.

קו בעל ערך וקטורי: התחילו ב-a, ולאחר מכן החלקו לפי t רבות בכיוון b
4.10

Matrices · ⁨מטריצות⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.10.A: Determine the product of two matrices.

  • 4.10.A.1 An $n \times m$ matrix is an array consisting of $n$ rows and $m$ columns.
  • 4.10.A.2 Two matrices can be multiplied if the number of columns in the first matrix equals the number of rows in the second matrix. The product of the matrices is a new matrix in which the component in the $i$th row and $j$th column is the dot product of the $i$th row of the first matrix and the $j$th column of the second matrix.
עברית

מטרת הלמידה 4.10.A: לחשב את המכפלה של שתי מטריצות.

  • 4.10.A.1 מטריצה $n \times m$ היא מערך המורכב מ$n$ שורות ו$m$ עמודות.
  • 4.10.A.2 ניתן להכפיל שתי מטריצות רק אם מספר העמודות במטריצה הראשונה שווה למספר השורות במטריצה השנייה. המכפלה של המטריצות היא מטריצה חדשה שבה רכיב בשורה ה$i$ ועמודה ה$j$ הוא מכפלת נקודתית של השורה ה$i$ של המטריצה הראשונה ועמודת ה$j$ של המטריצה השנייה.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

A matrix 矩阵 is a rectangular array of numbers. Add matrices of the same size entry-by-entry; multiply a matrix by a compatible one by combining rows with columns. Matrices store and transform data compactly.

עברית

מטריצה היא מערך מלבני של מספרים. מוסיפים מטריצות באותו גודל מרכיב-מרכיב; מכפילים מטריצה במטריצה תואמת על ידי שילוב שורות עם עמודות. מטריצות מאחסנות ומטרת נתונים בצורה דחוסה.

4.11

The Inverse and Determinant of a Matrix · ⁨ההופך והדיסקרימיננט של מטריצה⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.11.A: Determine the inverse of a $2 \times 2$ matrix.

  • 4.11.A.1 The identity matrix, $I$, is a square matrix consisting of $1$s on the diagonal from the top left to bottom right and $0$s everywhere else.
  • 4.11.A.2 Multiplying a square matrix by its corresponding identity matrix results in the original square matrix.
  • 4.11.A.3 The product of a square matrix and its inverse, when it exists, is the identity matrix of the same size.
  • 4.11.A.4 The inverse of a $2 \times 2$ matrix, when it exists, can be calculated with or without technology.

Learning Objective 4.11.B: Apply the value of the determinant to invertibility and vectors.

  • 4.11.B.1 The determinant of the matrix $A = \begin{bmatrix} a & b \\ c & d \end{bmatrix}$ is $ad - bc$. The determinant can be calculated with or without technology and is denoted $\det(A)$.
  • 4.11.B.2 If a $2 \times 2$ matrix consists of two column or row vectors from $\mathbb{R}^2$, then the nonzero absolute value of the determinant of the matrix is the area of the parallelogram spanned by the vectors represented in the columns or rows of the matrix. If the determinant equals $0$, then the vectors are parallel.
  • 4.11.B.3 The square matrix $A$ has an inverse if and only if $\det(A) \neq 0$.
עברית

מטרת הלמידה 4.11.A: לחשב את ההפוך של מטריצה $2 \times 2$.

  • 4.11.A.1 המטריצה היחידה, $I$, היא מטריצה ריבועית המורכבת מ-$1$ים באלכסון משמאל למעלה לימין למטה ומ-$0$ים בכל מקום אחר.
  • 4.11.A.2 הכפלת מטריצה ריבועית במטריצת היחידה המתאימה אליה מניבה את המטריצה הריבועית המקורית.
  • 4.11.A.3 מכפלת מטריצה ריבועית בהפוכה שלה, כאשר זו קיימת, היא מטריצת היחידה באותו גודל.
  • 4.11.A.4 ההפוך של מטריצה $2 \times 2$, כאשר הוא קיים, ניתן לחישוב עם או ללא שימוש בטכנולוגיה.

מטרת למידה 4.11.B: יישום ערך הדטרמיננטה לקיימות הפיכה ולווקטורים.

  • 4.11.B.1 הדטרמיננטה של המטריצה $A = \begin{bmatrix} a & b \\ c & d \end{bmatrix}$ היא $ad - bc$. ניתן לחשב את הדטרמיננטה עם או ללא שימוש בטכנולוגיה, והיא מסומנת ב$\det(A)$.
  • 4.11.B.2 אם מטריצה $2 \times 2$ מורכבת משני וקטורי עמודים או שורות מהמרחב $\mathbb{R}^2$, אזי הערך המוחלט הלא-אפסי של הדטרמיננטה שלה הוא השטח של המקבילית הנמתחת על ידי הווקטורים המיוצגים בעמודים או בשורות המטריצה. אם הדטרמיננטה שווה ל$0$, אזי הווקטורים מקבילים.
  • 4.11.B.3 המטריצה המרובעת $A$ בעלת הפיכה אם ורק אם $\det(A) \neq 0$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

The determinant 行列式 of a $2\times 2$ matrix $\begin{bmatrix} a & b \\ c & d\end{bmatrix}$ is $ad-bc$. A matrix has an inverse 逆矩阵 exactly when its determinant is nonzero; the inverse undoes the matrix, and it solves matrix equations (like a reciprocal for numbers).

Worked example. For $A=\begin{bmatrix}3 & 1\\ 2 & 4\end{bmatrix}$, the determinant is $ad-bc=(3)(4)-(1)(2)=10$. Since it is nonzero, $A$ is invertible, and $A^{-1}=\dfrac{1}{10}\begin{bmatrix}4 & -1\\ -2 & 3\end{bmatrix}$ (swap the diagonal, negate the off-diagonal, divide by the determinant).

עברית

הדיסקרימיננט של מטריצה $2\times 2$ $\begin{bmatrix} a & b \\ c & d\end{bmatrix}$ הוא $ad-bc$. למטריצה יש הופך אם ורק אם הדיסקרימיננט שלה אינו אפס; ההופך מבטל את פעולת המטריצה, ופתרן משוואות מטריציות (כמו היפוך למספרים).

דוגמה מפורטת. עבור $A=\begin{bmatrix}3 & 1\\ 2 & 4\end{bmatrix}$, הדיסקרימיננט היא $ad-bc=(3)(4)-(1)(2)=10$. מכיוון שהיא אינה אפס, $A$ מתהפכת, ועל כך $A^{-1}=\dfrac{1}{10}\begin{bmatrix}4 & -1\\ -2 & 3\end{bmatrix}$ (להחליף את האלמנטים באלכסון הראשי, לשנות סימן לאלמנטים שאינם באלכסון, ולחלק בדיסקרימיננט).

Vocabulary · ⁨מילון מונחים⁩ Train · ⁨אימון⁩
English עברית
matrix/ˈmeɪtrɪks/ מטריצה
determinant/dɪˈtɜːmɪnənt/ קובעת
inverse/ɪnˈvɜːs/ הפוך
linear transformation/ˈlɪnɪə trænsfɔːˈmeɪʃn/ טרנספורמציה ליניארית
4.12

Linear Transformations and Matrices · ⁨טרנספורמציות ליניאריות ומטריצות⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.12.A: Determine the output vectors of a linear transformation using a $2 \times 2$ matrix.

  • 4.12.A.1 A linear transformation is a function that maps an input vector to an output vector such that each component of the output vector is the sum of constant multiples of the input vector components.
  • 4.12.A.2 A linear transformation will map the zero vector to the zero vector.
  • 4.12.A.3 A single vector in $\mathbb{R}^2$ can be expressed as a $2 \times 1$ matrix. A set of $n$ vectors in $\mathbb{R}^2$ can be expressed as a $2 \times n$ matrix.
  • 4.12.A.4 For a linear transformation, $L$, from $\mathbb{R}^2$ to $\mathbb{R}^2$, there is a unique $2 \times 2$ matrix, $A$, such that $L(\vec{v}) = A\vec{v}$ for vectors in $\mathbb{R}^2$. Conversely, for a given $2 \times 2$ matrix, $A$, the function $L(\vec{v}) = A\vec{v}$ is a linear transformation from $\mathbb{R}^2$ to $\mathbb{R}^2$.
  • 4.12.A.5 Multiplication of a $2 \times 2$ transformation matrix, $A$, and a $2 \times n$ matrix of $n$ input vectors gives a $2 \times n$ matrix of the $n$ output vectors for the linear transformation $L(\vec{v}) = A\vec{v}$.
עברית

מטרת למידה 4.12.A: קביעת וקטורי היציאה של טרנספורמציה ליניארית באמצעות מטריצה $2 \times 2$.

  • 4.12.A.1 טרנספורמציה ליניארית היא פונקציה הממפה וקטור כניסה לוקטור יציאה כך שכל רכיב של וקטור היציאה הוא סכום של מכפלים קבועים של רכיבי וקטור הכניסה.
  • 4.12.A.2 טרנספורמציה ליניארית תמפה את הווקטור האפס לוקטור האפס.
  • 4.12.A.3 וקטור יחיד במרחב $\mathbb{R}^2$ יכול להיות בלשון מטריצה בגודל $2 \times 1$. קבוצה של $n$ וקטורים במרחב $\mathbb{R}^2$ יכולה להיות בלשון מטריצה בגודל $2 \times n$.
  • 4.12.A.4 עבור טרנספורמציה ליניארית $L$, מהמרחב $\mathbb{R}^2$ למרחב $\mathbb{R}^2$, קיימת מטריצה יחידה, $2 \times 2$, מסומנת ב$A$, כך ש$L(\vec{v}) = A\vec{v}$ עבור וקטורים במרחב $\mathbb{R}^2$. להפך, עבור מטריצה נתונה, $2 \times 2$, מסומנת ב$A$, הפונקציה $L(\vec{v}) = A\vec{v}$ היא טרנספורמציה ליניארית מהמרחב $\mathbb{R}^2$ למרחב $\mathbb{R}^2$.
  • 4.12.A.5 כפל של מטריצת המרת $2 \times 2$, $A$, ומטריצת ⟨$2 \times n$⟩ של ⟨$n$⟩ וקטורי קלט נותן מטריצת ⟨$2 \times n$⟩ של ⟨$n$⟩ וקטורי הפלט עבור ההמרה הליניארית $L(\vec{v}) = A\vec{v}$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English
A matrix transforms the plane

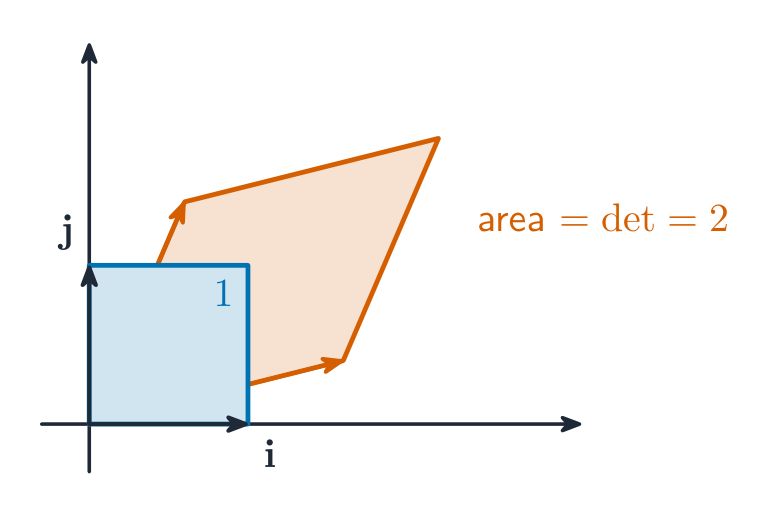
A $2\times 2$ matrix acts as a linear transformation 线性变换 of the plane – rotating, reflecting, stretching, or shearing points – by multiplying each position vector. The determinant measures how the transformation scales area (and its sign tells whether orientation flips).

Worked example. The matrix $\begin{bmatrix}2 & 0\\ 0 & 3\end{bmatrix}$ stretches the plane by $2$ horizontally and $3$ vertically, sending the vector $\begin{bmatrix}1\\1\end{bmatrix}$ to $\begin{bmatrix}2\\3\end{bmatrix}$. Its determinant $2\times3=6$ means every area is multiplied by $6$, so the unit square becomes a $2\times3$ rectangle.

עברית
מטריצה מטרת את המישור

מטריצה $2\times 2$ פועלת כטרנספורמציה ליניארית של המישור – סיבוב, השתקפות, מתיחה או גזירה של נקודות – על ידי הכפלת כל וקטור מיקום. הדיסקרימיננט מדדת כיצד הטרנספורמציה משנה את גודל השטח (והסימן שלה מצביע אם הכיוון משתנה).

דוגמה מפורטת. המטריצה $\begin{bmatrix}2 & 0\\ 0 & 3\end{bmatrix}$ מתיחה את המישור פי $2$ אופקית ופי $3$ אנכית, ומשדרת את הוקטור $\begin{bmatrix}1\\1\end{bmatrix}$ ל$\begin{bmatrix}2\\3\end{bmatrix}$. הדיסקרימיננט שלה $2\times3=6$ אומרת שכל שטח יוכפל ב$6$, ולכן ריבוע היחידה הופך למלבן $2\times3$.

מטריצה 2x2 מטרת ריבוע יחידה לצבוער; הדיסקרימיננט היא מקדם הקנה-מידה של השטח
Explore · ⁨חקור⁩

Transform the plane with a matrix · ⁨מרתק את המישור עם מטריצה⁩

A $2\times2$ matrix maps every point to a new one, so it stretches, rotates or shears the whole grid. Change the entries and watch the unit square transform. · ⁨מטריצה $2\times2$ ממפה כל נקודה לנקודה חדשה, ולכן מתיחה, מסובבת או מעוותת את כל הרשת. שנו את הערכים וצפו בשינוי הריבוע היחיד.⁩

4.13

Matrices as Functions · ⁨מטריצות כפונקציות⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.13.A: Determine the association between a linear transformation and a matrix.

  • 4.13.A.1 The linear transformation mapping $\langle x,\, y \rangle$ to $\langle a_{11} x + a_{12} y,\, a_{21} x + a_{22} y \rangle$ is associated with the matrix $\begin{bmatrix} a_{11} & a_{12} \\ a_{21} & a_{22} \end{bmatrix}$.
  • 4.13.A.2 The mapping of the unit vectors in a linear transformation provides valuable information for determining the associated matrix.
  • 4.13.A.3 The matrix $\begin{bmatrix} \cos\theta & -\sin\theta \\ \sin\theta & \cos\theta \end{bmatrix}$ is associated with a linear transformation of vectors that rotates every vector an angle $\theta$ counterclockwise about the origin.
  • 4.13.A.4 The absolute value of the determinant of a $2 \times 2$ transformation matrix gives the magnitude of the dilation of regions in $\mathbb{R}^2$ under the transformation.

Learning Objective 4.13.B: Determine the composition of two linear transformations.

  • 4.13.B.1 The composition of two linear transformations is a linear transformation.
  • 4.13.B.2 The matrix associated with the composition of two linear transformations is the product of the matrices associated with each linear transformation.

Learning Objective 4.13.C: Determine the inverse of a linear transformation.

  • 4.13.C.1 Two linear transformations are inverses if their composition maps any vector to itself.
  • 4.13.C.2 If a linear transformation, $L$, is given by $L(\vec{v}) = A\vec{v}$, then its inverse transformation is given by $L^{-1}(\vec{v}) = A^{-1}\vec{v}$, where $A^{-1}$ is the inverse of the matrix $A$.
עברית

מטרת למידה 4.13.A: קביעת הקשר בין טרנספורמציה ליניארית למטריצה.

  • 4.13.A.1 ההמרה הליניארית המקשרת ⟨$\langle x,\, y \rangle$⟩ ל$\langle a_{11} x + a_{12} y,\, a_{21} x + a_{22} y \rangle$ מקושרת למטריצה $\begin{bmatrix} a_{11} & a_{12} \\ a_{21} & a_{22} \end{bmatrix}$.
  • 4.13.A.2 המיפוי של וקטורי היחיד בטרנספורמציה ליניארית מספק מידע חשוב לקביעת המטריצה הקשורה.
  • 4.13.A.3 המטריצה $\begin{bmatrix} \cos\theta & -\sin\theta \\ \sin\theta & \cos\theta \end{bmatrix}$ קשורה לטרנספורמציה ליניארית של וקטורים שמסובבת כל וקטור בזווית $\theta$ נגד כיוון השעון סביב הראשית.
  • 4.13.A.4 הערך המוחלט של הדטרמיננטה של מטריצת טרנספורמציה $2 \times 2$ נותן את גודל ההתפשטות (dilation) של אזורות במרחב $\mathbb{R}^2$ תחת הטרנספורמציה.

מטרת למידה 4.13.B: קביעת הרכבה של שתי טרנספורמציות ליניאריות.

  • 4.13.B.1 הרכבה של שתי טרנספורמציות ליניאריות היא טרנספורמציה ליניארית.
  • 4.13.B.2 המטריצה הקשורה להרכבה של שתי טרנספורמציות ליניאריות היא מכפלת המטריצות הקשורות לכל טרנספורמציה ליניארית.

מטרת הלמידה 4.13.C: מציאת ההופך של טרנספורמציה ליניארית.

  • 4.13.C.1 שתי טרנספורמציות ליניאריות הן הופכות זו לזו אם ההרכבה שלהן מפתחת כל וקטור לעצמו.
  • 4.13.C.2 אם טרנספורמציה ליניארית, $L$, נתונה על ידי $L(\vec{v}) = A\vec{v}$, אזי הטרנספורמציה ההופכת שלה נתונה על ידי $L^{-1}(\vec{v}) = A^{-1}\vec{v}$, כאשר $A^{-1}$ הוא ההופך של המטריצה $A$.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

Because a matrix maps input vectors to output vectors, it is a function on the plane. Composing transformations corresponds to multiplying their matrices, and the inverse matrix reverses the mapping.

עברית

מכיוון שמטריצה מטרת וקטורי כניסה לוקטורי תוצאה, היא מהווה פונקציה על המישור. הרכבת טרנספורמציות תואמת להכפלת המטריצות שלהן, והמטריצה ההופכת הופכת את ההטבה.

4.14

Matrices Modeling Contexts · ⁨מטרצות המדמות הקשרים⁩

Syllabus · ⁨סיילבוס⁩
English

Learning Objective 4.14.A: Construct a model of a scenario involving transitions between two states using matrices.

  • 4.14.A.1 A contextual scenario can indicate the rate of transitions between states as percent changes. A matrix can be constructed based on these rates to model how states change over discrete intervals.

Learning Objective 4.14.B: Apply matrix models to predict future and past states for $n$ transition steps.

  • 4.14.B.1 The product of a matrix that models transitions between states and a corresponding state vector can predict future states.
  • 4.14.B.2 Repeated multiplication of a matrix that models the transitions between states and corresponding resultant state vectors can predict the steady state, a distribution between states that does not change from one step to the next.
  • 4.14.B.3 The product of the inverse of a matrix that models transitions between states and a corresponding state vector can predict past states.
עברית

מטרת הלמידה 4.14.A: בניית מודל של תרחיש המכיל מעברים בין שני מצבים באמצעות מטריצות.

  • 4.14.A.1 תרחיש קונטקסטי יכול להצביע על קצב המעברים בין מצבים כשינויים אחוזיים. ניתן לבנות מטריצה על בסיס קצבים אלו כדי לדמות כיצד מצטים משתנים לאורך אינטרוולים דיסקרטיים.

מטרת הלמידה 4.14.B: יישום מודלי מטריצות לחיזוי מצבים עתידיים ועבריים עבור $n$ צעדים של מעבר.

  • 4.14.B.1 מכפלה של מטריצה שמדמה מעברים בין מצבים עם וקטור מצב המתאים יכולה לחזות מצבים עתידיים.
  • 4.14.B.2 כפל חוזר של מטריצה שמדמה מעברים בין מצסים עם וקטורי מצב תוצאתיים מתאימים יכול לחזות את המצב היציב, כלומר חלוקה בין מצסים שאינה משתנה משלב אחד למשנהו.
  • 4.14.B.3 מכפלה של ההופך של מטריצה שמדמה מעברים בין מצסים עם וקטור מצב המתאים יכולה לחזות מצבים עבריים.

Source: College Board AP Course and Exam Description · ⁨מקור: תיאור הקורס והמבחן של College Board AP⁩

English

Matrices model systems that step forward in stages – for example, populations moving between states each year. Repeated multiplication by a transition matrix advances the model one step at a time, so matrix powers predict long-run behavior.

עברית

מטרצות מדמות מערכות המתקדמות בשלבים – לדוגמה, אוכלוסיות העוברות בין מצבים בכל שנה. כפילה חוזרת של מטריצת מעבר מקדמת את הדגם צעד אחר צעד, ולכן חזקות של מטריצות מנבאות התנהגות לטווח ארוך.

4.14

Exam tips · ⁨טיפים לבחינות⁩

English
  • A parametric function gives $x(t)$ and $y(t)$ separately — track the direction of motion as $t$ increases.
  • A vector has magnitude and direction; add component-by-component and find magnitude with $\sqrt{a^2+b^2}$.
  • The determinant of a $2\times2$ matrix is $ad-bc$ (mind the minus sign); it scales area under the transformation.
  • A $2\times2$ matrix transforms the plane (rotate, reflect, stretch); an inverse exists only when the determinant is non-zero.
  • Note this unit is not tested on the AP Precalculus Exam (Units 1–3 only), but it underpins later courses.
עברית
  • פונקציה פרמטרית נותנת $x(t)$ ו$y(t)$ בנפרד – עקוב אחר כיוון התנועה כאשר $t$ גדל.
  • וקטור הוא בעל גודל וכיוון; הוסיפו רכיב-על-רכיב ומצאו גודל באמצעות $\sqrt{a^2+b^2}$.
  • הדיטרמיננטה של מטריצה $2\times2$ היא $ad-bc$ (שימו לב למינוס); היא קובעת את היחס שבין השטח המקורי לשטח לאחר ההמרה.
  • מטריצה $2\times2$ ממירה את המישור (סיבוב, החזר, מתיחה); הפוך קיים רק כאשר הדיטרמיננטה אינה אפס.
  • שימו לב: יחידה זו אינה נבדקת בבחינת AP Precalculus (רק יחידות 1–3), אך היא מהווה בסיס לקורסים מאוחרים.

Interactive lessons on this topic · ⁨שיעורים אינטראקטיביים בנושא זה⁩

Work through it step by step, with instant-check exercises. · ⁨לעבור על הדברים צעד אחר צעד, עם תרגילים לבדיקה מיידית.⁩

Past Papers · ⁨מבחני עבר⁩

More topics in AP Precalculus · ⁨פרי-קלקולוס - AP⁩ · ⁨נושאים נוספים בAP Precalculus · ⁨פרי-קלקולוס - AP⁩⁩

Log in or create account · ⁨היכנס או צור חשבון⁩

IGCSE, A-Level & AP