| Learning Objective | Essential Knowledge |
|---|---|
1.1.A |
|
Kinematics · קינמטיקה
AP Physics C: Mechanics · פיזיקה AP C: מכניקה · Topic 1 · נושא 1
 7:31
קינמטיקה
רקטה משתקת לאוויר. כל שנייה, המנוע שלה שורף חזק יותר, ולכן ההאצה ממשיכה לגדול. כעת נסה למצוא את המהירות שלו באמצעות המשוואות מהראשון שלך…
English narration · English + 中文 subtitles burned in · קריאת קול באנגלית · תרגום אנגלי + סינית שרוף בתוך הסרטון
1.1
Scalars and Vectors · גדלים סקלאריים ווקטוריים
Syllabus · סיילבוס
Source: College Board AP Course and Exam Description · מקור: תיאור הקורס והמבחן של College Board AP
English
Kinematics 运动学 describes motion. Two kinds of quantity:
- A scalar 标量 has only size (magnitude 大小): distance, speed, mass, time.
- A vector 矢量 has magnitude and direction: displacement, velocity, acceleration, force.
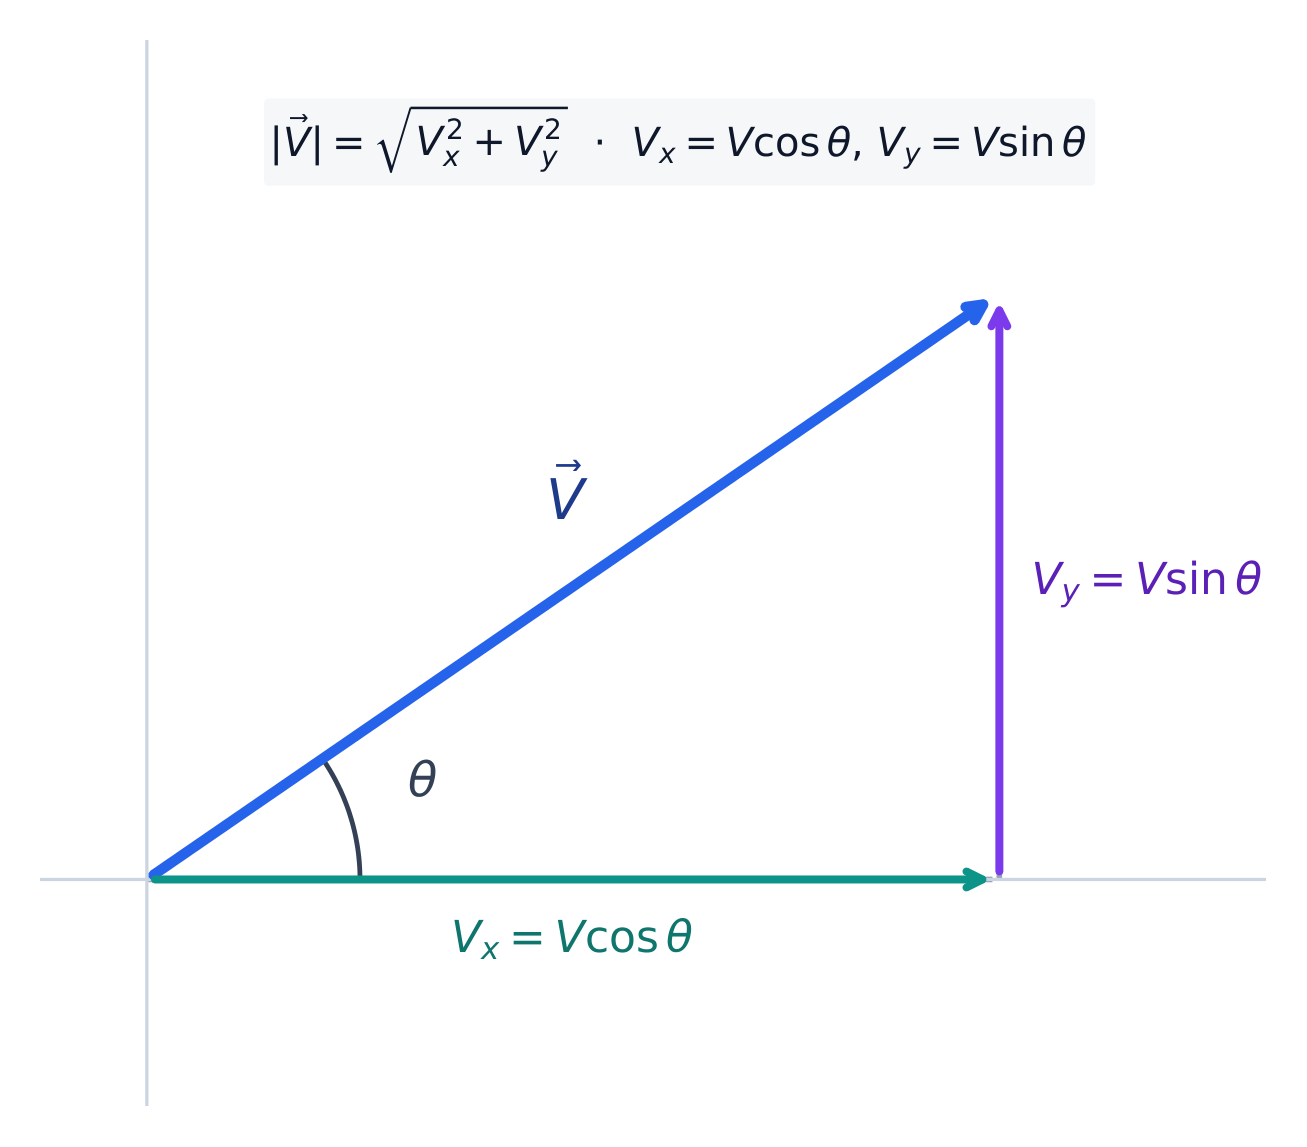
In this calculus-based course you resolve vectors into components 分量 and add them component by component; a vector's magnitude is $\sqrt{v_x^2+v_y^2+\cdots}$. Physics C also writes vectors with unit vectors 单位矢量: $\vec{v}=v_x\hat{i}+v_y\hat{j}$, where $\hat{i}$ and $\hat{j}$ are directions of length one along $x$ and $y$ – handy because calculus can then act on each component separately.
עברית
קינמטיקה מתארת תנועה. שני סוגים של גדלים:
- סקלאר הוא גדל בעל רק גודל (גודל מוחלט): מרחק, מהירות, מסה, זמן.
- לווקטור יש גודל וגם כיוון: תזחה, מהירות, תאוצה, כוח.
בקורס זה המבוסס על חשבון אינטגרלי פתחתם וקטורים לרכיבים ותוסיפו אותם רכיב-ברכיב; הגודל המוחלט של וקטור הוא $\sqrt{v_x^2+v_y^2+\cdots}$. פיזיקה C גם כותבת וקטורים עם ווקטורי יחיד: $\vec{v}=v_x\hat{i}+v_y\hat{j}$, כאשר $\hat{i}$ ו$\hat{j}$ הם כיוונים בגודל אחת לאורך $x$ ו$y$ – נוח מכיוון שמחשוב אינטגרלי יכול לפעול על כל רכיב בנפרד.
Explore · חקור
Explore the dot product · חקור את מכפלת נקודתית
Drag the components of $\vec{A}$ and $\vec{B}$. The dot product $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ reaches zero exactly when the two vectors are perpendicular — the geometry behind $\cos\theta$. · גרור את רכיבי $\vec{A}$ ו$\vec{B}$. מכפלת נקודתית $\vec{A}\cdot\vec{B}=A_xB_x+A_yB_y$ מגיעה ל-אפס בדיוק כאשר שני הווקטורים מאונכים — הגיאומטריה העומדת מאחורי $\cos\theta$.
Vocabulary · מילון מונחים
Train · אימון
| English | עברית |
|---|---|
| vector/ˈvektə/ | מסיר מחלות |
| components/kəmˈpəʊnənts/ | רכיבים |
| unit vectors/ˈjuːnɪt ˈvektəz/ | וקטורים יחידה |
| derivatives/dɪˈrɪvətɪvz/ | נגזרות |
| average velocity/ˈævrɪdʒ vəˈlɒsɪti/ | מהירות ממוצעת |
| instantaneous velocity/ˌɪnstənˈteɪnɪəs vəˈlɒsɪti/ | מהירות רגעית |
| free fall/friː fɔːl/ | נפילה חופשית |
| reference frame/ˈrefrəns freɪm/ | מערכת ייחוס |
| relative motion/ˈrelətɪv ˈməʊʃn/ | תנועה יחסית |
| projectile motion/prəˈdʒektaɪl ˈməʊʃn/ | תנועת פרויקטייל |
1.2
Displacement, Velocity, and Acceleration · תזחה, מהירות ותאוצה
Syllabus · סיילבוס
| Learning Objective | Essential Knowledge |
|---|---|
1.2.A |
|
1.2.B |
|
1.2.C |
|
Source: College Board AP Course and Exam Description · מקור: תיאור הקורס והמבחן של College Board AP
English
Because motion can change continuously, define the rates as derivatives 导数:
$$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$
Reversing this, integrate to recover velocity and position:
$$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$
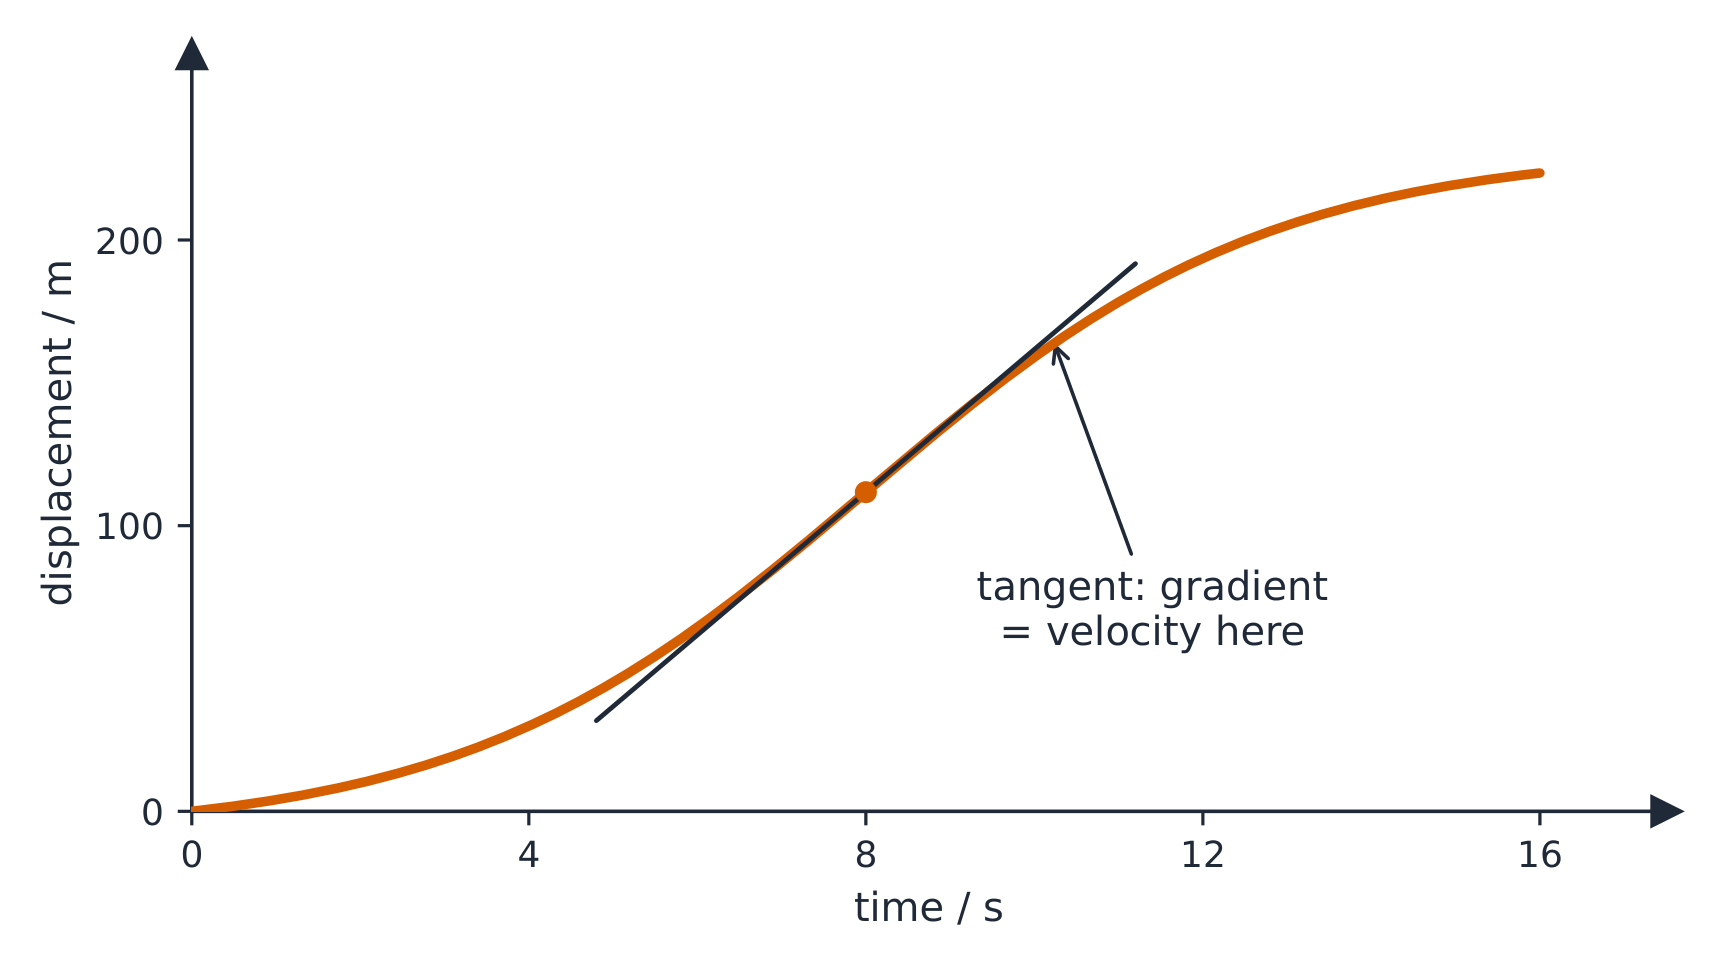
Distinguish the average from the instantaneous: average velocity 平均速度 is $\Delta x/\Delta t$ over an interval, while instantaneous velocity 瞬时速度 is the derivative at one moment – the slope of the tangent line, and what a speedometer shows.
For constant acceleration these give the familiar kinematic equations ($v=v_0+at$, $x=x_0+v_0t+\tfrac12at^2$, $v^2=v_0^2+2a\,\Delta x$). The most important constant-$a$ case is free fall 自由落体: near Earth's surface every object, heavy or light, accelerates downward at $g=9.8\ \text{m/s}^2$ once air resistance is negligible. When $a$ or $v$ varies with time, use the integrals directly.
Worked example. A particle moves with $x(t)=2t^3-3t^2$ (metres). Differentiate for velocity and acceleration:
$$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$
At $t=2\ \text{s}$, $v=24-12=12\ \text{m/s}$ and $a=24-6=18\ \text{m/s}^2$. This calculus link – not just the constant-$a$ formulas – is what distinguishes Physics C.
Worked example. A particle starts from rest at the origin with $a(t)=6t$. Integrate: $v=\int 6t\,dt=3t^2$ and $x=\int 3t^2\,dt=t^3$. At $t=2\ \text{s}$, $v=12\ \text{m/s}$ and $x=8\ \text{m}$.
עברית
מכיוון שתנועה עשויה להשתנות ברצף, הגדרו קצבים כנגזרות:
$$v=\frac{dx}{dt},\qquad a=\frac{dv}{dt}=\frac{d^2x}{dt^2}.$$
בהפיכה, אינטגרל כדי לשחזר את המהירות והמיקום:
$$v(t)=v_0+\int_0^t a\,dt,\qquad x(t)=x_0+\int_0^t v\,dt.$$
הבחינו בין ממוצע לבין רגעי: מהירות ממוצעת היא $\Delta x/\Delta t$ בתוך מרווח זמן, בעוד מהירות רגעית היא הנגזרת ברגע מסוים — השיפוע של המשיק, ומה שהמדומטר מראה.
עבור תאוצה קבועה, אלו נותנות את משוואות הקינמטיקה המוכרות ($v=v_0+at$, $x=x_0+v_0t+\tfrac12at^2$, $v^2=v_0^2+2a\,\Delta x$). המקרה החשוב ביותר של תאוצה קבועה-$a$ הוא נפילה חופשית: קרוב לפני השטח של כדור הארץ כל גוף, כבד או קל, מאיץ כלפי מטה ב$g=9.8\ \text{m/s}^2$ ברגע שהתנגדות האוויר becomes זניחה. כאשר $a$ או $v$ משתנה עם הזמן, השתמשו באינטגרלים ישירות.
דוגמה מפורטת. חלקיק נע לפי $x(t)=2t^3-3t^2$ (מטרים). גזרו עבור מהירות ותאוצה:
$$v=\frac{dx}{dt}=6t^2-6t,\qquad a=\frac{dv}{dt}=12t-6.$$
על $t=2\ \text{s}$, $v=24-12=12\ \text{m/s}$ ועל $a=24-6=18\ \text{m/s}^2$. הקשר החישובי הזה — ולא רק הנוסחות לתאוצה קבועה-$a$ — הוא מה שמבדיל את פיזיקה C.
דוגמה מפורטת. חלקיק מתחיל מנקודת הרגיעה בראשית הצירים עם $a(t)=6t$. אינטגרלו: $v=\int 6t\,dt=3t^2$ ועל $x=\int 3t^2\,dt=t^3$. על $t=2\ \text{s}$, $v=12\ \text{m/s}$ ועל $x=8\ \text{m}$.
Vocabulary · מילון מונחים
Train · אימון
| English | עברית |
|---|---|
| Kinematics/ˌkɪnɪˈmætɪks/ | קינמטיקה |
| scalar/ˈskeɪlə/ | סקאלר |
| magnitude/ˈmæɡnɪtjuːd/ | גודל |
1.3
Representing Motion · ייצוג תנועה
Syllabus · סיילבוס
| Learning Objective | Essential Knowledge |
|---|---|
1.3.A |
Boundary statement: AP Physics C: Mechanics and AP Physics C: Electricity and Magnetism expects that for all situations in which a numerical quantity is required for g, the value $g \approx 10 \ \text{m/s}^2$ will be used. However, students will not be penalized for correctly using the more precise commonly accepted values of $g = 9.81 \ \text{m/s}^2$ or $g = 9.8 \ \text{m/s}^2$. |
Source: College Board AP Course and Exam Description · מקור: תיאור הקורס והמבחן של College Board AP
English
Move fluently between description, graph, table, and equation:
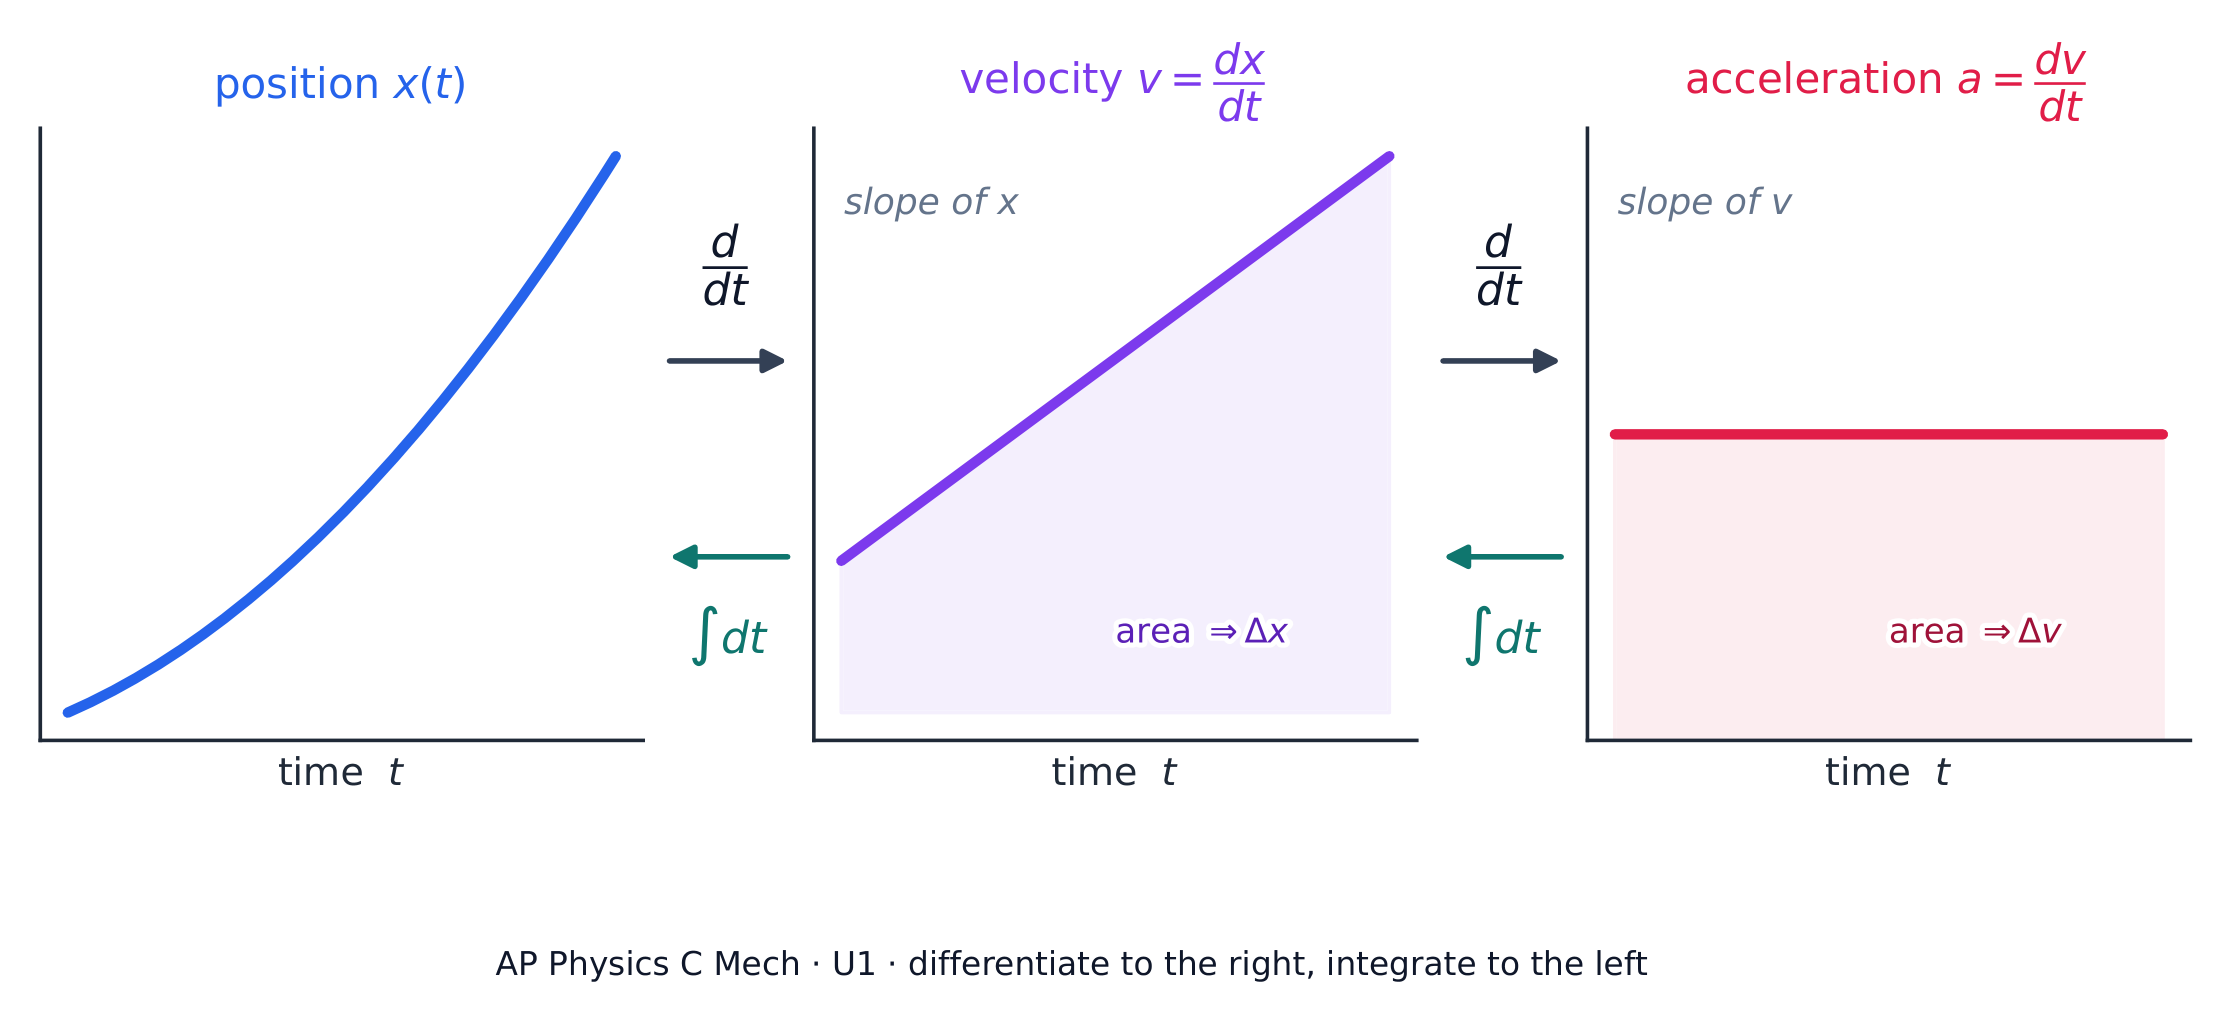
- On a position–time graph, the slope ($dx/dt$) is velocity.
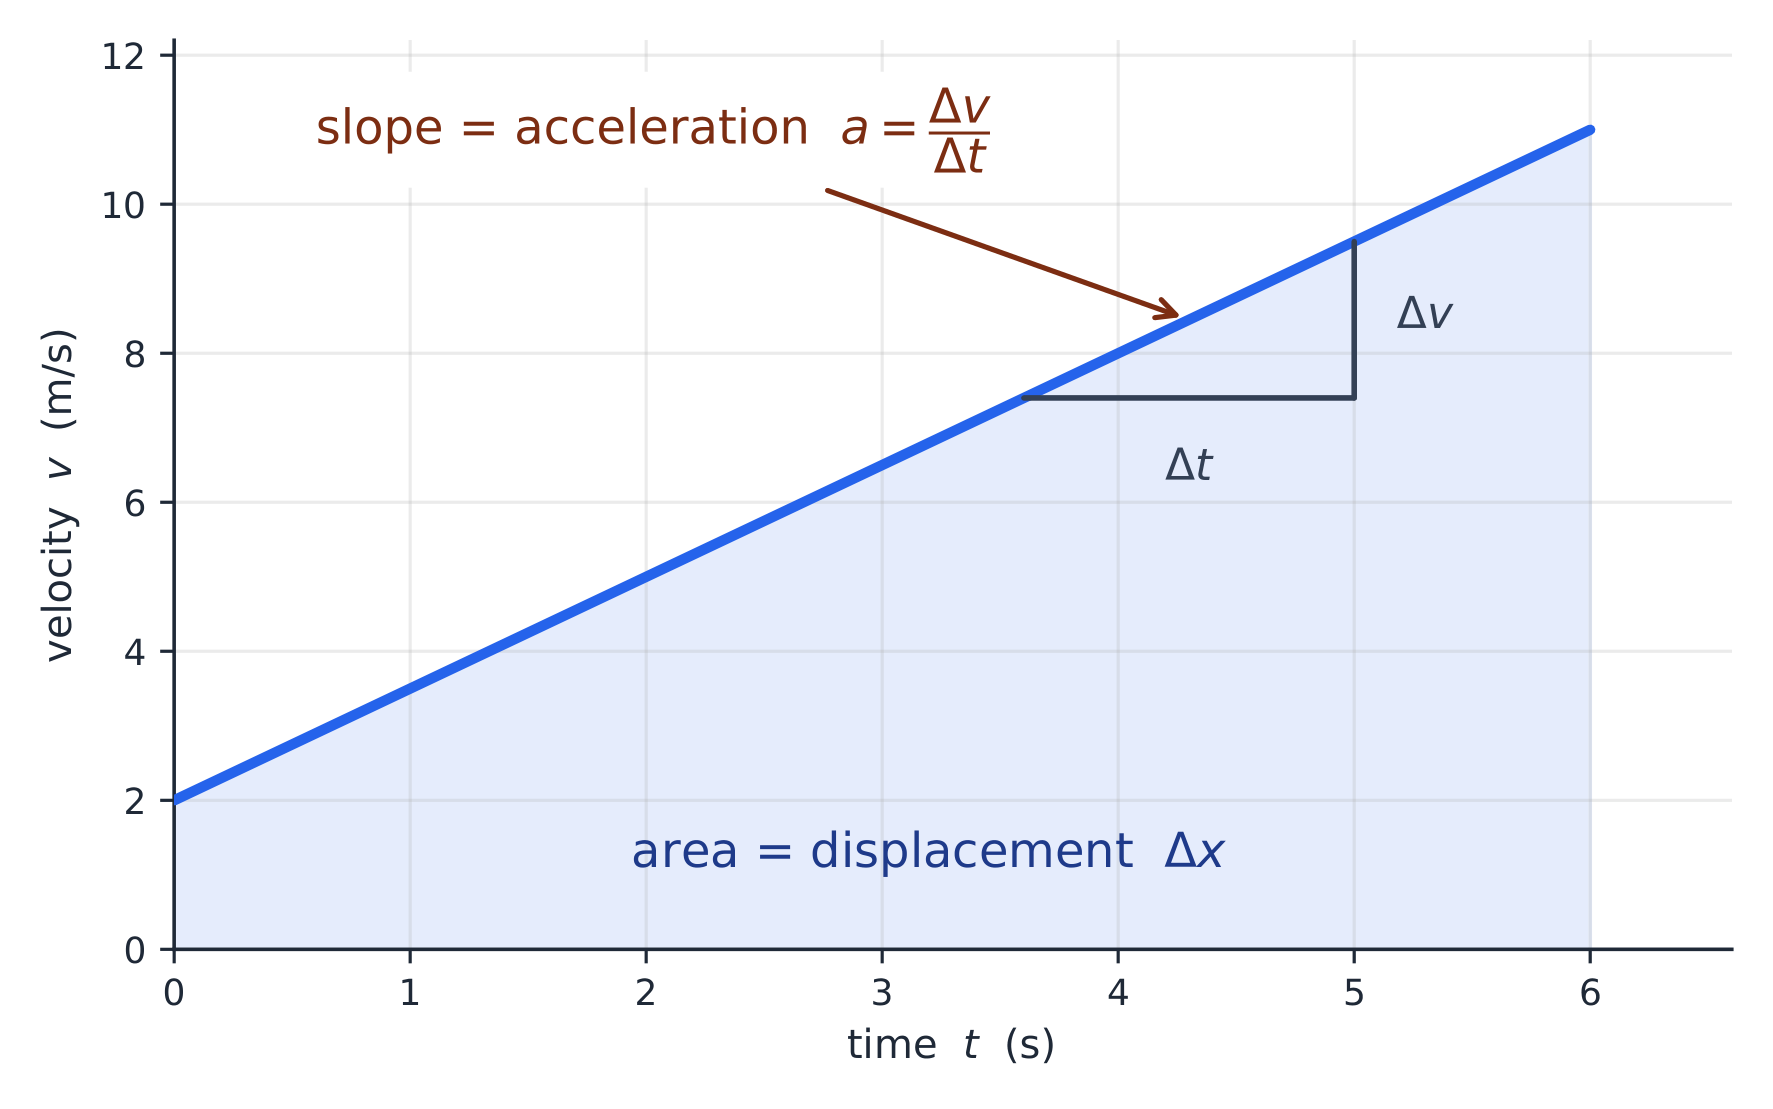
- On a velocity–time graph, the slope is acceleration and the area ($\int v\,dt$) is displacement.
- On an acceleration–time graph, the area ($\int a\,dt$) is the change in velocity.
Slopes are derivatives; areas are integrals – the two are inverse operations here.
עברית
מעבר זורם בין תיאור, גרף, טבלה ומשוואה:
- בגרף מיקום–זמן, השיפוע ($dx/dt$) הוא מהירות.
- בגרף מהירות–זמן, השיפוע הוא תאוצה והשטח ($\int v\,dt$) הוא הגבהל.
- בגרף תאוצה–זמן, השטח ($\int a\,dt$) הוא השינוי במהירות.
שיפועים הם נגזרות; שטחים הם אינטגרלים – שתי הפעולות הן הפוכות זו לזו כאן.
Explore · חקור
Explore the velocity–time graph · חקרו את הגרף מהירות-זמן
Change the start velocity and acceleration. The slope of a $v$–$t$ line is the acceleration $a=\tfrac{dv}{dt}$, and the area underneath is the displacement $\Delta x=\int v\,dt$ — slope and area are the graphical faces of the derivative and the integral. · שנה את מהירות ההתחלה והתאוצה. השיפוע של קו $v$–$t$ הוא התאוצה $a=\tfrac{dv}{dt}$, וה-שטח מתחתיו הוא ההזזה $\Delta x=\int v\,dt$ — שיפוע ושטח הם הפנים הגרפיות של הנגזרת והאינטגרל.
1.4
Reference Frames and Relative Motion · מערכות ייחוס ותנועה יחסית
Syllabus · סיילבוס
English
Learning Objective 1.4.A: Describe the reference frame of a given observer.
- 1.4.A.1 The choice of reference frame will determine the direction and magnitude of quantities measured by an observer in that reference frame.
Learning Objective 1.4.B: Describe the motion of objects as measured by observers in different inertial reference frames.
- 1.4.B.1 Measurements from a given reference frame may be converted to measurements from another reference frame.
- 1.4.B.2 The observed velocity of an object results from the combination of the object's velocity and the velocity of the observer's reference frame.
- 1.4.B.2.i Combining the motion of an object and the motion of an observer in a given reference frame involves the addition or subtraction of vectors.
- 1.4.B.2.ii The acceleration of any object is the same as measured from all inertial reference frames.
Boundary statement: Unless otherwise stated, the frame of reference of any problem may be assumed to be inertial.
עברית
מטרות למידה 1.4.A: לתאר את מערכת הייחוס של צופה נתון.
- 1.4.A.1 בחירת מערכת הייחוס תקבע את הכיוון והגודל של כמויות שנמדדות על ידי צופה במערכת זו.
מטרות למידה 1.4.B: לתאר את תנועת אובייקטים כפי שנמדדו על ידי צופים במערכות ייחוס אינרציאליות שונות.
- 1.4.B.1 מדידות ממערכת ייחוס נתונה יכולות להיות מומשות למדידות ממערכת ייחוס אחרת.
- 1.4.B.2 המהירות הנצפתה של אובייקט נובעת משילוב מהירות האובייקט ומהירות מערכת הייחוס של הצופה.
- 1.4.B.2.i שילוב תנועת אובייקט ותנועת צופה במערכת ייחוס נתונה מחייב חיבור או חיסור של וקטורים.
- 1.4.B.2.ii התאוצה של כל אובייקט זהה כפי שנמדדת מכל מערכות הייחוס האינרציאליות.
הצהרת גבול: אלא אם כן צוין אחרת, ניתן להניח שמערכת הייחוס של כל בעיה היא אינרציאלית.
Source: College Board AP Course and Exam Description · מקור: תיאור הקורס והמבחן של College Board AP
English
All motion is relative to a reference frame 参考系. Combine velocities by vector addition: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. This handles boats crossing rivers and passengers on moving vehicles – relative motion 相对运动 problems. Read the subscripts as a chain: "A relative to B" plus "B relative to C" gives "A relative to C".
Worked example. A boat that moves at $4.0\ \text{m/s}$ in still water heads straight across a river flowing at $3.0\ \text{m/s}$. Relative to the ground the boat moves at $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$, angled downstream. If the river is $80\ \text{m}$ wide, the crossing still takes $t=\dfrac{80}{4.0}=20\ \text{s}$ – only the across-stream component crosses the river; the current just carries the boat $60\ \text{m}$ downstream.
עברית
כל התנועה היא יחסית למערכת ייחוס. שילוב מהירויות מתבצע באמצעות חיבור וקטורי: $\vec{v}_{A/C}=\vec{v}_{A/B}+\vec{v}_{B/C}$. הדבר חל על ספינות החוצות נהרות ומסיעים ברכבים זזים – בעיות שלתנועה יחסית. קראו את המקדמים כשרשרת: "A ביחס ל-B" פלו "B ביחס ל-C" נותן "A ביחס ל-C".
דוגמה מוצגת. סירה הנעה במהירות $4.0\ \text{m/s}$ במים שקטים פונה ישר כלפי חוצה נהר זורם במהירות $3.0\ \text{m/s}$. ביחס לקרקע הסירה נעה במהירות $\sqrt{4.0^2+3.0^2}=5.0\ \text{m/s}$, בזווית כלפי מטה הזרם. אם רוחב הנהר הוא $80\ \text{m}$, עדיין לוקח לה לצלוח אותו $t=\dfrac{80}{4.0}=20\ \text{s}$ – רק המרכיב החוצני של מהירותה מצטלח את הנהר; הזרם פשוט נשא את הסירה $60\ \text{m}$ כלפי מטה הזרם.
1.5
Motion in Two or Three Dimensions · תנועה בשתי או שלושה ממדים
Syllabus · סיילבוס
English
Learning Objective 1.5.A: Describe the motion of an object moving in two or three dimensions.
- 1.5.A.1 Motion in two or three dimensions can be analyzed using one-dimensional kinematic relationships if the motion is separated into components.
- 1.5.A.2 Velocity and acceleration may be different in each dimension and may be nonuniform.
- 1.5.A.3 Motion in one dimension may be changed without causing a change in a perpendicular dimension.
- 1.5.A.4 Projectile motion is a special case of two-dimensional motion that has zero acceleration in one dimension and constant, nonzero acceleration in the second dimension.
Boundary statement: AP Physics C: Mechanics only expects students to quantitatively analyze the motion of an object in two dimensions. AP Physics C: Electricity and Magnetism expects students to also qualitatively describe the motion of a particle in three dimensions.
עברית
מטרת למידה 1.5.A: לתאר את תנועת גוף הנע בשני ממדים או שלושה ממדים.
- 1.5.A.1 תנועה בשני ממדים או שלושה ממדים ניתנת לניתוח באמצעות קשרים קינמטיים חד-ממדיים, אם התנועה מפוצלת לרכיבים.
- 1.5.A.2 מהירות ואיטוב עשויים להיות שונים בכל ממד ועשויים להיות לא אחידים.
- 1.5.A.3 תנועה בממד אחד עשויה להשתנות ללא גרימת שינוי בממד מאונך.
- 1.5.A.4 תנועת פרוקטייל היא מקרה פרטי של תנועה דו-ממדית המאופיינת באיטוב אפס בממד אחד ואיטוב קבוע ולא-אפסי בממד השני.
הצהרת גבול: AP Physics C: Mechanics מצפה רק מן התלמידים לבצע ניתוח כמותי של תנועת גוף בשני ממדים. AP Physics C: Electricity and Magnetism מצפה מן התלמידים גם לתאר איכותית תנועת חלקיק בשלושה ממדים.
Source: College Board AP Course and Exam Description · מקור: תיאור הקורס והמבחן של College Board AP
English
In two or three dimensions, position is a vector $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$, and velocity and acceleration are its successive derivatives – each component handled independently.
Worked example. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (metres). Differentiating each component: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ and $\vec{a}=4\,\hat{i}-6t\,\hat{j}$. At $t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$, so the speed is $\sqrt{17}\approx4.1\ \text{m/s}$ – no new physics, just one derivative per component.
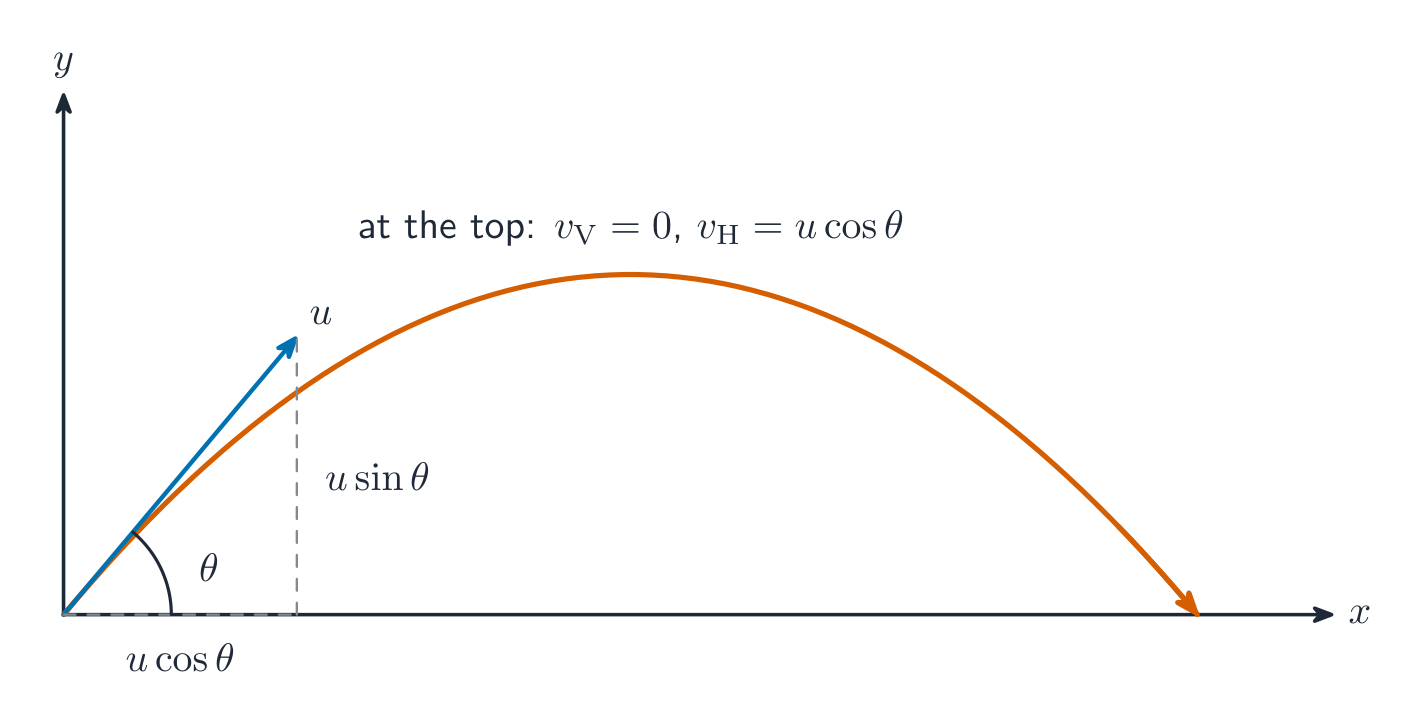
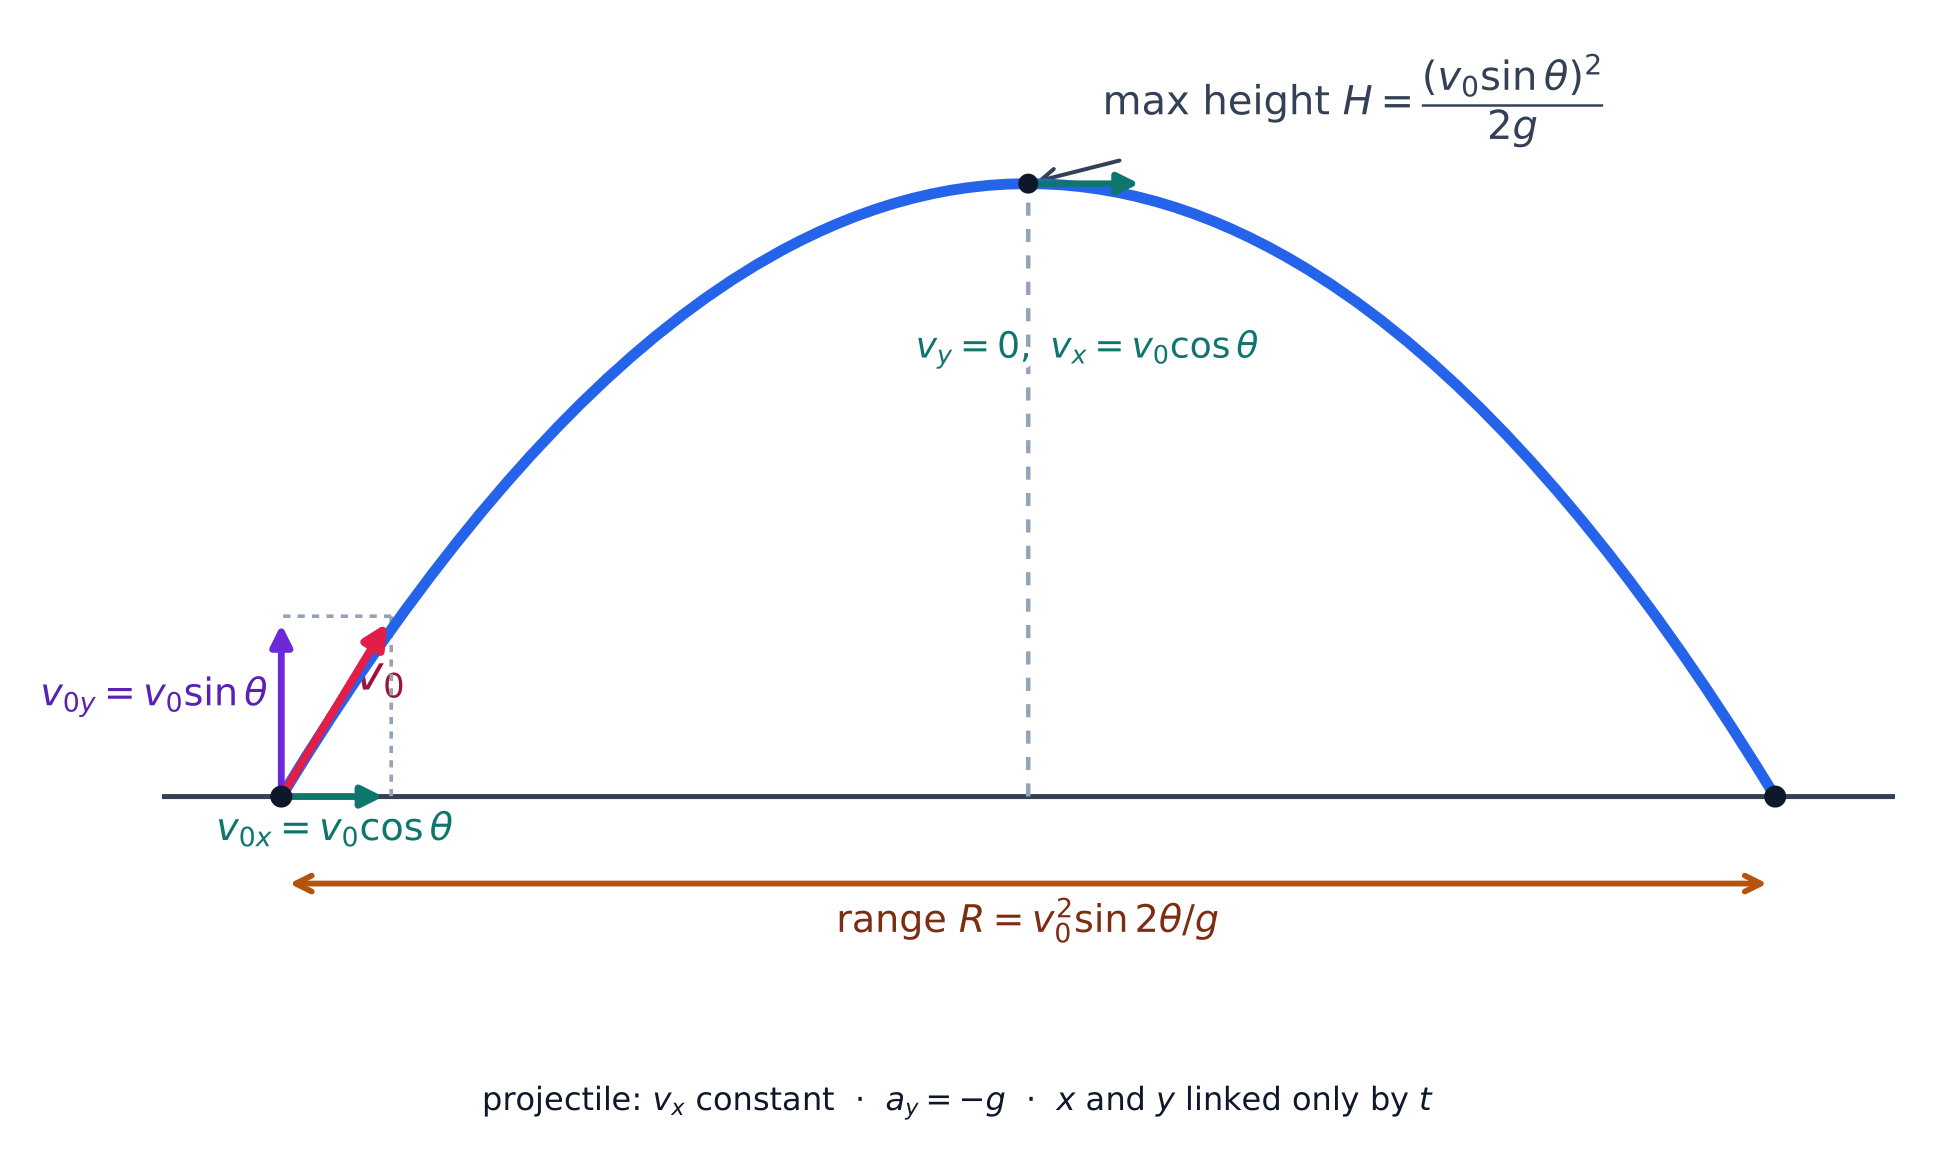
For projectile motion 抛体运动, horizontal and vertical motions are independent, linked only by time $t$: horizontally $a_x=0$ (constant velocity), vertically $a_y=-g$. The path is a parabola. This component method extends to any two-dimensional motion where the accelerations along each axis are known.
Worked example. A ball is launched at $20\ \text{m/s}$, $30^{\circ}$ above the horizontal ($g=9.8\ \text{m/s}^2$). The components are $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ and $v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. The vertical motion sets the time: total flight $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$, maximum height $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$, and range $=v_{0x}\times2.0=35\ \text{m}$.
עברית
בשני או שלושה ממדים, המיקום הוא וקטור $\vec{r}(t)=\langle x(t),y(t),z(t)\rangle$, והמהירות והתאוצה הן הנגזרות העוקבות שלו – כל רכיב מטופל בנפרד.
דוגמה מופרזת. $\vec{r}(t)=\big(2t^2\big)\hat{i}+\big(4t-t^3\big)\hat{j}$ (מטר). נגזרת כל רכיב: $\vec{v}=4t\,\hat{i}+(4-3t^2)\,\hat{j}$ ו$\vec{a}=4\,\hat{i}-6t\,\hat{j}$. ב$t=1\ \text{s}$: $\vec{v}=4\hat{i}+1\hat{j}$, ולכן המהירות היא $\sqrt{17}\approx4.1\ \text{m/s}$ – אין כאן פיזיקה חדשה, רק נגזרת אחת לכל רכיב.
עבורתנועת פרaboile, התנועה האופקית והתנועה האנכיות הן עצמאיות, מקושרות רק על ידי הזמן $t$: אופקית $a_x=0$ (מהירות קבועה), אנכית $a_y=-g$. המסלול הוא פרבולה. שיטה זו מתרחבת לכל תנועה דו-ממדית שבה ידועות התאוצות לאורך ציר כל אחד.
דוגמה מופרזת. כדור משוגע במהירות $20\ \text{m/s}$, בزاوية $30^{\circ}$ מעל האופק ($g=9.8\ \text{m/s}^2$). הרכיבים הם $v_{0x}=20\cos30^{\circ}=17.3\ \text{m/s}$ ו$v_{0y}=20\sin30^{\circ}=10\ \text{m/s}$. התנועה האנכית קובעת את הזמן: זמן טיסה כולל $=\dfrac{2v_{0y}}{g}=\dfrac{20}{9.8}=2.0\ \text{s}$, גובה מקסימלי $=\dfrac{v_{0y}^2}{2g}=5.1\ \text{m}$, וטווח $=v_{0x}\times2.0=35\ \text{m}$.
Explore · חקור
Explore projectile motion · חקרו תנועת פריל
Fire the projectile, then vary the angle and speed. The horizontal motion is steady while gravity acts only downward — together they trace a parabola. Find the angle that gives the greatest range (it peaks near $45^\circ$), and try the Moon. · שחרר את הפרויקטייל, ואז משנה את הזווית והמהירות. התנועה האופקית היא אחידה בעוד שכובד פועל רק כלפי מטה — יחד הם משרטטים פרבולה. מצא את הזווית הנותנת את הטווח הגדול ביותר (הוא מקבל שיא בקרבת $45^\circ$), ונסה את הירח.
1.5
Exam tips · טיפים לבחינות
English
- Resolve every vector into components before adding — never add magnitudes at an angle directly.
- On Physics C you are expected to use calculus: velocity is $\vec v=\tfrac{d\vec r}{dt}$ and acceleration $\vec a=\tfrac{d\vec v}{dt}$; reverse with integration.
- Carry and check units and treat direction with signs (choose a positive axis and stick to it).
- Use the dot product for work-type quantities and the cross product for torque and angular momentum.
- Sketch the vectors — a diagram catches sign and direction errors the algebra hides.
עברית
- פירקו כל וקטור לרכיבים לפני החיבור – לעולם אל תחברו גדלים בזווית ישירות.
- בקורס Physics C מצופים שתשתמשו בק্যালקולוס: מהירות היא $\vec v=\tfrac{d\vec r}{dt}$ ותאוצה $\vec a=\tfrac{d\vec v}{dt}$; הפוך באמצעות אינטגרציה.
- שמרו עליחידות ובדקו אותן, וטפל בכיוון באמצעות סימנים (בחרו ציר חיובי והתמידו בו).
- השתמשו ב מכפלה נקודתית לכמויות מסוג עבודה ובמכפלה צולבת למומנט ולתנע זוויתי.
- שרטט את הווקטורים — דיאגרמה חושפת טעויות סימן וכיוון שהאלגברה מחביאה.
Interactive lessons on this topic · שיעורים אינטראקטיביים בנושא זה
Work through it step by step, with instant-check exercises. · לעבור על הדברים צעד אחר צעד, עם תרגילים לבדיקה מיידית.