Sensors and actuators: the error budget decides
引入| English | 释义 | 拼音 |
|---|---|---|
| error/ˈerə/ | 误差 | wù chā |
| measurand | 被测量 | bèi cè liáng |
| platinum resistance thermometer | 铂电阻温度计 | bó diàn zǔ wēn dù jì |
| signal chain | 信号链 | xìn hào liàn |
| error budget | 误差预算 | wù chā yù suàn |
| ADC/ˌeɪ diː ˈsiː/ | 模数转换器 | mó shù zhuǎn huàn qì |
Only as good as the thermometer
- The temperature loop can hold the water only as well as the thermometer reads it. A sensor chain with an unknown error makes the whole design a guess.
- Choose the principle for the measurand (a platinum resistance thermometer, Pt100, for 0–100 °C water), follow the signal chain and write an error budget.
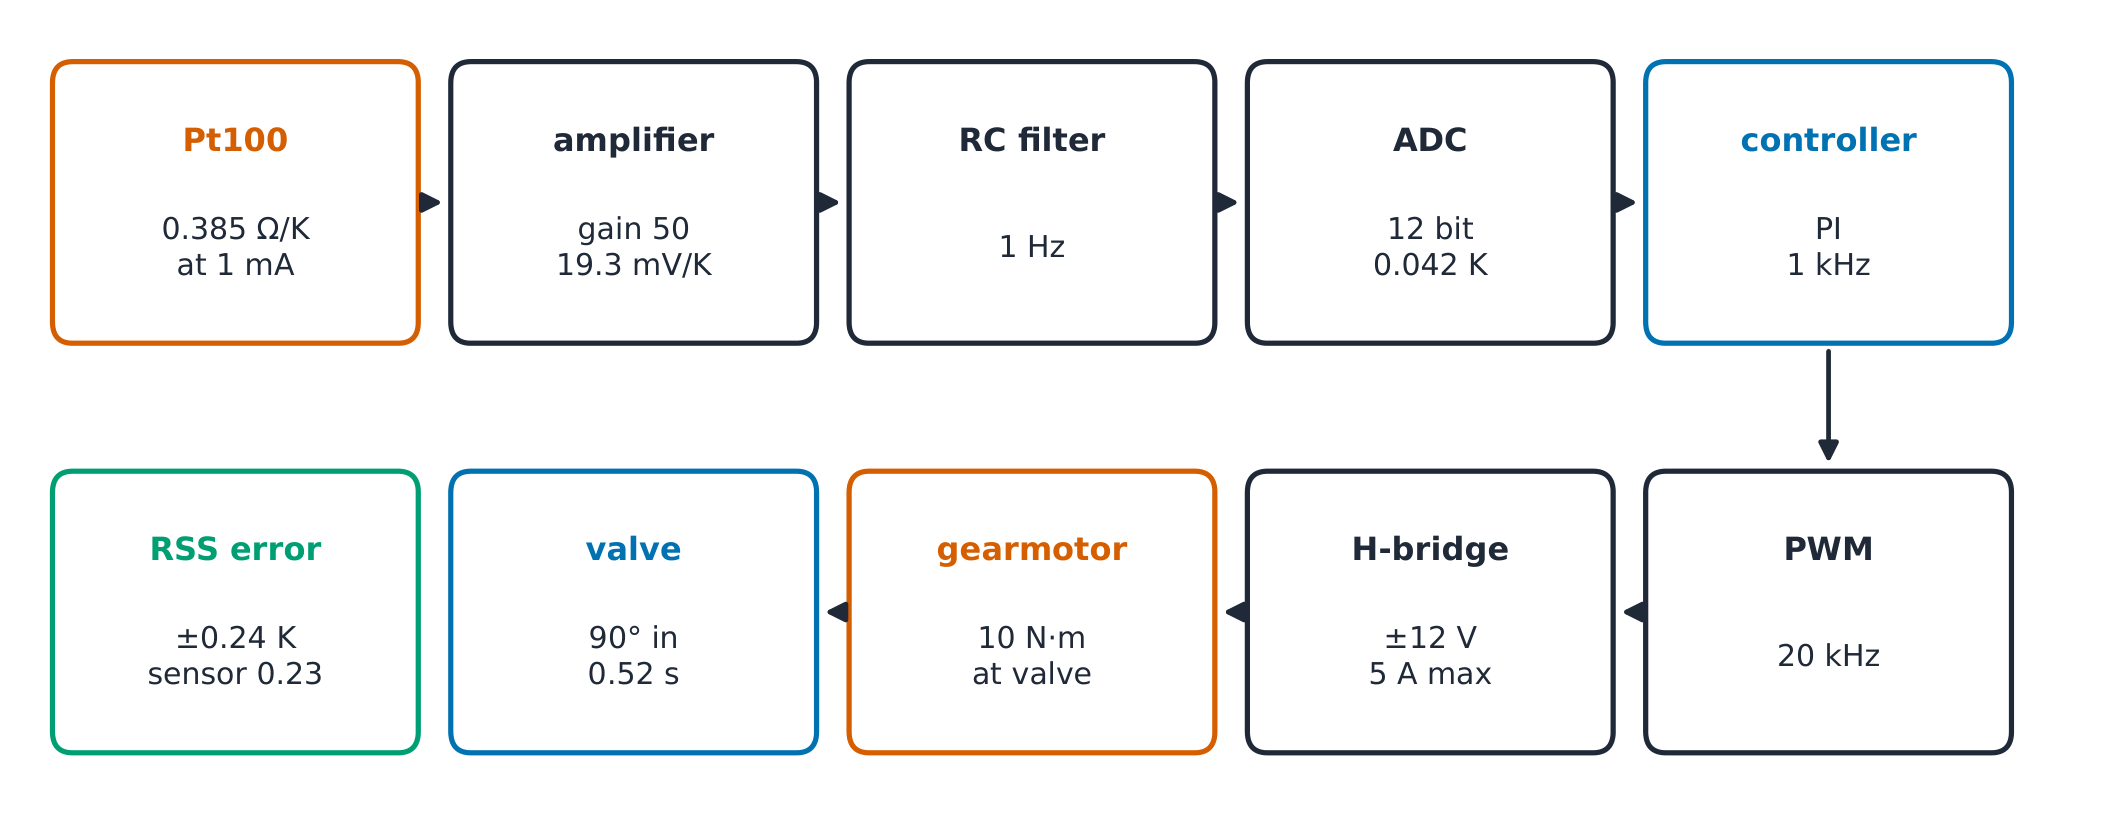
Scaling the chain
- A Pt100 changes 0.385 Ω/K: at 1 mA that is 0.385 mV/K, and a gain of 50 makes 19.25 mV/K.
- A 12-bit ADC over 3.3 V steps 0.806 mV, so one step is $\mathbf{0.042}$ K, with a rounding error of step$/\sqrt{12} = 0.012$ K.
Sensitivity after a gain of 50 on 0.385 mV/K (two decimals, mV/K)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
50 times 0.385.
Kelvin per step of a 12-bit ADC over 3.3 V (three decimals, K)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
0.806 mV over 19.25 mV/K.
The error budget at 40 °C
- Sensor class A: $\pm(0.15 + 0.002 \times 40) = \pm\mathbf{0.23}$ K. ADC 0.012 K; gain error 0.04 K; self-heating 0.05 K.
- RSS: $\sqrt{0.23^2 + 0.012^2 + 0.04^2 + 0.05^2} = \pm\mathbf{0.24}$ K.
- The sensor dominates: a 16-bit ADC would change nothing.
Which error term?
Place each number in the error budget or the actuator limits.
Class A tolerance at 40 degrees C (two decimals, K)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
0.15 + 0.002 x 40.
RSS of 0.23, 0.012, 0.04 and 0.05 K (two decimals, K)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
Root of the sum of squares.
To improve this budget, first:
难度 1/5 · 今日首次完成可获 100 金币及少量额外奖励
The sensor term dominates.
The actuator's limits
- Volts set speed: 12 V gives at most 4.78 rad/s at the valve. Amps set torque: 5 A gives 10 N·m, twice the load.
- Power at full speed and load is about 30 W. The motor's 9.6 ms lag is the whole plant for the position loop, but instantaneous for the 2.3-hour tank.
For a motor drive the voltage limit sets the top speed.
难度 1/5 · 今日首次完成可获 100 金币及少量额外奖励
Through the back emf.
Leads that read as heat
- A two-wire Pt100 measures its leads too. Two 0.2 Ω leads add 0.4 Ω, read as $0.4/0.385 = \mathbf{1.04}$ K: four times the whole error budget.
- A three-wire connection cancels equal leads, and a four-wire one carries the current and senses the voltage on separate pairs, so lead resistance drops out entirely.
Two-wire Pt100 with two 0.2 Ω leads: temperature error (two decimals, K)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
$0.4/0.385 = 1.04$ K.
A four-wire connection removes the lead resistance from a Pt100 reading.
难度 1/5 · 今日首次完成可获 100 金币及少量额外奖励
Current flows on one pair and the voltage is sensed on the other, which carries almost no current.
Worked example: the self-heating term
- At 40 °C the Pt100 is 115.4 Ω, so 1 mA dissipates $I^2R = 0.115$ mW. In stirred water it sheds 2.5 mW per kelvin of rise.
- The sensor sits $0.115/2.5 = \mathbf{0.046}$ K warm: the 0.05 K in the budget. At 5 mA the power is 25 times larger and so is the error, 1.15 K, which is why the excitation is kept at 1 mA.
Pt100 at 115.4 Ω carrying 1 mA, dissipation 2.5 mW/K: self-heating error (three decimals, K)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
$10^{-6} \times 115.4 = 0.1154$ mW; $0.1154/2.5 = 0.046$ K.
Three measurement slips
- Adding independent errors linearly. Use RSS; and only for independent ones.
- Forgetting self-heating and lead resistance. They bias a resistance thermometer.
- Buying resolution the sensor cannot use. The biggest term decides.
Recap
- 19.25 mV/K into a 12-bit ADC: 0.042 K per step.
- RSS budget $\pm0.24$ K, dominated by the sensor.
- Volts limit speed, amps limit torque.