Transfer functions: reading response from the poles
引入| English | 释义 | 拼音 |
|---|---|---|
| overshoot/ˌəʊvəˈʃuːt/ | 超调量 | chāo diào liàng |
| transfer function | 传递函数 | chuán dì hán shù |
| poles/pəʊlz/ | 极点 | jí diǎn |
| zeros/ˈzɪərəʊz/ | 零点 | líng diǎn |
| stable/ˈsteɪbl/ | 稳定 | wěn dìng |
| crossover | 穿越频率 | chuān yuè pín lǜ |
| phase margin | 相位裕度 | xiàng wèi yù dù |
| root locus | 根轨迹 | gēn guǐ jì |
How fast, how much overshoot?
- Given a transfer function, an engineer must say how its output will move: how fast, how much overshoot, and whether it settles at all.
- The roots of the denominator are the poles; the roots of the numerator are the zeros. Poles in the left half-plane decay, so the system is stable.
A pole in the right half-plane means:
难度 1/5 · 今日首次完成可获 100 金币及少量额外奖励
e to a positive power grows.
The second-order dictionary
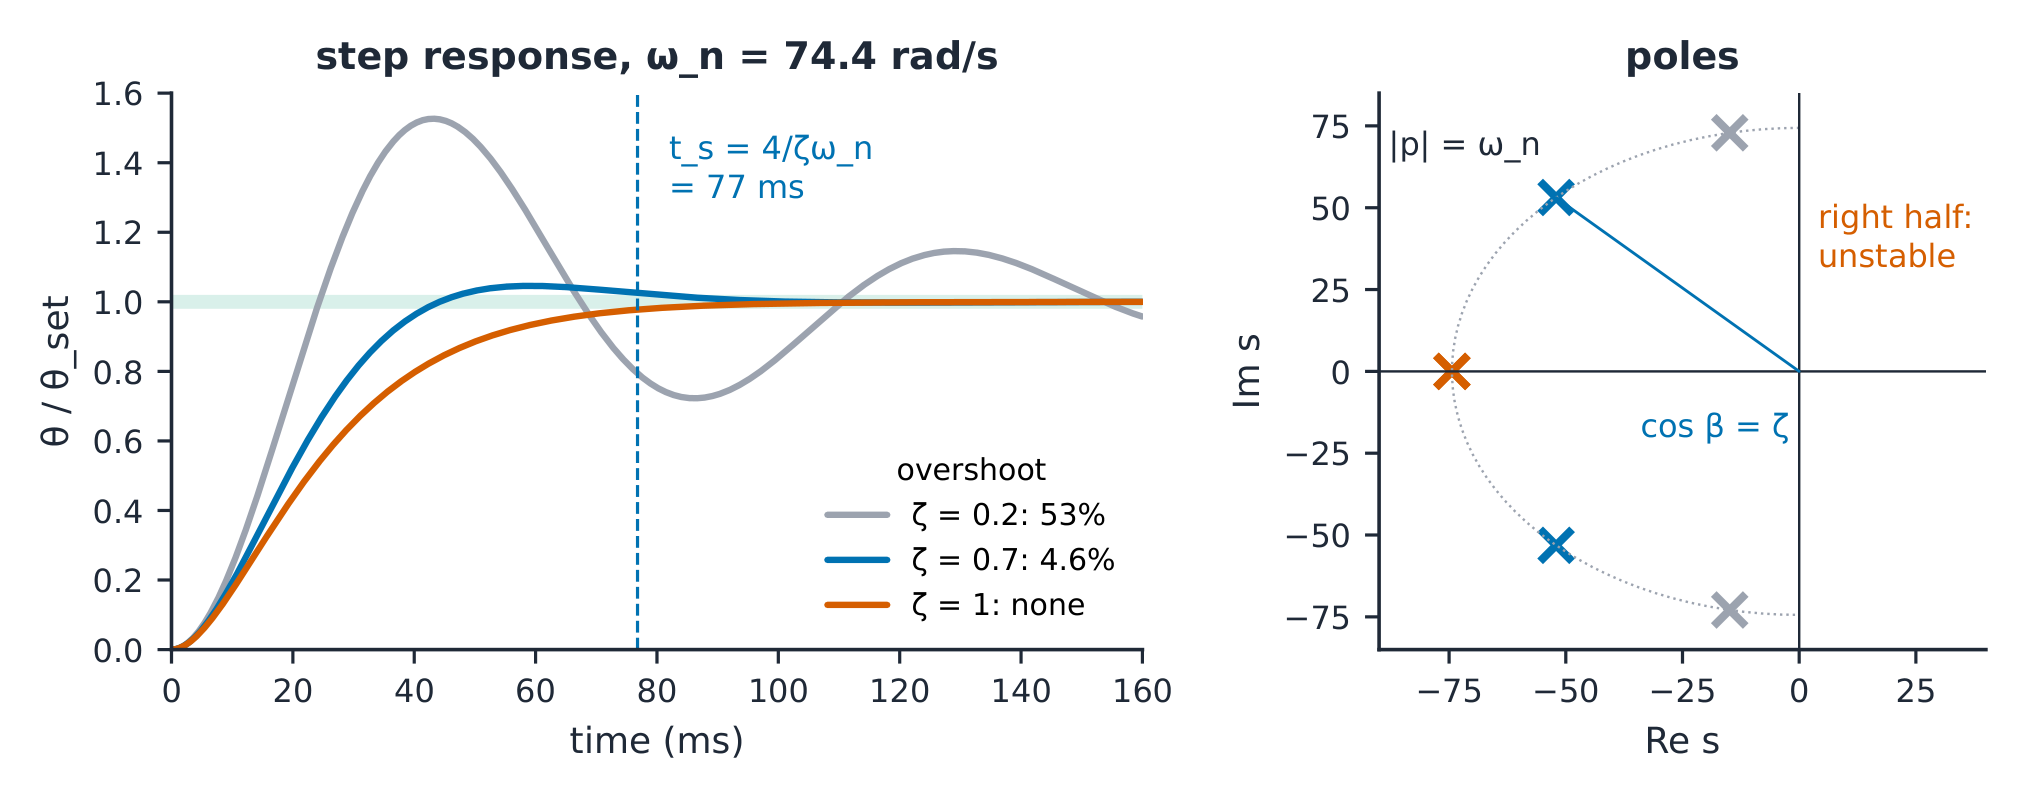
- Poles at $-\zeta\omega_n \pm j\omega_n\sqrt{1 - \zeta^2}$: their distance from the origin is $\omega_n$, and their angle from the negative real axis is $\cos^{-1}\zeta$.
- Overshoot $M_p = e^{-\zeta\pi/\sqrt{1 - \zeta^2}}$ at $t_p = \pi/\omega_d$, and 2% settling after $t_s \approx 4/(\zeta\omega_n)$.
What do the poles say?
Read each pole description as a response.
Overshoot at zeta = 0.7 (one decimal, percent)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
e^(-0.7 pi / root(0.51)).
The valve position loop
- Plant $0.398/[s(0.0096s + 1)]$ with gain $K_p$. For $\zeta = 0.7$: $0.398K_p = 53.1$, so $K_p = \mathbf{134}$ V/rad.
- Then $\omega_n = \mathbf{74.4}$ rad/s, overshoot $\mathbf{4.6\%}$ and $t_s = \mathbf{77}$ ms, for steps small enough to stay below 12 V.
Gain K_p for 0.398 K_p = 53.1 (V/rad, whole number)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
53.1 over 0.398.
omega_n = root(53.1/0.0096) (one decimal, rad/s)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
Root of 5531.
2% settling time 4/(zeta omega_n) (ms, whole number)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
4 over 52.1.
The frequency response
- With $s = j\omega$, the open loop has $|L| = 1$ at the crossover $\omega_c = \mathbf{48.2}$ rad/s, where the phase is −114.8°: a phase margin of $\mathbf{65.2°}$.
- The rule $\zeta \approx PM/100 = 0.65$ agrees with the 0.7 designed for. Gain alone cannot destabilise this loop, but delay can.
Phase margin with phase -114.8 degrees at crossover (one decimal, degrees)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
180 minus 114.8.
More gain cannot settle faster
- The closed-loop poles solve $0.0096s^2 + s + 0.398K_p = 0$. As $K_p$ rises they move along the root locus 根轨迹: from 0 and −104.2 towards each other, then up and down the vertical line $s = -52.1$.
- Once complex, their real part stays at −52.1, so $t_s = 4/52.1 = \mathbf{77}$ ms for every gain beyond critical. More gain buys speed of rise and overshoot, never faster settling; that needs a faster motor or a lead term.
Loop $0.0096s^2 + s + 0.398K_p = 0$ with complex poles: their real part (one decimal)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
$-1/(2 \times 0.0096) = -52.1$, whatever the gain.
Raising $K_p$ past critical damping shortens the 2% settling time of this loop.
难度 1/5 · 今日首次完成可获 100 金币及少量额外奖励
The poles move vertically at $\sigma = -52.1$, so $t_s \approx 4/52.1$ stays 77 ms.
Worked example: double the gain
- $K_p = 268$: $\omega_n = \sqrt{0.398 \times 268/0.0096} = \mathbf{105.4}$ rad/s and $\zeta = 1/(2 \times 0.0096 \times 105.4) = 0.494$.
- Overshoot rises to $\mathbf{16.8\%}$ and fails the 5% spec, while $t_s$ stays 77 ms. The loop rises sooner and rings more: the design value of 134 was the better trade.
Same loop with $K_p = 268$: percentage overshoot (one decimal, %)?
难度 2/5 · 今日首次完成可获 140 金币及少量额外奖励
$\omega_n = 105.4$, $\zeta = 0.494$; $e^{-\zeta\pi/\sqrt{1 - \zeta^2}} = 0.168$.
Three response slips
- Second-order formulas with nearby extra poles or zeros. They shift the response.
- $t_s = 4/\zeta\omega_n$ when the actuator saturates. The linear estimate no longer holds.
- A pole at the origin called stable. It is marginally stable.
A system with a pole at the origin is stable.
难度 1/5 · 今日首次完成可获 100 金币及少量额外奖励
It is marginally stable.
Recap
- Distance $\omega_n$, angle $\cos^{-1}\zeta$; $M_p = e^{-\zeta\pi/\sqrt{1 - \zeta^2}}$.
- $K_p = 134$: $\omega_n = 74.4$ rad/s, 4.6% overshoot, 77 ms.
- Crossover 48.2 rad/s, phase margin 65.2°.