PID control and compensation
Diperkenalkan| English | Makna |
|---|---|
| PID controller | Pengontrol PID |
| proportional/prəˈpɔːʃənl/ | proporsional |
| integral/ˈɪntɪɡrəl/ | integral |
| derivative/dɪˈrɪvətɪv/ | turunan |
| lead compensator | kompensator超前 (lead compensator) |
| anti-windup | anti-windup |
The controller you will tune most
- Most industrial loops run a PID. It is the first controller an engineer tunes, and the one tuned most often.
- Each of its three terms buys one behaviour and charges a known price.
Three terms
- A PID controller PID 控制器 acts on the error $e = r - y$: $u = K_{p}e + K_{i}\displaystyle\int e\,dt + K_{d}\dfrac{de}{dt}$.
- Proportional 比例 reacts now. Integral 积分 remembers, removing steady-state error. Derivative 微分 anticipates, adding damping.
Match each term to what it does.
Kesulitan 2/5 · 140 koin + bonus kecil pada penyelesaian pertama hari ini
Each term buys one behaviour; the price list follows.
Ziegler–Nichols tuning
- Raise the proportional gain until the loop just oscillates. Record the ultimate gain $K_{u}$ and the period $T_{u}$.
- The PID row of the table: $K_{p} = 0.6K_{u}$, $T_{i} = T_{u}/2$, $T_{d} = T_{u}/8$. In parallel form, $K_{i} = K_{p}/T_{i}$ and $K_{d} = K_{p}T_{d}$.
A loop oscillates at K_u = 20 with period T_u = 4 s. What integral time T_i does the Ziegler–Nichols PID row give, in s?
Kesulitan 2/5 · 140 koin + bonus kecil pada penyelesaian pertama hari ini
$T_{i} = T_{u}/2 = 2$ s, with $K_{p} = 0.6 \times 20 = 12$ dan $T_{d} = T_{u}/8 = 0.5$ s.
K_p = 28.8 and T_i = 1.11 s. What is the parallel integral gain K_i? Give 1 decimal place.
Kesulitan 2/5 · 140 koin + bonus kecil pada penyelesaian pertama hari ini
$K_{i} = K_{p}/T_{i} = 28.8/1.11 = 25.9$ per second.
The price list
- P alone never removes steady-state error. I adds phase lag. D amplifies measurement noise.
- Take the derivative of the measurement, not the error, or every setpoint step kicks the actuator.
Taking the derivative of the error, instead of the measurement, makes a setpoint step kick the actuator.
Kesulitan 1/5 · 100 koin + bonus kecil pada penyelesaian pertama hari ini
A step in r has an infinite slope, so de/dt spikes. The measured output moves smoothly, so derivative on y avoids the kick.
Worked example: Ziegler–Nichols
- The running plant oscillates at $K_{u} = 48$, $T_{u} = 2.22$ s, so $K_{p} = 28.8$, $T_{i} = 1.11$ s, $T_{d} = 0.278$ s.
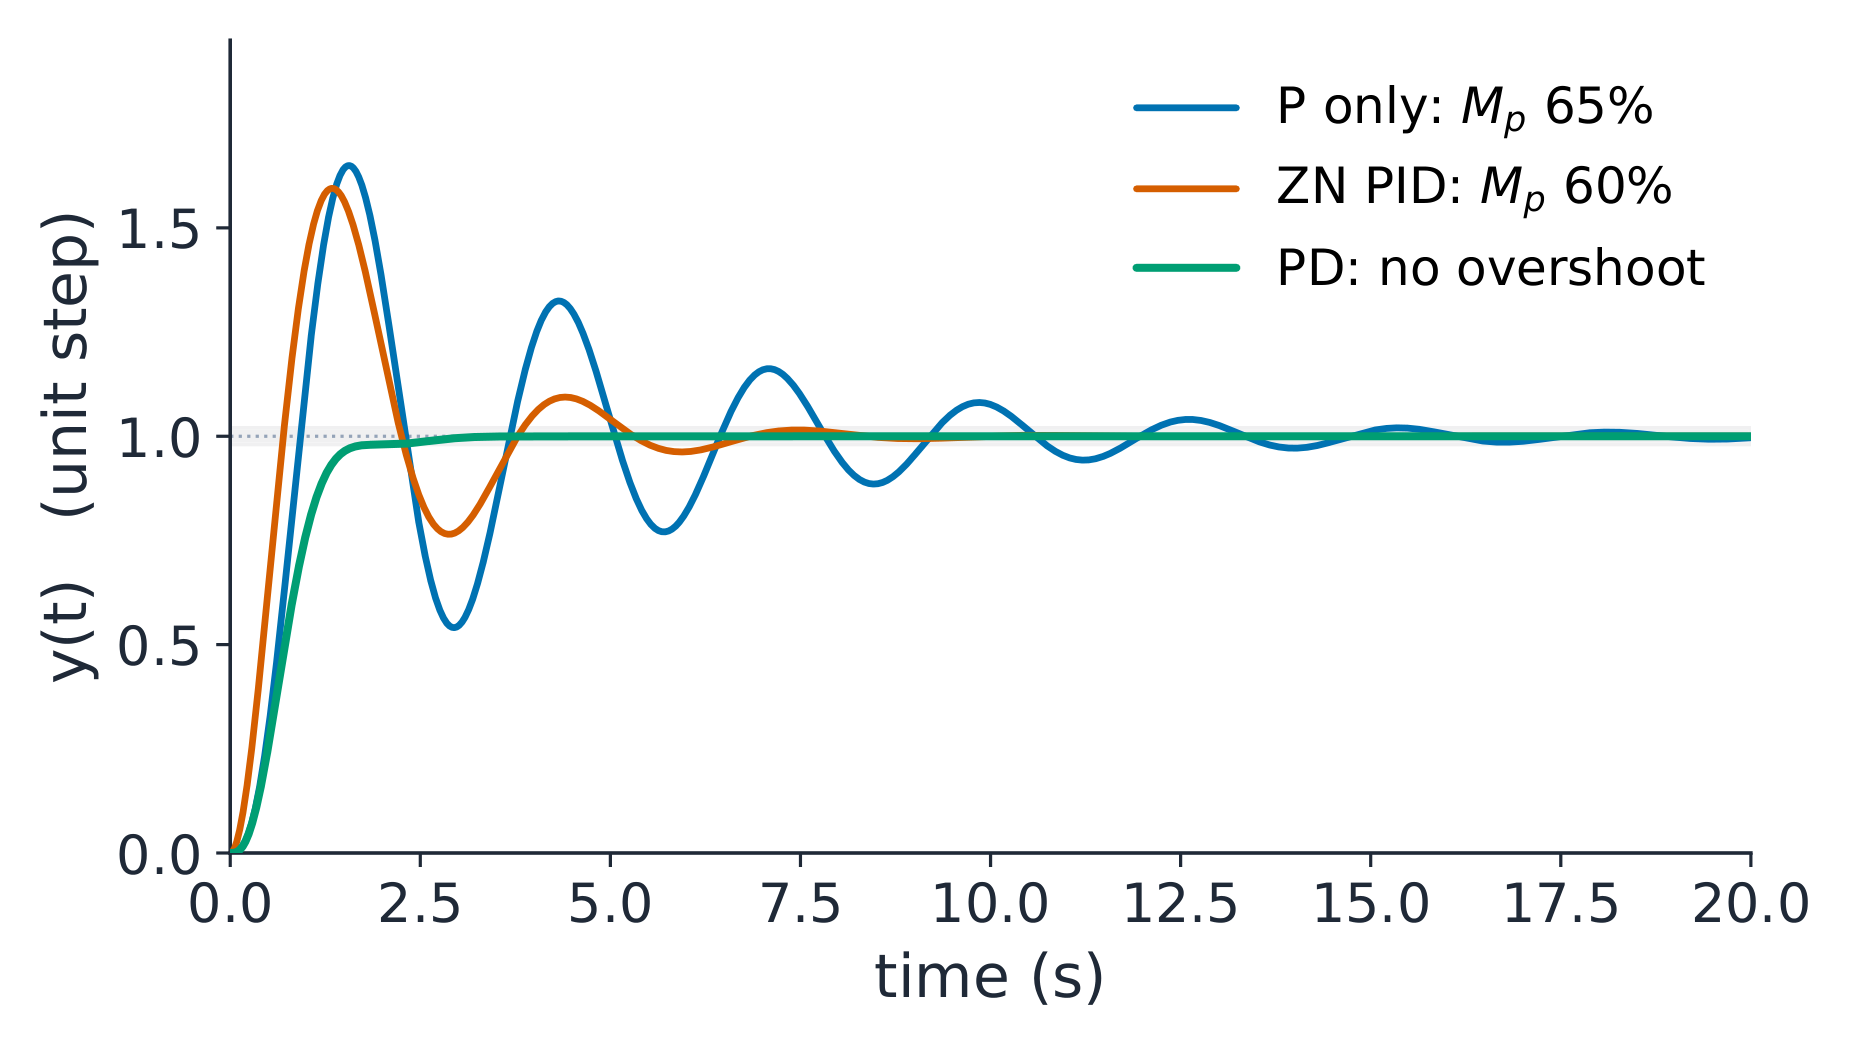
- P alone overshoots 65% and leaves a ramp error of $8/K_{p} = 0.278$. The PID removes that error but still rings at 60%: a first cut, not a finish.
The running plant 1/[s(s + 2)(s + 4)] runs with P control, K_p = 16. What is the ramp error?
Kesulitan 2/5 · 140 koin + bonus kecil pada penyelesaian pertama hari ini
$K_{v} = K_{p}/(2 \times 4) = 2$, so the ramp error is $1/K_{v} = 0.5$. An integrator would remove it.
Worked example: add derivative
- With $K_{p} = 28.8$ the PD polynomial is $s^{3} + 6s^{2} + (8 + K_{p}T_{d})s + K_{p}$: derivative adds to the damping term.
- At $T_{d} = 0.5$ s the poles are $-2$ and $-2 \pm j3.22$. With D on the measurement the step shows no overshoot and settles in 2.1 s.
One knob for gain, one for damping
Move Kp and Td and watch overshoot, settling and the Routh verdict move together; gain alone breaks the loop at 48, and damping repairs it.
With K_p = 20 and T_d = 0.3 s on the running plant, what is the s-coefficient of the PD characteristic polynomial?
Kesulitan 2/5 · 140 koin + bonus kecil pada penyelesaian pertama hari ini
$8 + K_{p}T_{d} = 8 + 6 = 14$. Derivative raises the damping term directly.
The lead compensator
- A lead compensator 超前校正装置 $\dfrac{1 + \tau s}{1 + \alpha\tau s}$, with $0 < \alpha < 1$, adds phase near one frequency: $\sin\phi_{m} = \dfrac{1 - \alpha}{1 + \alpha}$.
- For +45°, $\alpha = 0.172$. It also raises the high-frequency gain by $1/\alpha = 5.8$, which the design must absorb.
A lead network must add 30° at its peak. What α does it need? Give 3 decimal places.
Kesulitan 2/5 · 140 koin + bonus kecil pada penyelesaian pertama hari ini
$\alpha = (1 - \sin 30°)/(1 + \sin 30°) = 0.5/1.5 = 0.333$. Its high-frequency gain rises by $1/\alpha = 3$.
Anti-windup
- When the actuator saturates, the integrator keeps adding error it cannot use, then releases it as one big overshoot.
- Anti-windup 抗饱和 stops this: clamp the integrator while saturated, or feed back the saturation excess.
Three common slips
- Ultimate gain on a plant that never oscillates. Use the step-response version of the table.
- Mixing tuning forms. $K_{p}, T_{i}, T_{d}$ are not the parallel gains.
- Forgetting the lead's $1/\alpha$. The extra high-frequency gain eats the margin you bought.
Recap
- P reacts, I remembers, D anticipates.
- Ziegler–Nichols gives a first cut; margins and simulation finish the job.
- Derivative on the measurement; anti-windup always.